Copter-4.7.1 released!

Copter-4.7.1 has been released as the stable/official version for multicopters and traditional helicopters and can be downloaded using Mission Planner, QGC or directly downloaded from firmware.ardupilot.org.

The list of changes vs 4.7.0 are in the ReleaseNotes and copied below.

  1. Board specific changes
  • ARKV6S board added (@dakejahl, PR:33157)
  • CORVON_V5 board added (@holydust, PR:33593)
  • DAKEFPV boards add support for LSM6DSV and BMI270 IMUs (@engineer-dakefpv, PR:33984)
  • FlywooF405S-AIO and -HD boards support SPL06 barometer (@mbuzdalov, PR:33779)
  • KakuteH7-Wing boards support LSM6DSV IMU (@zebulon-86, PR:33761)
  • ORBITH743v2 board added (@orbittechnologyx, PR:33582)
  1. Plane specific changes
  • Q_P_JERK_NE/D renamed to Q_P_NE/D_JERK (@rmackay9, PR:33843)
  • Quadplane: In transition only set TECS throttle min in auto throttle modes (@IamPete1, PR:33972)
  1. Copter specific changes
  • Auto mode climbing Arc waypoint speed limits and velocity/acceleration fixed (@lthall, PR:33833)
  • Auto mode fix to continue past RTL if rtl-final-descent non-zero (@rmackay9, PR:33797)
  • Circle mode entry fixed when RC input present (@peterbarker, PR:33525)
  • PSC_JERK_NE/D renamed to PSC_NE/D_JERK (@rmackay9, PR:33843)
  • Simple mode fixed (@rmackay9, PR:33947)
  1. Library/Driver changes
  • AC_WPNAV: Use of uninitialised values avoided in m/cm conversion code (@peterbarker, PR:33715)
  • AP_Filesystem: Files without an End-Of-Line character get correctly read (@peterbarker, PR:33744)
  • AP_FlashStorage: Fix incorrect value of current_sector during init (@Juergen-Fahlbusch, PR:33640)
  • AP_Follow: Fix parameter ranges to include their defaults (@lthall, PR:33928)
  • AP_GPS: Unicore baseline correction in vertical component of Unicore reported baseline (@lthall, PR:33730)
  • AP_Mount: Fix AlexMos yaw angle scaling (@borischernov, PR:33785)
  • AP_NavEKF: Log per-core source set in XKFS (@mykhailopylyp, PR:33904)
  • AP_OSD: use Betaflight SYM_TOTAL_DISTANCE for DisplayPort distance icon (@coreyfarley, PR:33908)
  • AP_RangeFinder: TFMiniPlus: Small delay added to improve read reliability (@IamPete1, PR:33709)
  • ChibiOS: fix overdrive disabled on H7 boards clocked above 400MHz (@andyp1per, PR:33824)
  • GCS_MAVLink: Correction in diagnostics printing (@peterbarker, PR:33800)
  • IST8310 compass gets probed only if the driver is enabled (@peterbarker, PR:32696)
  • Topotek gimbal network connection handling is corrected (@peterbarker, PR:33803)
  1. Tool changes
  • build_options.py: Wrong dependecy for MAVLINK_SIGNING has been removed (@peterbarker, PR:33798)

Thanks to the developers and beta testers who contributed to this release!

Can someone look at this and give advice? New Loiter shows overshoot in Yaw

Today I tried to do a magfit flight same way I usually do - COMPASS_USE to 0, and YAW source set to GSF, takeoff in althold and fly a bit until heading is figured out, then switching to loiter and do some circles and 8 figures.

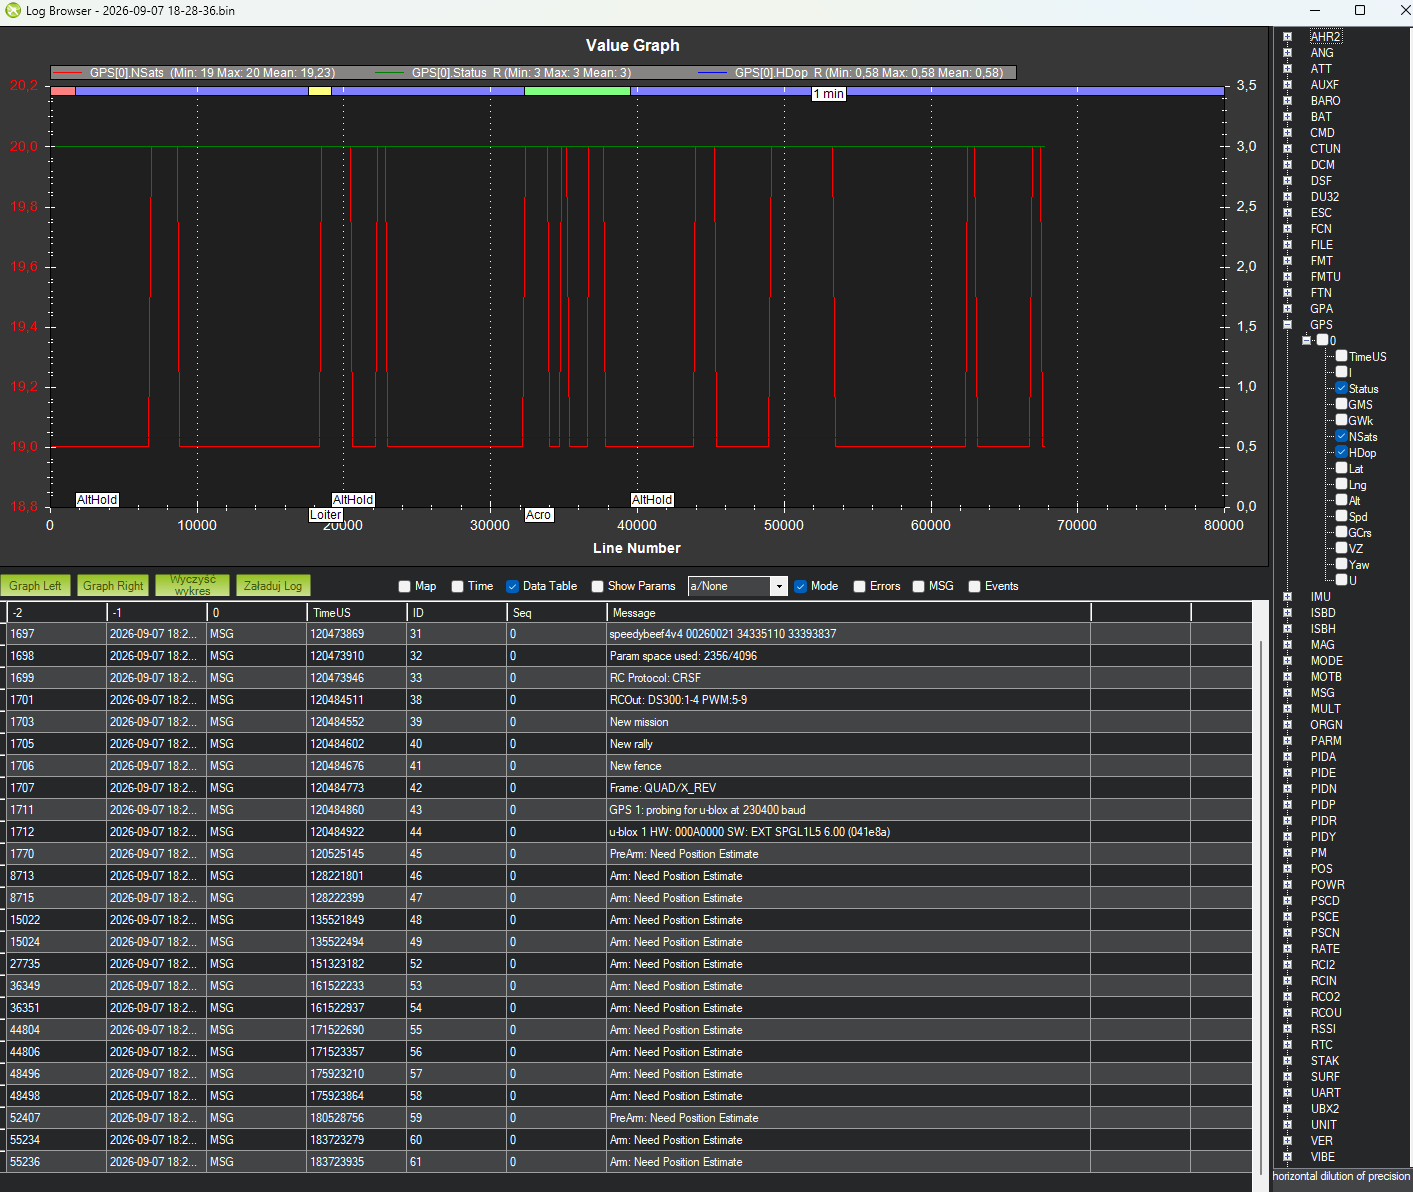
However… this seems to be not possible anymore with 4.7.1 (did not test with 4.7.0) and in MP pos_horiz_abs was constantly red and everytime I tried to arm in althold I got message “PreArm: Need Position Estimate” despite good gps fix (ublox DAN-F10N based GPS, 18+ sats, HDOP ~0.7m with SBAS), and “HOME” on OSD not blinking.

Is that a feature or a bug?

Once I allowed to use compass and set yaw source to compass, everything was fine again.

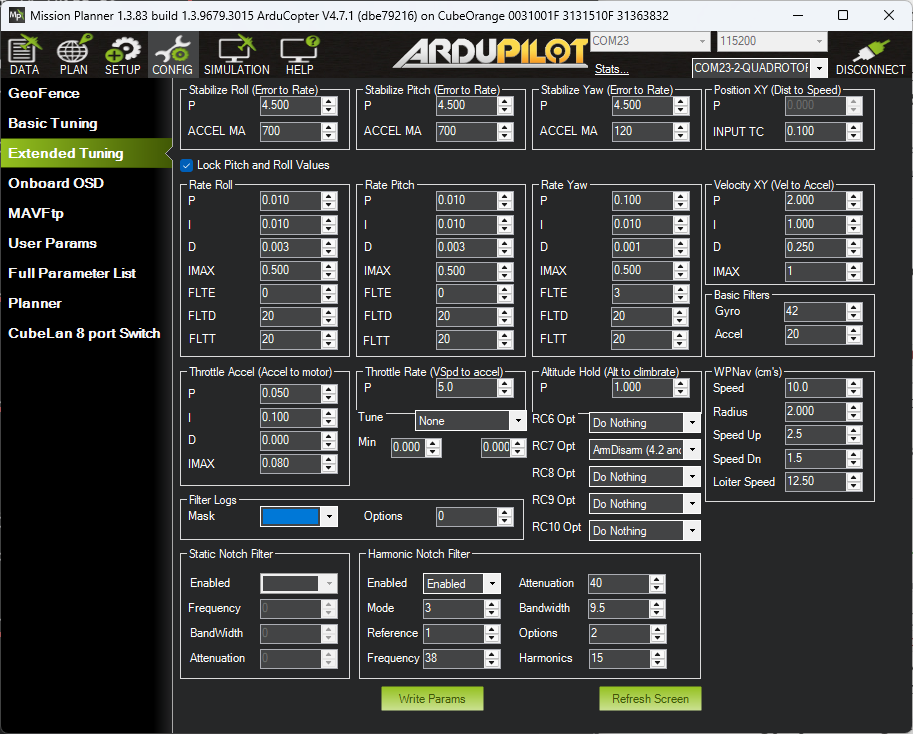
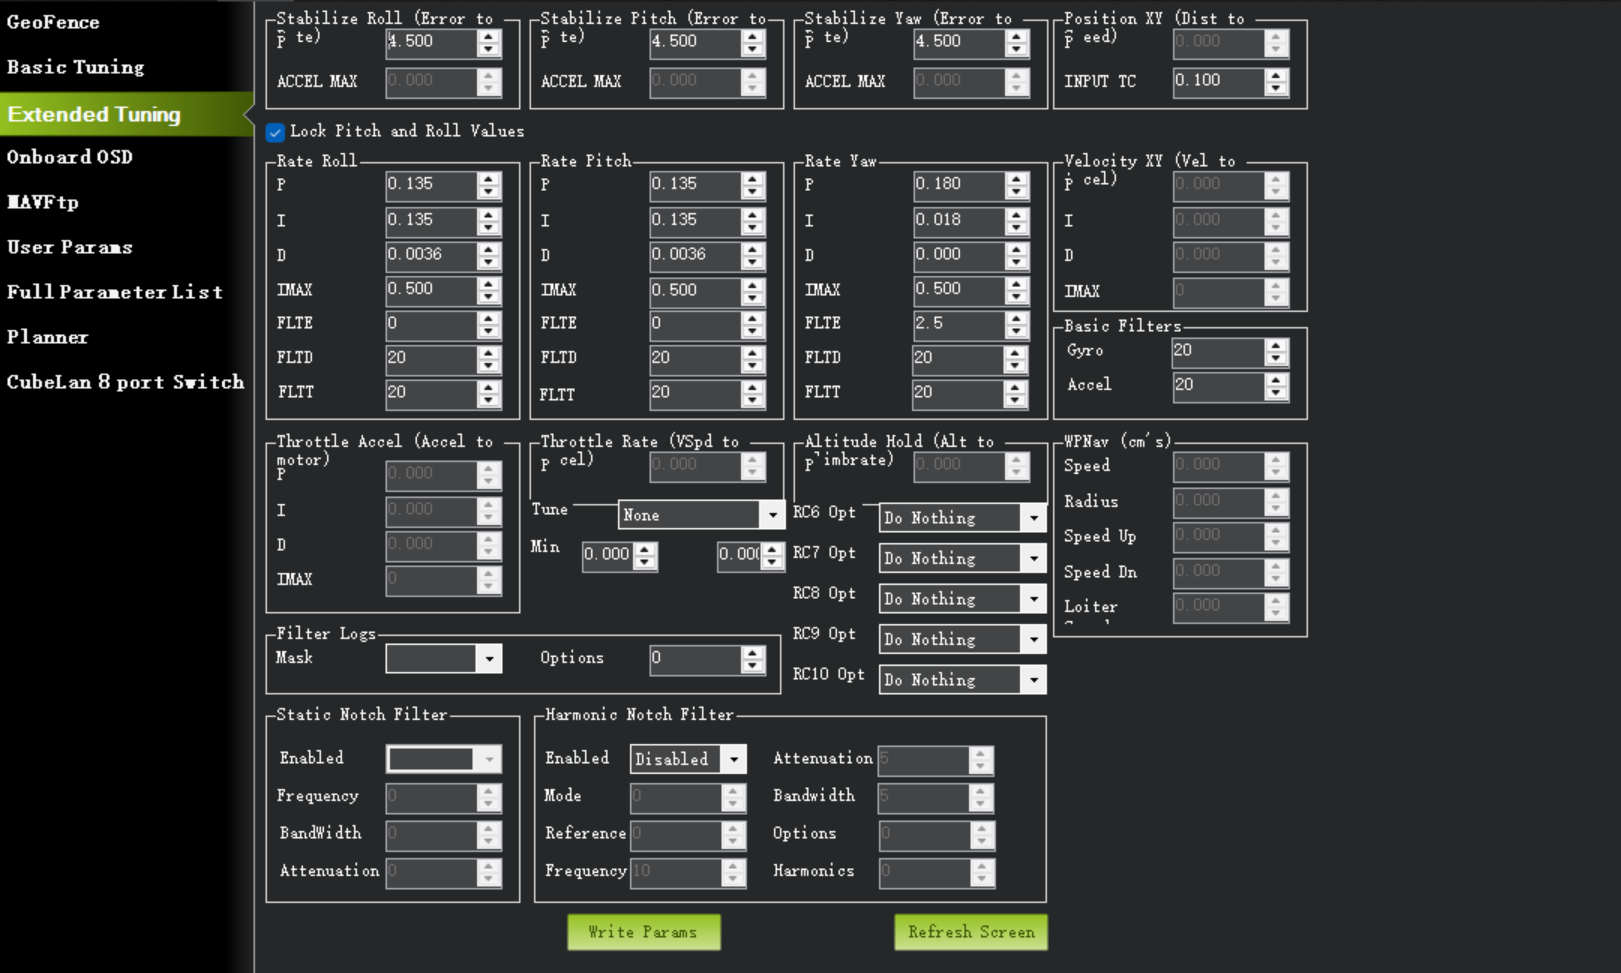
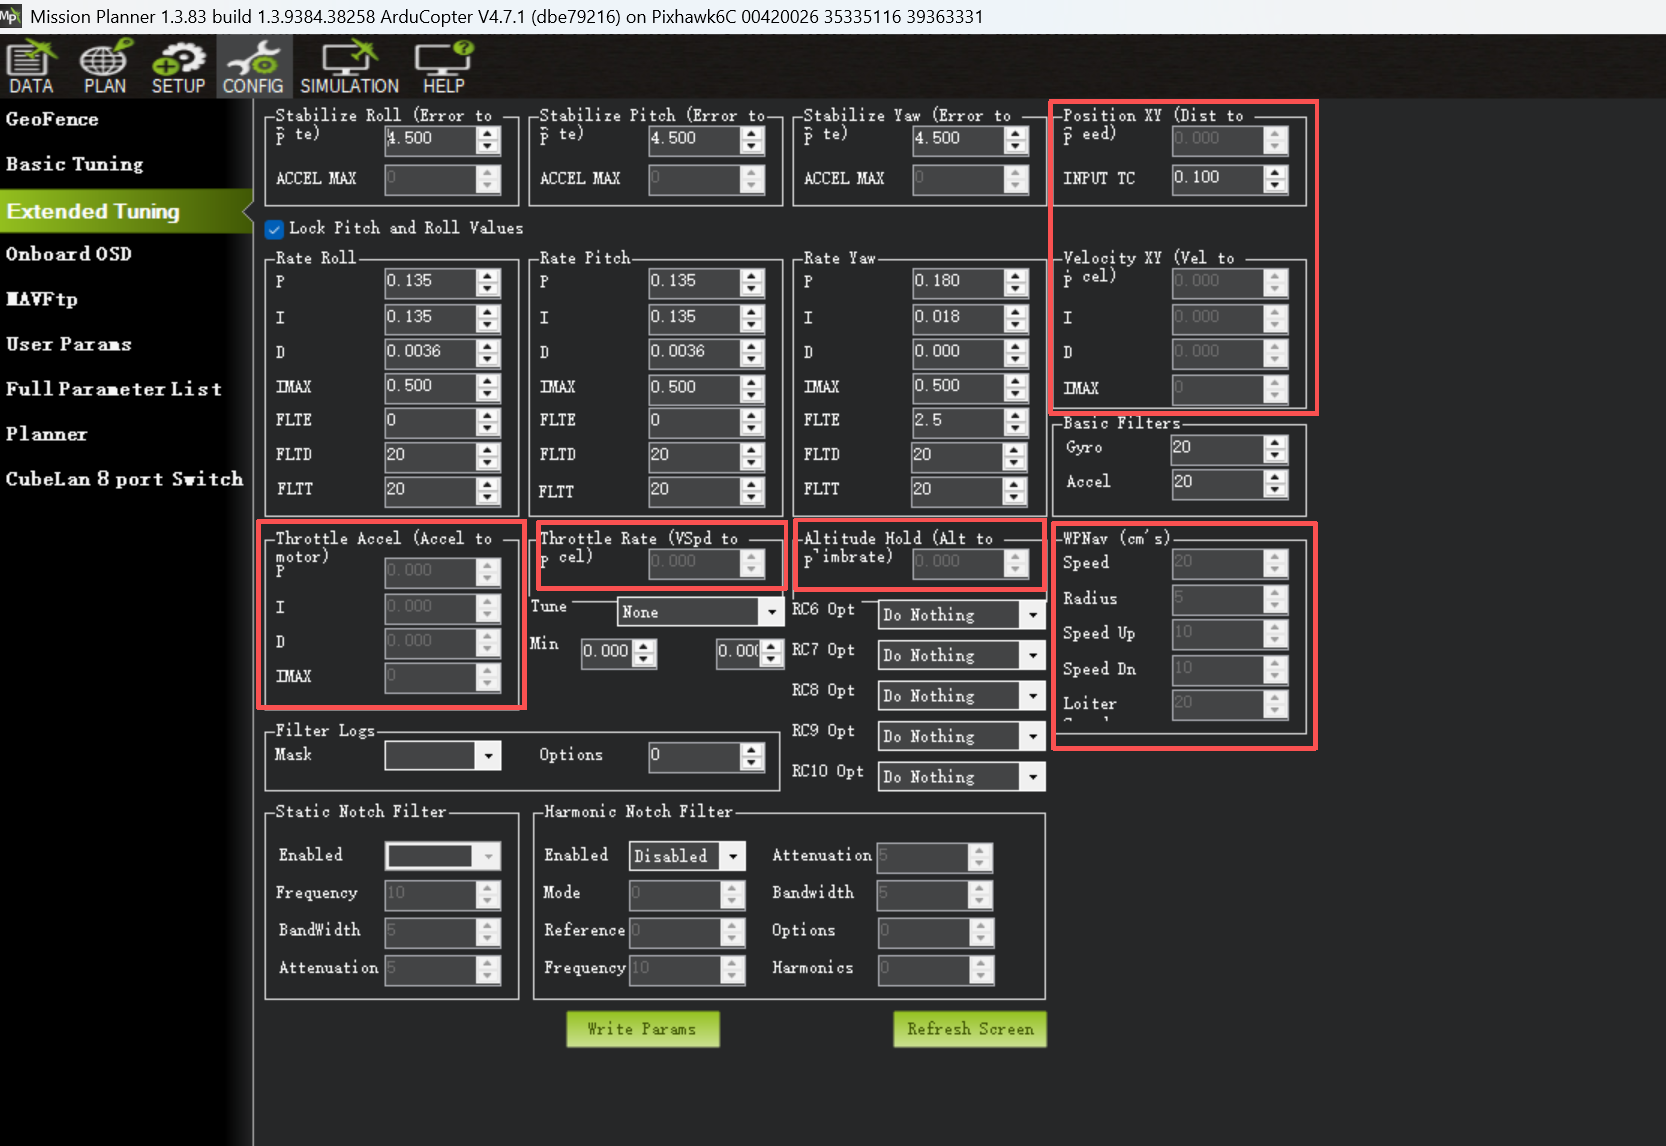
@**rmackay9**Hello, after flashing Copter 4.7.1, I found that I can no longer adjust certain parameters on the extended parameters page—such as throttle acceleration, throttle rate, and altitude hold. What is the reason for this?

Hi @Rik_Sam,

The issue is likely because we’ve updated many parameter’s names and scaling so Mission Planner also needs to be updated.

I’ve got a slightly newer version of MP installed and nearly all the fields are filled in.

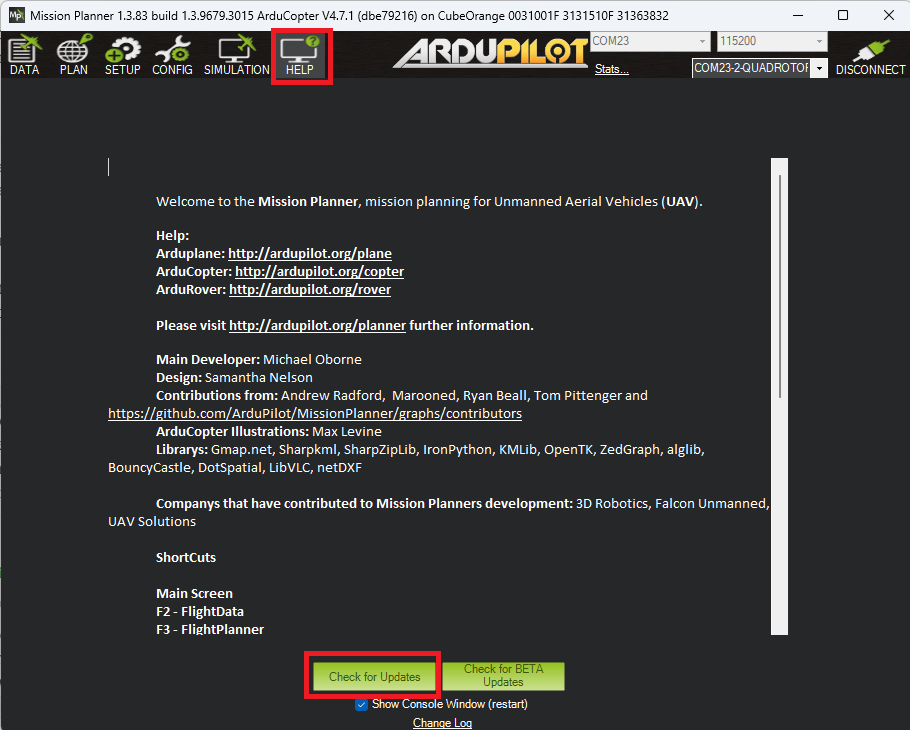
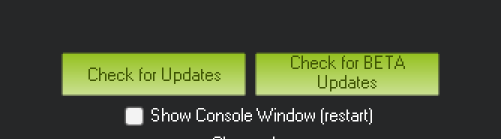
Could you try selecting “Help” “Check for Updates” to see if that resolves the issue?

Migration from 4.6.x to 4.7.x, SERIALn_OPTIONS did not migrate properly.

Hi @Jai.GAY,

Txs very much for the report. Could you be more specific about what happened?

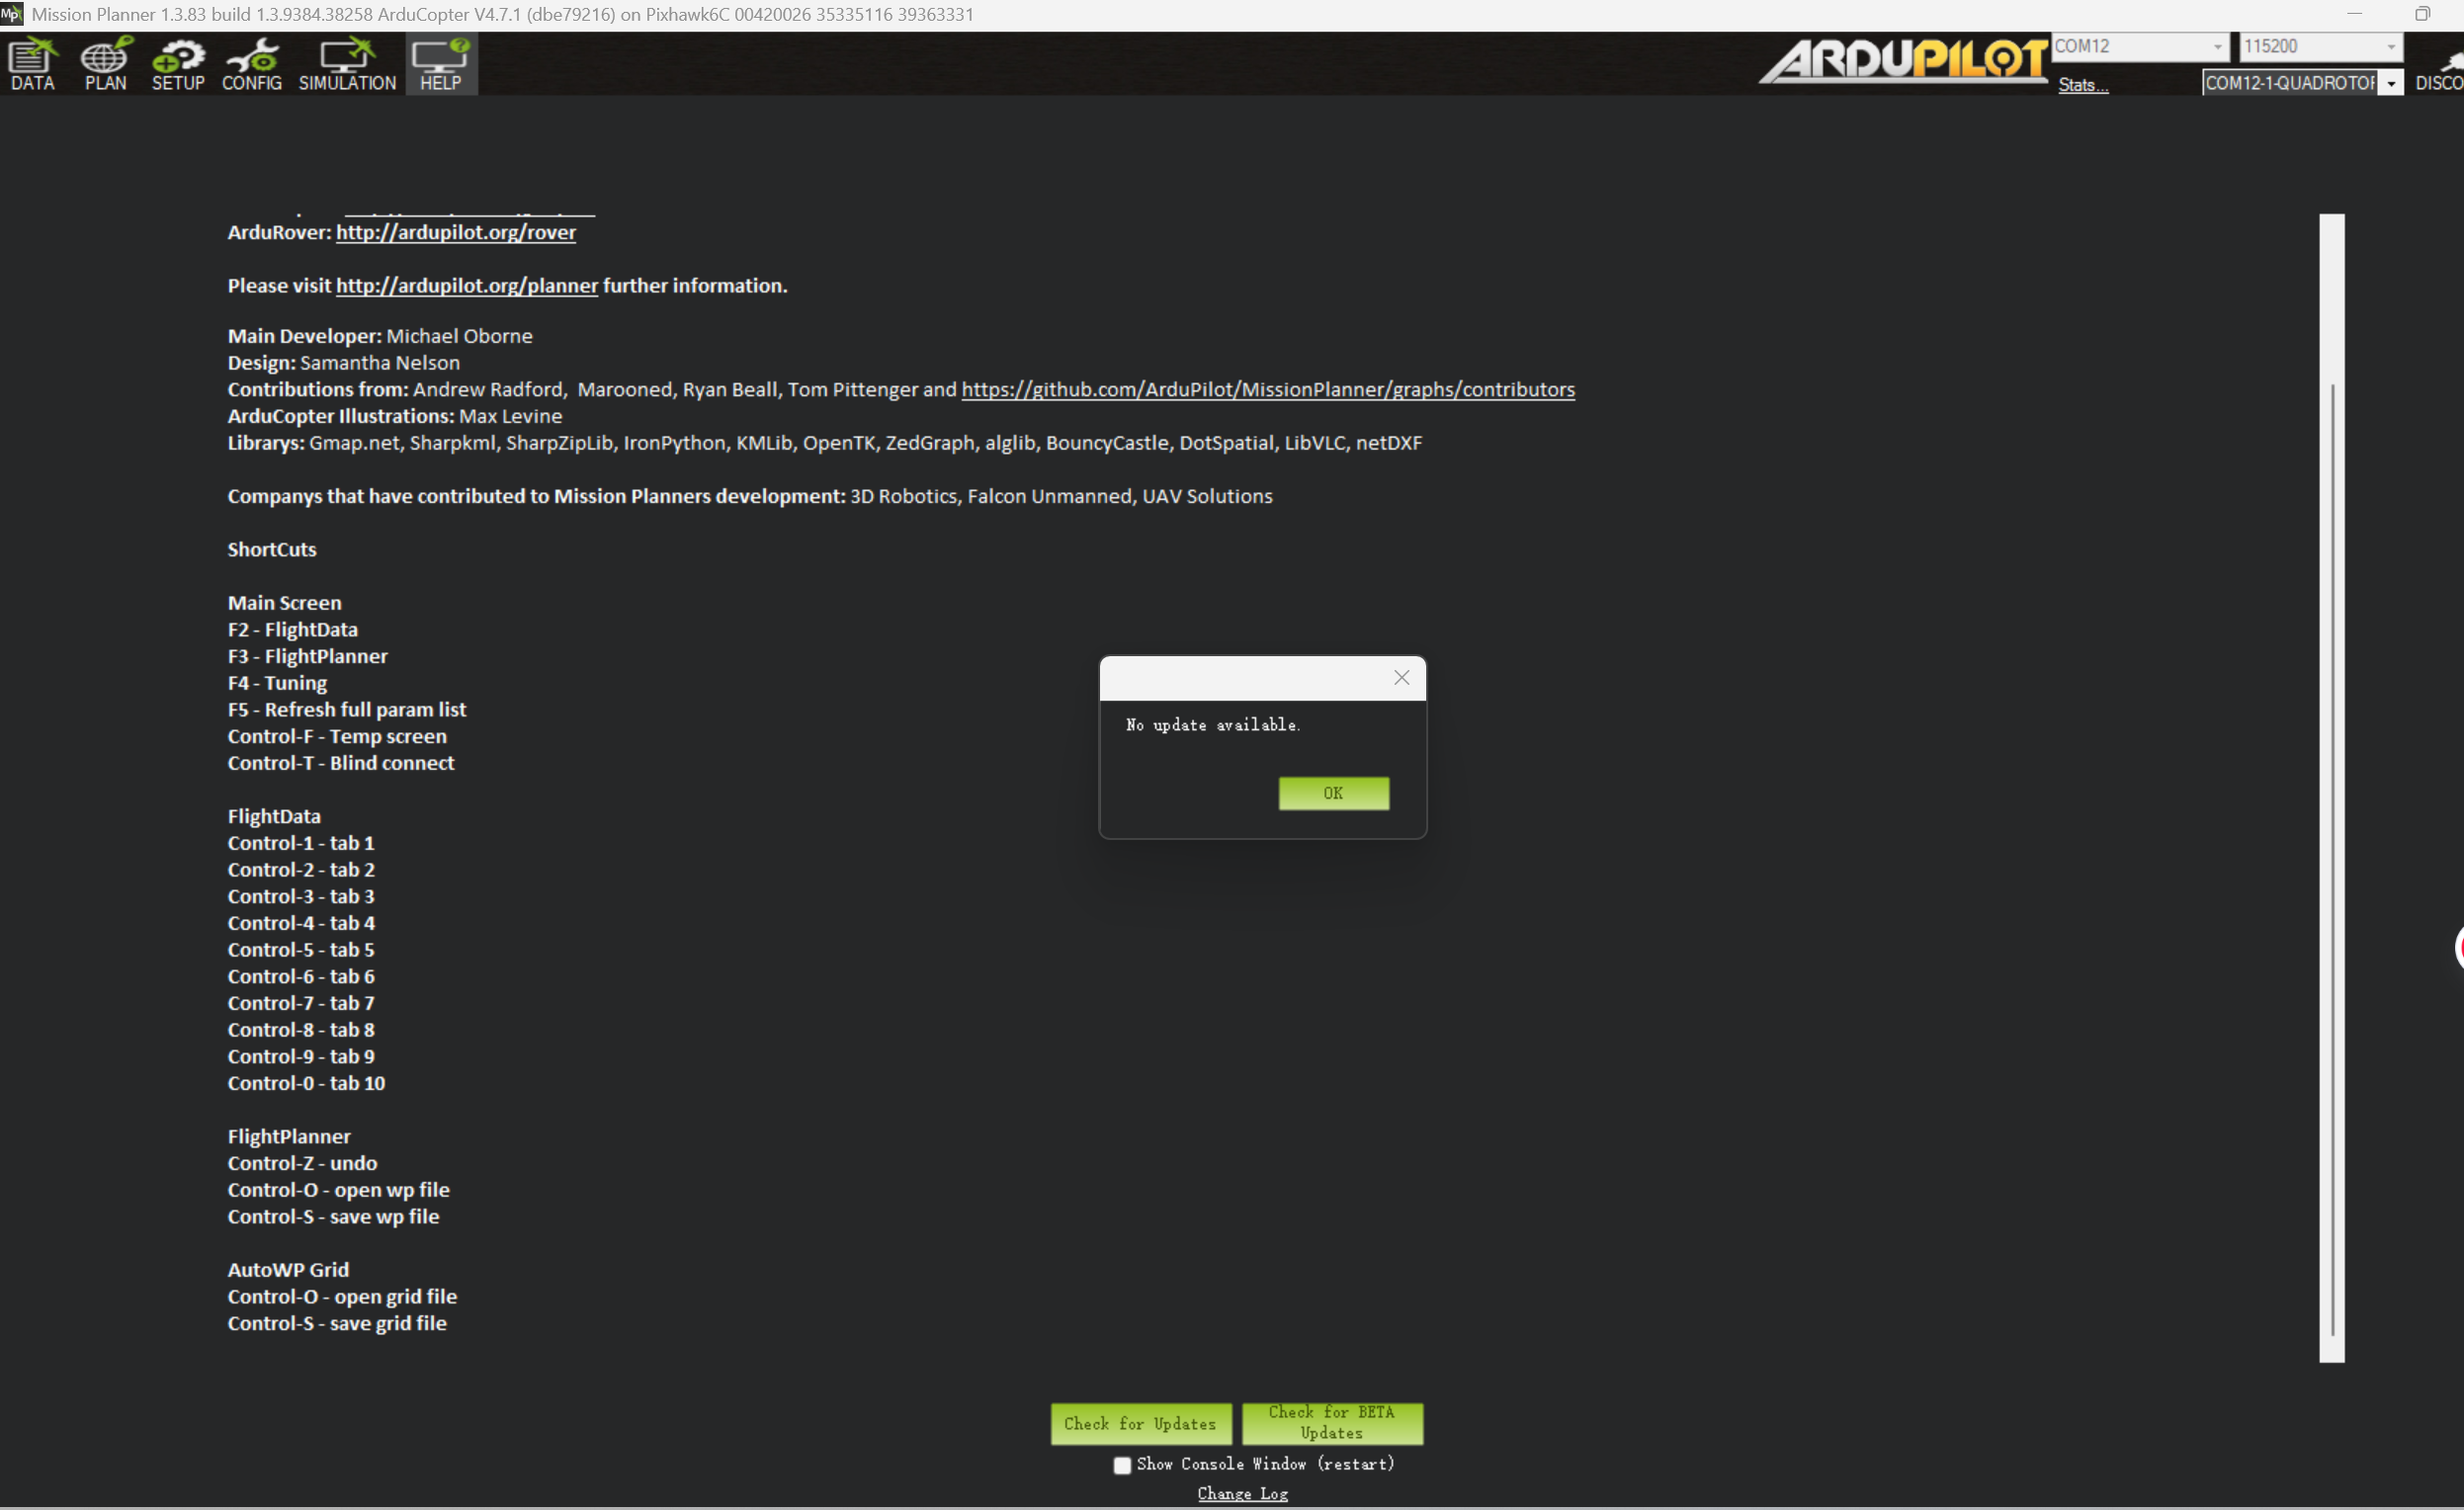
Thank you very much for your reply. I tried selecting “Help” > “Check for Updates,” but MP did not indicate that an update was available. My MP version is 1.3.83, which should be the latest version.

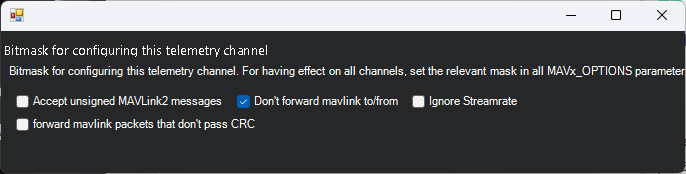
micoair recommends SERIALn_OPTIONS 1024 for their MTF-02P Optical Flow&Range Sensor, after migration, it was SERIALn_OPTIONS, 0. I am using serial 4 in MicoAir743v2-AIO-45A. How should I migrate to MAVn_OPTIONS? I set it to MAV4_OPTIONS Bit 1; am I correct?

Hello@rmackay9,

is there a version newer than 1.3.83?

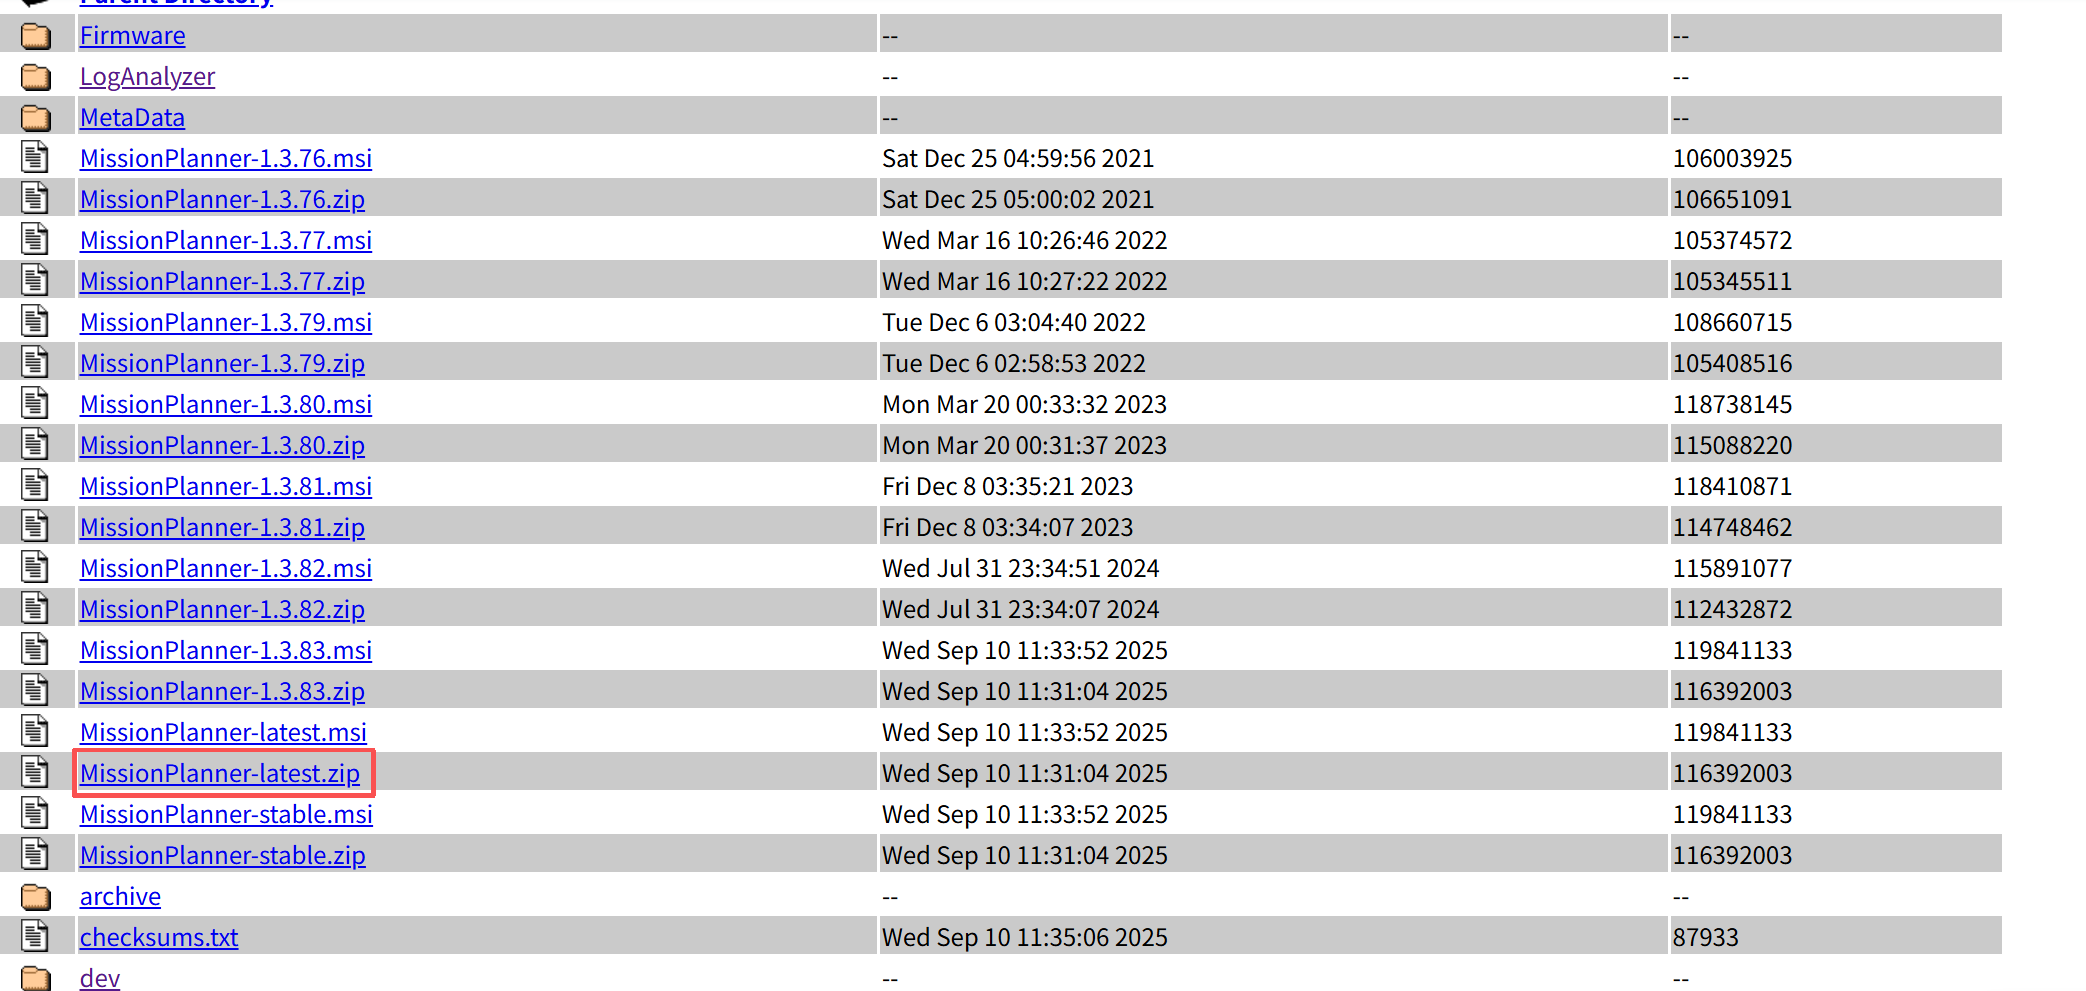
No, but do the beta update for the latest minor version.
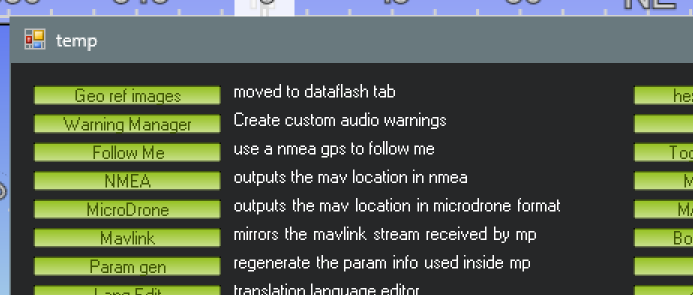
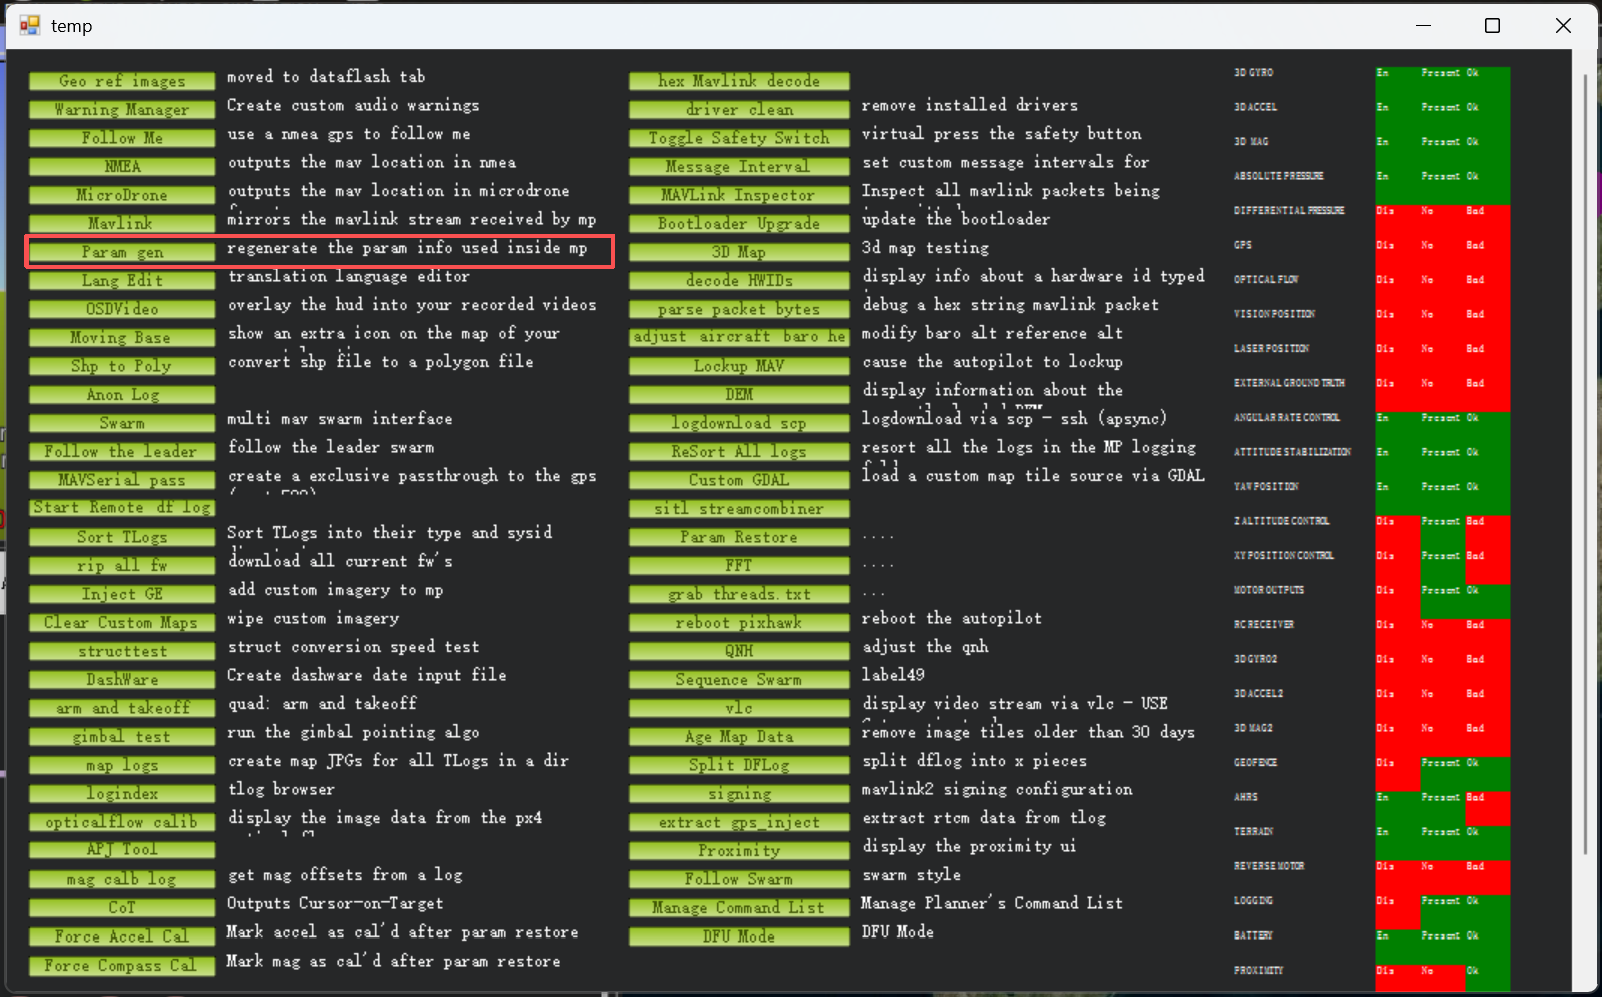
Then connect your 4.7.1 flight controller and press Control F and select “Param gen” from the extensive list.

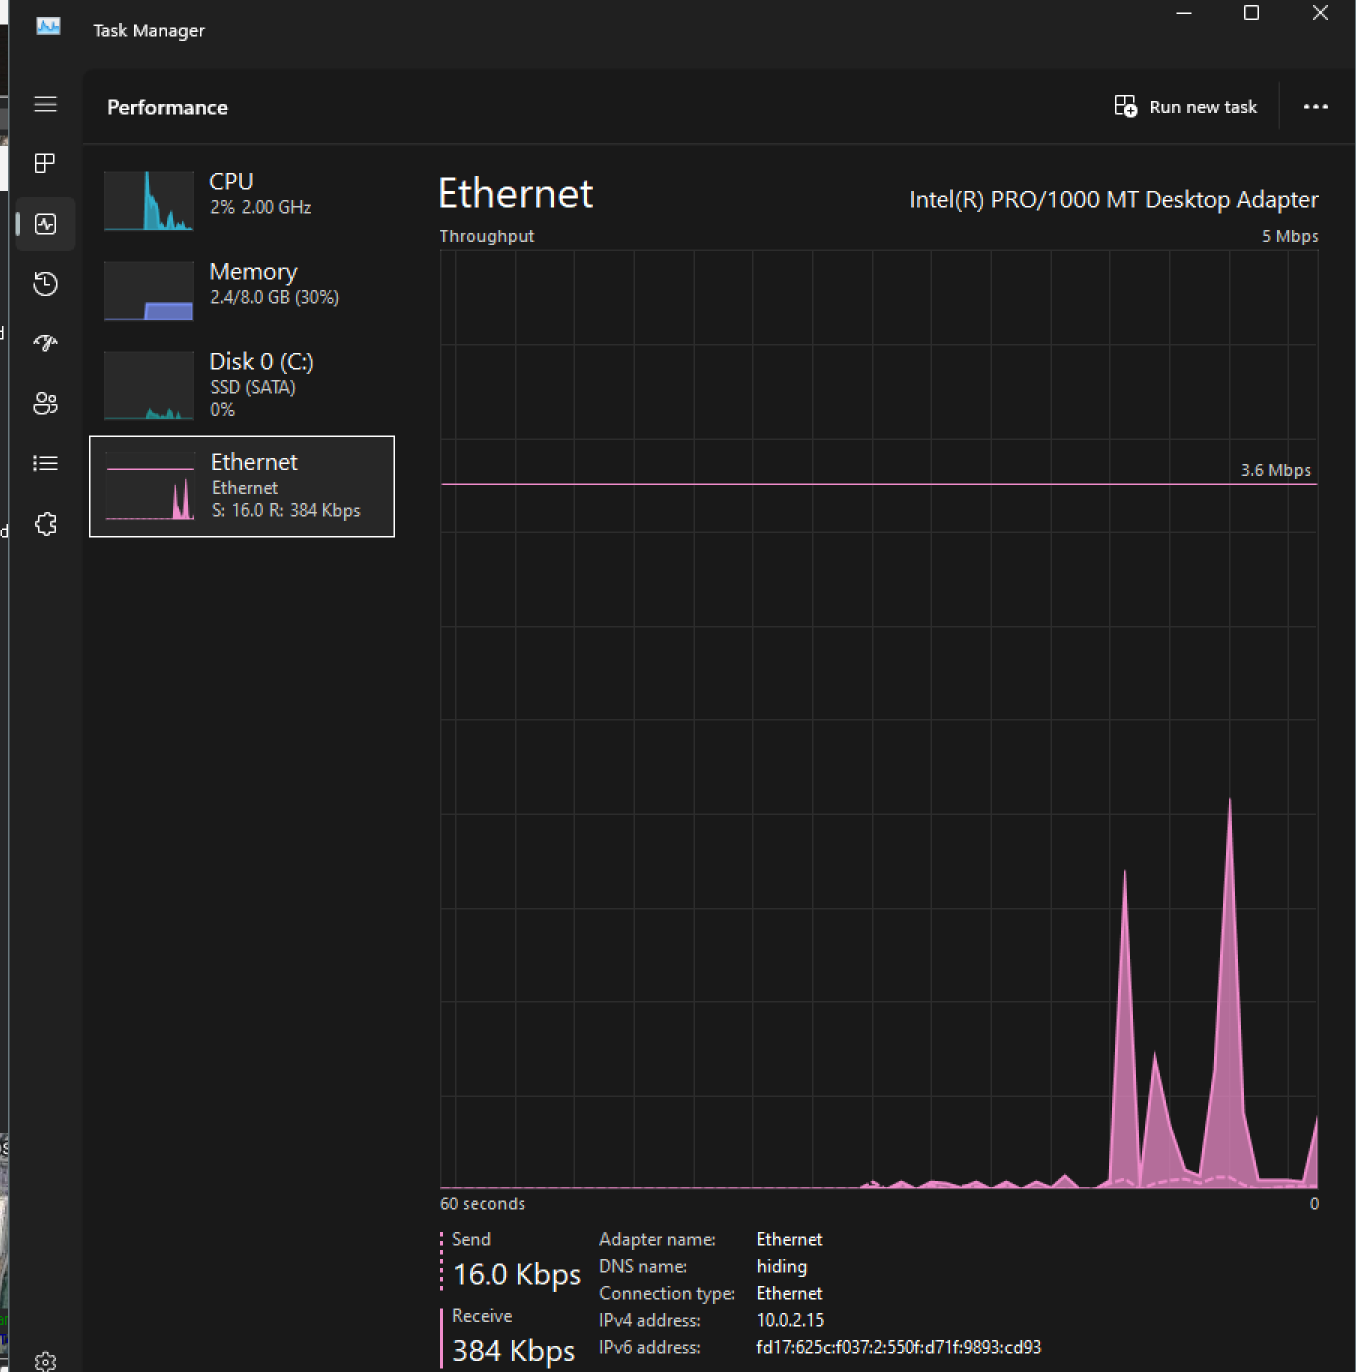
You can open Task Manager and look at your network to tell when the param download is finished, it can take a few minutes.

Hi @Rik_Sam,

I’ve ping’d MichaelO to ask him if he can release a new stable version. Sorry about that and thanks for the report!

Thanks @xfacta too!

@**xfacta**Thank you very much for your reply. Today, I followed the steps you mentioned to upgrade to Mission Planner-latest.

Then, I connected the flight controller running version 4.7.1, pressed Ctrl+F, and selected “Parameter Gen” from the list.

I am still unable to configure the settings.

In the MissionPlanner Help screen select the “Check for BETA Updates”

You dont need to download anything manually.

How come in my 4.7.1, I do not see MAV5 Parameters, MAV6 Parameters, and above in MicoAir743v2-AIO-45A ?

Hi @Jai.GAY,

I haven’t investigated but I suspect it is because there aren’t that many serial ports setup to use mavlink.

One thing that is tricky about the MAVx parameters (and it was the same for the SERx params) is that it is not a 1-to-1 mapping with the SERIALx parameters. The reason is that the MAVx parameters only apply to the serial ports which are using MAVlink.

In 4.8 we’ve added a MAVx_DEVID parameter to make it easier to figure out which serial port the MAVx parameters apply to.

I think similar to the rangefinder using serial interface. So, I just set MAV1_OPTIONS Bit 1 will do, is it?

Hi @Jai.GAY,

Yes, I think you’ll need to set MAVx_OPTIONS = 2 (“Don’t forwared mavlink to/from”). This will stop the mavlink messages from the sensor from being sent to the GCS which would just consume bandwidth and the GCS doesn’t use the data.

I’ve created this wiki issue to add this

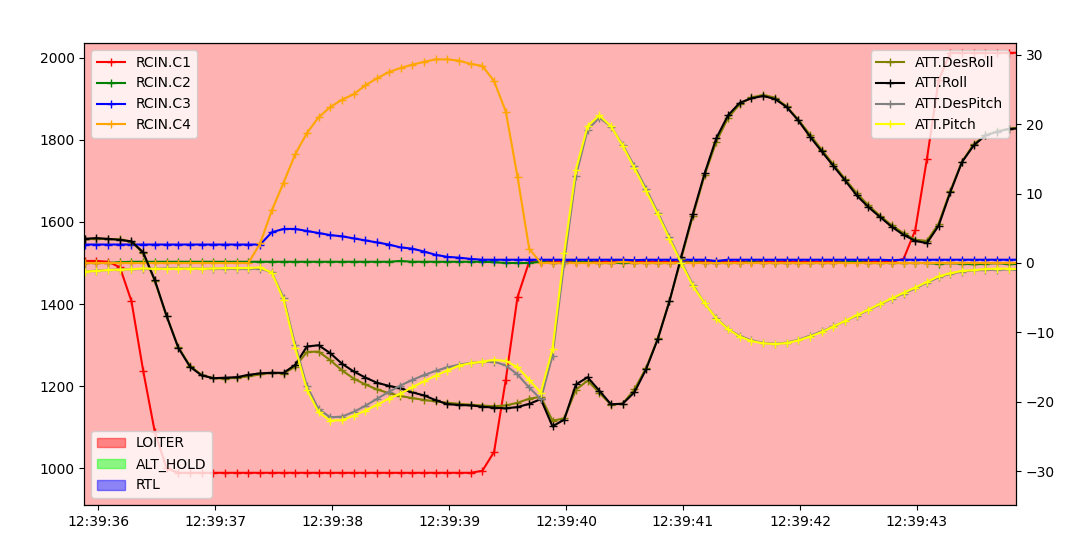
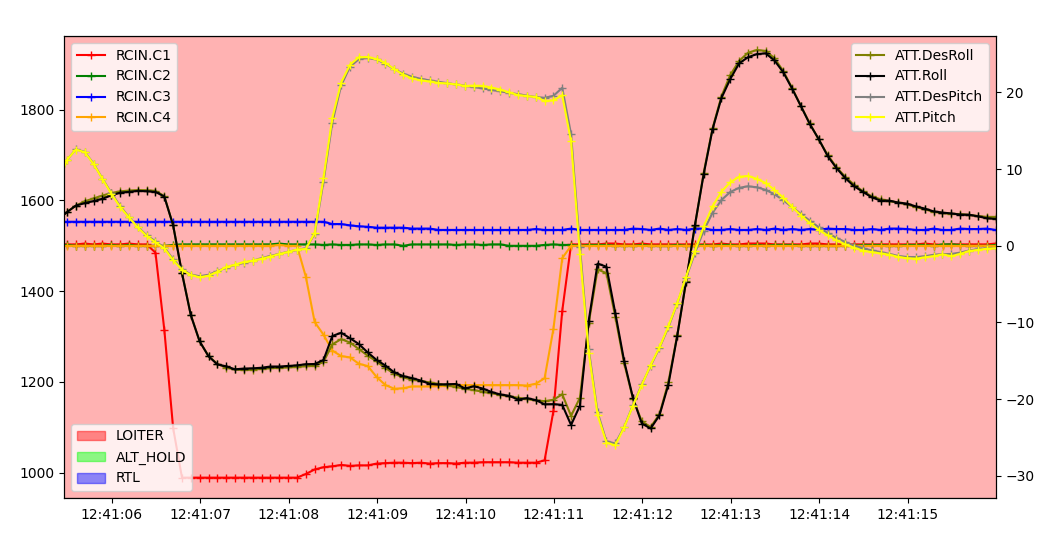
I’m seeing some strange behaviour with the coordinated turns in loiter mode. If I go from directly from a turn (yaw and pitch inputs only) to neutral sticks the quad seems to hold in an excessive counter roll angle for some time.

Two examples from the same flight:

It was repeatable, go directly from a yaw turn to a stop and the roll would hold for several seconds. It’s as if the braking action was holding on for too long. Long enough to cover some ground after centering the sticks.

If I released the yaw and continued with a pitch input then everything acted as expected, no issues.
Log: Proton Drive