Hi all, I getting a lot of yaw overshoot in realflight with the new Loitor mode but i have forgotten how to change it to reduce the relaxed behaviour,
Hi all, I getting a lot of yaw overshoot in realflight with the new Loitor mode but i have forgotten how to change it to reduce the relaxed behaviour,
The horizonal braking loiter seems ok but yaw is not. I have used quicktune.
Run the autotune, quicktune can overtune without enough disturbances.
Thanks for your response, I like to manually input the settings to make it fly pre loiter change if possable.
I just tried Autotune and Realfight can’t finish it.
Here is a tailsitter in Alt-hold. Very precise. no issues at all.
Same everything but with the new QLOITER Yaw is ok but the bird keeps flying.
Looks like i’m holding the stick forward but i just tapped it a wee bit is this normal? (@rmackay9
Hi @Quadzilla,
Re the coordinated turns, it can be disabled by setting LOIT_OPTIONS = 0.
Hi Randy, Not seeing any changes. But it is realflight. Do you think it will be ok to fly the new Loiter in tight space with trees?
Hi @Quadzilla,
Oh, you know, I can’t give any guarantees of anything really except that we will do our best if you find issues.
I guess if i want to know i have to fly it.
Kinda wish i had a better place to test… Realflight is telling me we have a possible drift issue. If i base it on the old Loiter I never had this type of problem. I had some stunning flights in the past. I guess if i want to know i have to fly it but i will need to wait until we get rain. I wonder if we could bring the old loiter back with a new flight mode name.
Here is what i consider good in this old very video.. If new loiter flys the same then no worries.
My gopro was recording x2 but it still stunning. In this video i was testing the LOC1 GPS from 3DR.
If anyone has any videos that is showing the new loiter with this quality I would be grateful.
Recent developer builds (such as ArduCopter 4.8.0-dev) have a reported regression where releasing the sticks to center in Loiter mode can cause aggressive uncommanded movement and random drifting. [1, 2]
Loiter Mode Regression in Development Builds
A recent bug report on the ArduPilot Discourse highlights a serious issue in the 4.8.0dev master branch: [1, 2]
4.6. [1, 2]Hi @Quadzilla,
That AI response is not accurate. A more accurate response would have been that a few users were surprised by Loiter’s new coordinated turns feature but their concerns were addressed by disabled the feature by setting LOIT_OPTIONS = 0.
I don’t understand the request to “bring the old loiter back”. There’s no difference between the new and old Loiter with the exception of the optional feature. Please feel free to try older versions of ArduPilot, they’re all available of course. Alternatively just disable coordinated turns.
I think what’s possibly happening is that the frame, software, configuration and environment have all changed and blame is going to the software when the issue is actually one of the other three.
If you can provide logs showing behaviour has degraded we will jump on it and investigate.
Ahh I basing this on Realfight. Yes I know i don’t need to upgrade. The changes to loiter have a big impact in the software for tailsitters. In my case i not able to make the set to zero option.
I only have my work in realflight showing the issues. Nothing has changed but the flight mode. I not trying to make blame that would not make sense. Please look at the two videos i uploaded again the Paco in alt hold and Paco in loiter. I guess the simple answer is i am unable to make the changes your asking me to do. I can ask Peter Hall we done a few realflight projects together for some a list clients. “bring the old loiter back” I did not mean to say only have one but two versions. what i said, “I wonder if we could bring the old loiter back with a new flight mode name”
Thanks for your help.
I made one more video to help show what I am seeing, this Realflight model was tested and approved and can be downloaded in Git hub. Please look at the red plane icon upper left in the MP hud and note that I just taped the sticks, please notice the model is not keeping it location as it should and is drifting way off. I have made zero changes to the working model but only currently running the new Loiter.
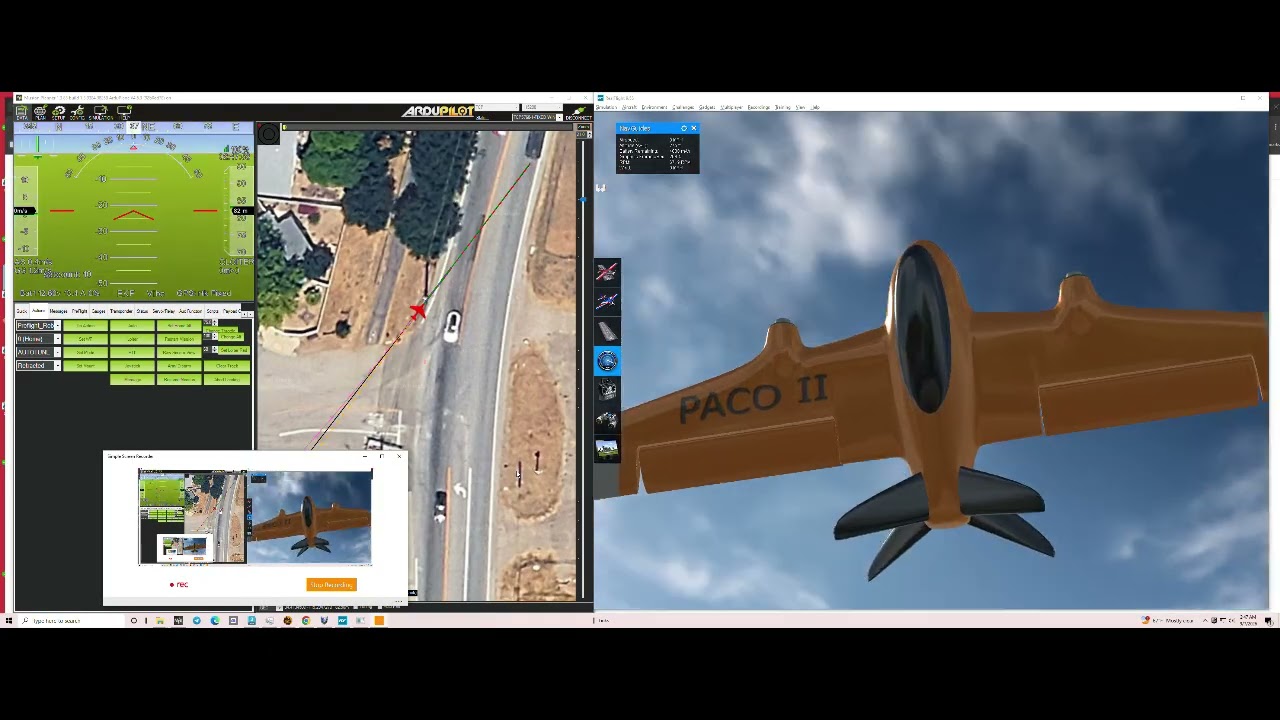
I moving this over to Realflight and flight testing
Those new coordinated turns can cause quite unpredictable behaviour when combined with rapid turns.
Hi @LupusTheCanine,
ok, maybe we should add a warning to the wiki and/or maybe Leonard would consider adding a minimum velocity threshold and we blend in the response.
