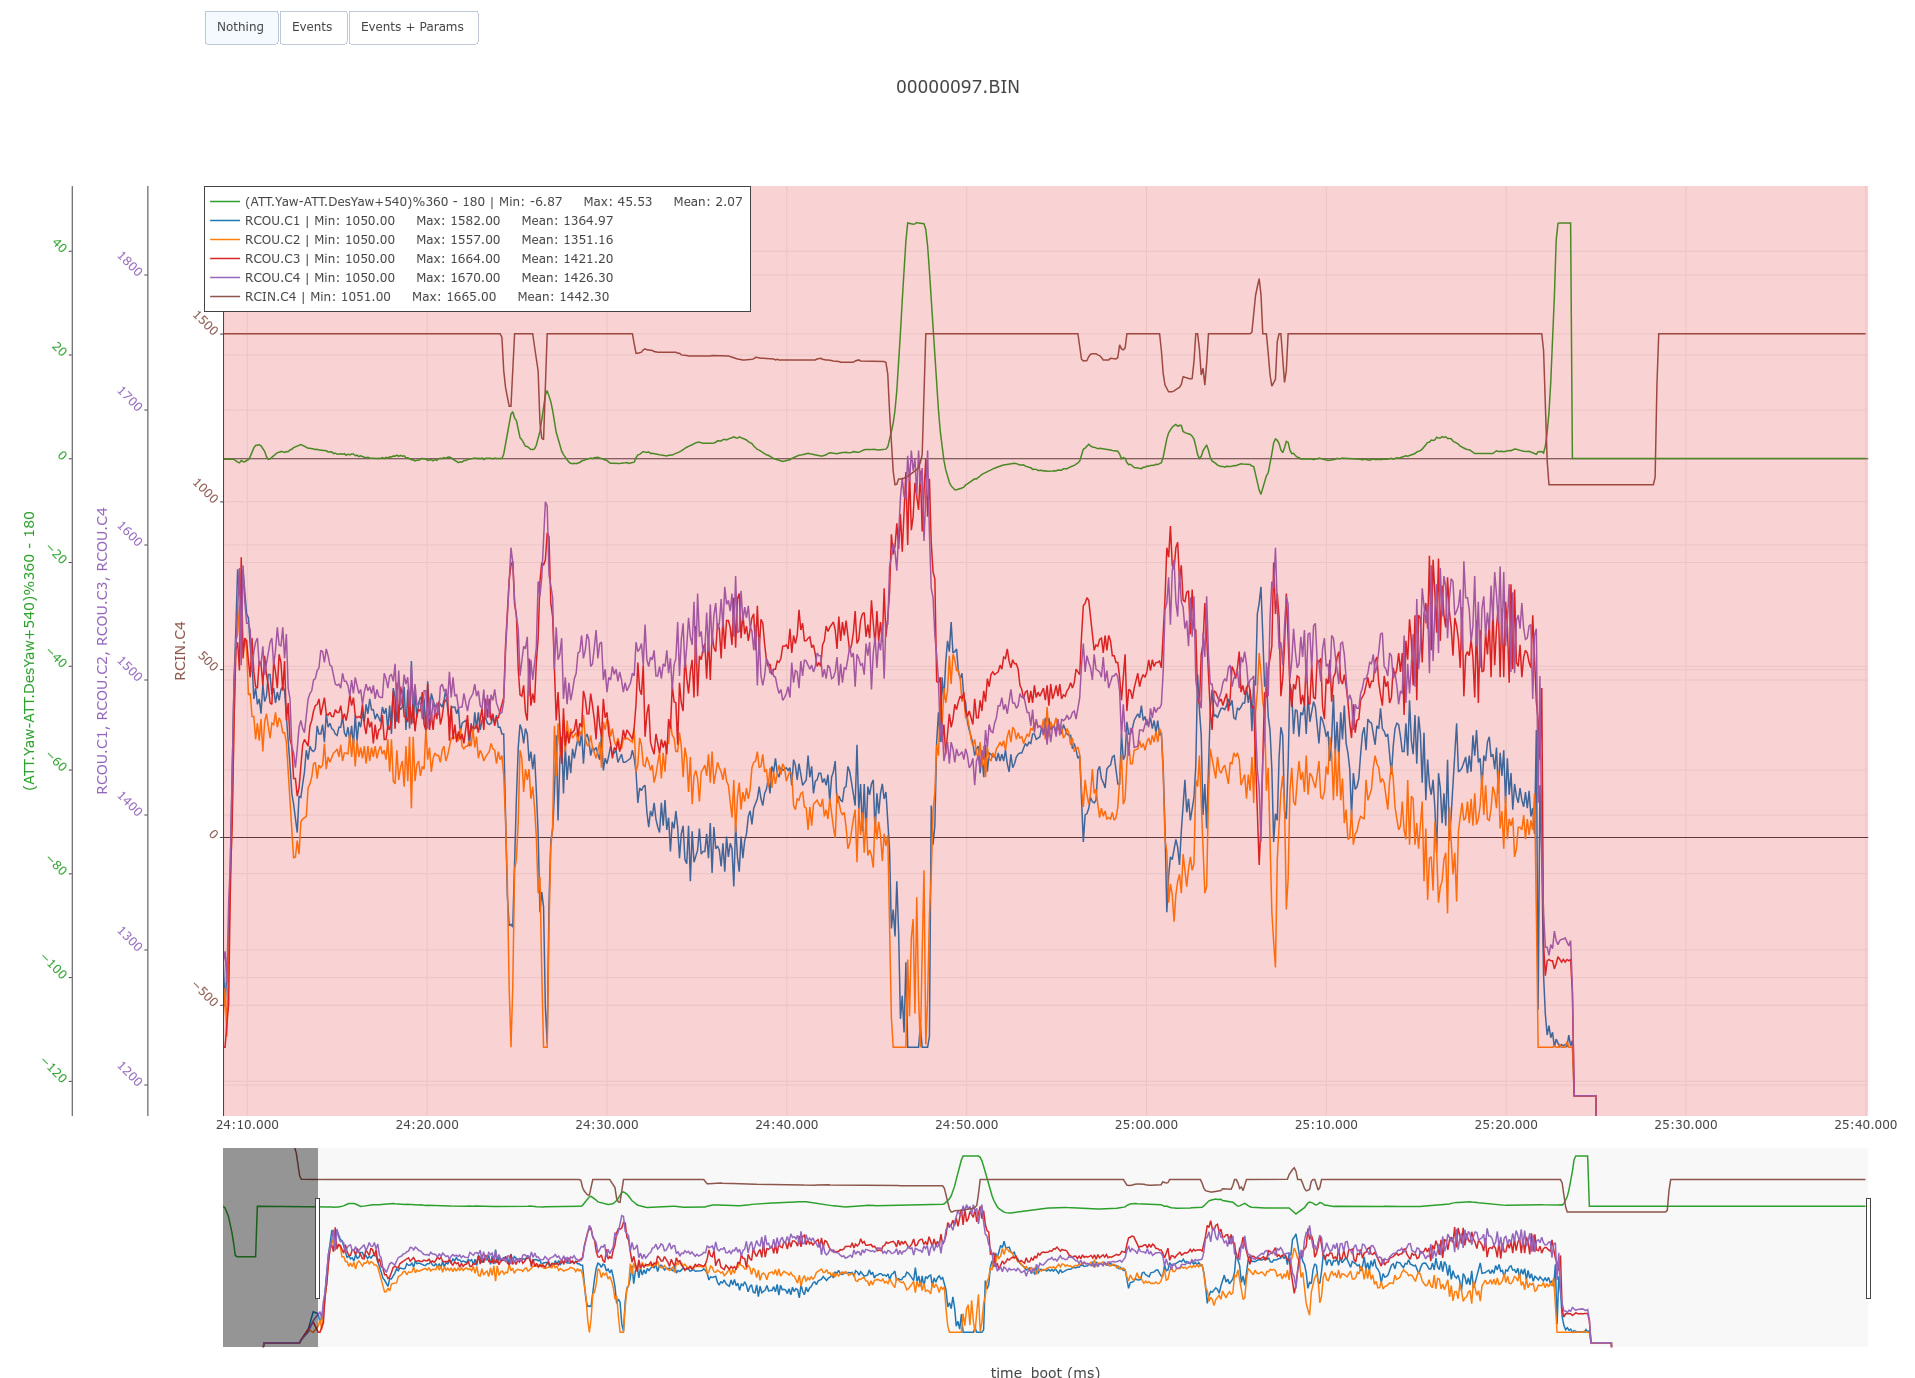
I tuned my quadcopter using methodic configurator and mission planner initial tune parameters. I feel the drone is OK in roll and pitch, any insights would be helpful. But in yaw there is slight instability. If there is sudden wind or if I yaw the drone for more than 90 degree continously then the drone becomes unstable for a small amount of time. This log was in auto mission where there is slight derailment from desired path of drone. This log is hover log where yaw was given.
Set ARMING_CHECK,1 and BATT_FS_CRT_ACT,1 and change the harmonic notch filter settings as follows:
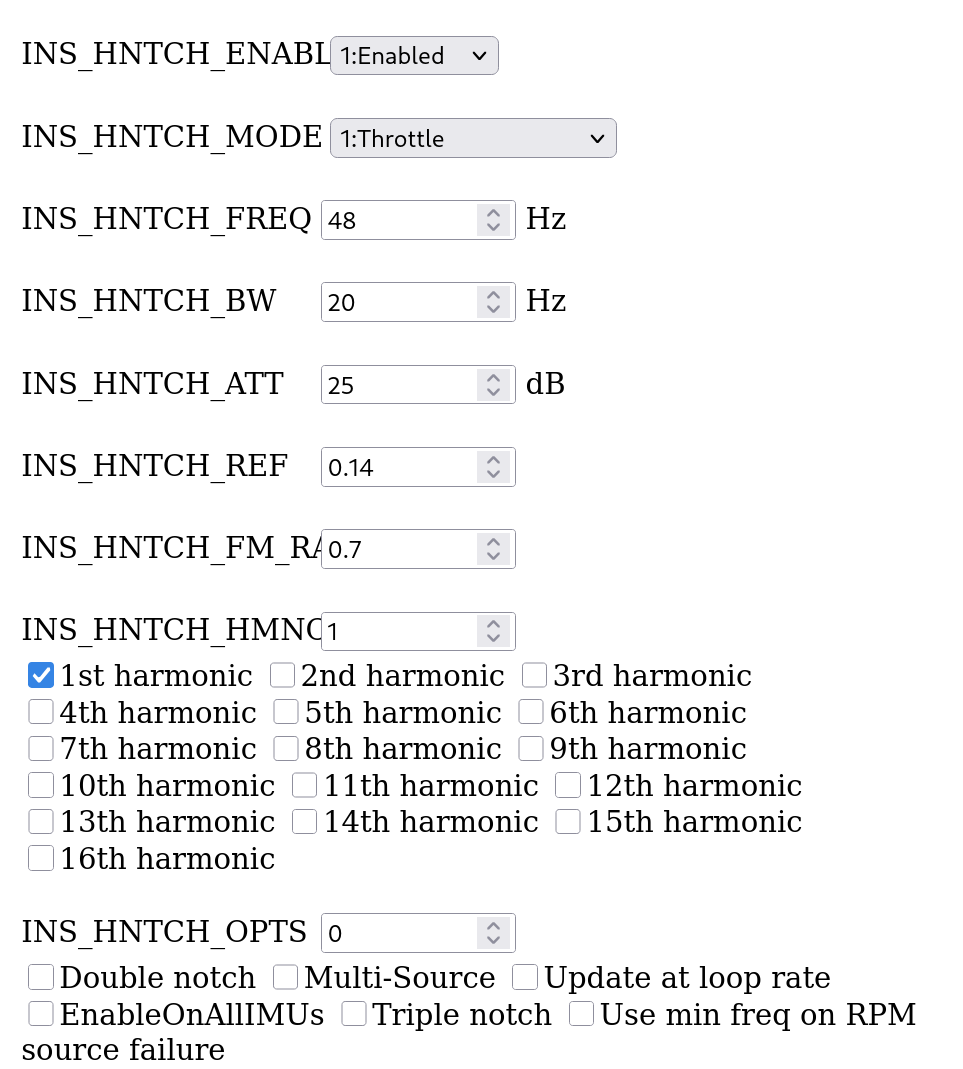
Luckily the notch filter settings you had didnt work at all (INS_HNTCH_REF,0) or there would have been problems.
Probably reduce ATC_INPUT_TC to about 0.22 or 0.20 since 0.5 will leave the copter with extremely slow, loose control. This may even be what you are seeing as poor yaw control, but tuning is definitely still an issue.
Then run Autotune on pitch and roll.
I usually run yaw autotune last, and sometimes it’s not even required but I think your copter will need it.
@Nischith_Raj unfortunately the methodic configurator was not correctly used.
When correctly used the:
ARMING_CHECK,1
BATT_FS_CRT_ACT,1
INS_HNTCH_REF,0.14
Would have been correctly set. Please try to follow the instructions, when steps are skipped errors like these pop-up.