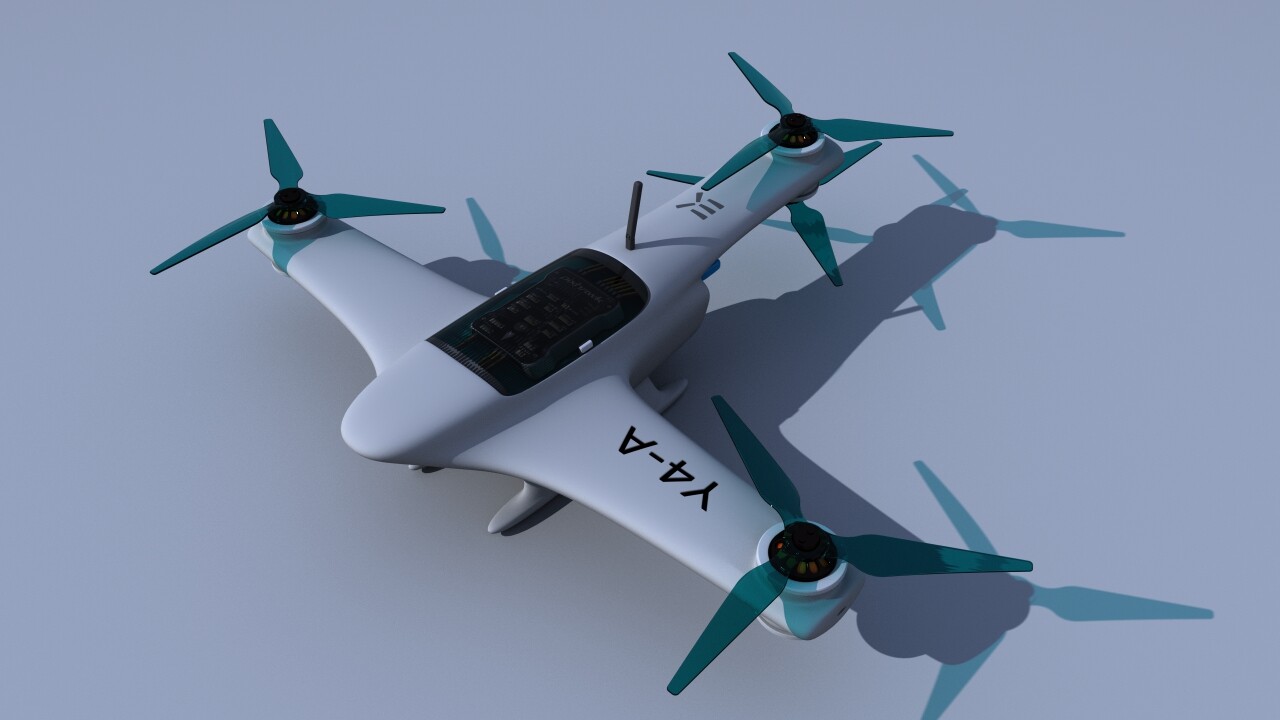
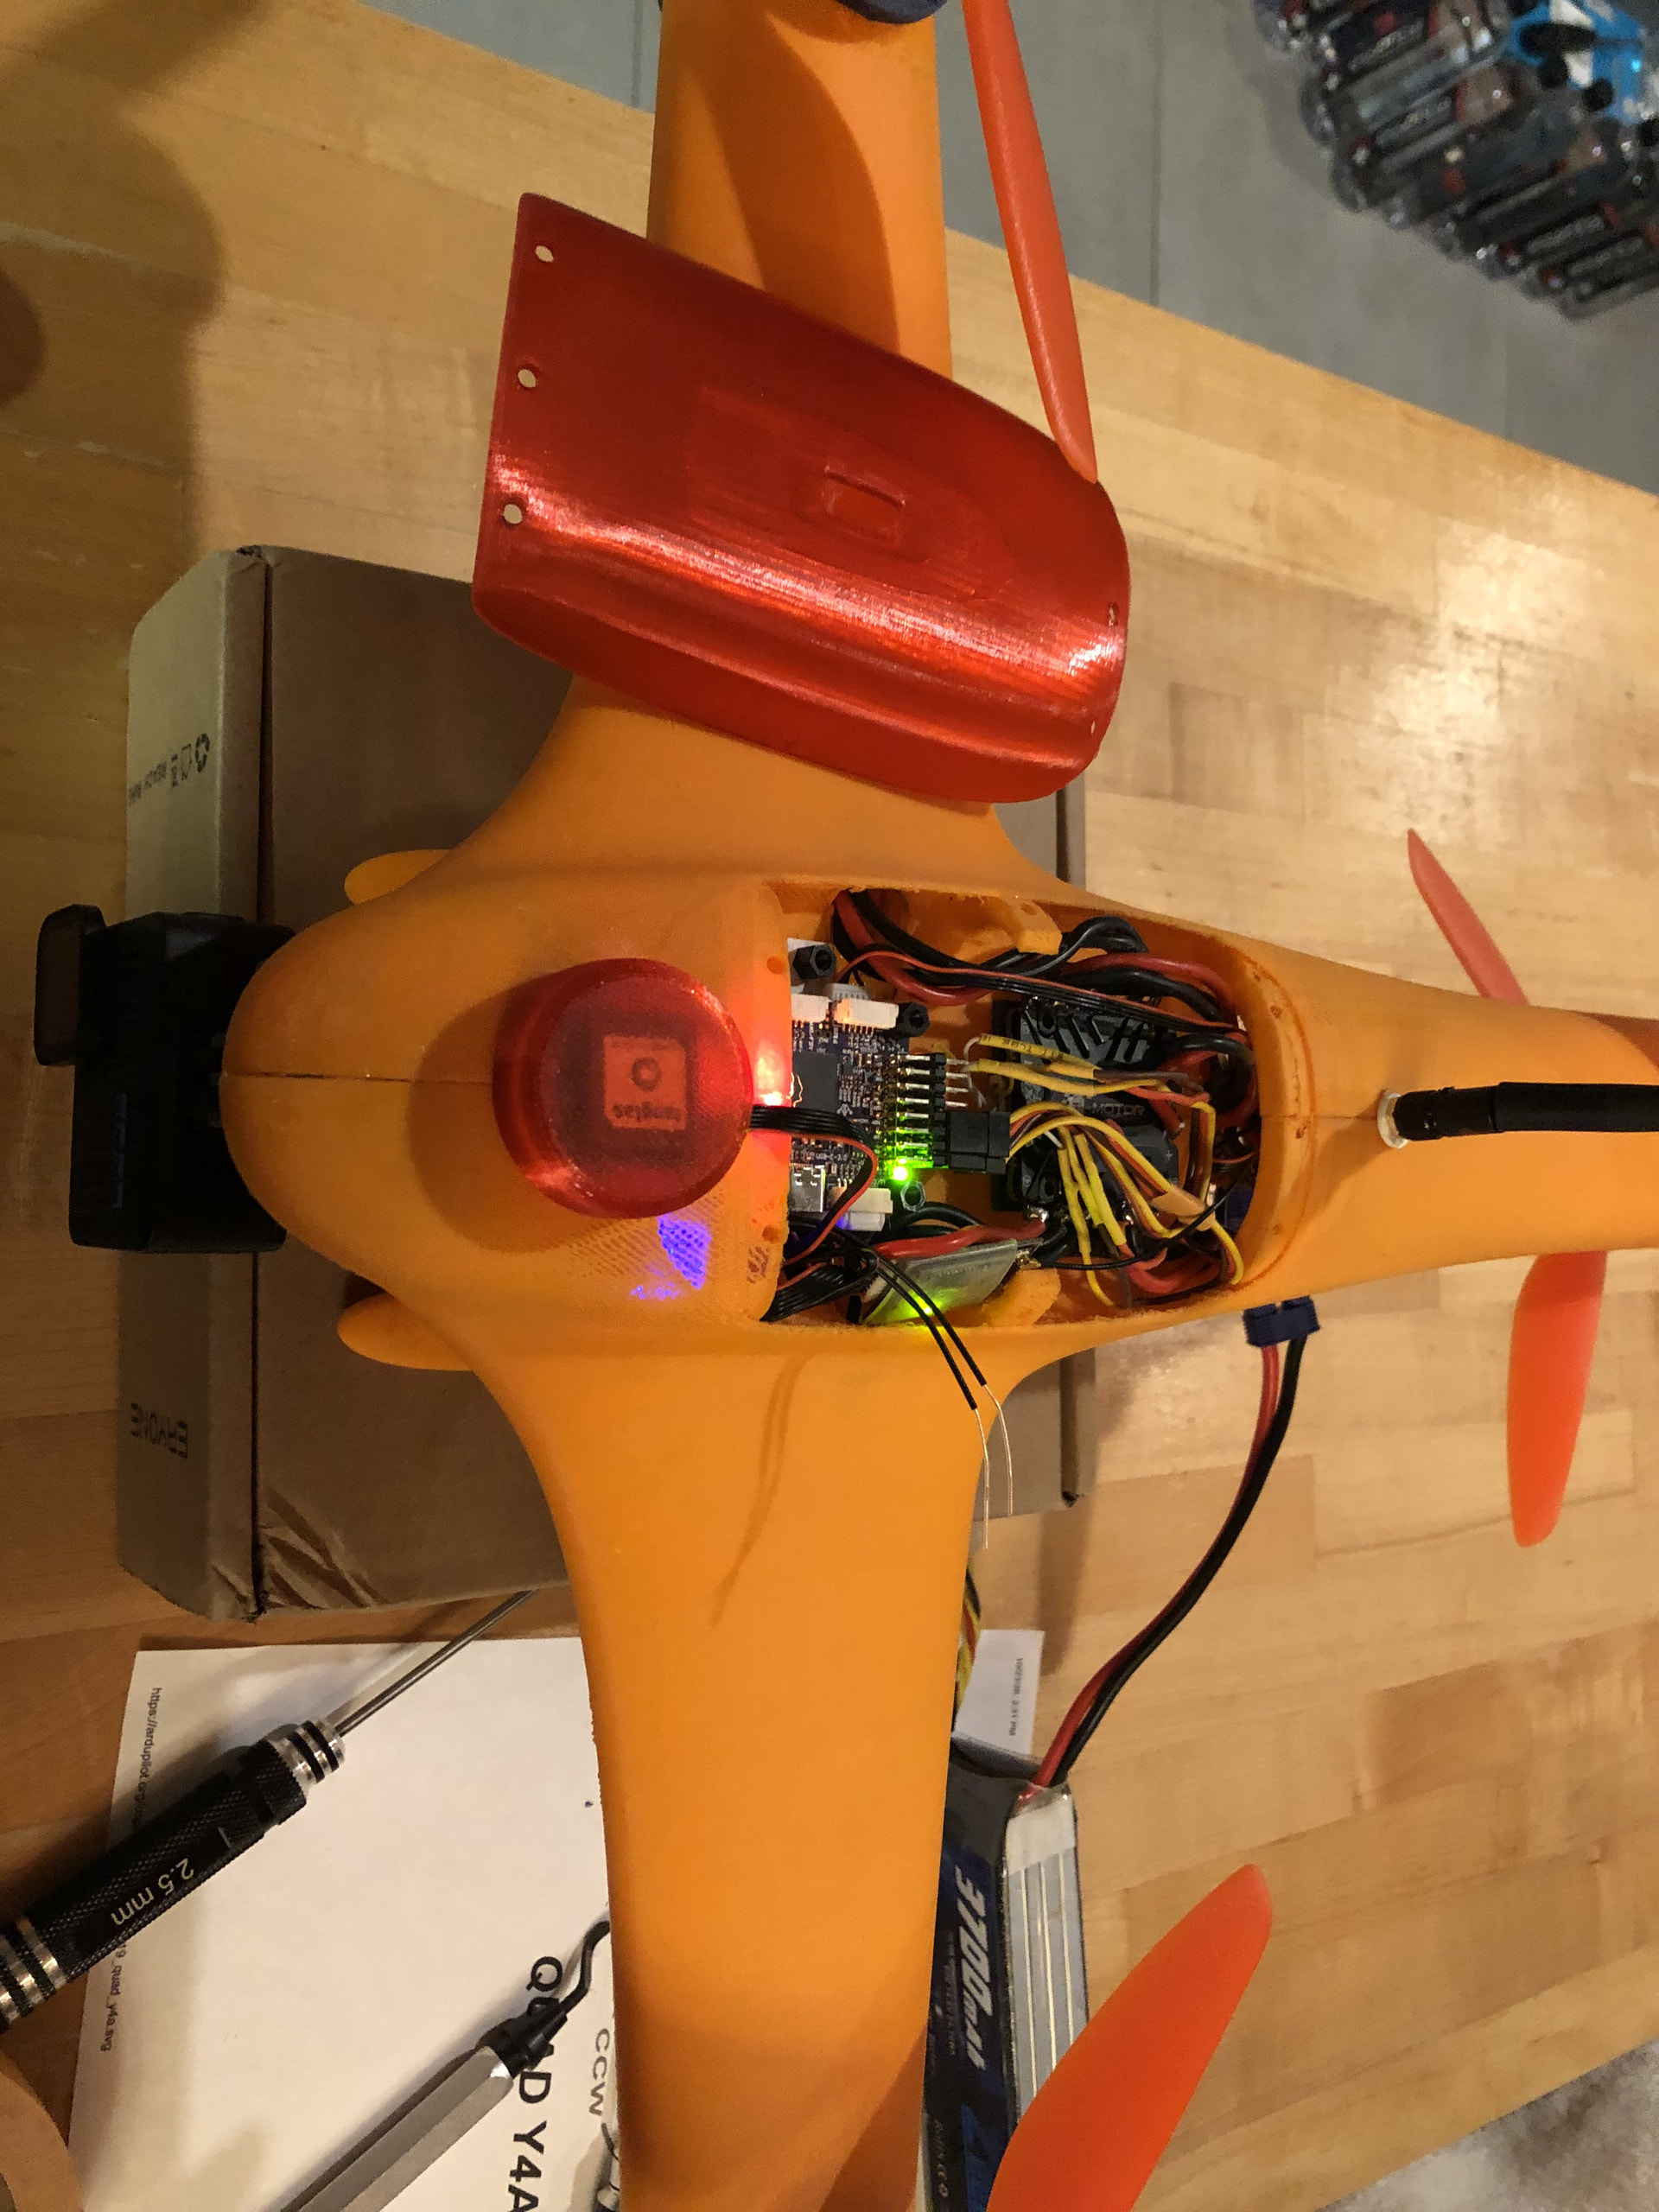
We are currently working on a custom Y4 frame setup and running into severe roll-yaw cross-coupling. Whenever a yaw command is given, the craft exhibits a pronounced roll moment instead of rotating cleanly on its z-axis.
Hardware & Configuration Details:
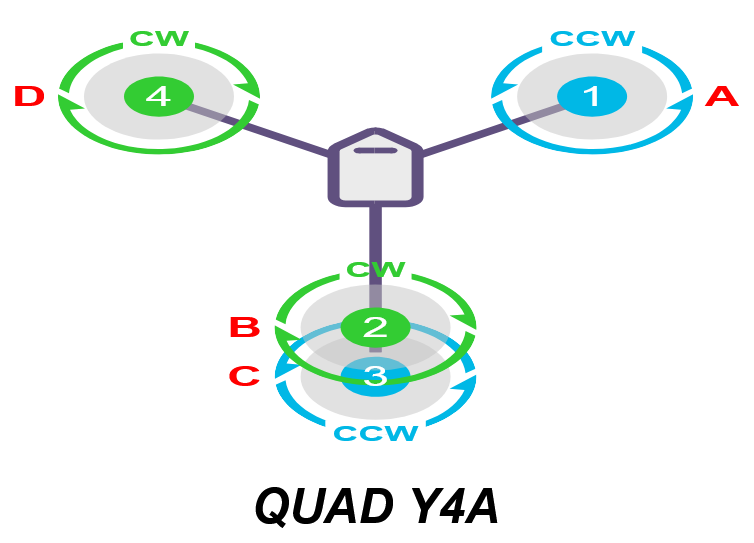
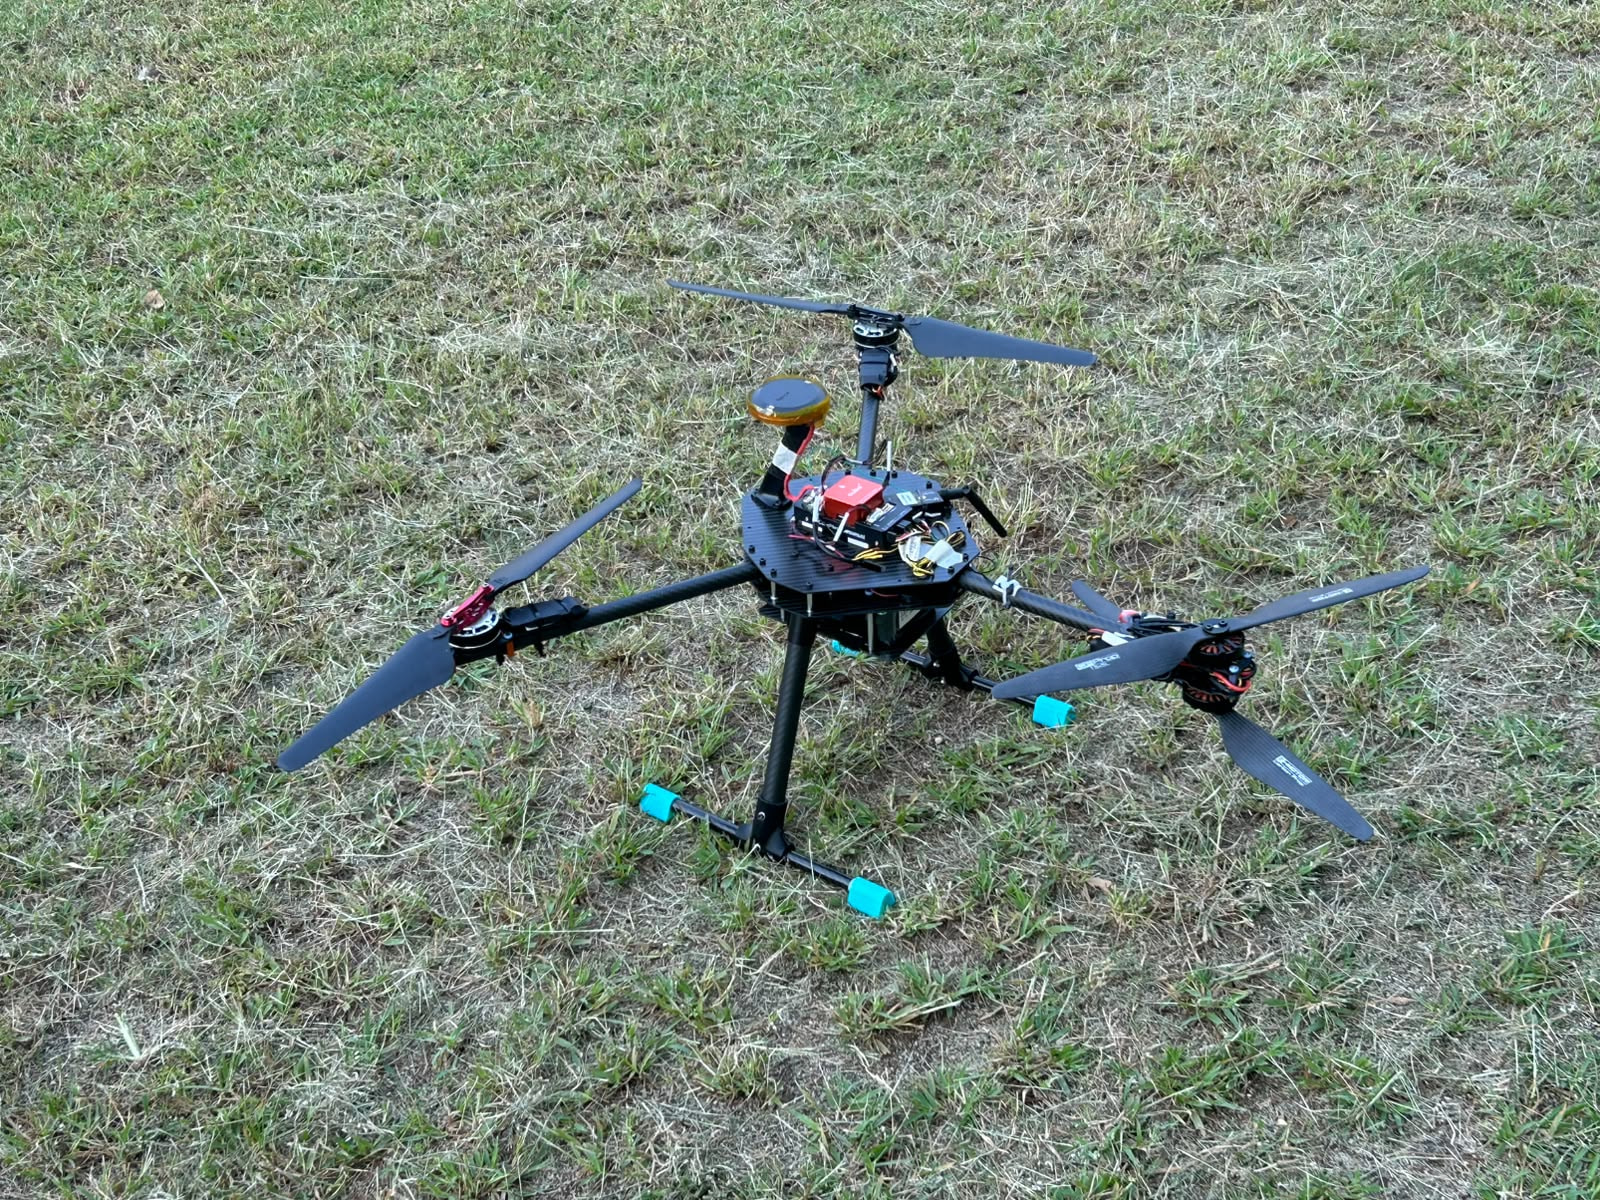
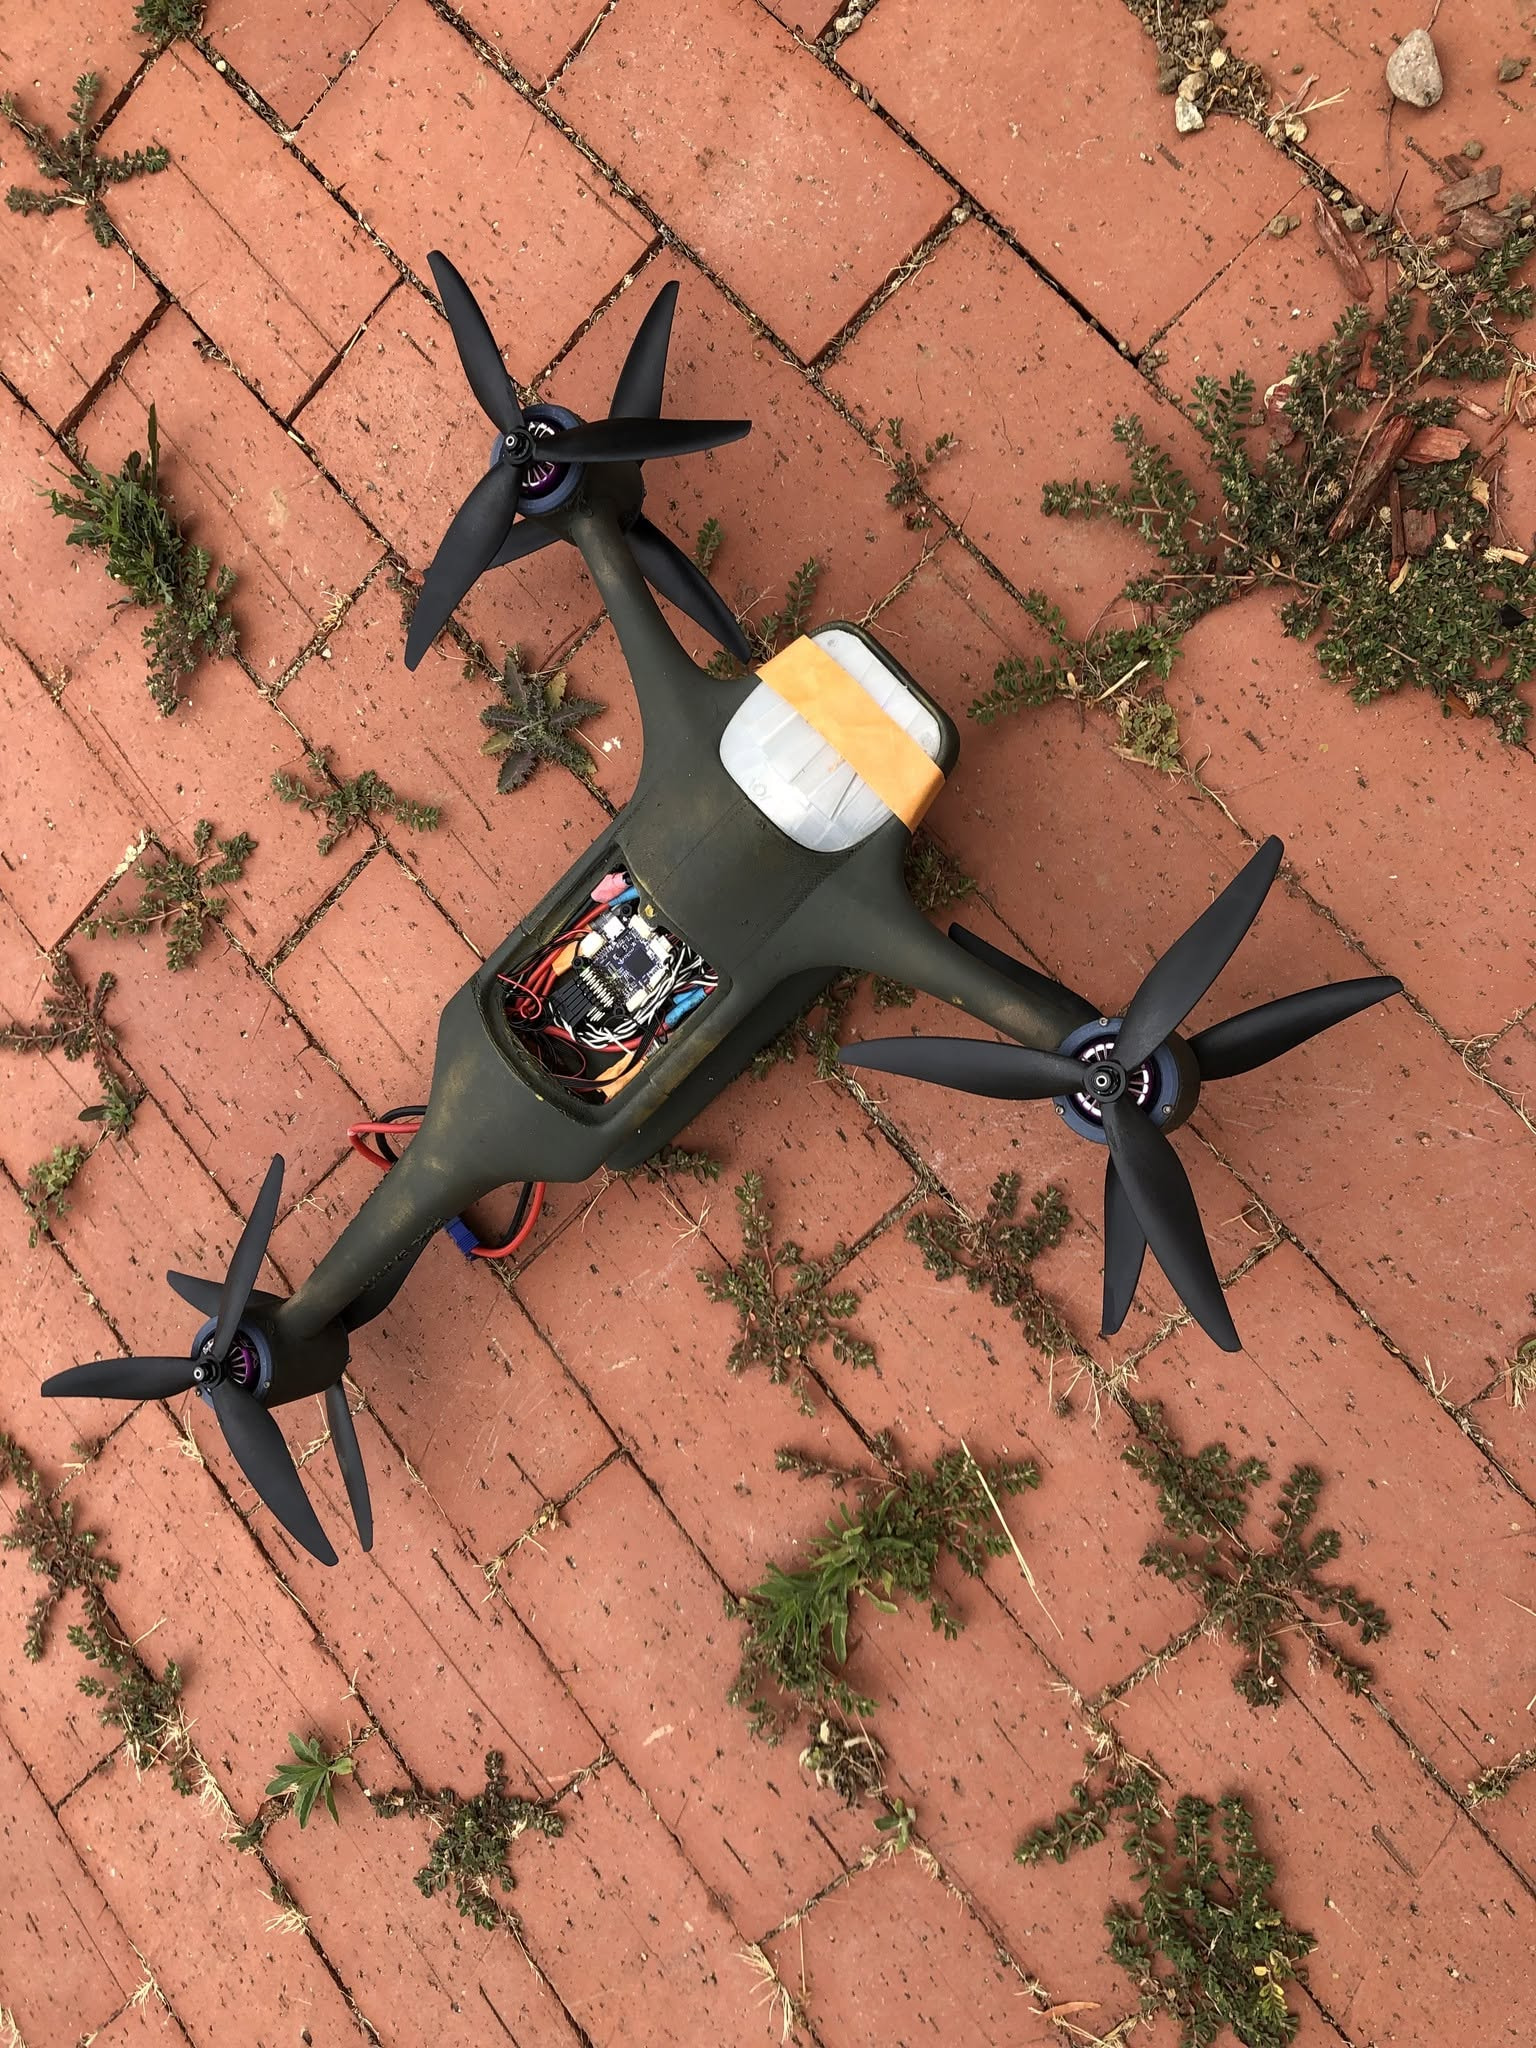
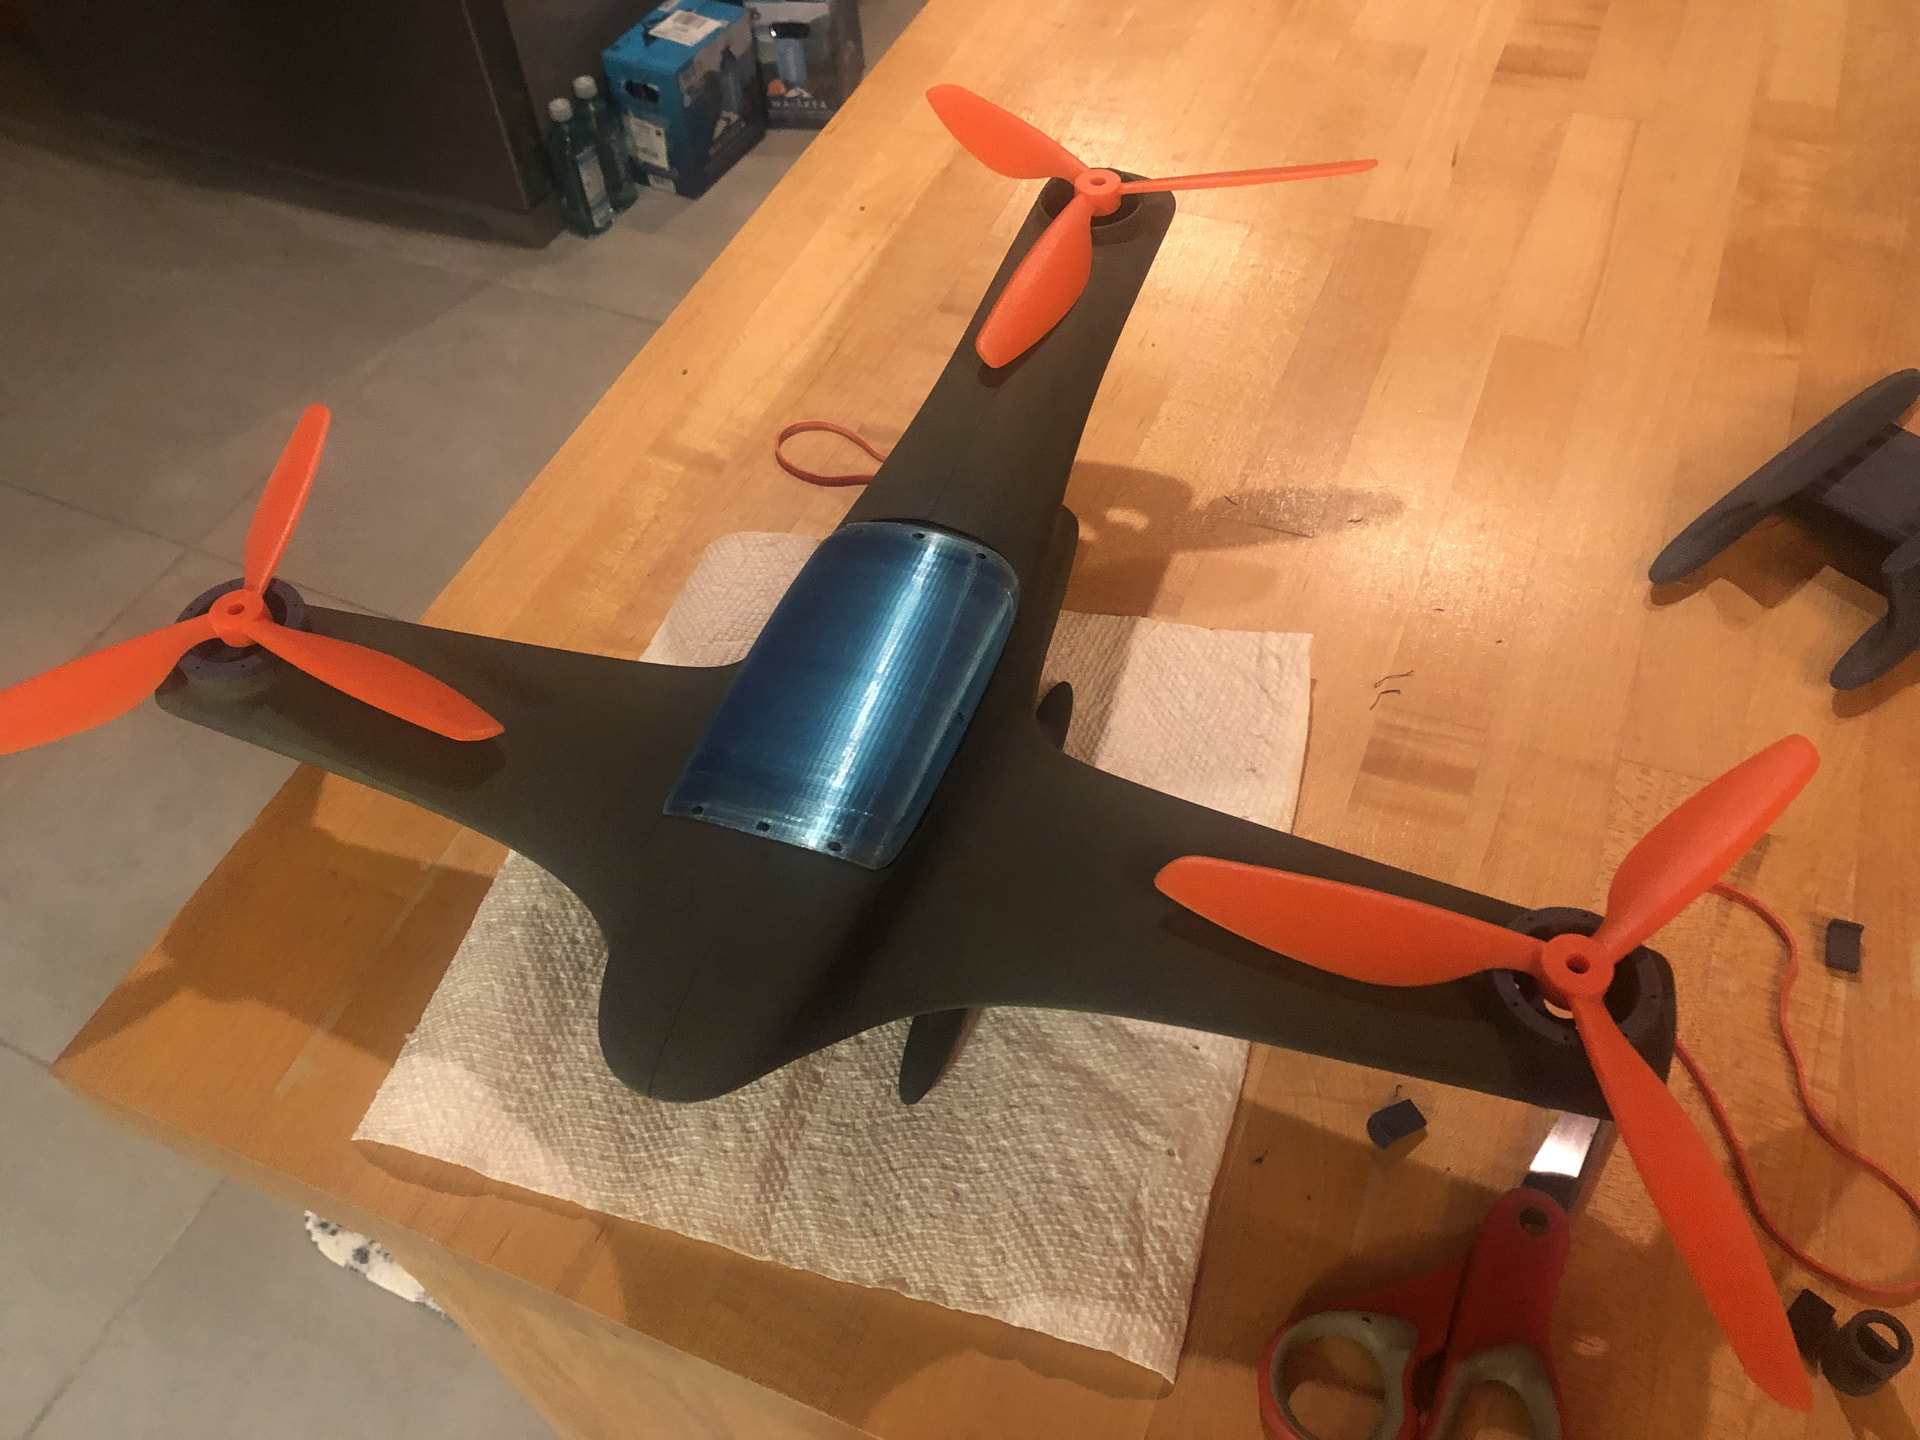
Frame Type: Y4 (Y-frame with dual front motors and counter-rotating coaxial rear motors)
Frame Class/Type:FRAME_CLASS = 1 (Quad/Y-shape) / FRAME_TYPE = [Insert value, e.g., 7 or custom motor matrix]
Observed Behavior: Applying yaw inputs causes noticeable roll pitching/tilting. The aircraft struggles to remain level in roll/pitch during aggressive yaw maneuvers.
Questions for the Community:
What is the recommended way to balance thrust and torque scaling when using unequal propeller sizes (17" front vs 15" coaxial rear) in ArduPilot?
How should we set up custom motor mixing / AP_MotorsMatrix factors to decouple yaw from roll on a Y4 with asymmetric rotors?
Are there specific dynamic notch filter tuning parameters or ATC_RAT_YAW_* adjustments we should prioritize to restore stability across all axes?
Any guidance on motor matrix adjustments or log analysis tips would be greatly appreciated! I have attached a flight log file showing the coupling issue.
we tried tuning multiple time. After increasing YAW values, we were facing yaw with high angle role. By decreasing YAW values, yaw and role motion got less but still coupling motion is happening.
Thanks for posting the picture, One thing to check besides tuning is that the rear prop bottom number 3 or C is not turned upside down. think logo of the prop will always be up an not flipped in the axis. Same for a Y6 or x8. Nevermind if your doing this now…