we had a catastrophic failure with our large VTOL (12kg) plane which ended in a flipped state - stable - hover motors full speed - to the ground.
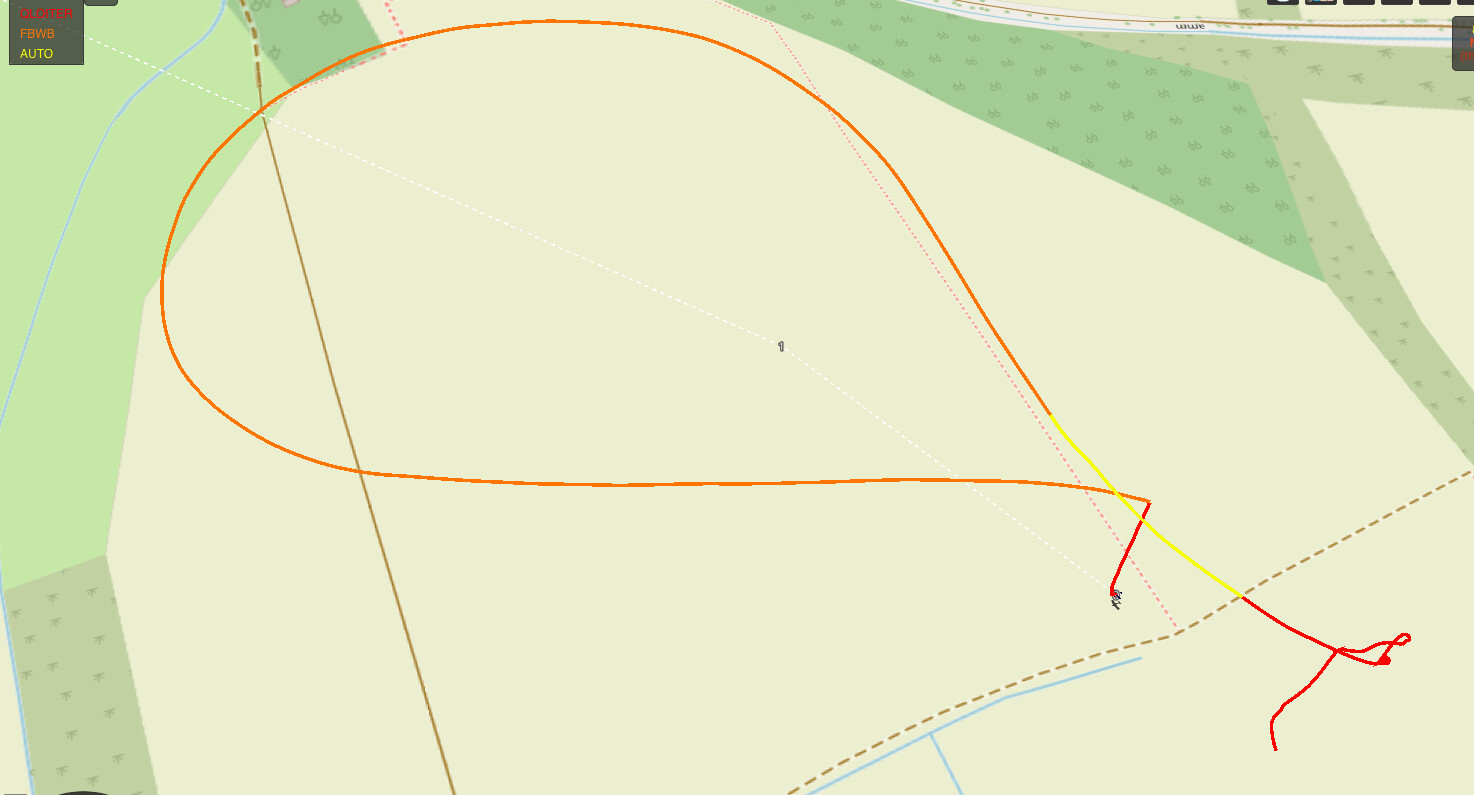
After multiple successful flights on our testfield there was another flight started: Takeoff in QLoiter, climb to safe altitude, transition to FBWB, fly a curve, switch to Auto, noticed the hovermotors started spinning (despite a plane waypoint mission being loaded), switched back to QLoiter, transition was a bit more rough than usual and there was quite an aggressive pitch back moment which resulted in the loss of a foam piece of the fuselage cover - which at least audibly did not hit any propellers or anything else from the plane and is in it self not neccessary for the plane to function normally, although it appeared to have damaged the downward facing lidar on its dismount as we were getting unhealthy lidar messages. Afterwards it almost seemed stable in hover for a quick moment but then became unstable again, flipped on its back, went full throttle on the hover motors, extremly stable, no amount of RC Input did change anything, a few seconds later it crashed into the ground in that state.
Log file analysis showed that multiple EKF lane switching occurred and that the last section of full throttle on its back shows the plane upright in the log file, which is definitely wrong.
The FC is mounted 90° rotated and on its back in the fuselage, as it is set up with AHRS_ORIENTATION.
I have two RTK CAN GPS for YAW and also two airspeed sensors.
Does anybody have an idea what happened? Any help is greatly appreciated!
If i compare the ATT and AHR2 Data (and XKQ[0], XKQ[1], XKQ[2]) in the stable flipped section right before the crash - ATT and XKQ[0] show the plane upright, the others show it flipped (as it was)
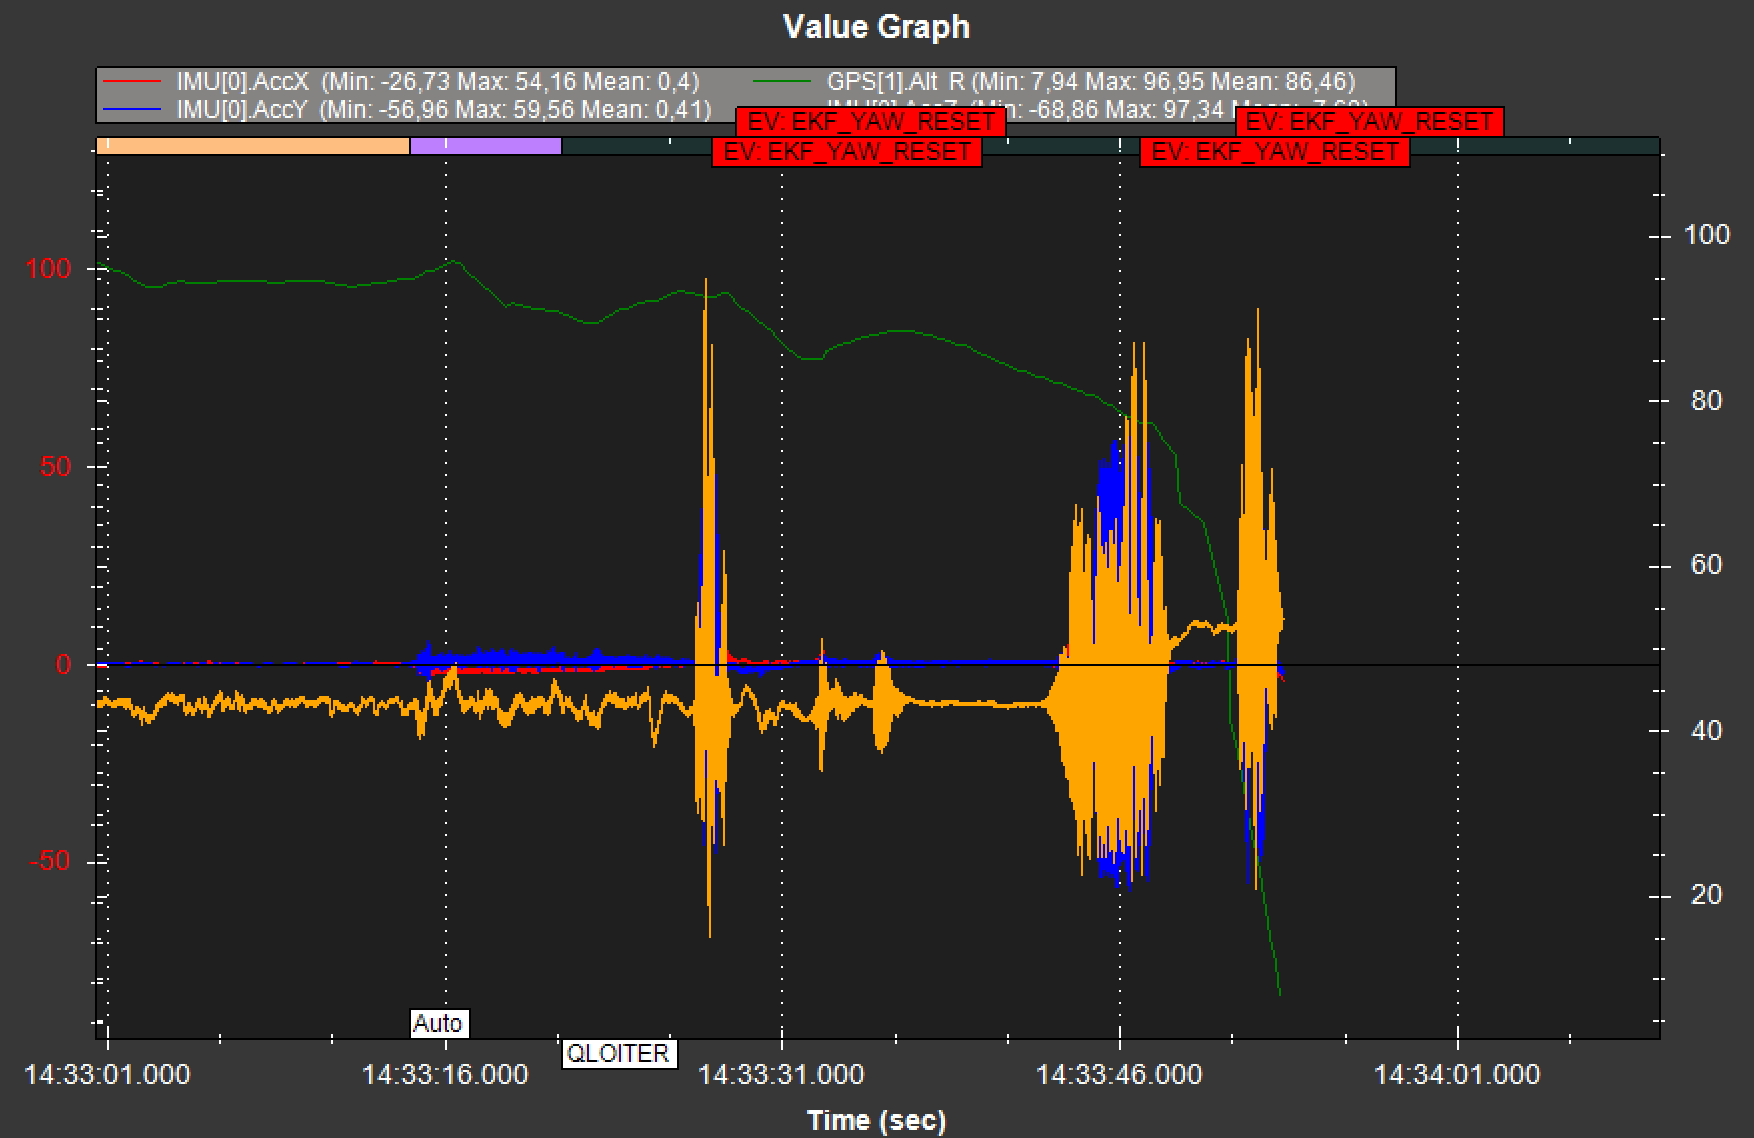
Thanks for the suggestion, i’ve seen those as well, but I can’t explain them. After the crash very few things survived but it is visible, that the FC is still mounted in its original place, the cruise motor as well, the props survived - and during the malfunction there was no vibration audible from the spinning motors, or at least no change to the usual sound profile - so I am really baffled how these huge acceleration spikes came to be.
I am currently writing from my holidays and don’t have time to dig into your log any deeper. I was just triggered because your crash sounded very similar to mine. Maybe @Rolf will remember the crashes, as he helped me to find the cause.
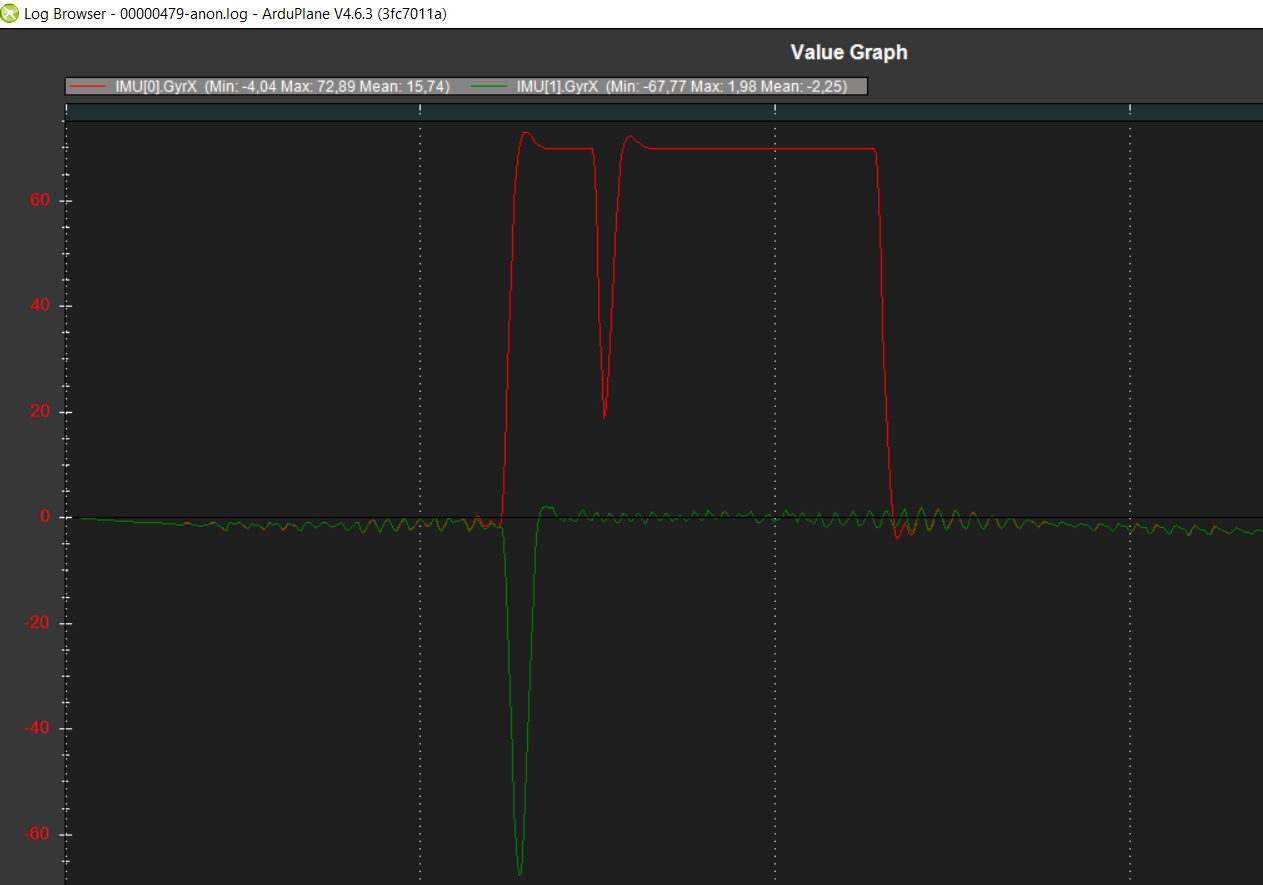
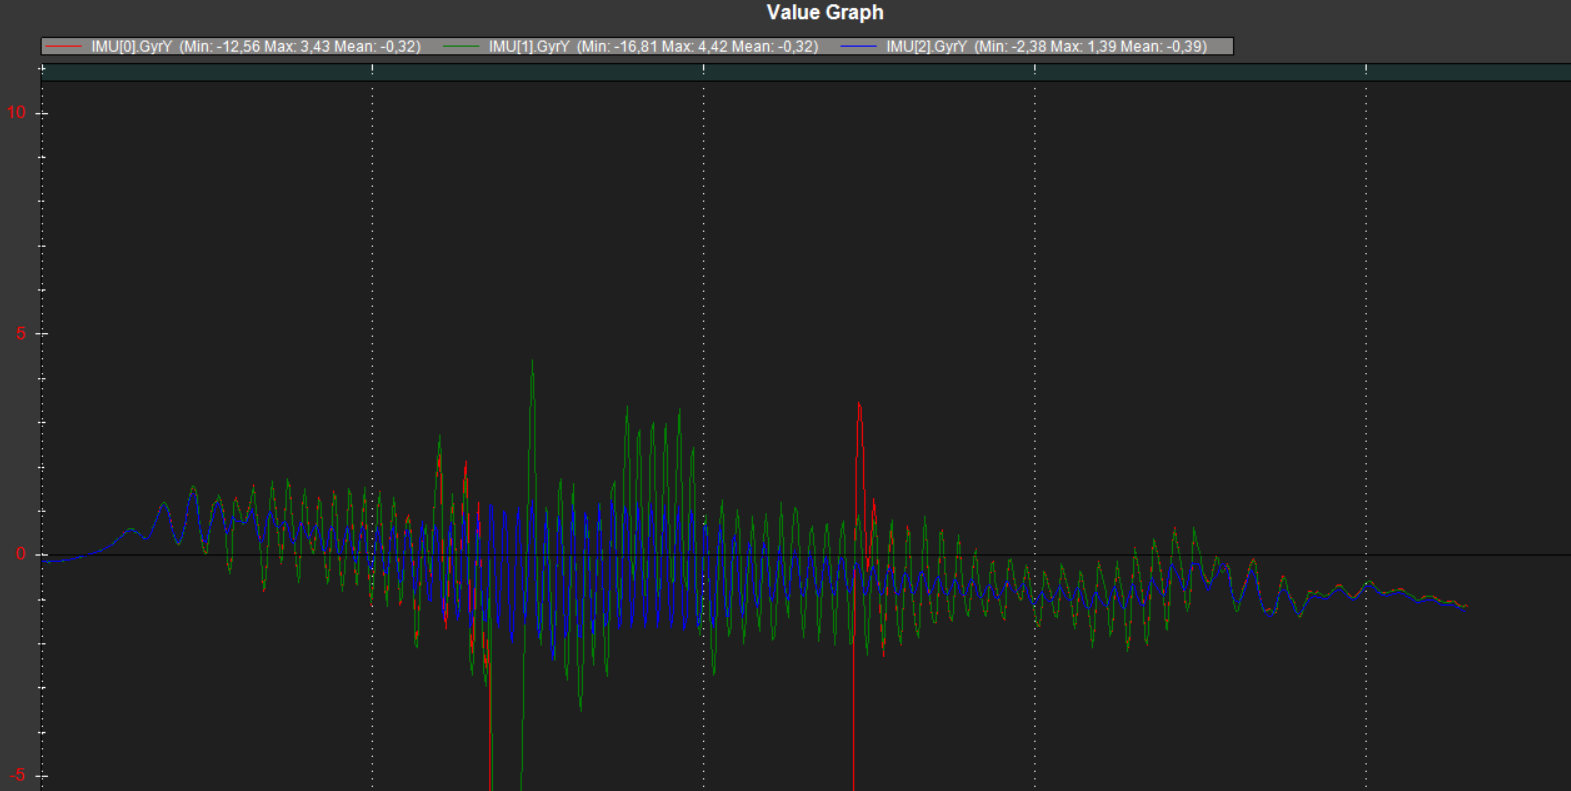
Edit: In contrast to my crashes, your Gyro values don’t switch axis but simply do some wrong output. First guess would be some problems with your soft mounted IMU 0 + 1: