Round tubes… Motors aren’t level with each other.
I made these for the X500V2 frame to level the motors, but it will work on anything.
Round tubes… Motors aren’t level with each other.
I made these for the X500V2 frame to level the motors, but it will work on anything.
Sorry for this Red Herring. The 1st reply you received in this thread and @Allister comments are all you need to focus on.
Ahhhaa! I think I know where is the mistake: I was aligning the base of the motors not the motors themselves.
Thank you for guiding me to the solution!
I used the method shown by @Allister with a slight modification: I leveled the motors by placing a ruler on the foldable props probeller hub (the center part, that holds the blades).
I got interesting results 
I alwalys leveled the motors in a completely unfold configuration.
I have double-checked:
Is this usual with foldable frames with round arms?
Is this the standard procedure to re-align the motors almost every time I fly?
What am I doing wrong?
It’s not clear to me how this method will detect a twist in the motor mounts or arms. @Allister fixture has a large flat area where you can detect this under the straight edge.
Correcting for this:
@dkemxr here are a few pictures from today morning. The photo is taken from the right side of the drone, the FPV camera is facing to the right side of the picture.
I don’t have the logfiles with me, but I checked motor RPM on MissionPlanner dashboard: there was no significant RPM difference between the 4 motors. I can provide logfiles later today, when I arrived home from work.
https://drive.google.com/file/d/1ITJq1gIH_tpIH4jD6y9J2wr7o110LIii/view?usp=sharing, https://drive.google.com/file/d/1QqrJgC_aE_TA_jJcwOnb-YakTP4yVMfs/view?usp=sharing, https://drive.google.com/file/d/1bQY1k5jUHQ2DRHcmKOcAIRzsptjz_UJE/view?usp=sharing
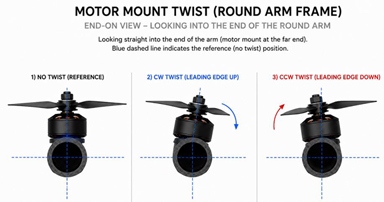
Regarding mount twist illustration: Do I understand correctly, that the best would be 1, but #2 is also acceptable?
From @dkemxr ‘s image, only number one is correct. 2 & 3 will both result in a torque split.
Make sure when you’re aligning the motors you check both X and Y axis. For example compare motor 1 against motor 3 and motor 4. In a perfect world you would compare all four motors, but most of the time that’s not practical. And if you have motor one level with 3 and 4, and motor 2 level with 3 and 4, then it should be fine.
Yea, what @Allister said. I see from your photos there is a good flat area on the prop hub to use, so that should work. If it’s not repeatable with the arm folding/unfolding then it’s just the issue always seen with those mechanisms. The joke is it can easily be remedied with JB Weld…
Alternatively if the arms have to be foldable, motors can be deliberately twisted so positive correlation between drag and thrust torque is always maintained.
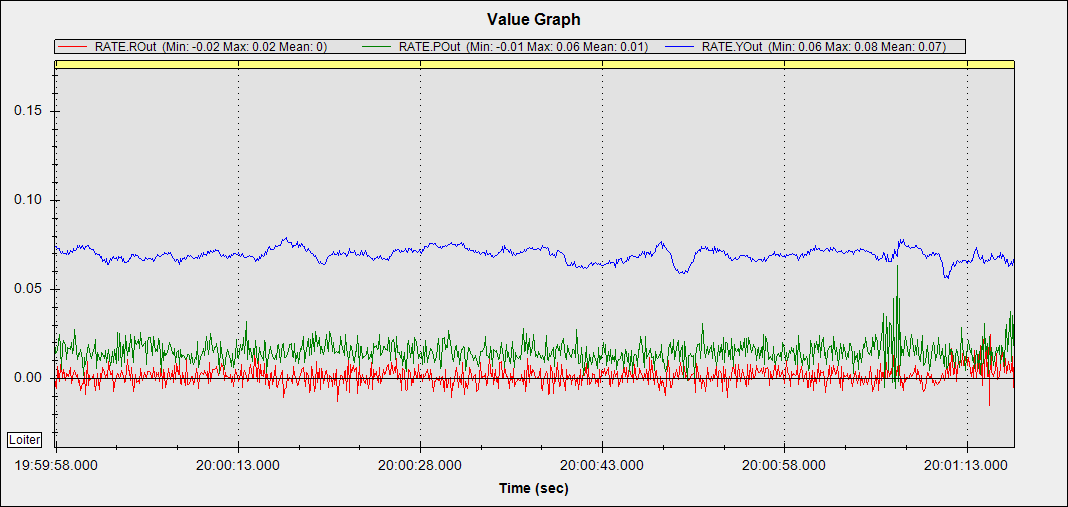
Provided the motors are assigned correctly you can avoid confusion by looking at the pre motor mixer roll pitch and yaw outputs in the RATE message.
If the CG was perfectly in the middle we would expect roll and pitch to average 0 and if is no yaw imbalance the yaw output would also average 0.
In this case the yaw output is by far the largest. A positive number means the copter was trying to yaw clockwise, so its CCW motors would be at a higher throttle level. Pitch is positive nose up and roll is positive roll right. So we can also say that the CG is a little forward of ideal as there is a constant nose up pitch output.
In general you want roll/pitch/yaw outputs to be of around the same amplitude, if one is dominating its worth either aligning the motors or shifting the CG.