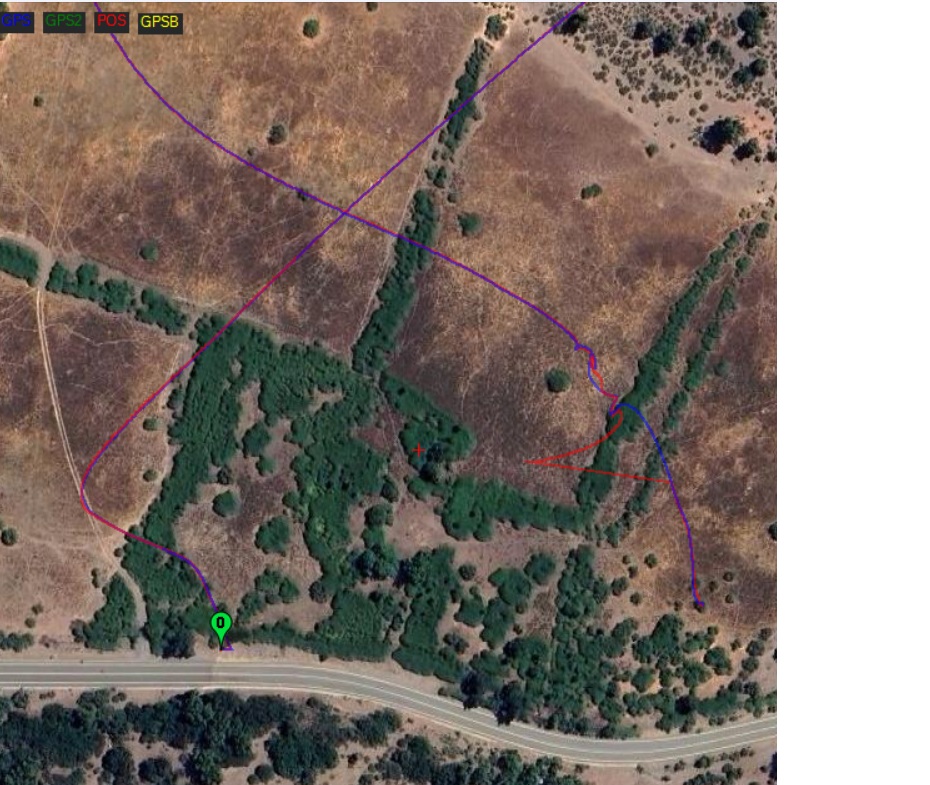
I got an issue with a copter that after the flight, when I was about 200 meters from Home, the copter entered LAND mode and landed in the bushes.
I can not upload the .bin file, it is over 1 GB (the flight was 50 minutes long).
Checking .bin file, at that precise moment when LAND began, Err: EKFCHECK-2 and FAILSAFE_EKFINAV-1 appeared, also 2 seconds before, Err:GPS-2 appeared, followed by YAW RESET (1 second before land).
What I remember is that the home arrow was pointing towards a tree on the road which was some 150 meters off to the right (on the map), even before the land event occurred. When land
First, the failsafe behaviour. I found the parameter FS_EKF_ACTION, it was set to 1 (LAND). That was obviously a big mistake, and it should be AltHold.
I also changed FS_EKF_FILT to 1 Hz (I wounder if one could enter something like 0.1 Hz,i.e. if an event lasts about 10 seconds, nothing should happen?)
and FS_EKF_THRESH to 1.0 (Relaxed).
I think that if I was higher up, I most probably had caught the problem and switched to ACRO mode, but I was very low, some 15 meters maybe, and the video signal faded fast when copter descended. I thought that the battery gave up, and the last thing I saw was that it was still good before the video faded out… That forced landing cost me 1 hour of search, and I got totally blooded out in the bushes…will never forget it!
I eliminated all failsafes long time ago, like battery failsafes, but I did not know about this failsafe…
Second, the reason for the GPS failure, is that a potentially hardware problem or transitory?