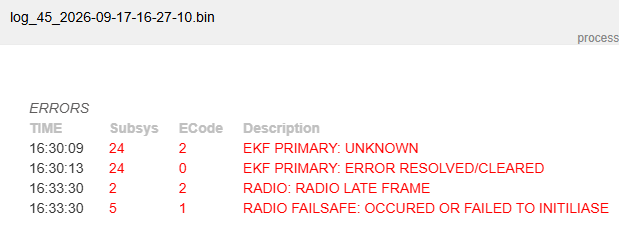
I’m currently testing my craft. It was flying well in AltHold mode, and I performed multiple aggressive maneuvers without issues. However, the system won’t even take off when in Loiter mode.
I have tried several parameter changes on my end, but I haven’t been able to identify the exact root cause. If anyone has any suggestions or insights, I would appreciate your help. I’m attaching my flight logs for reference.
I reviewed the attached log, and this looks more like an EKF/IMU issue than a Loiter tuning issue.
While the vehicle is stationary, CTUN.Alt rises to around 464 m, while BARO.Alt remains near 0 m. The following PreArm errors also appear:
PreArm: Need Alt Estimate
PreArm: EKF attitude is bad
PreArm: AHRS: EKF3 Roll/Pitch inconsistent by 13 deg
Since EK3_IMU_MASK = 7, all three IMUs are being used, and one EKF core shows about a 12–13° attitude difference compared to the others.
I would first check for an IMU issue, EKF initialization problem, or gyro/accelerometer bias. As a diagnostic test, you could temporarily set EK3_IMU_MASK = 3 and check whether the EKF becomes stable.
"Thank you, Jack for pointing these things out. Is it an issue with the IMU itself, or could something else be causing my IMU to deviate by 13 degrees? Every time I fly in Loiter mode, I experience IMU/EKF issues.
It may not necessarily be a faulty IMU itself. A 13-degree difference could also be caused by vibration, sensor calibration, mounting/orientation issues, temperature-related gyro bias, or an EKF initialization problem.
Since the issue repeatedly appears in Loiter mode, I would first compare each EKF core and temporarily exclude the third IMU using EK3_IMU_MASK = 3. If the issue disappears, that would help narrow it down to the third IMU or its sensor data.
I would also recommend checking vibration levels and repeating the accelerometer calibration before replacing any hardware.