My strategy is to tune the copter portion first, then tune aerodynamic controls in FW flight, then tune the combination of aerodynamic and copter controls in hover. My sense right now is that the two controllers are fighting each other.
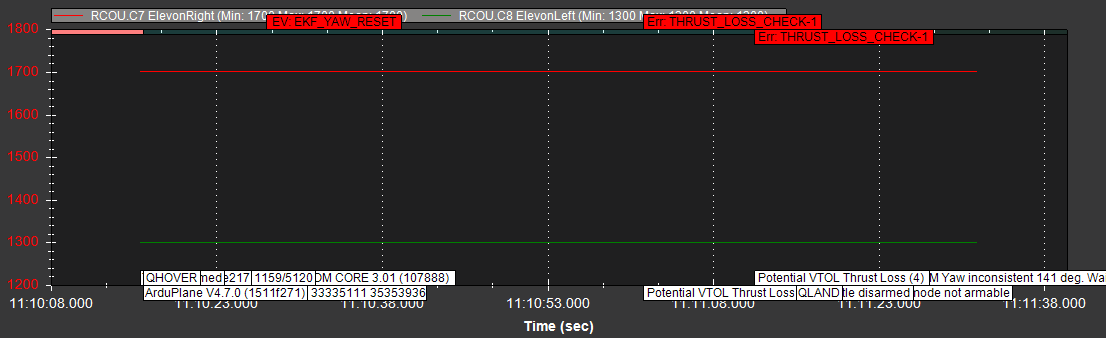
I tried to set Q_TAILSIT_VT_x_P to 0, but the servos still move in QHOVER. Short of disabling the servos, is there a way to force only quad control in hover? Disabling the servos would interfere with FW transition and flight.
In hover the FW gains do not have any effect, and in FW flight the VTOL gains don’t have any effect, so the two controllers never run together, its either one or the other. (the exception is the if you have set the motor only Q Assist Q option).
I would have expected zeroing those all to result in no surface movement. Do you have a log?
Thank you @iampete. No log yet–I plan to fly later today with the new settings and will gladly post the log. My observation is based on bench test. After setting the parameters to 0, I turned the plane on and moved it around without arming. I expected to see no servo movement, but they were moving.
Well, this is embarrassing. In flight it did exactly what the tin and @iampete said it should and the servos stayed at their trim outputs. I can only assume that when I did the bench test, I had it in one of the FW modes instead of one of the Q modes. #cannotreproduce#worksonmymachine
While we’re here, what is the EV:EKF_YAW_RESET event? I see it often in QPlane logs, this aircraft as well as others.
Its possible that while disarmed the underlying FW servo outputs still make it out since the VTOL rate controller is not running.
This is normal, once way from the ground the EKF does a yaw reset incase there was anything on the ground causing a incorrect heading (rebar in concrete for example). It happens when you first climb above 2m.
It tunes the VTOL controller, which outputs to both the motors and the servo outputs. But it will not tune the ratio of control surface to motors. That is where some manual setting of the Q_TAILSIT_VT_x_Pparams comes in.