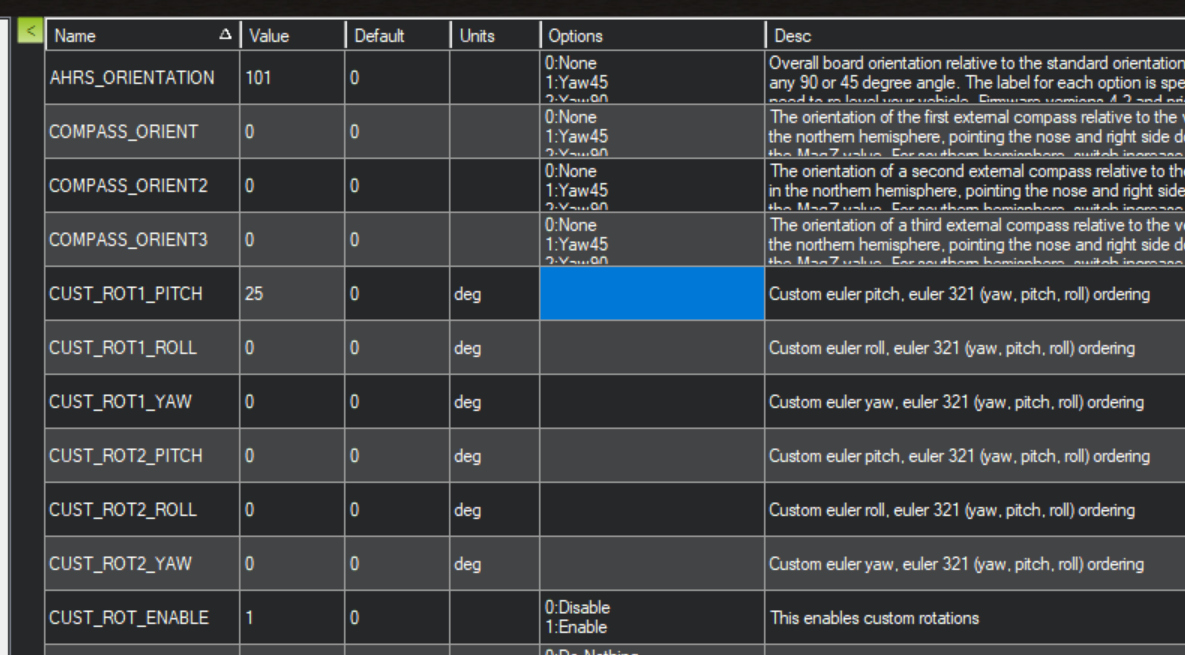
I’ve built a quadcopter with props tilted 25 degrees forward (adjustable), so that the deck flies level when the the props are pitched 25 degrees forward in cruise flight (the idea is lower drag in forward flight).
I’ve seen two ways to configure the flight controller:
- Tell the FC in parameters that it is mounted 25 degrees backwards (pitched up) - using “Custom 1”? And then…
Define Custom Angles:
- Configure the roll, pitch, and yaw rotation offsets using:
-
CUST_ROT1_ROLL(Roll offset in degrees) -
CUST_ROT1_PIT(Pitch offset in degrees) -
CUST_ROT1_YAW(Yaw offset in degrees)-
Place the frame on a level surface (with the landing gear holding the deck (and flight controller) 25 degrees backward) and calibrate the accelerometer in that orientation, so that the FC sees that orientation as level.
-
Both?
Thanks…
-
-