Hi there,
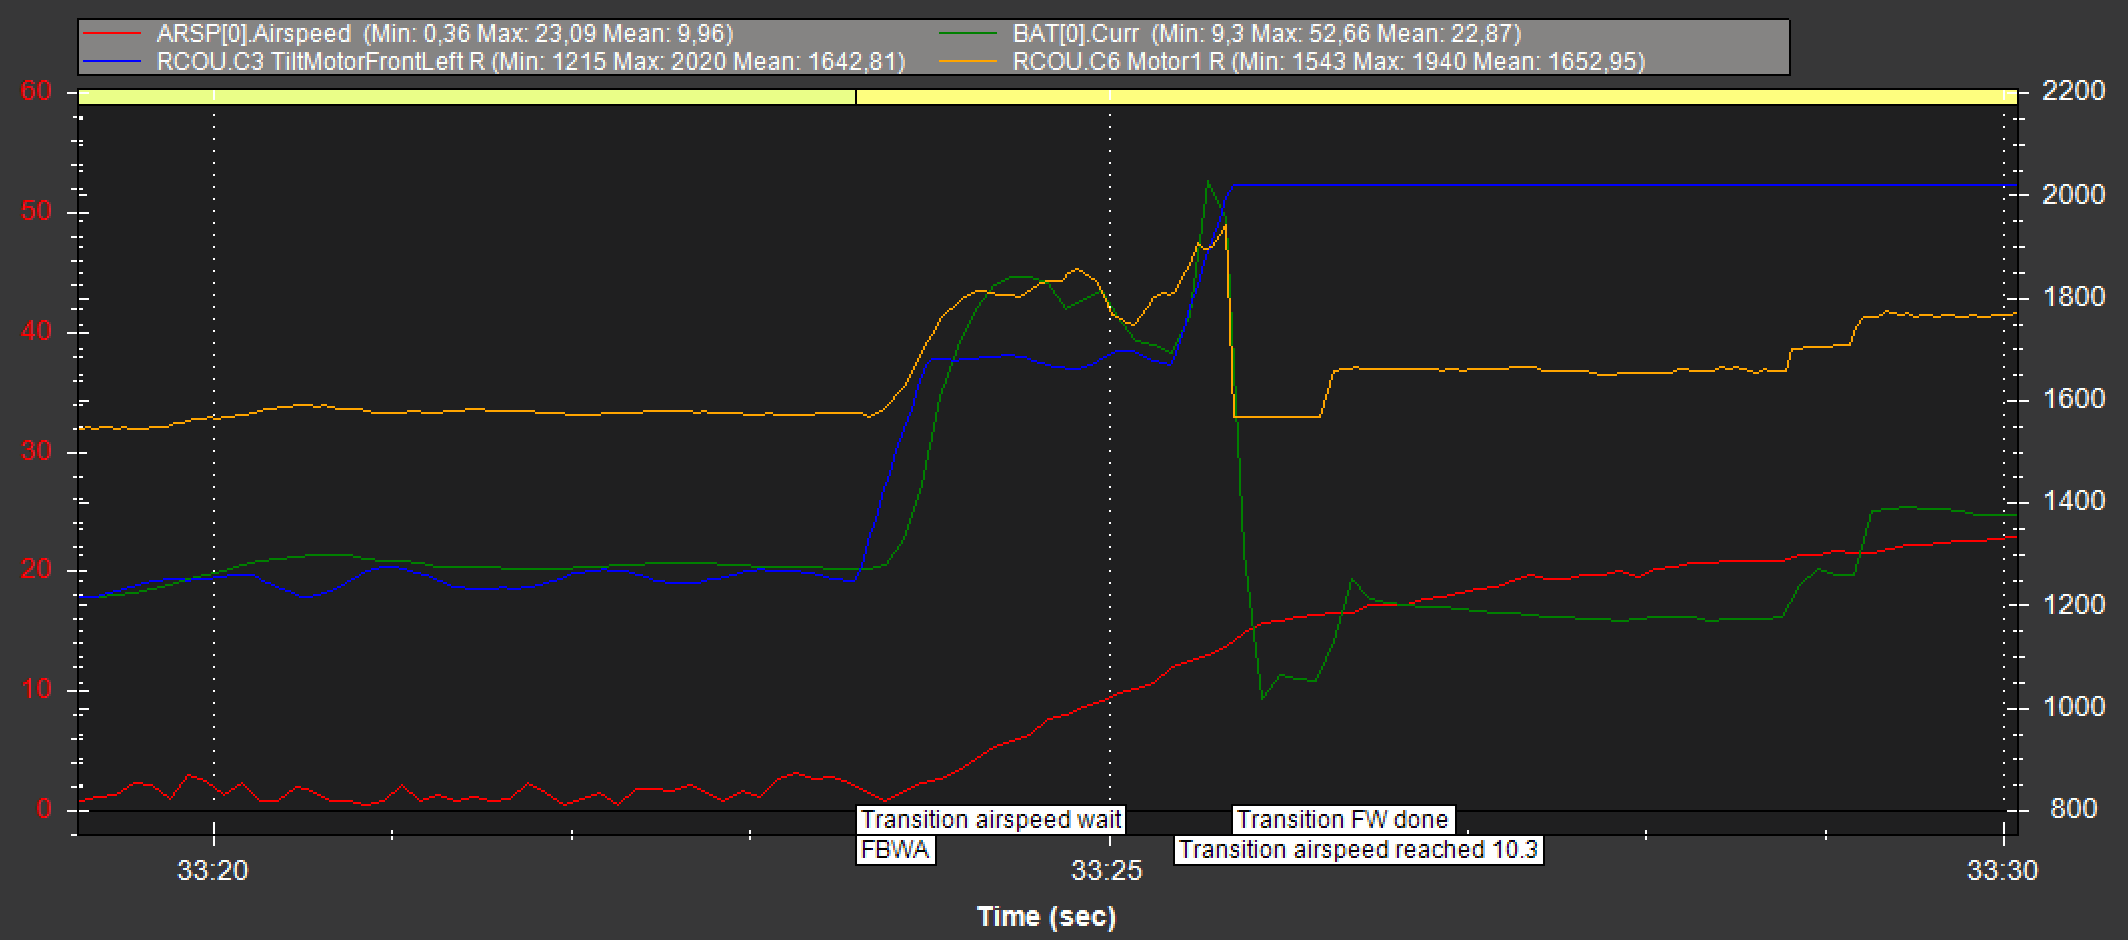
I’ve got a question about the transition of a tilt rotor flying wing. The transition works stable in both directiions but in eather way there is a throttle blip which seems unnecessary to me. Especially when switching back to QLoiter with an nearly empty battery the high current is harsh. Is there a way to mitigate that?
Transition to flight:
Transition to hover:
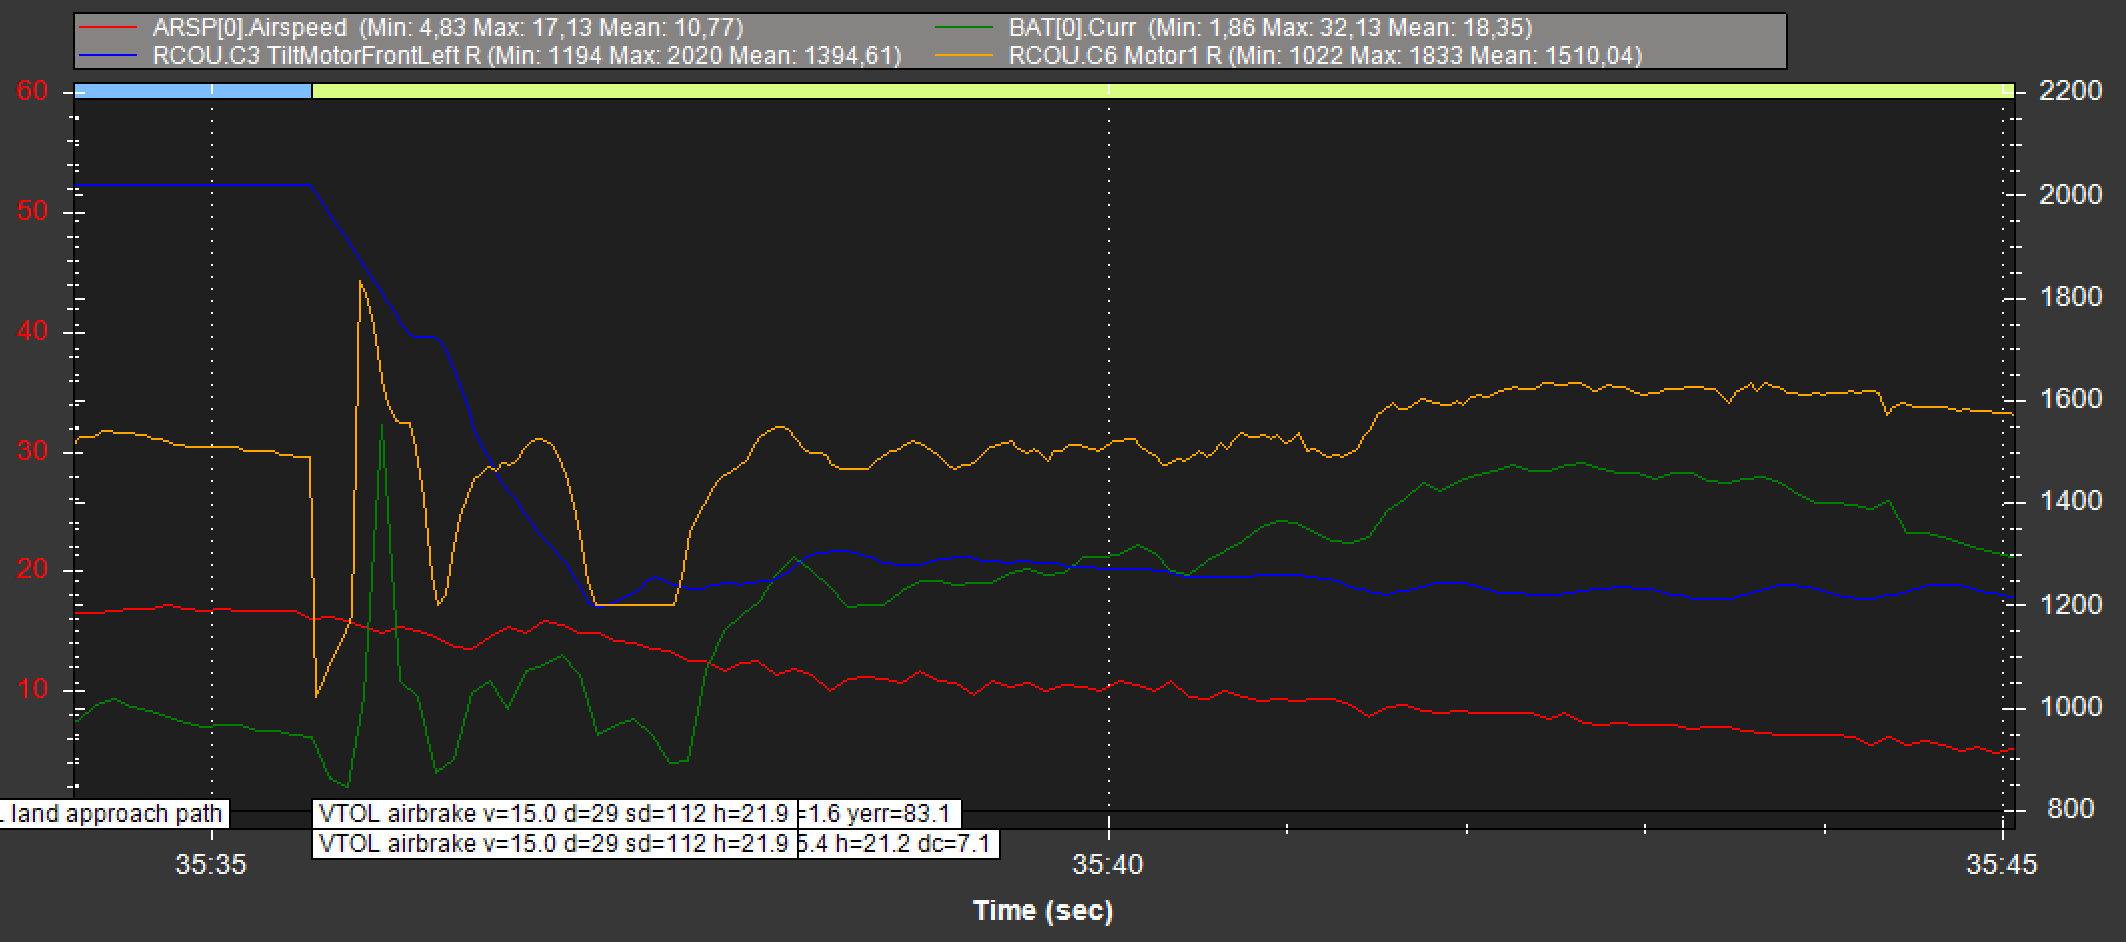
The green line shows the current and RCOUT.C6 is the servo signal of an ESC of a front motor.
Some data of the VTOL
flying wing, span: 1m
2 tilt rotors front, 1 non tilt at the back
crusing speed: 16m/s
min speed: 10m/s