I have reviewed other posts reporting a similar problem, but I suspect that mine is different. MY Tarot quad suffered a horrific crash during a video mission - the lipo pack slid from its harness at an altitude of 30 meters destroying the battery pack and heavily damaging the aircraft. It took a couple of months to repair it and I had a successful post-crash test flight. But two days ago, after receiving a new lipo pack, I tried another flight. I chose Stabilize, Alt Hold and RTL as my flight modes.
I took off in Stabilize - no problem - the landing gear retracted automatically. I then switched to Alt Hold and it held its altitude and I was able to move it around. The motors were running smoothly and all was good. Finally, I switched to RTL - the aircraft rose to its assigned altitude and flew over the launch point where it then began an uncommanded yaw. After one or two revolutions it reoriented itself and began to descend, the landing gear extended for landing, but when it was a couple of feet off the ground it began to yaw again. I managed to set it down safely.
This morning I tried again. There were some nearby landscapers who were making a lot of noise, so I relied on watching the GPS module LED to show green before attempting to arm. It armed okay and I took off but it immediately began yawing uncontrollably as the landing gear retracted. I had to set it down quickly - fortunately it was only a couple of feet off the ground so there was no damage.
Back home, I ran a motor test. All motors will start running at 6% power except #4 which requires 7%. I don’t know if this is a problem or not. My log can be found here.
Also, here is a video of the motor test: Click here.
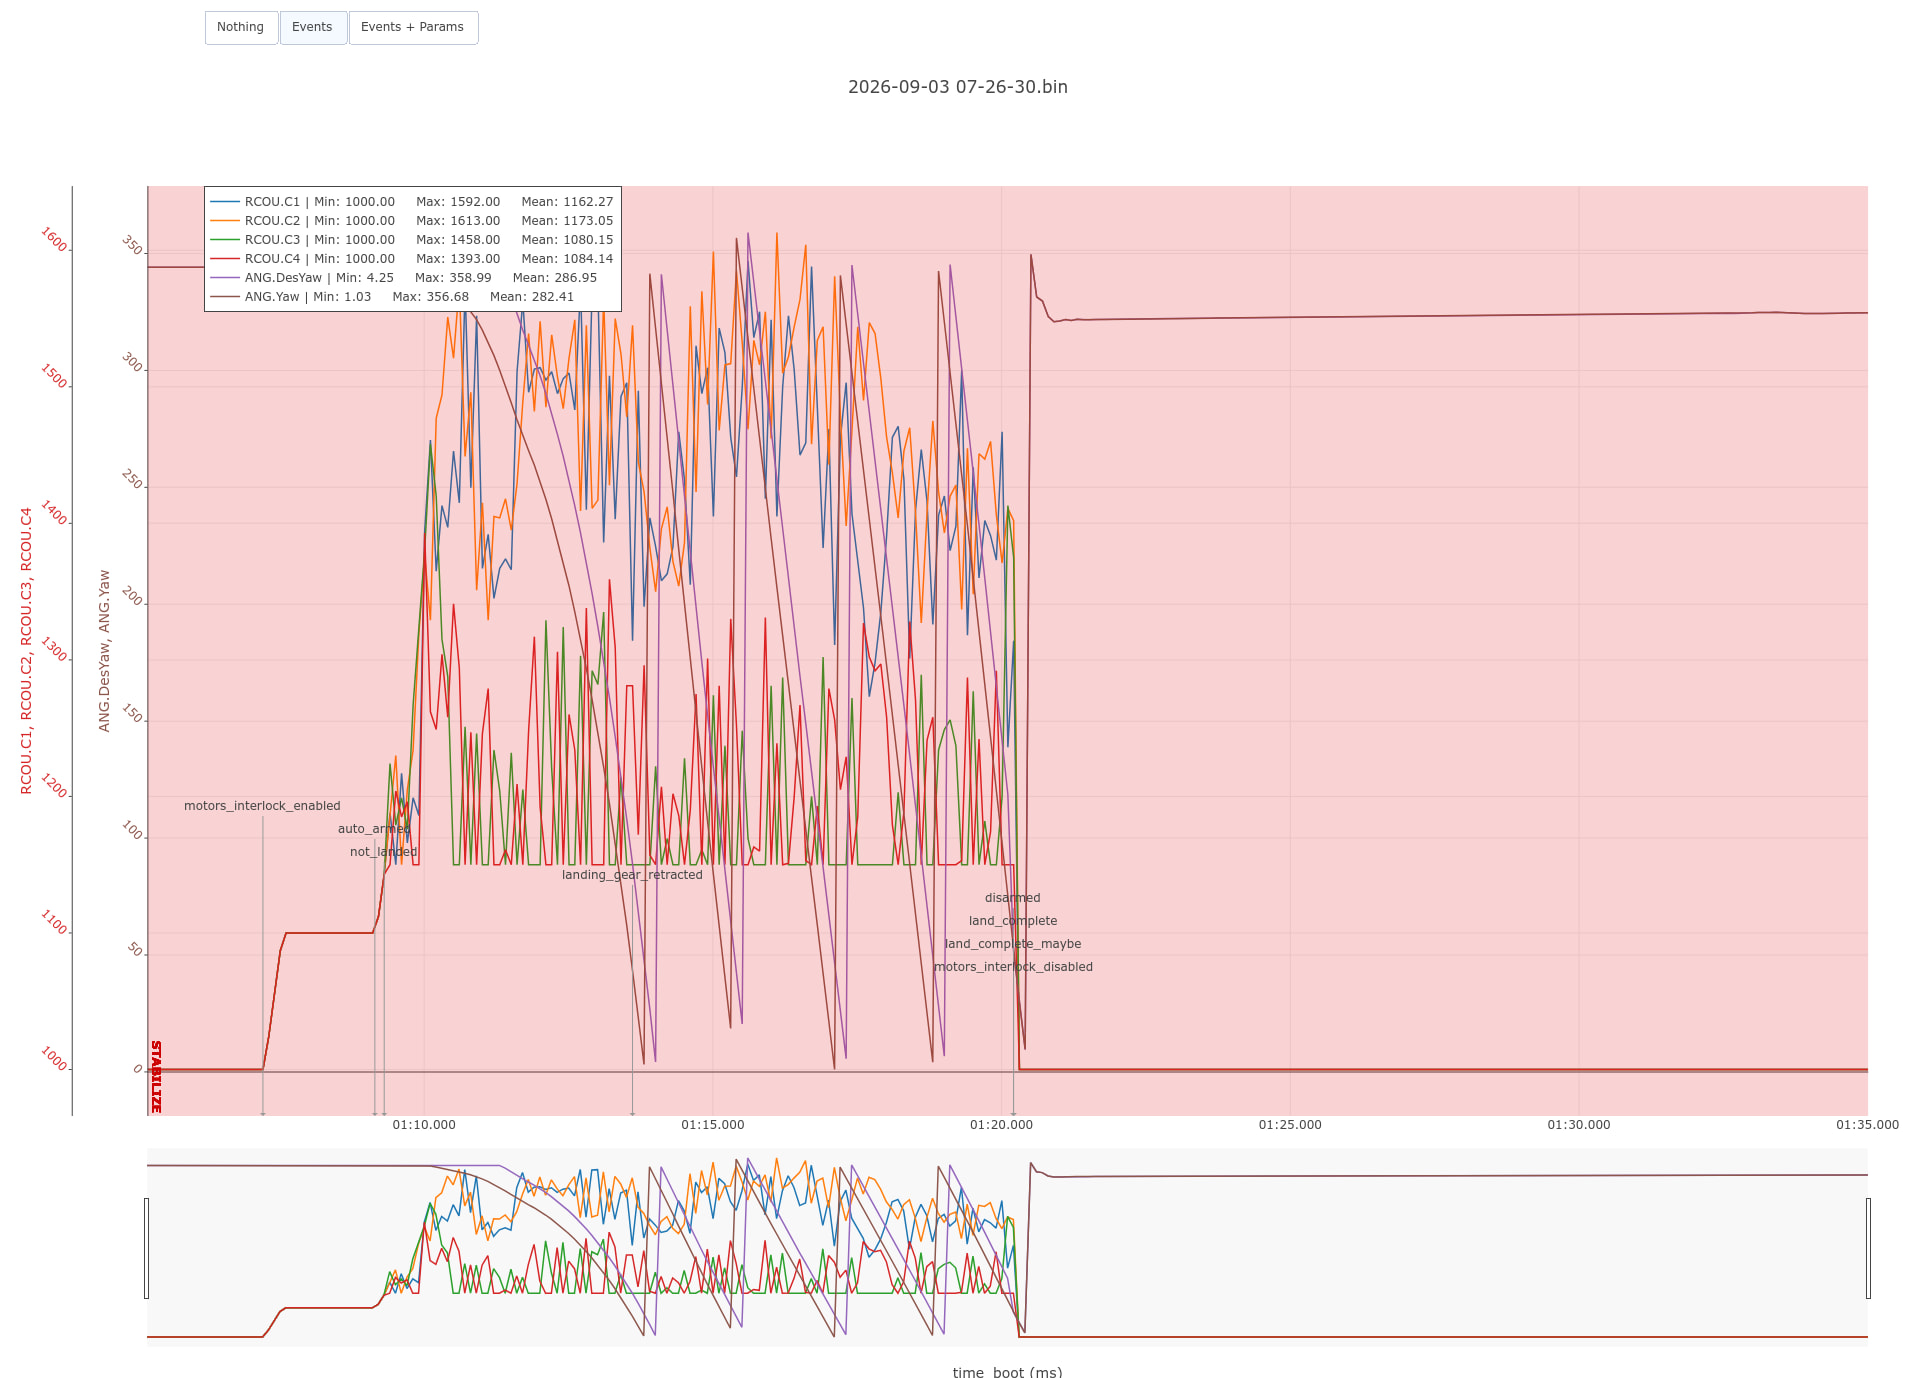
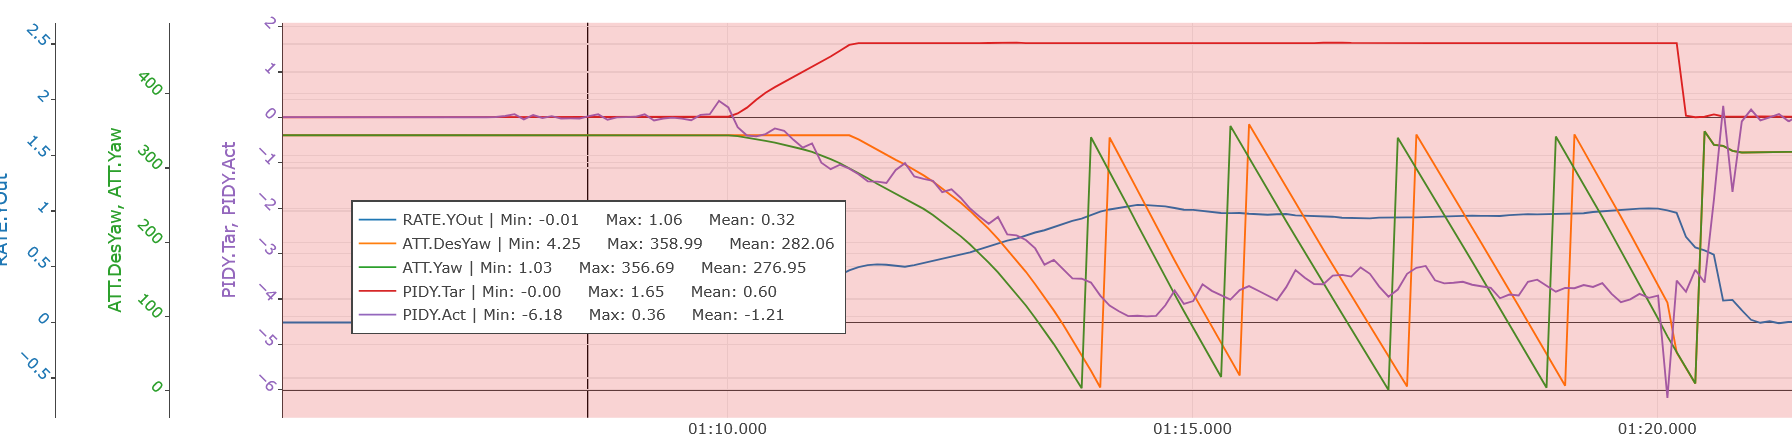
I believe this is the classic yaw imbalance due to motor misalignment on round tubes. Based on the log, this has nothing to do with the landing gear, yaw started to drift immediately after lift-off. Clockwise motors 3 and 4 cannot be made smaller than min RPM, so the machine cannot keep yaw and altitude at the same time.
What @MaxBuzz identified is the major problem and the tune on this craft is poor. Rate PID’s at default, MOT_SPIN_MIN at default and no Notch filter configuration are contributing factors. Looks like you missed some basic tuning steps.
That’s easy to see with RATE.YOut, it’s fully saturated (close to 1) while still not enough to keep yaw steady.
But I’m not 100% sure about it, are the props rotates in correct direction (target have other sign than actual)?
I noticed that when I reviewed the log but had no clue as to the cause. The propellers were properly installed and the motors’ spin directions were correct. As I had mentioned, I had previously flown the aircraft and it flew fine in Alt Hold mode.
I will recheck the motor alignments before attempting another flight. The hard landing requires me to recheck everything structurally. I removed the camera gimbal and will keep it off until I fix the problem - this will require a slight repositioning of the lipo pack to insure correct balance.
I checked the alignment of the motors by securing a level to the motor mount with a rubber band and turning until the motor was level and cinched down the mounting screws. Three of the motors were fine but the #2 motor was off a bit. Then I discovered that the mounting screws were all loose - yikes! When I repaired the aircraft after its horrible crash, I had to replace the #2 motor and I guess i neglected to tighten the mounting screws. So, I leveled the motor and cinched the screws.
Also, I changed the MOT_SPIN_MIN and MOT_SPIN_ARM parameters according to the recommendations.. I also raised the altitude for deploying the landing gear - wanted them too remain extended in case I had to quickly land. I took it out to the field but there was a light breeze but tried anyway. The plan was to do a short hop. Takeoff was normal and the aircraft was steady - no yaw. I immediately landed, satisfied that the problem was solved. I will wait for a morning with no breeze to fly it in ALT_HOLD and get some data for adjusting the filters.