I have been flying all the common modes including Acro, but never tried Sport mode.
I am interesting in flying my quad in cruise mode which does not exist. So the only two options I see are Acro (0) and Sport. Are both fundamentally same or there is some difference?
In both modes, pitch, roll and yaw sticks control rotation rates along the corresponding axes. There are few fundamental differences though:
in Acro, you control throttle directly, while in Sport the altitude controller is used instead (like in AltHold)
as a result, Acro (without trainer) is unlimited in pitch and roll, while in Sport the global angle limit is applied and roll/pitch stick inputs will be simply rejected if you want to go further
there is a fundamental difference in setpoints:
In Acro, yaw inputs do not change earth-frame attitude, so when you give a yaw input without roll and pitch inputs, you continue flying in the same direction relative to the surroundings/observers, but possibly sideways or backwards as seen from the FPV camera.
In Sport, this is in body-frame. When you have -40 degrees of pitch, 0 degrees of roll and are flying quickly forward as a result, and then apply yaw, you will still have -40 pitch and 0 roll at the end of the move, but a different attitude and direction of flight as seen by an external observer.
This changes flying quite a bit, for instance:
You are not required to perform coordinated turns in Sport to turn left and right, but the turns performed this way will not be as sharp as what you may do in Acro. To emulate that, you need to learn a different sequence of inputs.
Of course you are no longer able to do flips and rolls, Sport is just not for that.
Some usual Acro strategies, like changing forward speed by changing pitch while keeping throttle the same - which I use often in long-range flying when I want to keep current draw roughly the same - do not work in Sport because throttle is auto-managed and the effect would be quite the opposite.
I mainly use Sport in long-range/cinematic flights: with it, you can essentially fix both attitude and altitude, and release the sticks.
Last but not least, Sport is often left compiled out in readily available firmware, so you may need to enable it via Custom Build Server (or by compiling firmware yourself) and then upload to your board by choosing the downloaded (or compiled) firmware file.
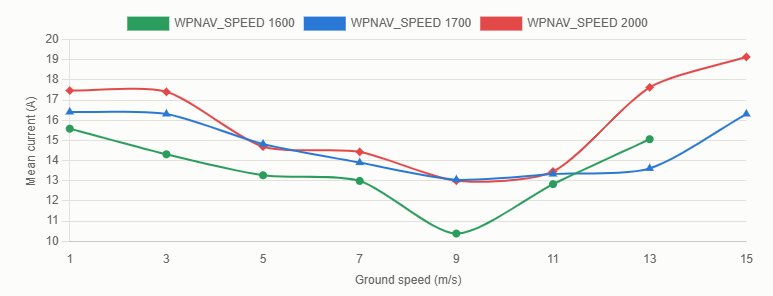
Thank you for such a detail explaination… much appricate. I checked both my quads and they have Sports mode available. I am gathering power consumption data via Auto mode as a function of speed VS current draw. But the Auto (mission) mode is balancing Alt and speed constantly which is preventing me to evalaute different wing geomatry to hone in on a best wing size (Yes, this experimental quad have wings). Based on your explaination Sport mode will do the same as Auto mode to maintaing Alt, meaning controlling the throttle. So I am left with Acro (w/o trainer) mode to test the aircraft. Only risk I see is flipping over if I am not careful