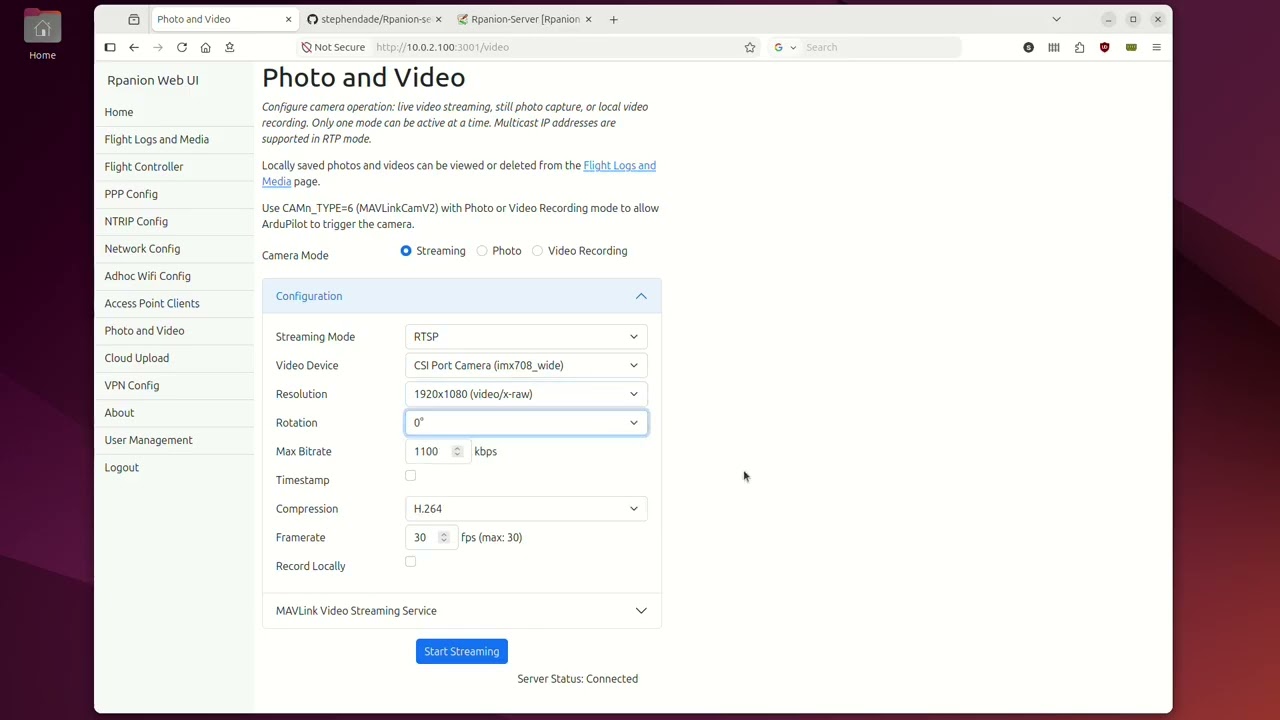
Rpanion-Server 1.0.0 has been released, with support for platforms (Jetson Orin, RasPiOS Trixie) and MAVLink camera controls (Camera Controls and Parameters — Copter documentation)
Rpanion-Server is an Open-Source software package designed to facilitate the management of companion computers (such as a Raspberry Pi or NVIDIA Jetson) on an ArduPilot-powered vehicle. It provides functions like MAVLink telemetry distribution, video recording/streaming and network management, NTRIP streaming, flight log management, PPP connection management, and automatic flight log cloud uploads. It is designed to be simple and light-weight, and can be run on fairly low-end platforms.
This release includes the following major changes:
- Add local video and stills recording
- Support added for Jetson Orin (Jetpack 7.2)
- Support ArduPilot MAVLinkCamera, to allow ArduPilot to trigger still or video capture
- Add option to sync flight controller time (clock) to system time
- PPP: Better reliability with restarts and start-on-boot
- Add support for RasPiOS Trixie
- Updated detection of cameras
- Cloud: Upload photos and video. Allow for upload-on-disarm
Comprehensive documentation is available here, with pre-built disk images and deb packages on the Releases page.
The source code for Rpanion-Server is available on GitHub, where bug reports and Pull Requests are welcome.
