Hello community,
We are facing an intermittent navigation/heading issue with an ArduPilot-based quadcopter during autonomous missions and would appreciate your guidance. We have been using the same quadcopter for the past 3 years and have taken almost 400 flights without any issues.
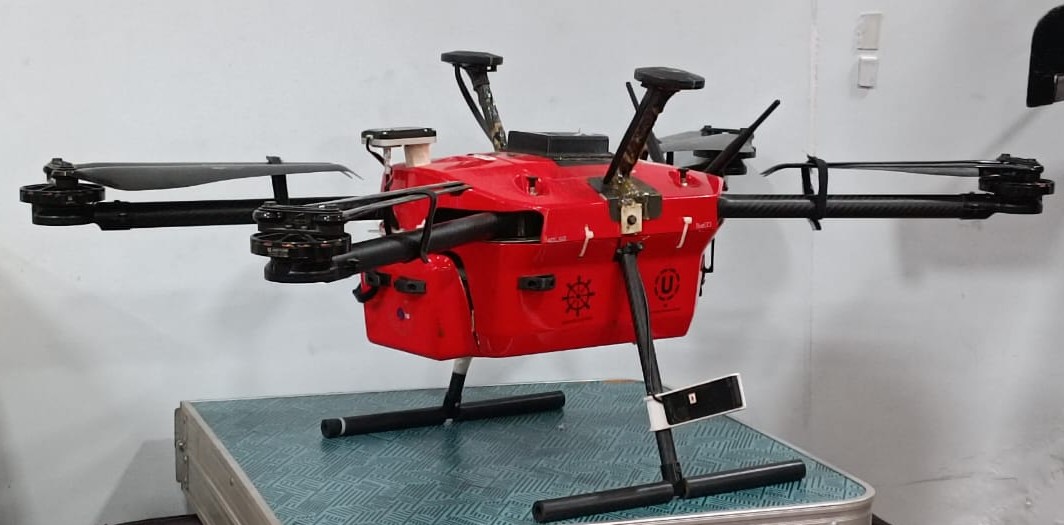
It’s a T-Drones M1000 drone with two MicaSense MX cameras as payload
Problem
During an AUTO mission, the quadcopter sometimes behaves as follows:
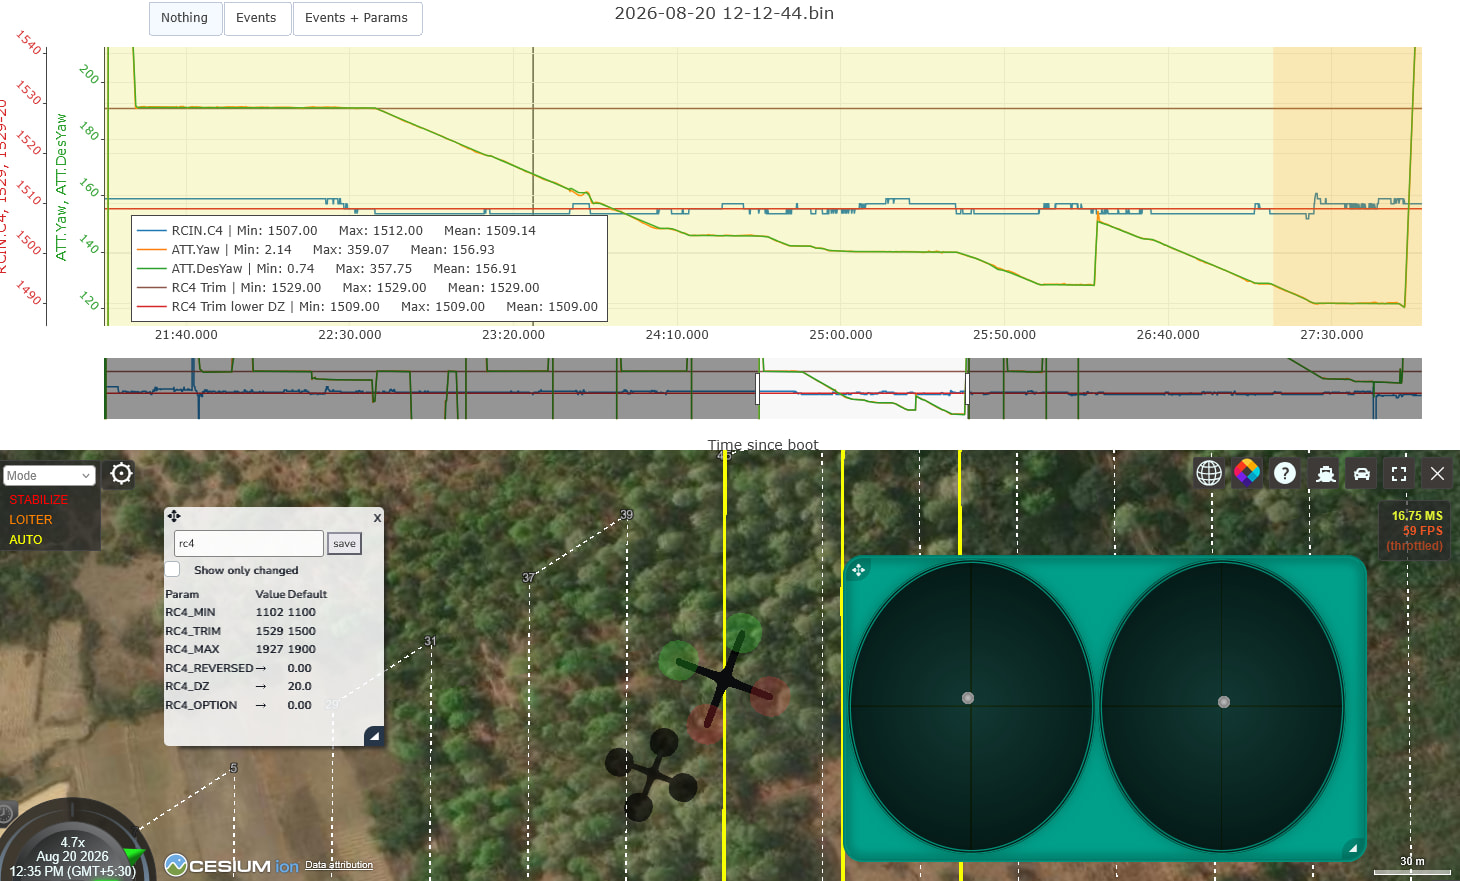
- The vehicle flies along the desired mission flight path, but its heading/yaw is oriented in a different direction.
- The yaw offset remains almost constant throughout a particular flight leg. In other words, the vehicle may be travelling north along the planned path while the nose is pointing, for example, 20–40° away from the direction of travel.
- The vehicle does not necessarily exhibit this behaviour on every leg or every flight. It’s kind of random. Sometimes the same/similar mission executes normally, while on other flights this issue occurs.
Logs are attached: https://drive.google.com/file/d/1_4SOTLZ8W-0t8f3YjSH60NEuBhz-2kN4/view?usp=drivesdk
Troubleshooting already performed
- We performed magnetic/compass calibration, but the problem persisted.
- We updated the ArduPilot firmware and also reverted to the previously working firmware version, but the issue was still present.
- The mission itself appears to be correctly generated, and the same mission has worked properly previously.
Could you please help us find the problem and resolve this weird issue? What is the recommended systematic approach to troubleshooting this kind of intermittent behaviour?