Hi everyone,
I am facing an issue with my quadcopter in Loiter mode and would appreciate some guidance on where I should start troubleshooting.
Problem
The quad is able to maintain its altitude very well in Loiter. However, it has two simultaneous issues:
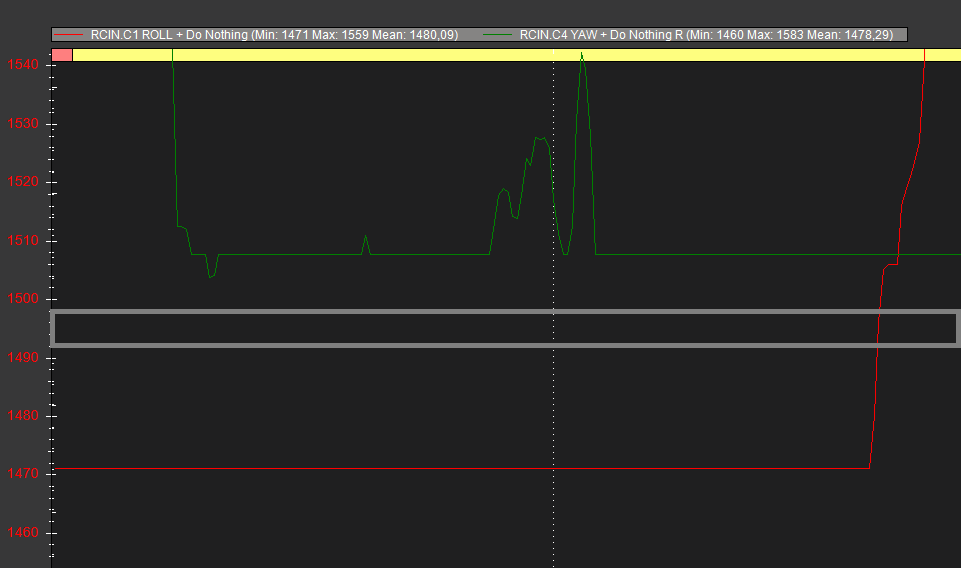
- It slowly drifts towards the left side even though the sticks are centered.
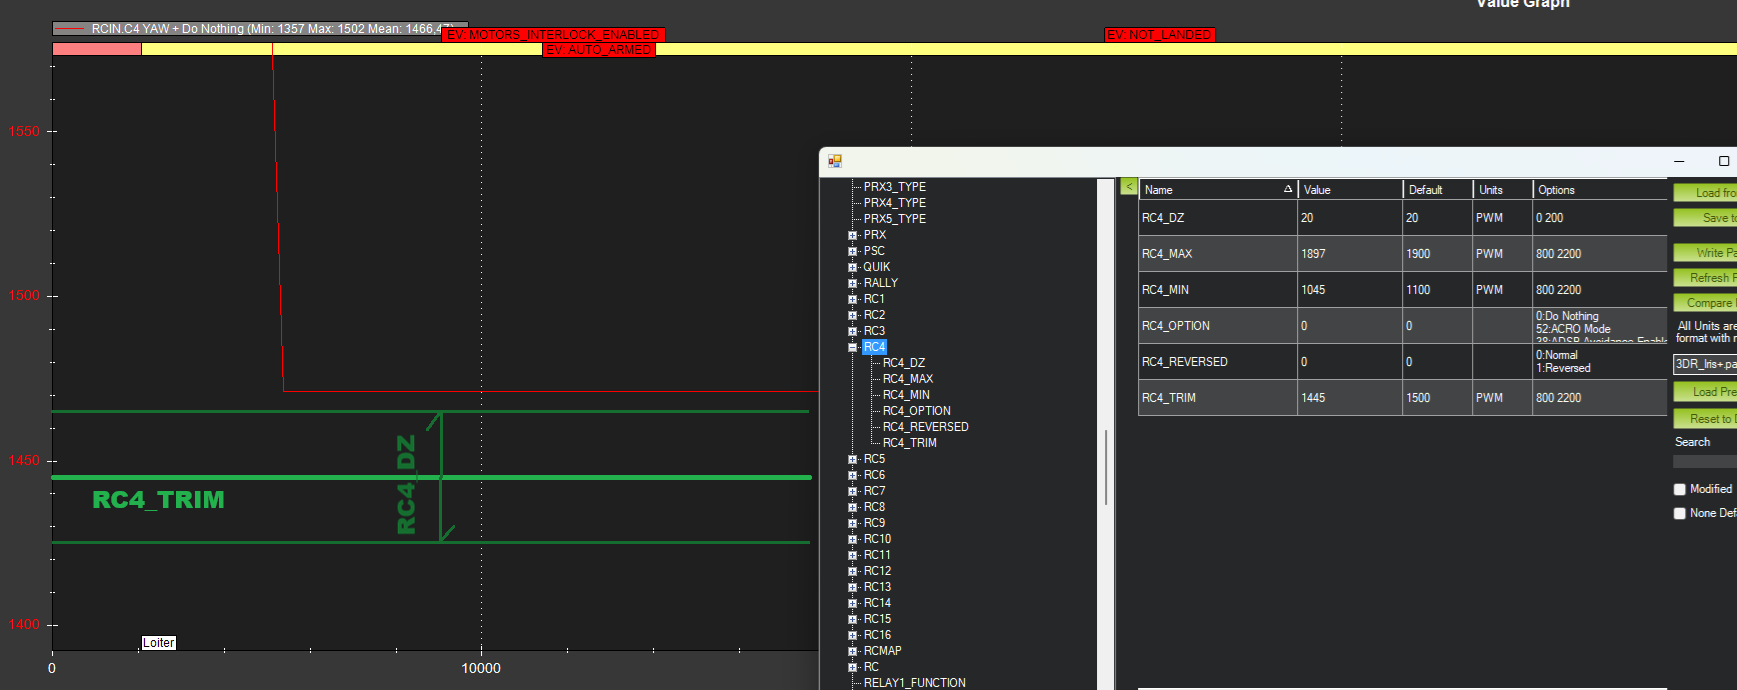
- At the same time, the quad slowly yaws towards the left, approximately in increments of 1°.
The yaw is not a sudden or aggressive rotation. It is a slow, continuous leftward yaw while the vehicle is trying to hold position.
Interestingly, the altitude hold is very good, and there is no significant up/down oscillation.
Hardware configuration
- Flight Controller: Cube Orange Plus
- Frame: Quad X
- Motors: T-Motor MN7005 KV115
- ESCs: T-Motor Flame 60A V2.0
- Propellers: 24 inch
- Battery: 2 × GenX Pro Solid State 6S 21 Ah connected in series
- Battery: 12S, 50.4 V fully charged
- AUW: approximately 7 kg
- Flight Mode: Loiter
Note: Calibrated compass in good GPS 3D fix , tested MOT compass interference (1%), aligned motors in level.
Observations
The vehicle does not appear to have an altitude-control problem. It maintains its altitude quite well.
The main concern is the combination of:
Slow leftward position drift + slow continuous left yaw.
The drift appears to happen even when there is no intentional stick input.
I have already followed the ArduPilot Mandatory Hardware Checks (AMC) as much as possible.
However, I had previously disabled the pre-arm checks for testing purposes. I will be enabling the pre-arm checks again before further testing.