There is definitely a mechanical problem with VIBE.VibeZ entries reaching 20 before the crash sequence and reaching more than 30 once the machine started to oscillate. But I see it quite unlikely that it contributed to the crash - it is just a thing requiring attention.
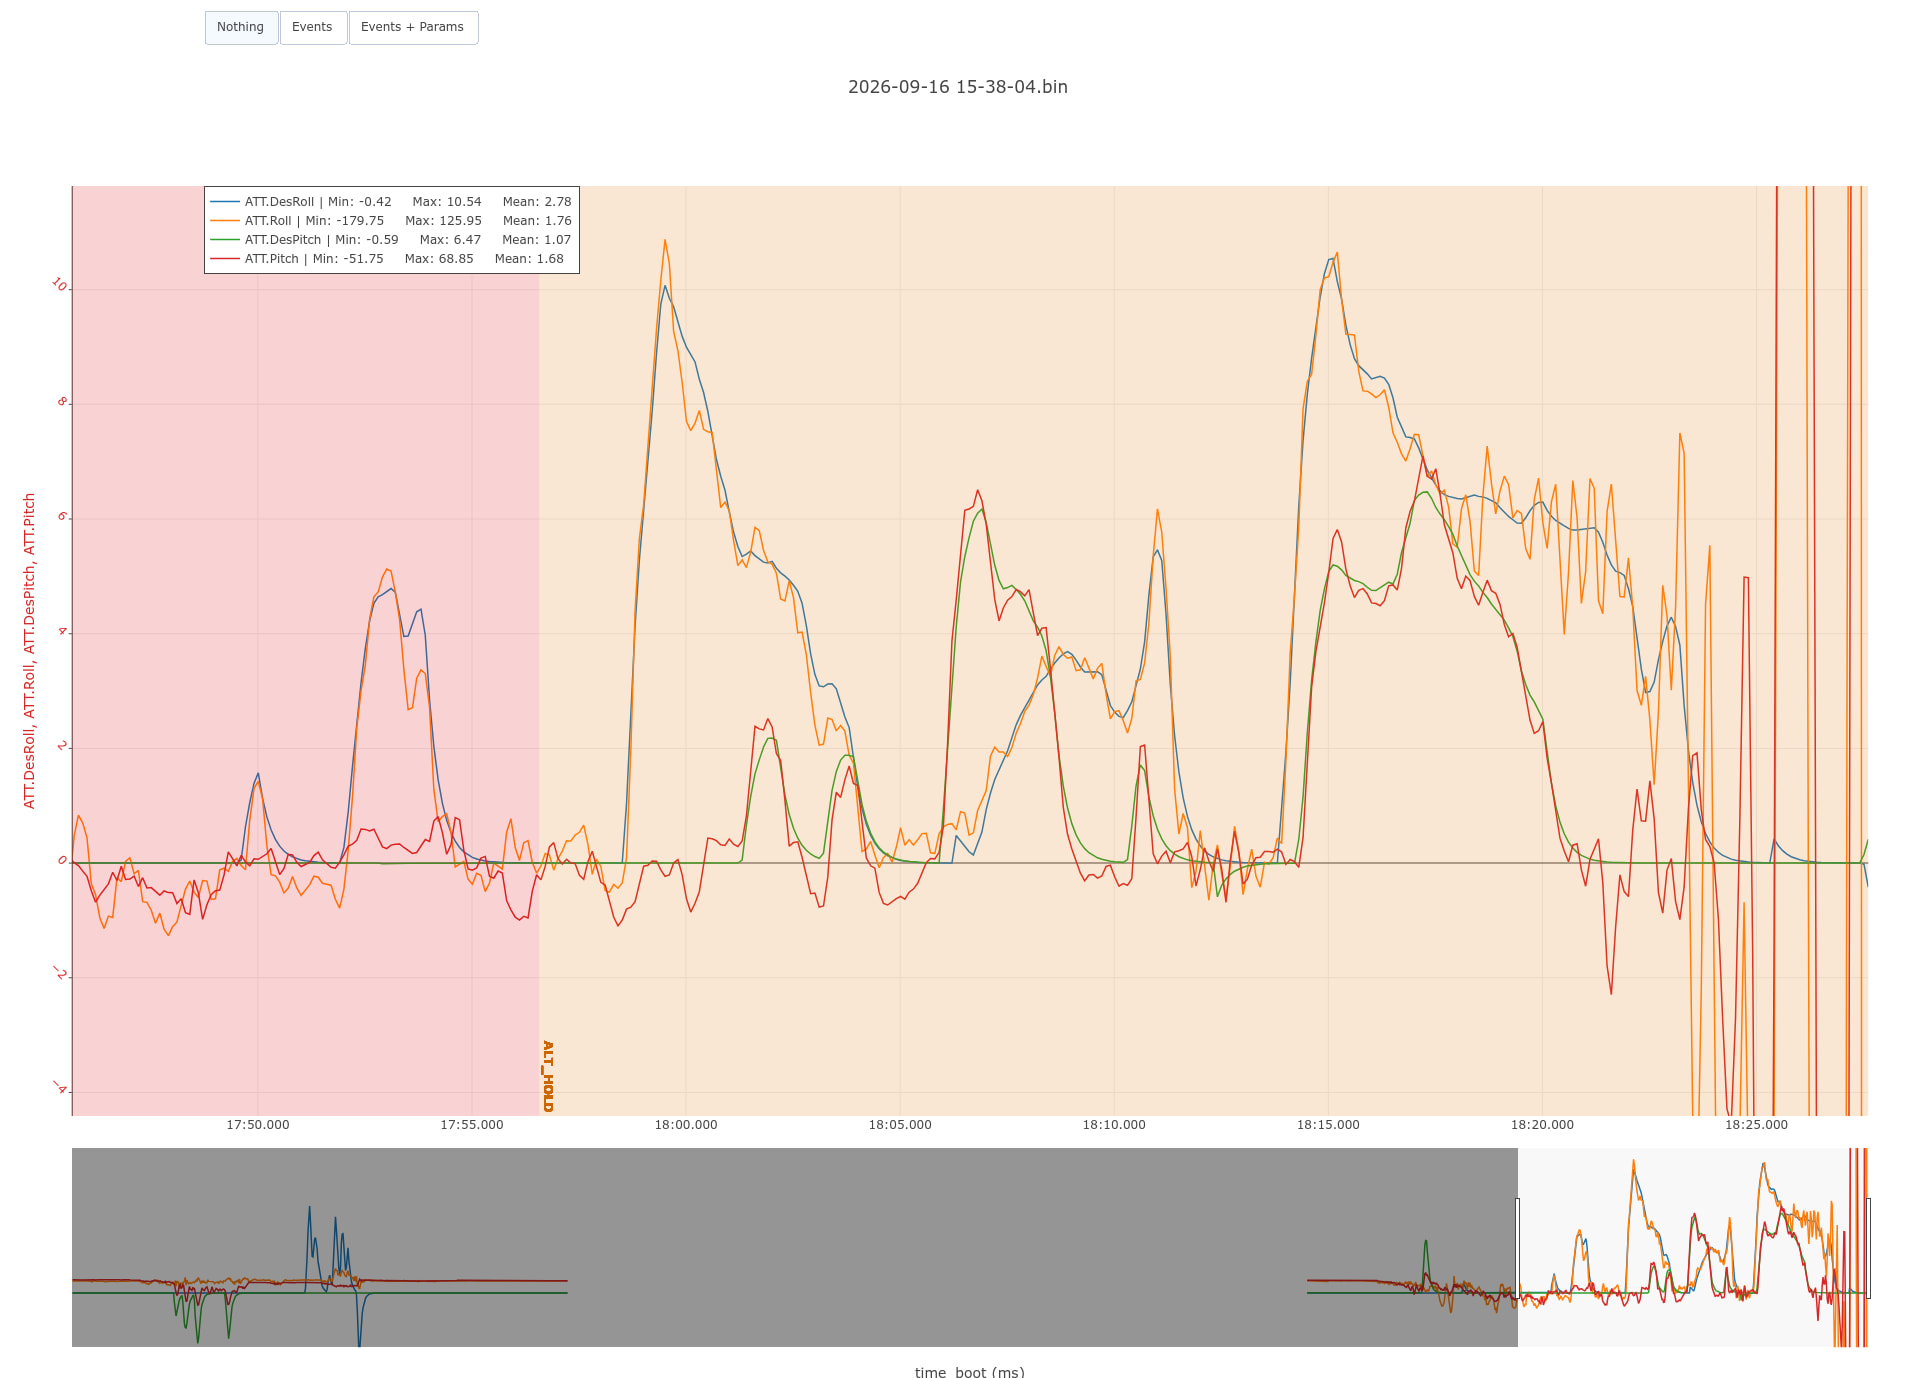
My main conjecture is that the crash happened because copter was barely ever tuned with a lot of incorrect parameter values, which simply self-excited itself in the roll.
More precisely, except for rate P, I and D values, everything is at defaults, including maximum angular accelerations (ATC_ACCEL_{R,P,Y}_MAX) which are set for a 9-inch ancient quad. I am almost sure that this machine cannot bear accelerations like that, so whenever it starts to compensate for any disturbances, the motors start kicking the frame much harder than it can handle. All the filters, and the angular P rates, are also for the same kind of machine, which might not be totally unreasonable for a machine of this size, but just contributes to the idea that there was barely any tuning.
As a result, the machine quite noticeably overcorrected (a lot of overshoots at setpoint changes), which just started to self-excite at some point.
As @amilcarlucas would have probably said if he reached this thread first - for a machine of this size, reset parameters and start anew with the Methodic Configurator.