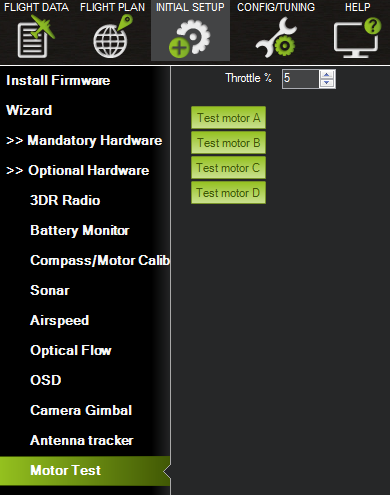
I am making an Octa H Plane with ArduPlane 4.6.3. FC is the Holybro Durandal and two 4in1 ESCs with the Bluejay firmware and DShot300 protocol are used to control the VTOL motors. I conducted the Motor test of the Mission Planner and found all 7 motors except moto5 are good. Their rotational directions are correct. But the motor5 did’t respond. It did not turn even if I raised the throttle setting up to 7%. But, starnge enough, when I armed with QLOITER mode, all 8 motors including motor5 turns slowly and correct directions.
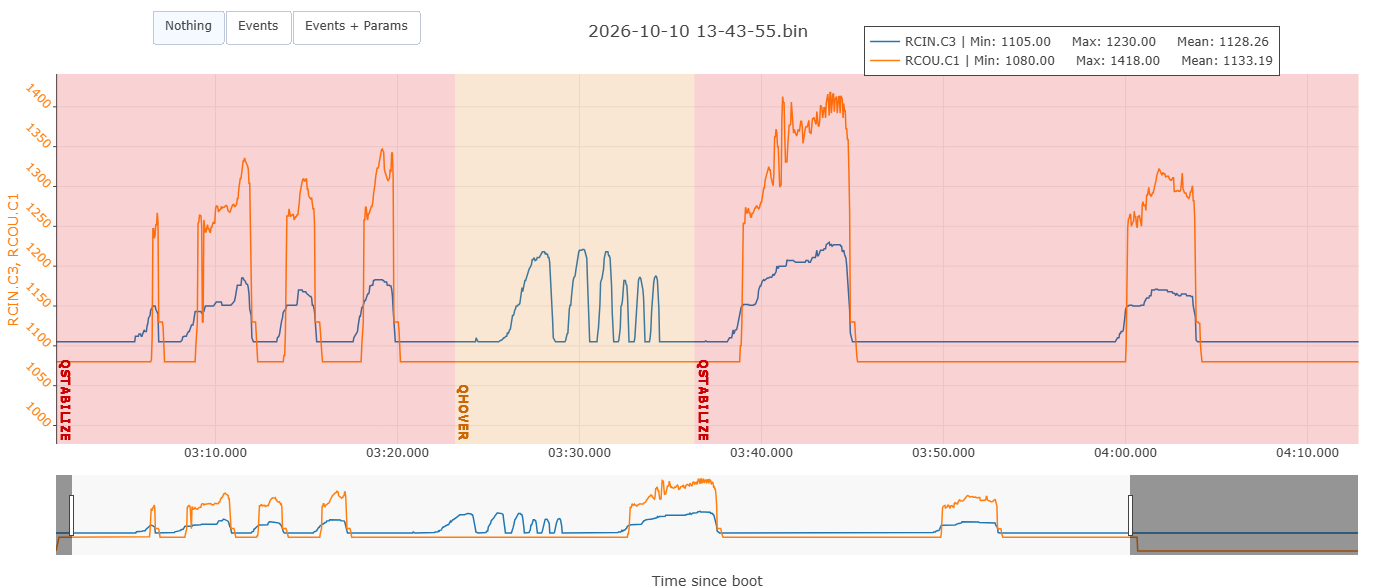
Then I tested throttole response with propellers off. The flight mode was QSTABILZE. All 8 motors respond as I moved the throttle. But when I changed the flight mode to QHOVER no motor turned even if I increase the throttle up to about 16% (Check the upper time history). Next I tried same test with QLOITER mode (lower time history) and found very strange facts, i.e. when I add small throttle input all 8 motors did not increase rotational speed. But when I increased throttle further, say about 1150, motors turn at a bit high speed. Then I increased the throttle even more, motors did not correspond the throttle. They stayed at middle speed. So in summary,
QSTABILIZE is OK but at QHOVER and QLOITER mode Motors did not follow the throttle.
Could anyone help me to resolve this strange phenomena? Thank you in advance.
Do not try to test the attitude controller using your RC controller as input and without propellers, it will not work, such tests are inconclusive and meaningless.
Do not try to test the attitude controller using your RC controller as input and with the vehicle tied down on the ground, it will not work, such tests are inconclusive and meaningless.
At this point, the vehicle does not react to roll, pitch, yaw or thrust inputs.
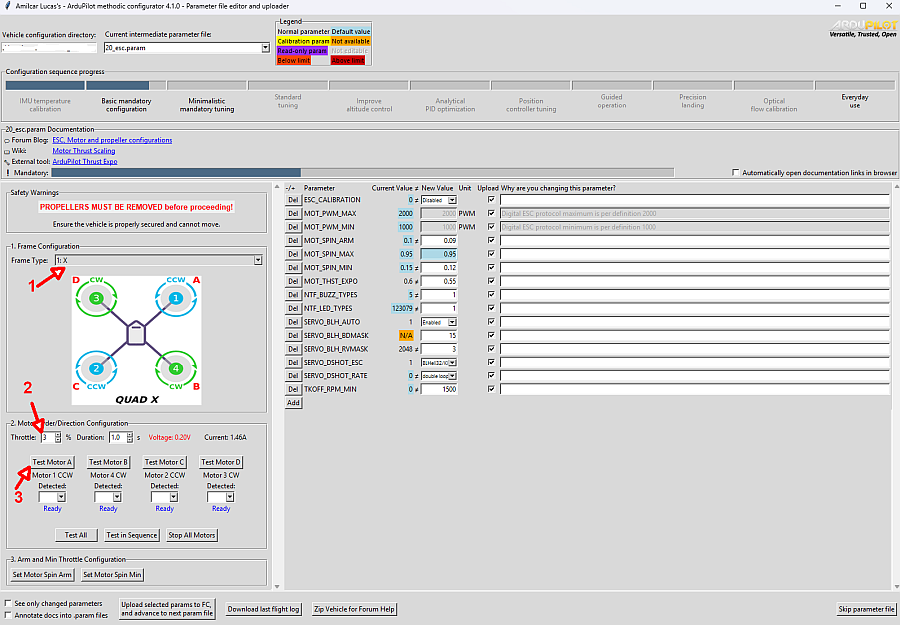
Use either MissionPlanner’s Motor test or ArduPilotMethodicConfigurator Motor test both will do what you want and the results are valid. Both do not use input from the RC controller so both bypass the open control loops!
The problem is the open control loops. Read a bit on control theory and you will understand what that is and why it just does not work.
Edit: I improved my post above explaining why they are inconclusive.
A closed control loop (Ardupilot when using the RC-controller as input) is like a machine that keeps checking, “Am I doing what I’m supposed to?” and adjusting itself when it drifts.
If the loop opens (you remove the props, or tie the vehicle down), that checking and correcting stops. For an unstable system (multicopters are by nature unstable), even a tiny disturbance can then grow over time instead of being corrected. Imagine balancing a broom upright: with your hand guiding it, you can keep it balanced; let go, and a small lean quickly becomes a fall.
The exact result depends on the vehicle. Its output might drift, oscillate more and more, or shoot toward a limit. Opening the loop doesn’t always make it unstable—the key is that an unstable system no longer has the feedback that was keeping it under control.
OK I can understand. Mission Planner’s Motor Test is valid but those test I did without propellers were invalid because of no feedback. Right? Then I have a question what was the reason the Motor5 did’t turn during the Motor Test? What shall I do to turn the Motor5 in this test?
Is the Motor5 output correctly configured? Is it correctly connected? What configurations have you done? Did it ever worked at some point?
If it worked like you described in the first post, but does not work with Mission Planner motor test, then something is extremely wrong in your system!
Motor5 is connected correctly. Its parameters are set as SERVO5_MIN=1000, SERVO5_MAX=2000, SERVO5_TRIM=1000, SERVO5_REVERSED=0, SERVO5_FUNCTION=37. It does not rurn at the Motor Test but it turns QSTABILIZED mode as I described in the first post. Shall I increase the Throttle % more, say up to 10%?
I conducted QLOITER mode test with propellers. The vehicle was on the ground and it was not tied. All motors began to turn slowly when I armed. It was normal. When I increased the throttle slowly, at first motors did not increase speed because of the 10% throttle_wait. But when the throttle exceeded 10%, motors turn quite rapidly. It is absolutely unusual. Then I increase throttle but the motor speed did not incresed but there are vibration. So the vehicle did not lift off. Could you teach me the reason of this mysterious phenomena? The Bin log file is here. https://drive.google.com/file/d/1qUbfBxRCow1_n4M_2ldSe6NHADKXnlZz/view?usp=sharing
That’s not unusual. It’s trying to take off, and until it does, it will increase throttle. STOP conducting these experiments until you solve the actual issue, which appears to be a potentially faulty or misconfigured motor 5. You will end up crashing your copter if you keep doing what amounts to random “testing.”
Maybe you can interchange the ESC and / or the motor with one other and see if the problem is still on the same motor or esc. By this you can find the faulty component.