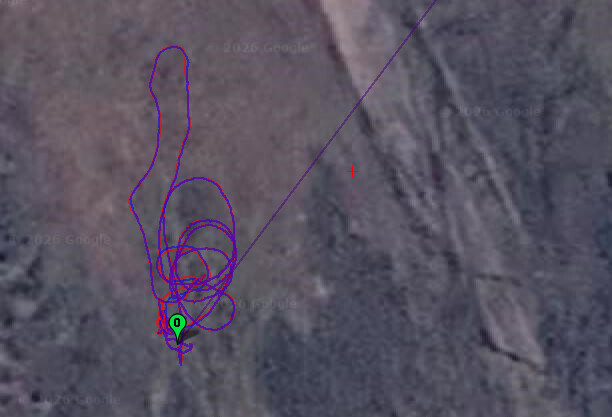
Hello,
I’m an advanced ArduCopter and ArduPlane user, and now I’ve decided time has came to build my first ArduRover. My son lost any interest in his Traxxas Stampede after he got the Traxxas 4WD Raptor, so I’ve started to get the former one into the ArduRover world. I added the Matek F765 controller, upgraded the ESC to a sensored QuicRun 10BL120 and in general thought that compared to drones it will be an easy piece of cake…
But the reality was very different. In fact, the task seem to be more daunting and frustrating… after several attempts, I don’t know if the autonomous mode works at all!
When in Manual, it listenes to the control - I can drive and turn where I want. The ESC is not tuned and calibrated correctly, but the truck moves forwards and backwards. The strange thing is that after booting, the direction of the turns is reversed and then it changes to what I would expect (moving the stick to the right and the vehicle turns rights).
However, in Circle, it seems to be a random ride. I can see some partial circle shape in the track log, but these circles are not located in the same place, and in general it is not reproducible. Also, I can’t see any turn servo corrections. How to diagnose this problem?