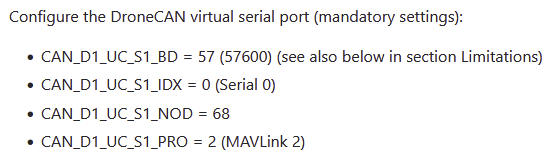
edit: Here’s the fix:
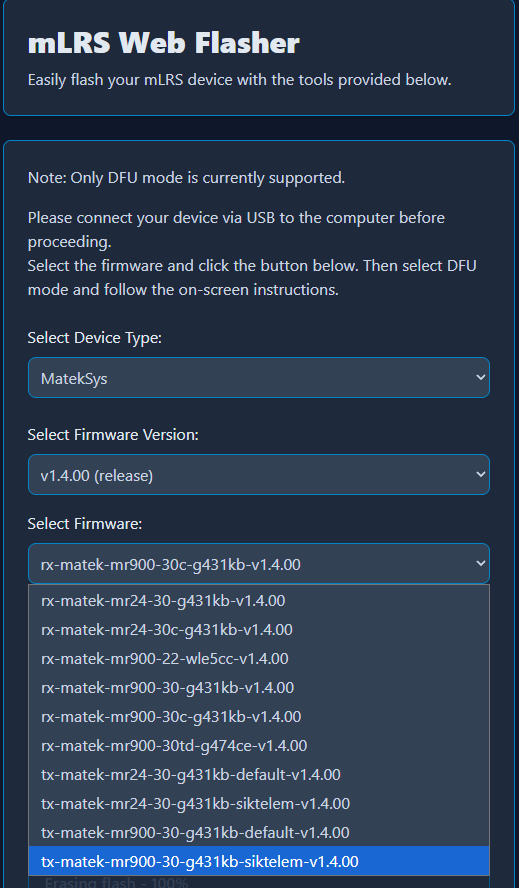
Don’t flash the “default.” Instead get the “siktelem” version. Also I downgraded from “prerelease” to 1.4.00 “release” So try doing both or either of those things if you have a similar problem yourself.
/edit
Cube Orange+ was running low on serial ports so I removed the mR900-30(not c) rx from its serial port and installed the CAN version onto a CANPDBHUB-4A. Mission Planner can see it at address 68.
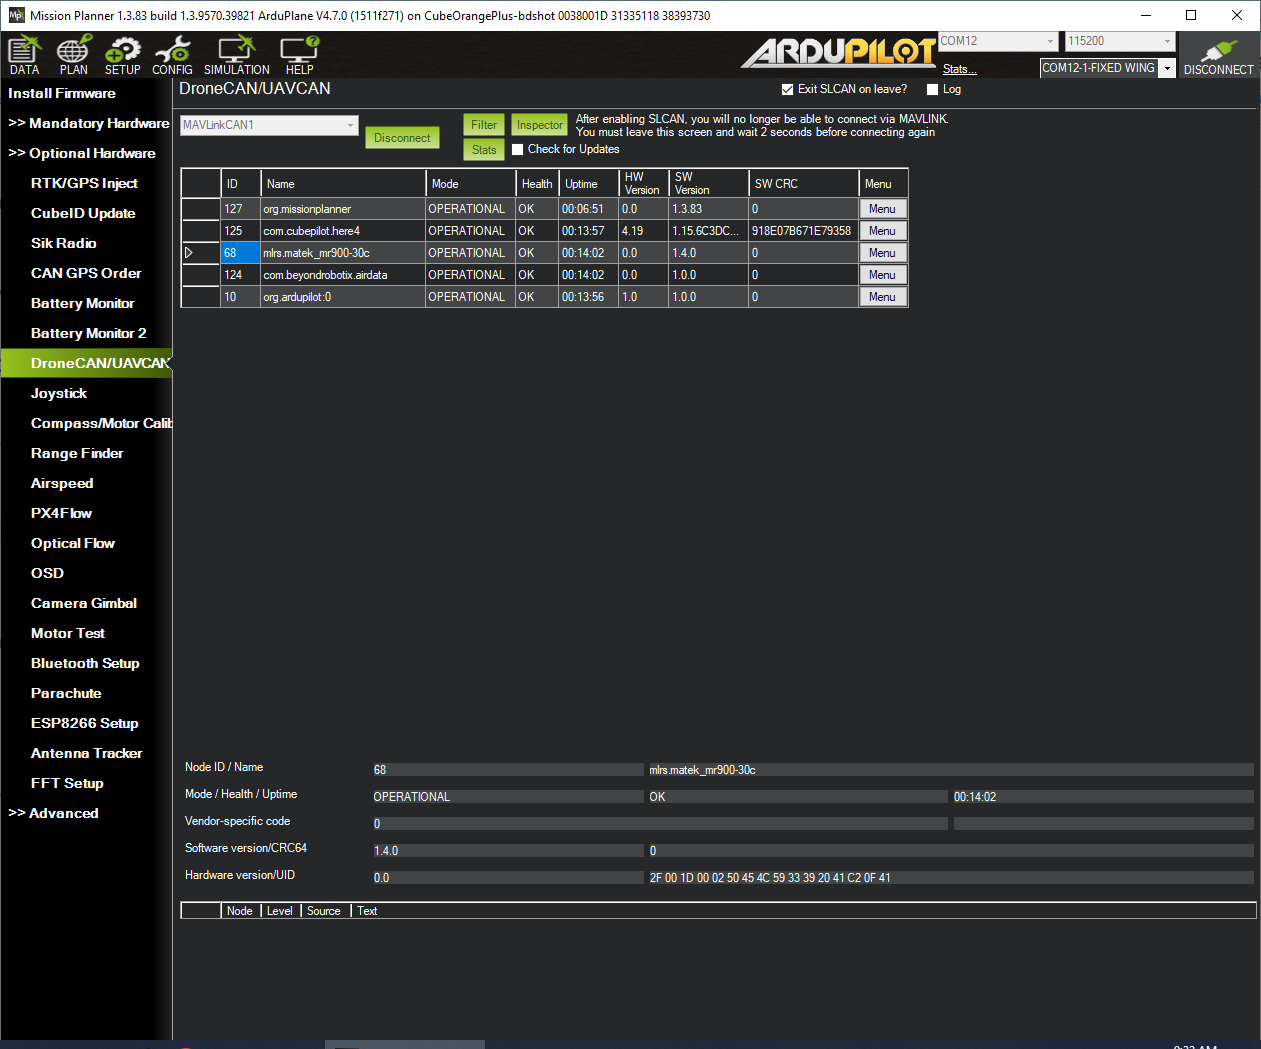
202610210153.param (19.3 KB)
I followed the instructions at mLRS-docu/docs/DRONECAN.md at main · olliw42/mLRS-docu · GitHub, and I failed so hard that my GPS and airspeed sensor stopped working. So I reset to default parameters and started over. I’ve repeated this step a few times and I don’t seem to be getting anywhere.
I followed the same binding procedure for the radios as I did for the non-CAN version. The lights are blinking slow and green which indicates they are bound. But when I try to connect I get no heartbeat packets.
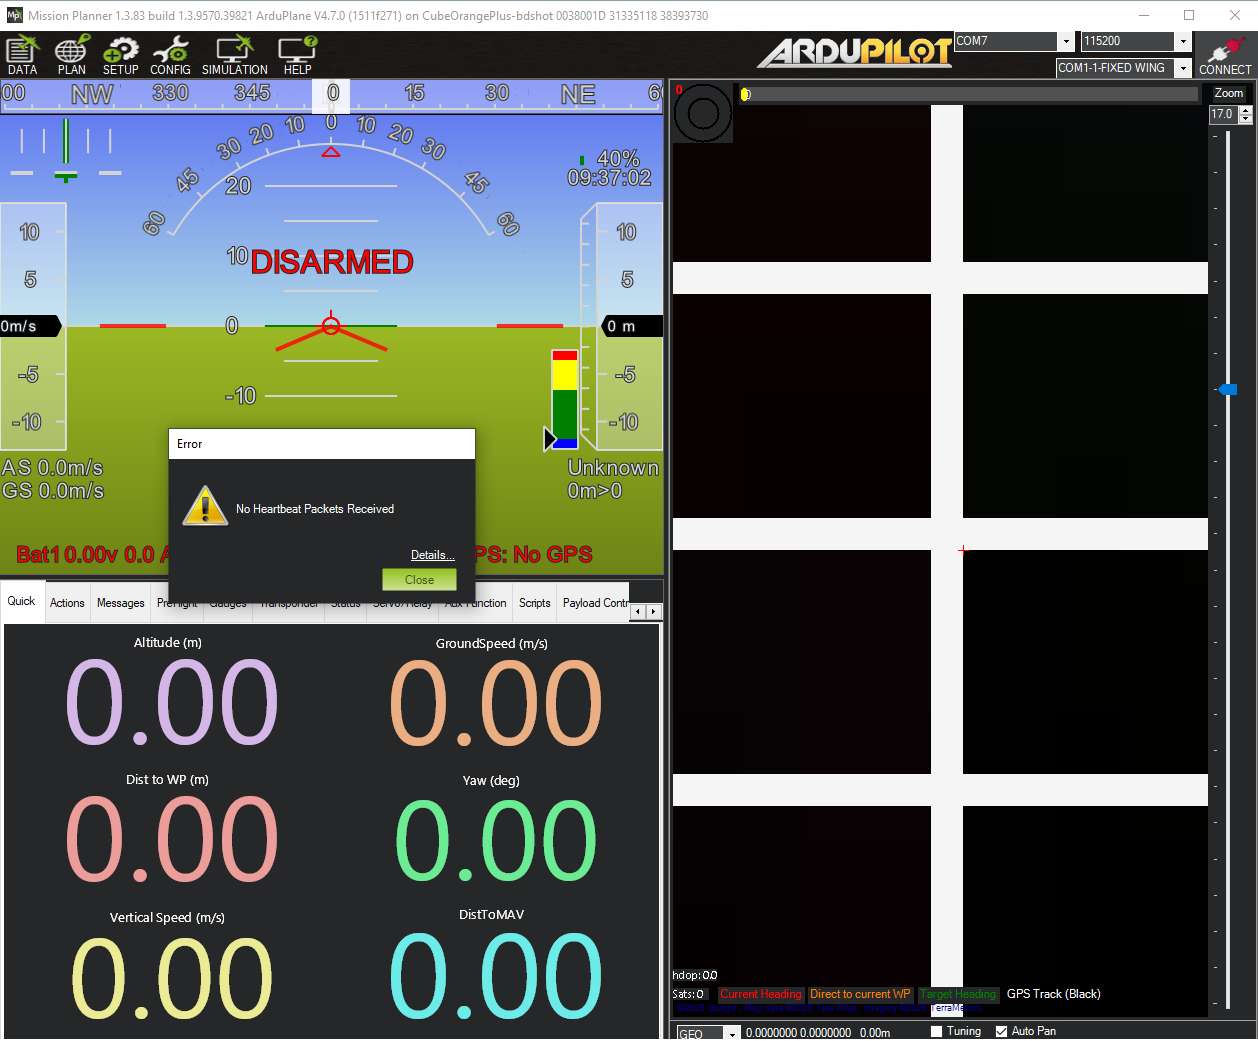
But the connection has 40% signal strength.
The tx and rx are bound. Arduplane knows there’s something at address 68, and there’s 40% connection strength. I know I’m overlooking something but I don’t know what.