The onboard barometer on the Matek ASPD-AUAV is experiencing intermittent faults, fluctuating between accurate altitude readings and erroneous values of -2000m every few seconds. I am using DroneCAN, disabling the device resolves the issue; however, we would prefer to maintain the barometer as a redundant sensor. Do you have any recommendations for resolving this instability?
Is the airspeed sensor functioning correctly? A link to a log file would be helpful.
I also connected the ASPD-AUAV via the CAN bus and found that both the airspeed measurement and the barometer were working without any issues.
Rolf
Airspeed works fine. Only the barometer is acting up. I haven’t flown it with the external baro enabled but i can take a log while on the ground.
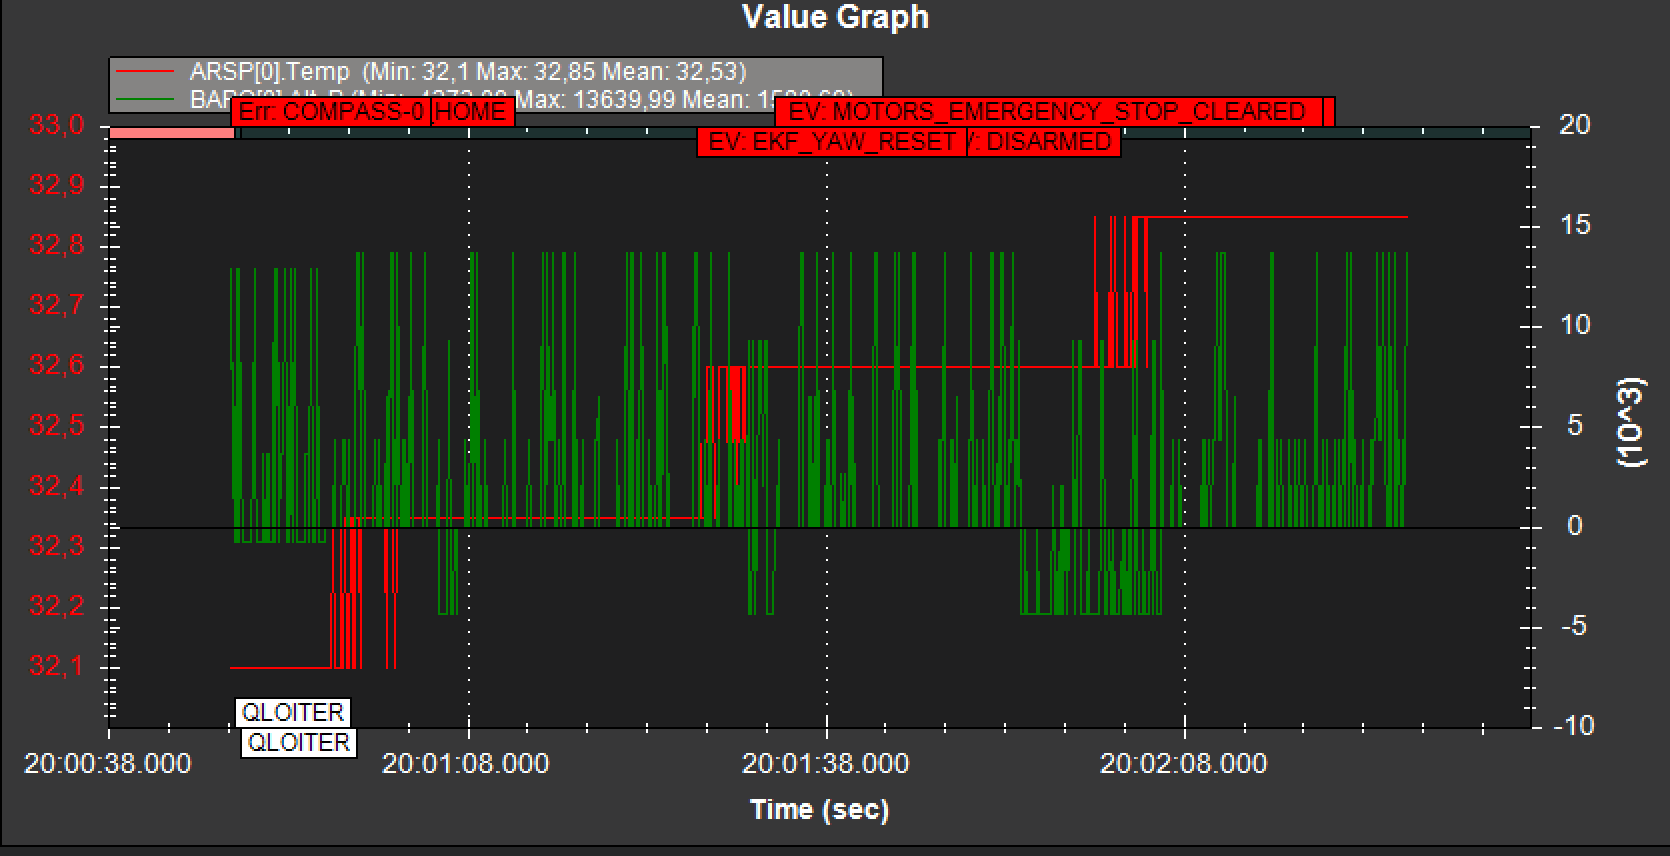
Youll see that baro 0 is all over the place. Thats the matek airspeed baro
I tried the sensor on a cube orange plus runing plane 4.7.1. Same weird behavior.
For I2C operation, you must close a solder jumper (see red circle: https://www.mateksys.com/?portfolio=aspd-auav#tab-id-1)
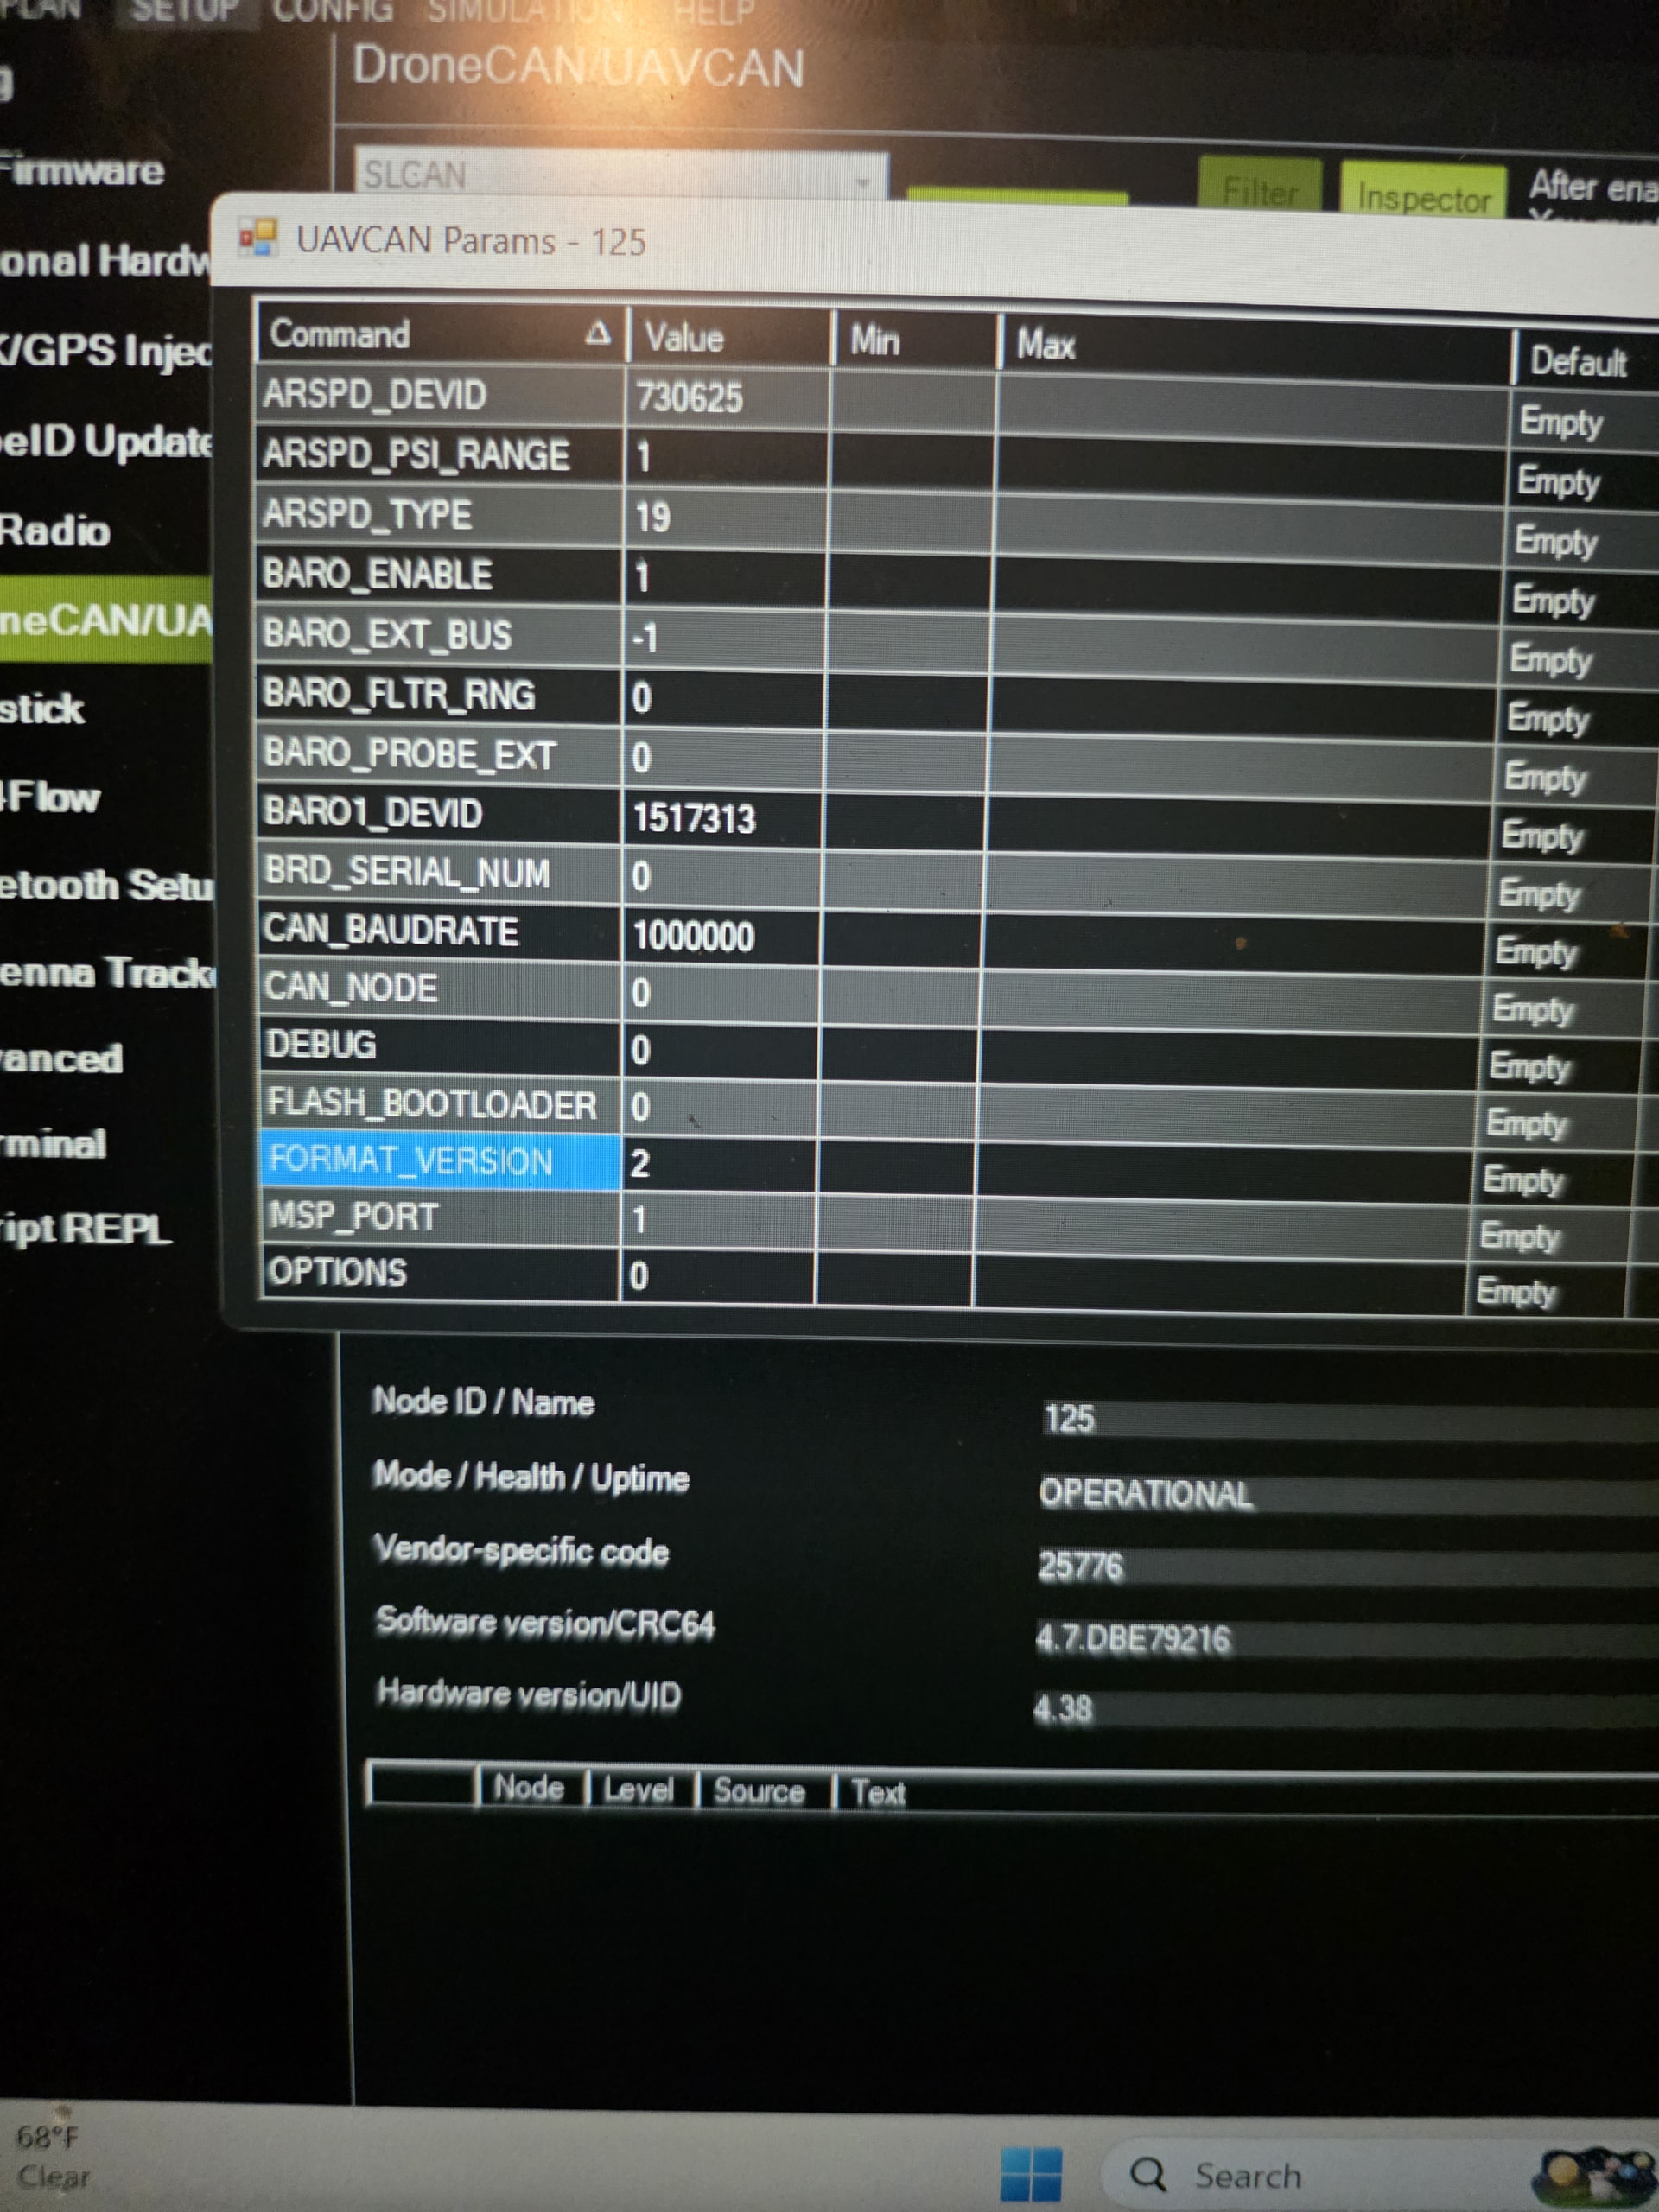
If you can do without the barometer, you could disable it in the Drone-Can menu.
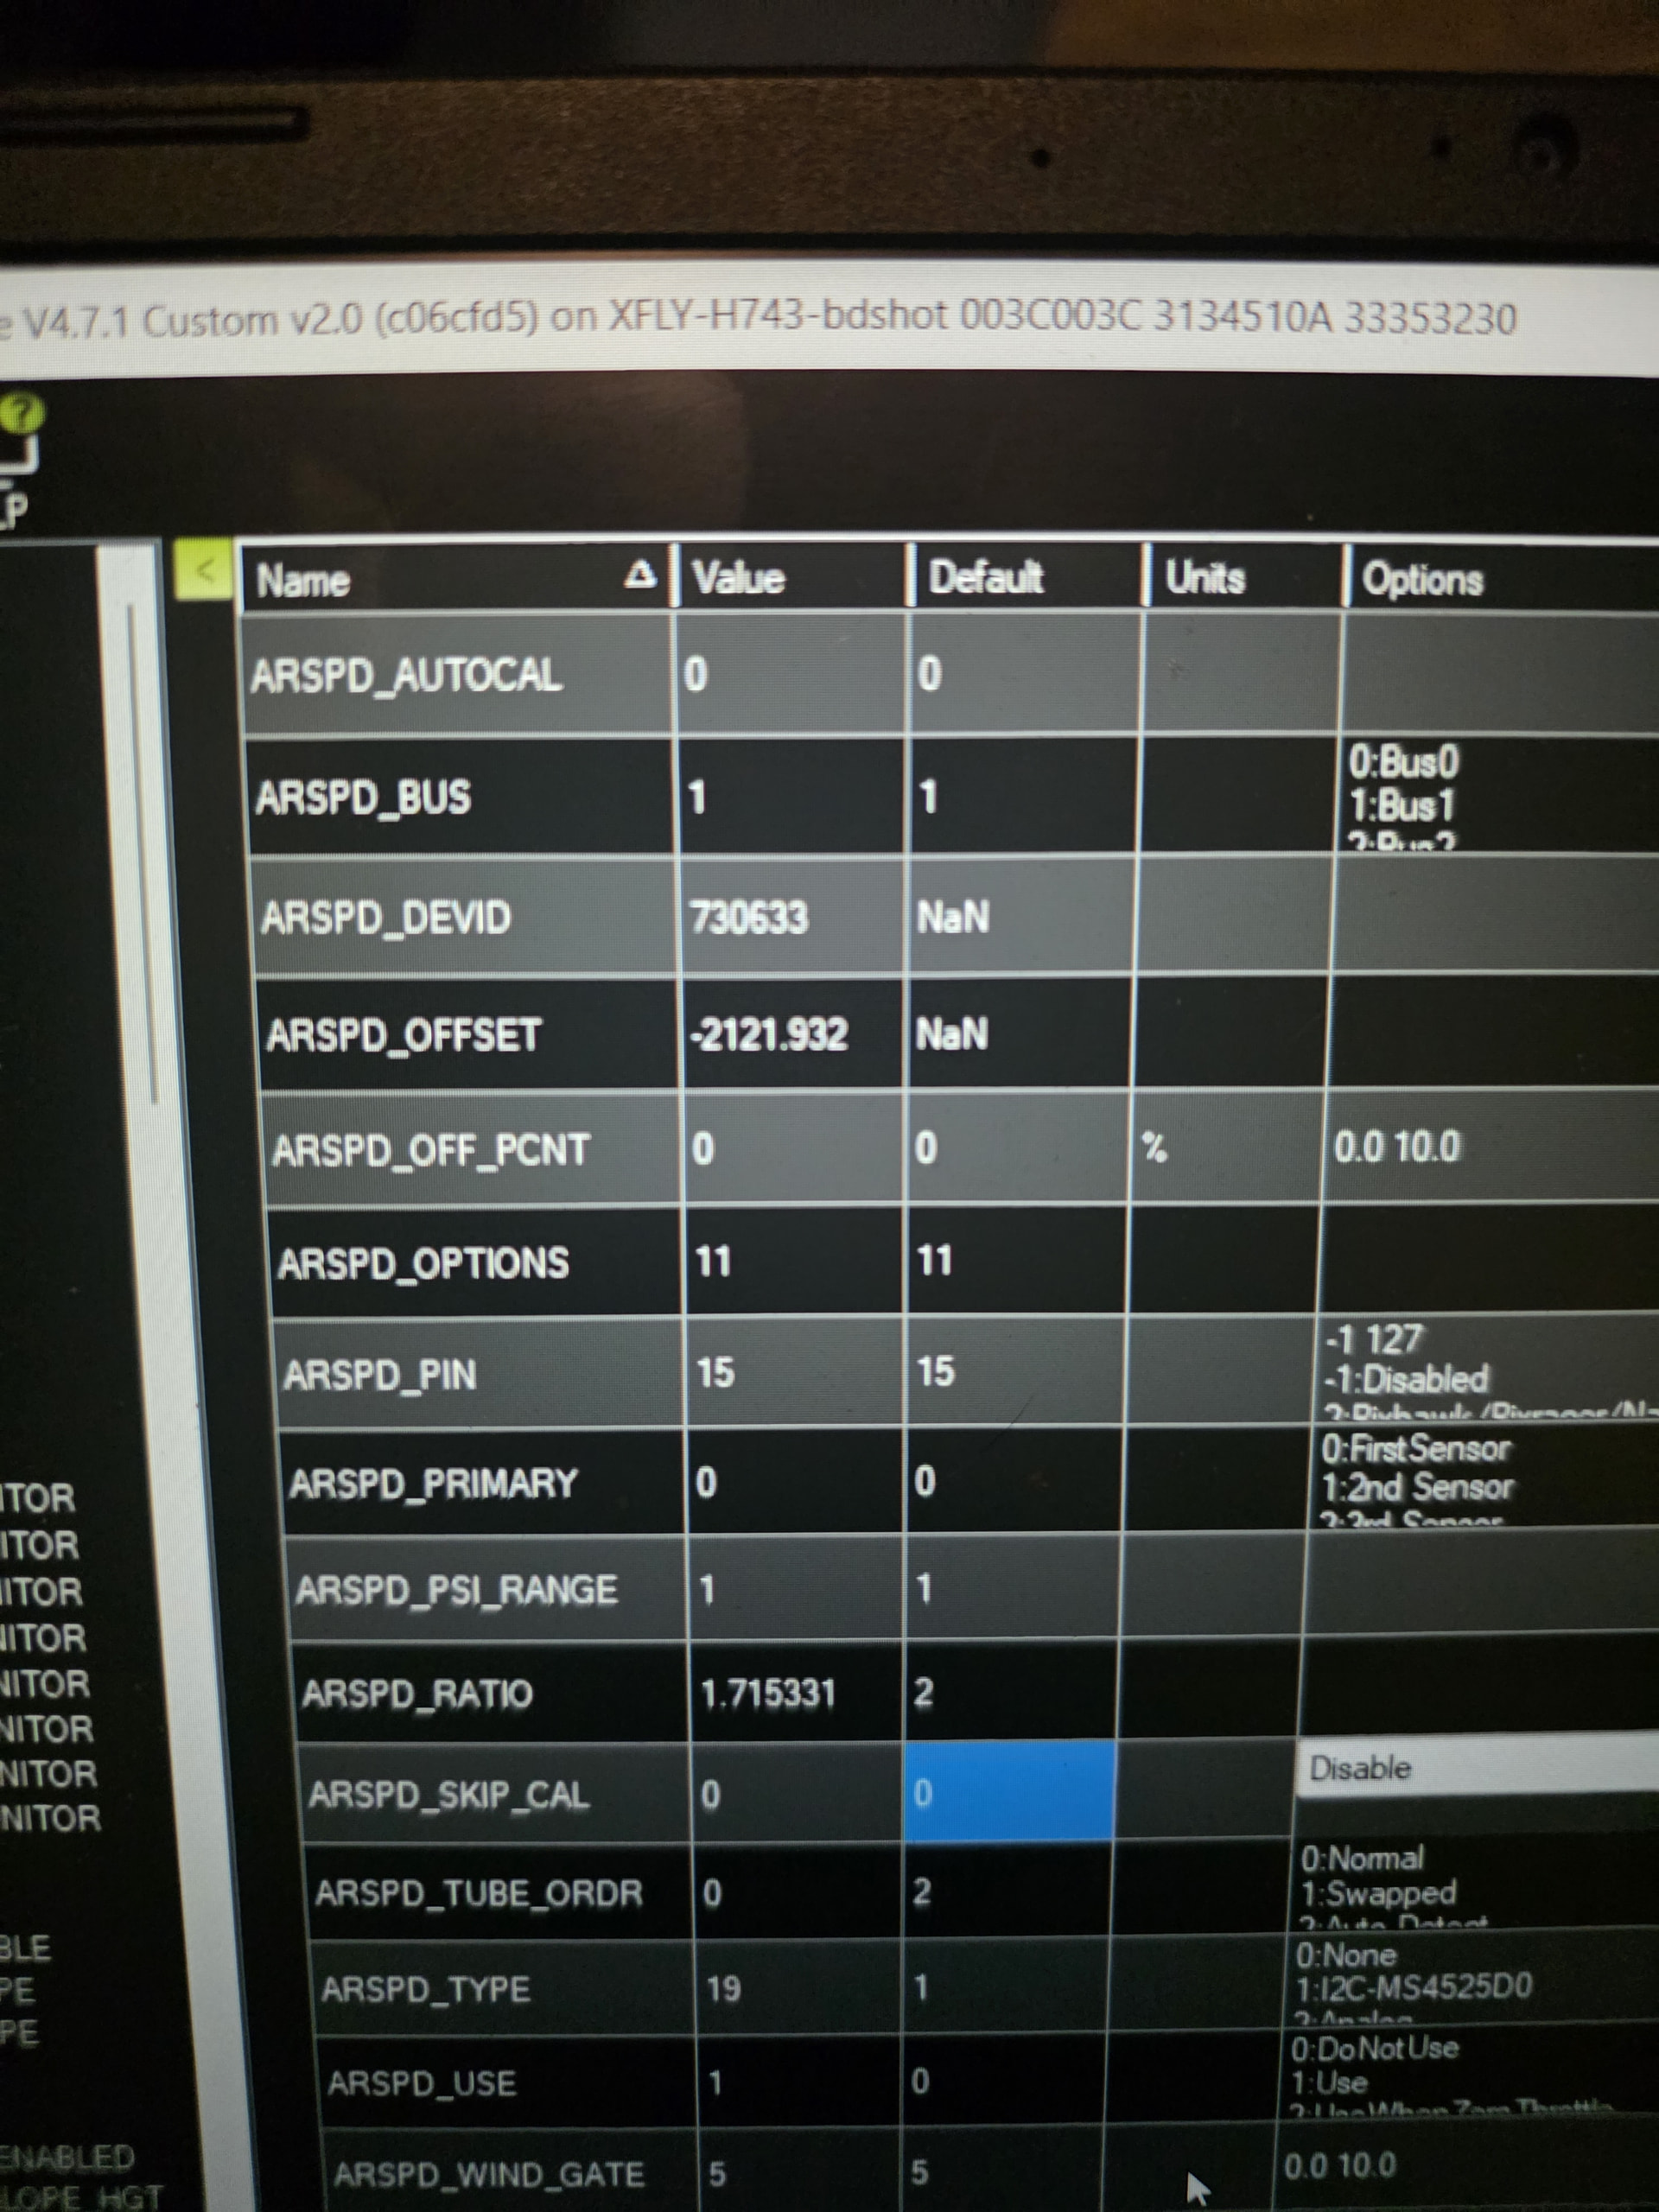
In conclusion, I think the sensor is defective. Your settings look fine.
That’s what I’ve been doing. I’ve had a few flights and the airspeed was fine. I like this sensor better than the dlvr and it’s definitely better than a 4525DO.