Using Pixhawk 6c I have flown many flights with this handmade drone. I use the SKYDROIDG G30 which includes a long range receiver GR03. I use external antennas mounted up on top of an SUV. While testing some spotlights last I flew around my yard for a bit and then upon landing, I hover a bit just to practice doing some tight maneuvering around my SUV and I probably hover it 2 feet for 30 seconds as practice. Upon touching down on asphalt, it would not disarm by pulling the throttle all the way backwards and instead maintained motor thrust in that a strange thing happened it turned over on its left-hand side and balanced on the left hand, landing gear without crashing the left props. It literally stayed on the left-hand landing gear at about a 45 or less degree angle for at least 30 seconds yet did not crash the props until after about 30 seconds finally he touched asphalt but did not flip over. At no time did the props stop turning and it finally settled down and disarmed. During this time that the drone was rolled over to one side so that the left props were almost touching ground. I lost all control with the remote control, and I could not cause to propellers to slow down by pulling backwards. I could not disarm it by doing throttle towards the 7 o’clock position I also have a Killswitch on the remote control that should have instantly disarmed it, but it did not work. I had no control.
ChatGPT says I can upload the.BIN and it can analyze it for me without even having to put it into mission planner. But it is mandatory that I understand what happened here. If anybody can give some suggestions as to what to look for I am not an expert on looking at logs.
Here is the log file. I am just starting to figure out how to analyze it. The issue happened in the last few minutes of flight. On takeoff I did get a warning EKF variance but it flew ok. I have seen this before and have had some bad experiences with trying to land after getting this error but once you take of and get this error, its too late. You have to accept what happens. Maybe it will fly ok and maybe you’re lucky to land it as it fly erratic. I’ve been lucky. This new problem is very different, total loss of control. One note, before flight FLYGCS on the Skydroid g30 wanted to do an update so I did. This was the first flight after the new GCS update on the remote. However, that would not explain this thing balancing on the left landing gear for 30 seconds.
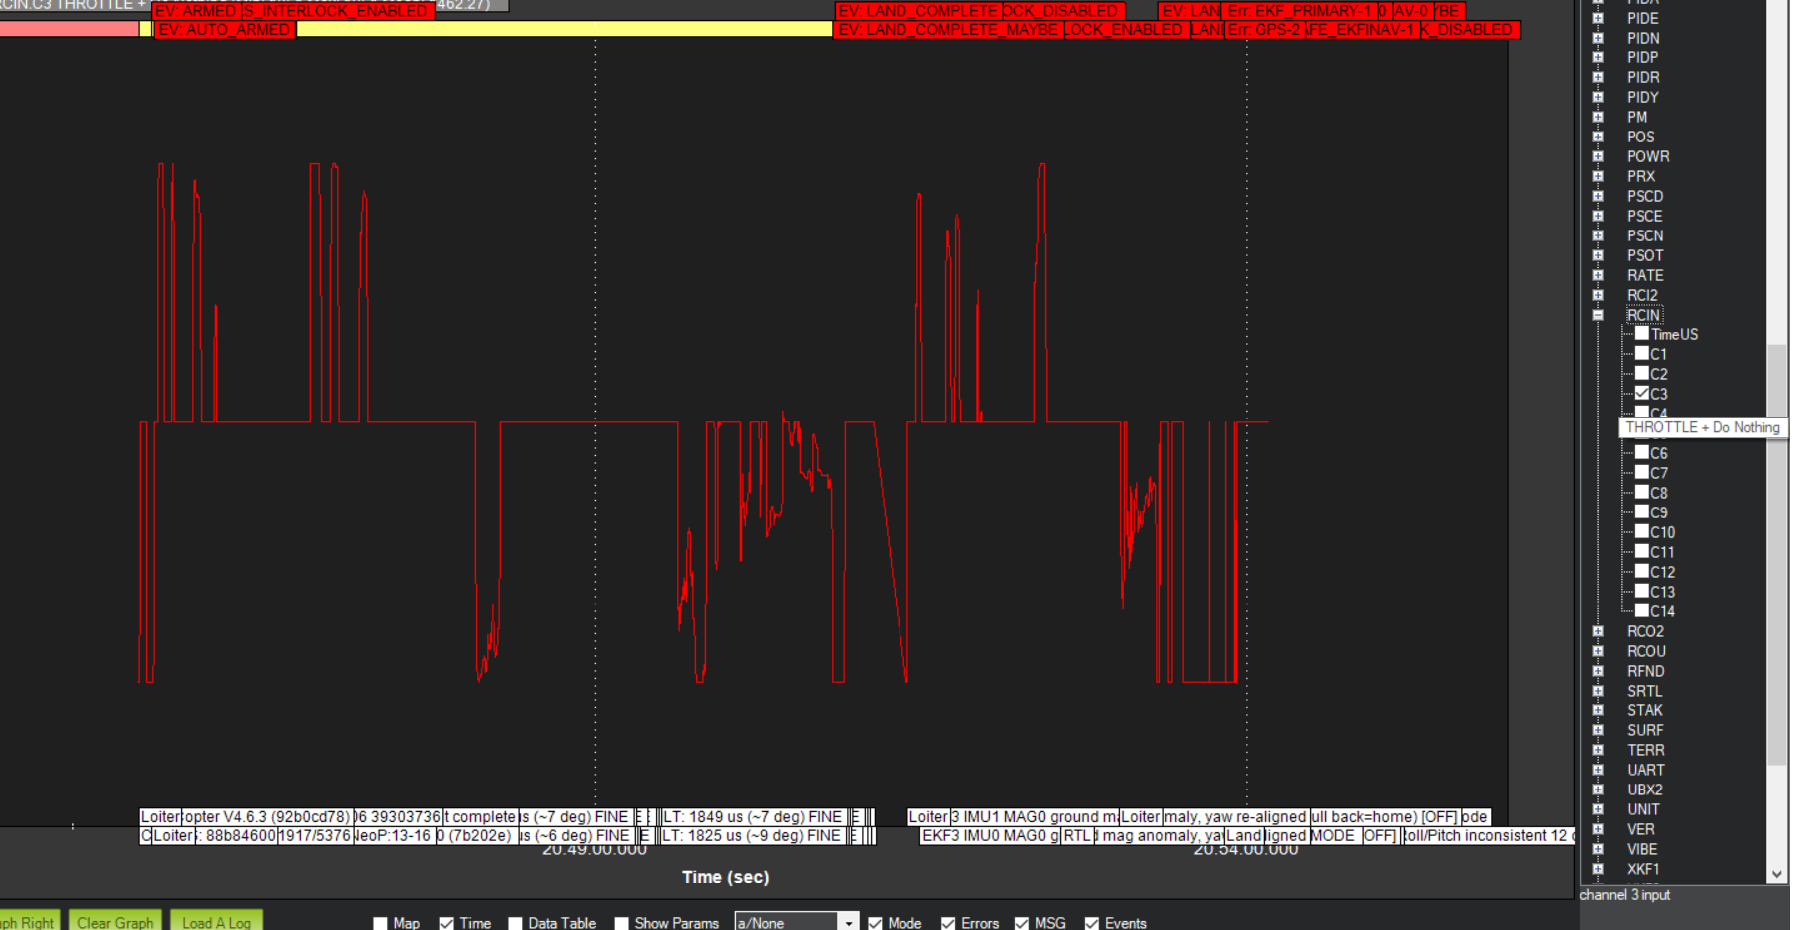
Looking at my controls in Mission planner, I can see that I definitely was trying to command a disarm with throttle channel 3, but the motors would not slow down. I can also see a significant role, but it appears that it says landing complete and landing complete. maybe during this entire time but there’s also EKF IMU0 IMU1MAG ground mag anomalies.
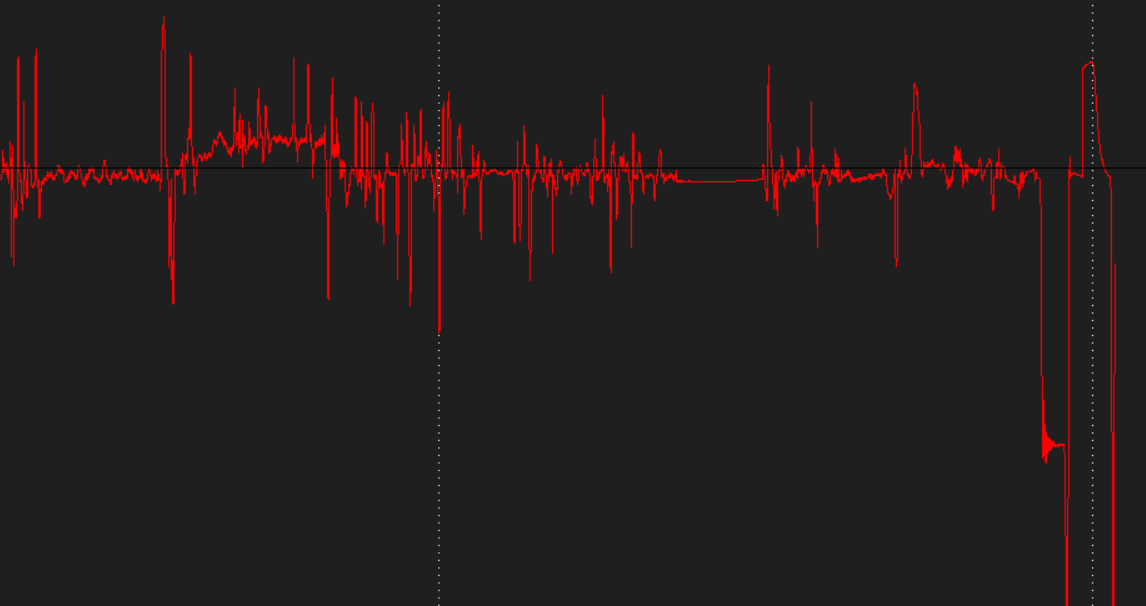
You can see the Roll graph and also see the Throttle control trying to disarm at the end but the speed never dropped to the lowest speed near disarm type speeds.
That appears to have triggered an EKF failsafe / navigation failure response toward LAND.
During/after landing, the aircraft reached roughly −52° roll and the controller continued actively driving opposing motor pairs trying to correct attitude.
The land detector was toggling between LAND_COMPLETE and LAND_COMPLETE_MAYBE, so it was not cleanly recognizing a settled landing.
Mission Planner independently flagged GPS_GLITCH and a major compass-field anomaly.
The remaining unexplained issue was why your manual/Lua emergency-disarm commands did not shut the motors down immediately.
My Shutdown uses the small joysticks Ch13 on left side and Ch15 on the right. Ch13 push hard left and Ch15 push hard right and LUA will Disarm (vs complete shutdown which sometimes can spin the props off). It looks like I have broken my LUA disarm so that might be part of why I couldn’t kill it. Not sure why throttle pulled back didn’t have an effect to shut it down either. Is it possible that auto LAND shut out all external commands?
I do not see this configured on the drone. I would expect one of the RC channels to be either “Motor Emergency Stop” (option 31) or “Motor Interlock” (option 32) to act like a kill switch, but I have seen none of the RC channels to have any of this. Could you please tell us more what you think you have for a kill switch?
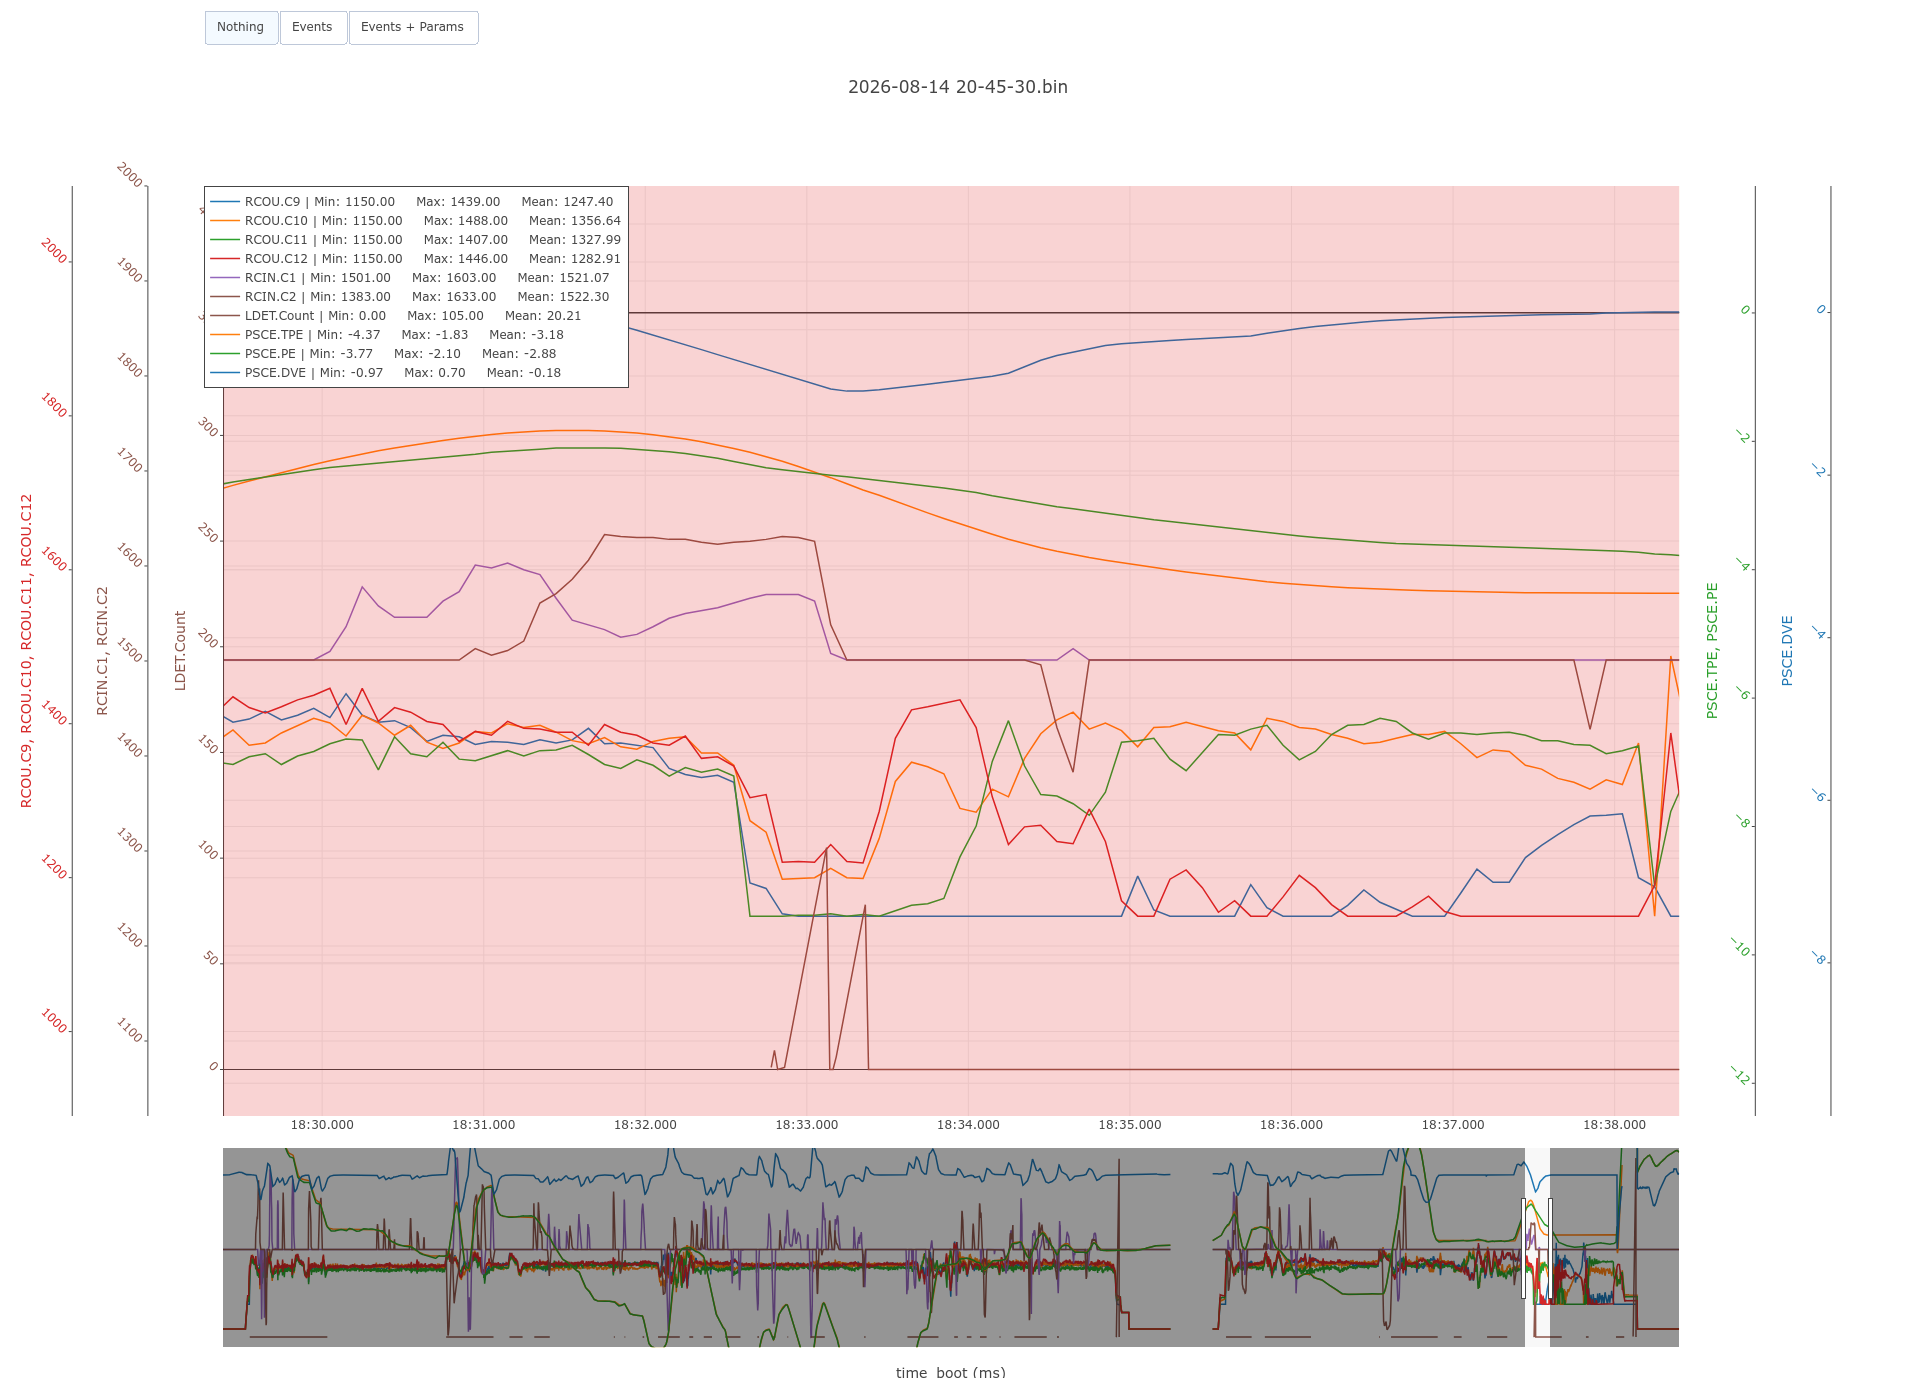
I think that the most probable cause is quite strong action on the pitch/roll stick during the final phase of landing. Here is the relevant portion of the logs:
The brown plot with two peaks at the lower part is the landing detector count. It was only active during that period and has actually reached the state “maybe landed” before the rest of the copter decided otherwise.
The reason it decided otherwise was a growing discrepancy between desired and actual positions (PSCE plots shown), and a quite high desired velocity. That’s why the drone started flying sideways, but at this moment some of its landing legs were already on the ground - so it was kind of standing on the edge. It wanted to fly few meters sideways - because of your earlier quite aggressive actions on pitch and roll sticks.
Switching to LAND immediately removed the desire of flying sideways.
TL;DR: better switch to LAND when you want to land, then repositioning with sticks would do a more correct job.
Re: kill switch. My LUA script had accidentally been removed. I have 2 small joysticks under the larger, so I use a combination on those for Disarm in LUA that works perfect, unitl you accidentally delete the file off the drone.
I usually take off and land in Loiter. My driveway is always slow for GPS with trees all around so it takes a while and only arms at 1.2. I have noticed a few times on take off an EKF variance and it flies erratic but I can get it back down. Last night was one of those that was uploaded today. I tried to take off today from the same spot in ALTHOLD and on take off immediately got the EKF variance again. This is a hand made drone and I have no prior experience but have flown at least 25 hours. As I said I have seen EKF variance a few times and it goes away. I am thinking this is a motor current issue on take off creating noise. I need to understand how to mitigate noise getting on the PIXhawk6c from motor cables running along each side.
Here is the latest file which is very short and only shows the error EKF.
Any thoughts on whether motor RPM/Current might be the real problem on compass or EKF issues here?
Yes, it was an EKF failsafe. Error messages are not very easy to see in the tool I am using.
For your EKF-related problems I need some more time, I guess. (Right now, the universe is punishing me for being overconfident in my handing of composite materials)
One assumption I had is is that on takeoff increase in motor current could be adding noise up to the M 10 compass, which is the only Compass and GPS that I’m using. And last night when I took off, I had the EKF variance on takeoff and then when landing had the same error when getting close to the ground. So this would not seem to correlate to motor current and that once it is up and flying. I don’t get the EKF again. It’s more noticed when you takeoff. The same today when I did a TestFlight and takeoff I had variance and the YAW correction but landing was fine.
Well, I would say I don’t see anything that is way too serious with EKF.
The “ground mag anomaly” around the lift-off is almost normal. It may be a true compass measurement deviation, or interference from motors (in which case, compass motor calibration may help), but only influences the very beginning of the flight. A truly high interference from the motors usually manifests differently, e.g. yaw misbehaves every time throttle changes. What you likely experience is an intermittent yaw instability just as you lift off. A typical signature would be yawing left-right a couple of times at some maybe 5-10 degrees, then converging. The easiest way is to avoid rushing sideways as you lift off, like give it some 5-10 seconds to settle down - then the rest of the flight should be OK.
Or just be prepared. This is what I do with my 5" quad which in particular has no place for a compass to work reliably, so I chose to use the GSF filter (by simply disabling the compass). This has to re-converge on where the north is in the first 20-ish seconds of the flight, so I’m vigilant at lift-off (which amounts to punching it up and away from myself) and am making minor corrections when it’s flying but the direction drifts a bit.
The EKF error that triggered a LAND switch in the standing-on-the-edge flight was most likely triggered by insane (VIBE up to 50 on the first IMU and up to 100 on the second one) vibrations, which happened when roll reached really high values - so I suspect propellers touching the ground. In these conditions with such vibrations, one cannot expect the machine to behave well, it’s an emergency - so, getting back to potential EKF problems, this is not an indication of any problems.
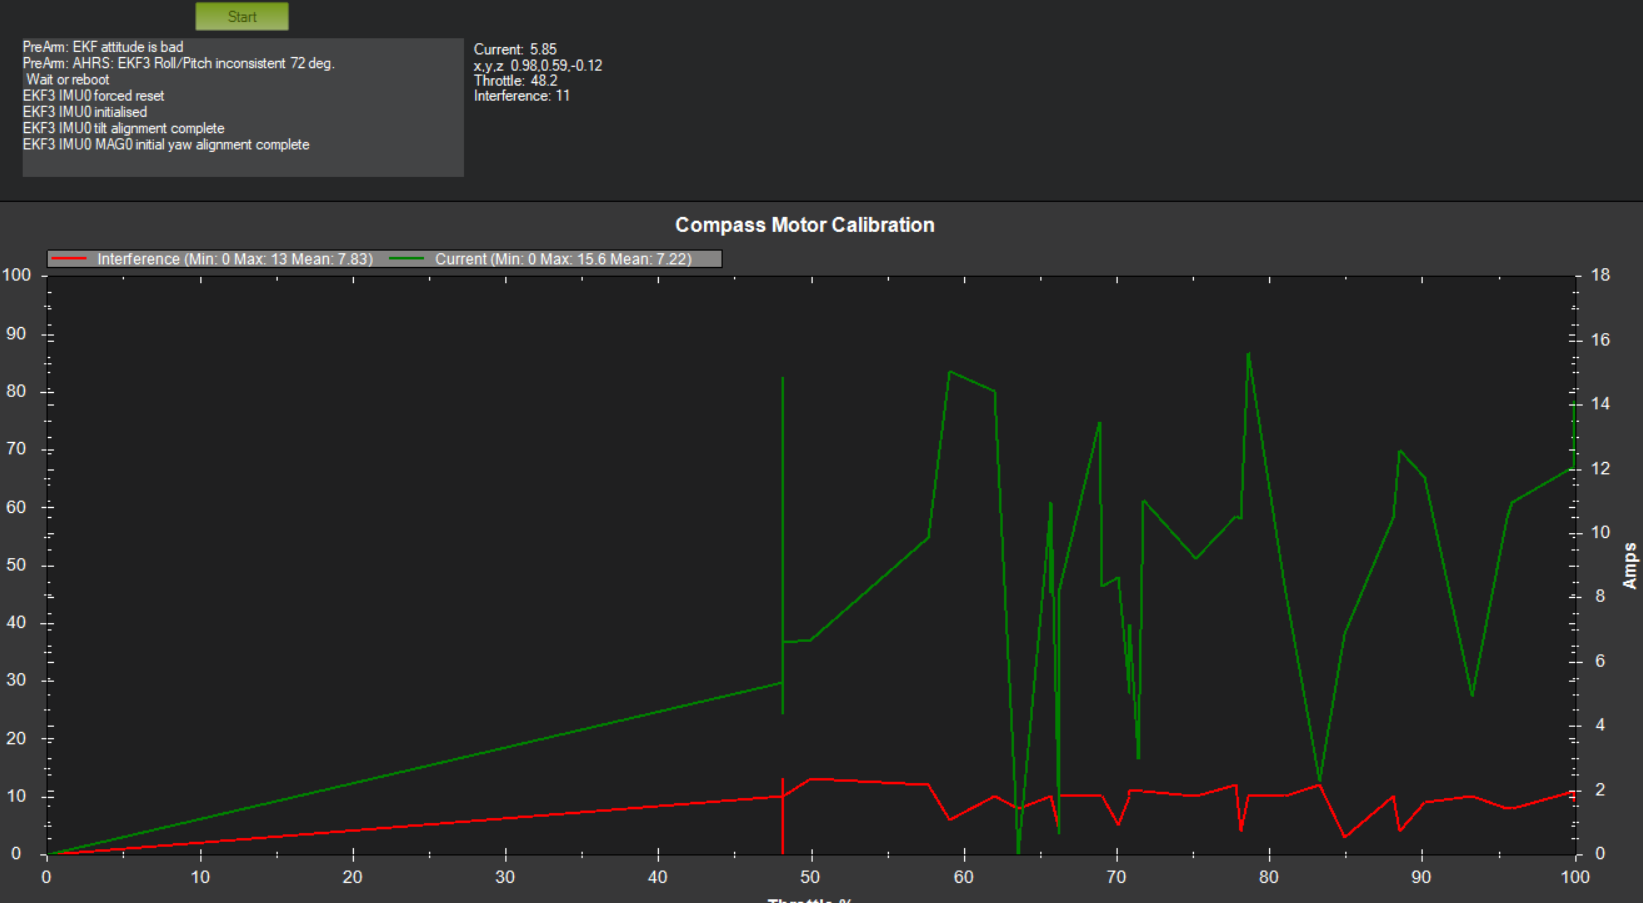
So either your launch location has something magnetic in the ground, or there is some mild motor interference. The latter can be mitigated by the compassmot procedure (ArduPilot’s manual is pretty detailed on that).
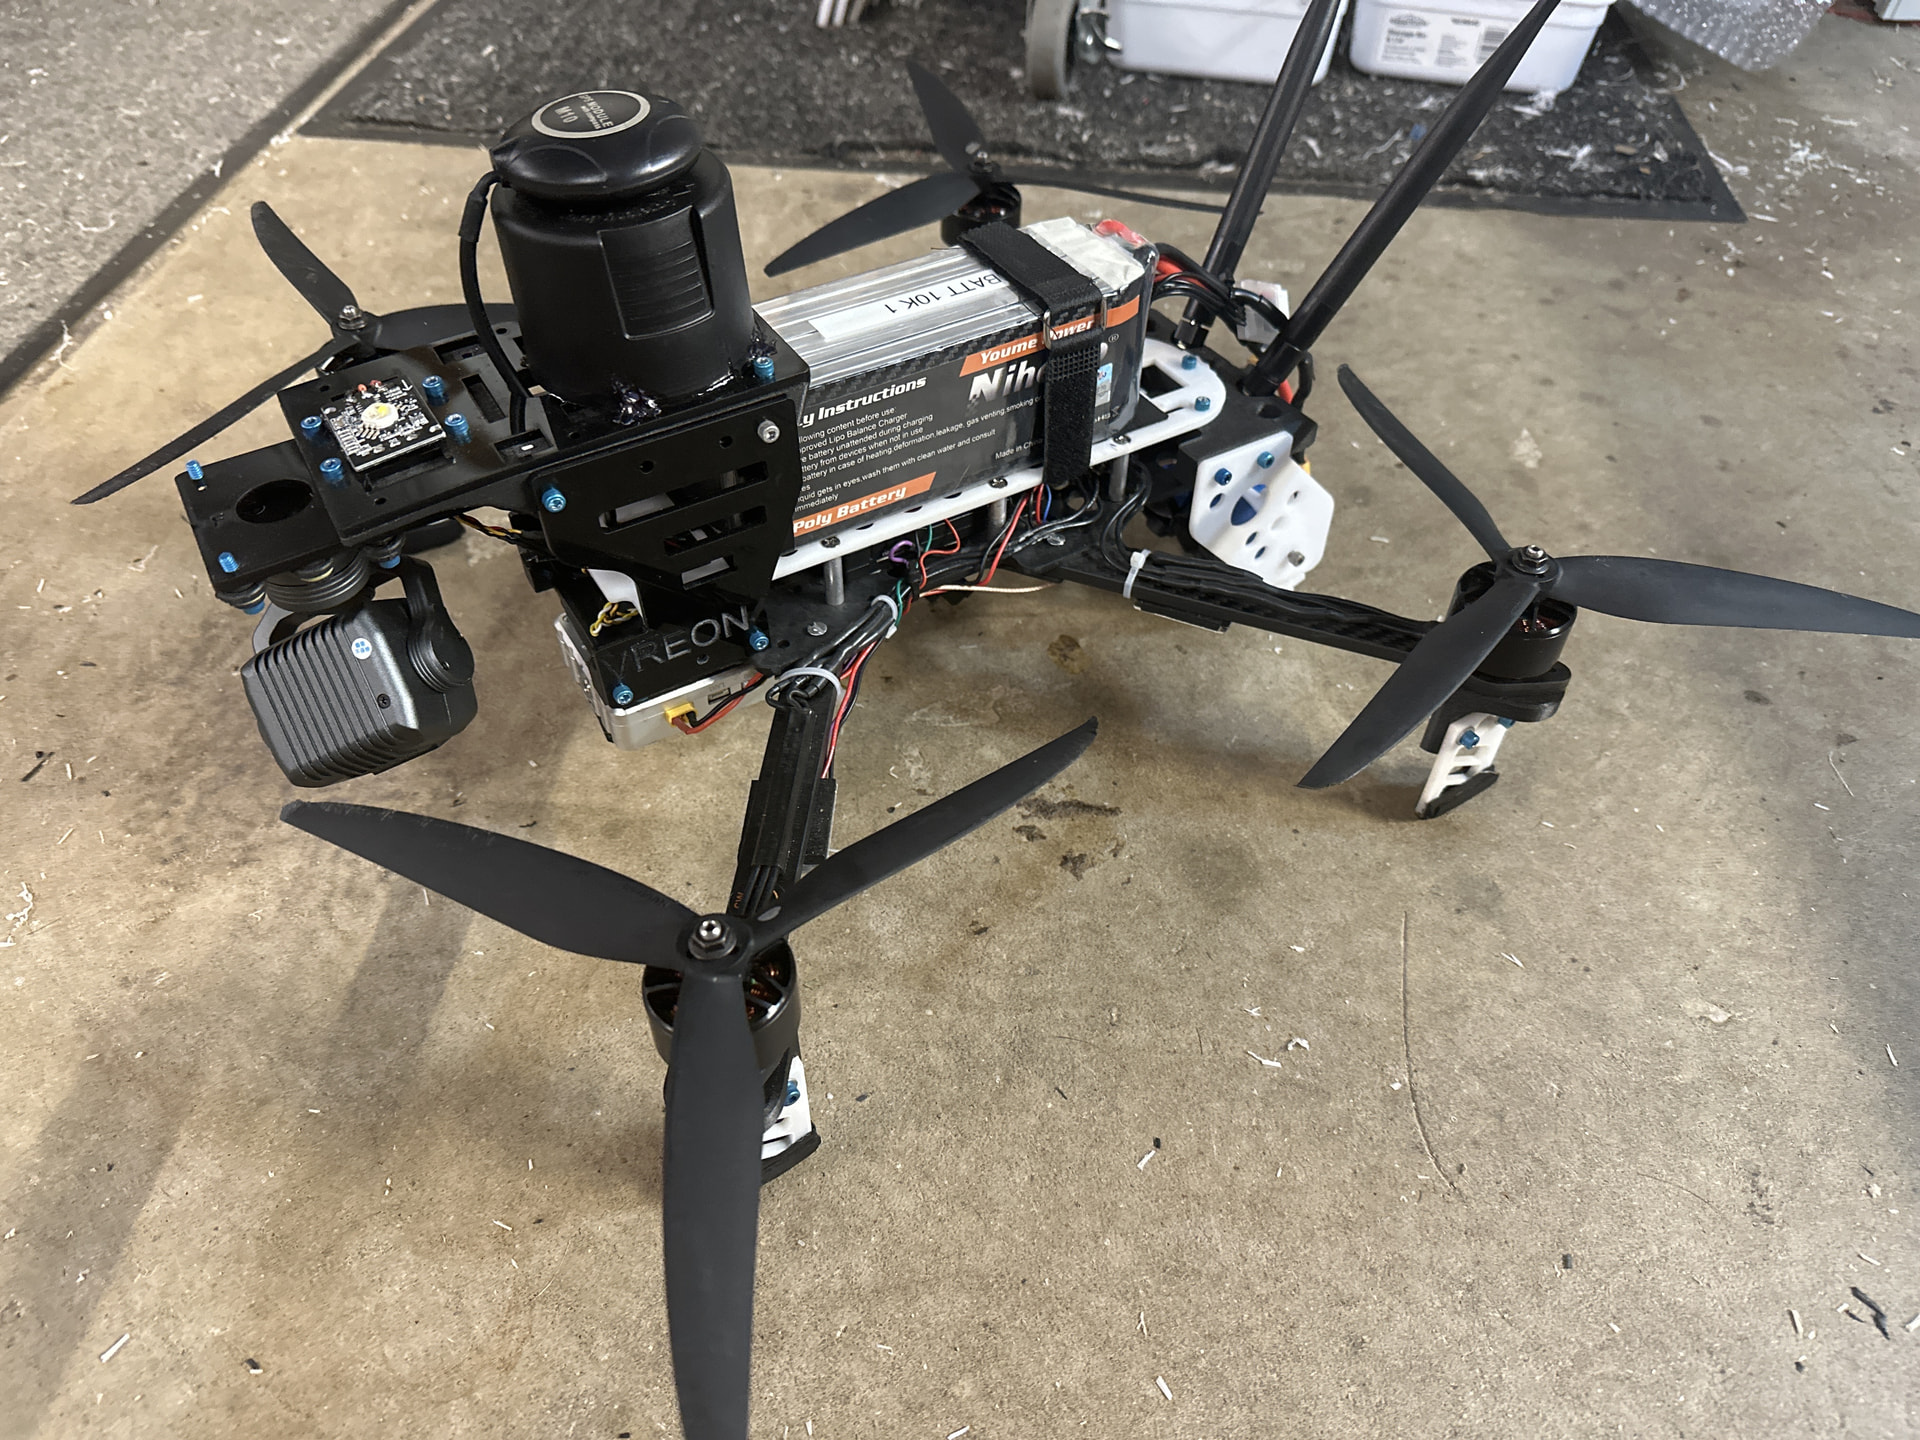
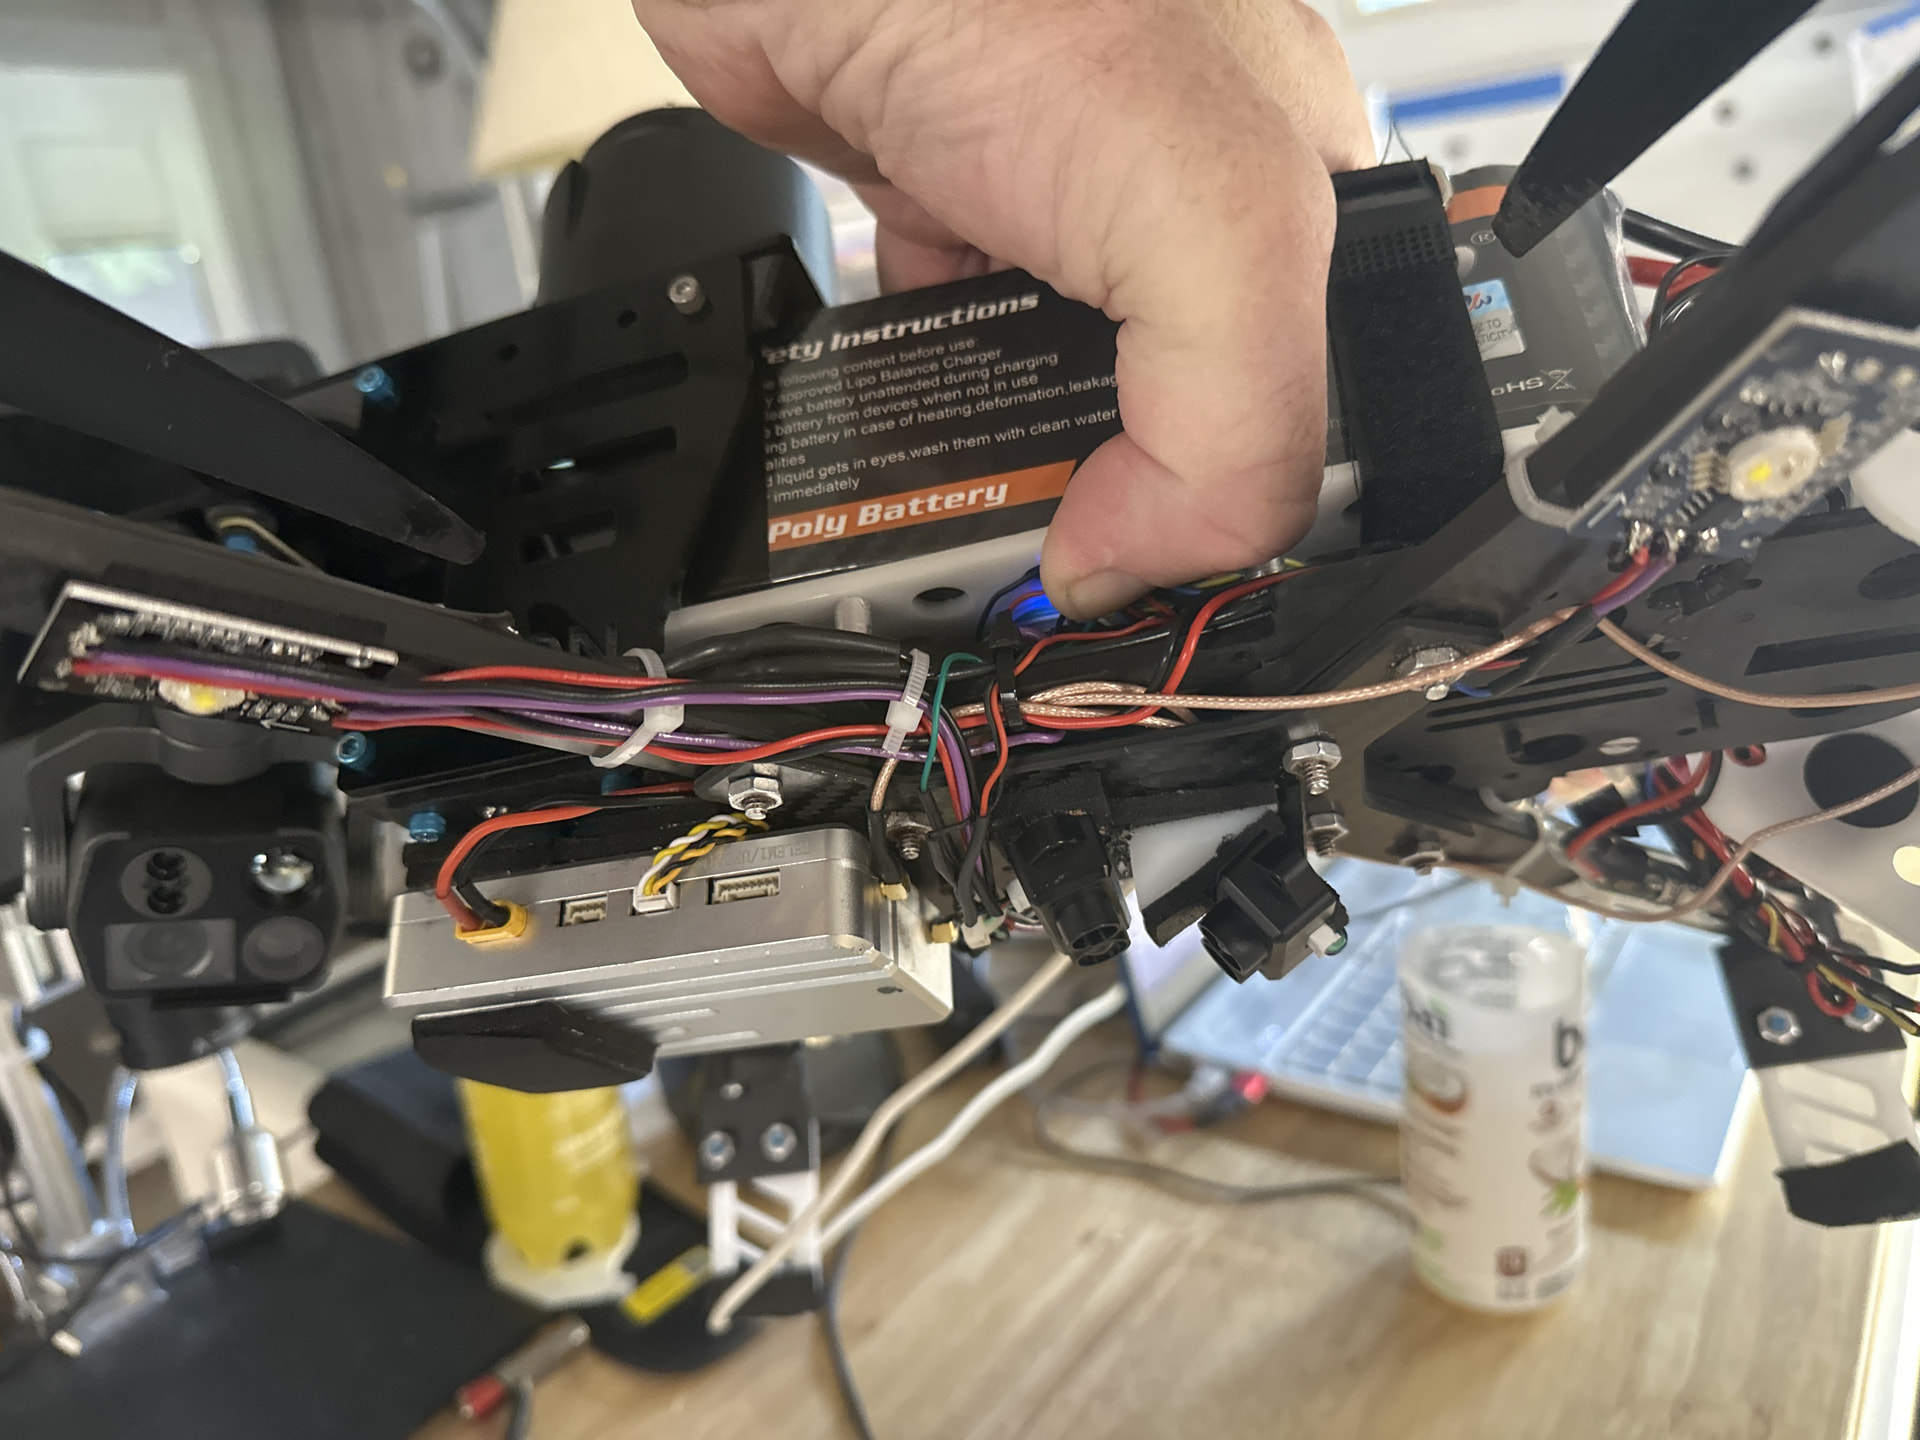
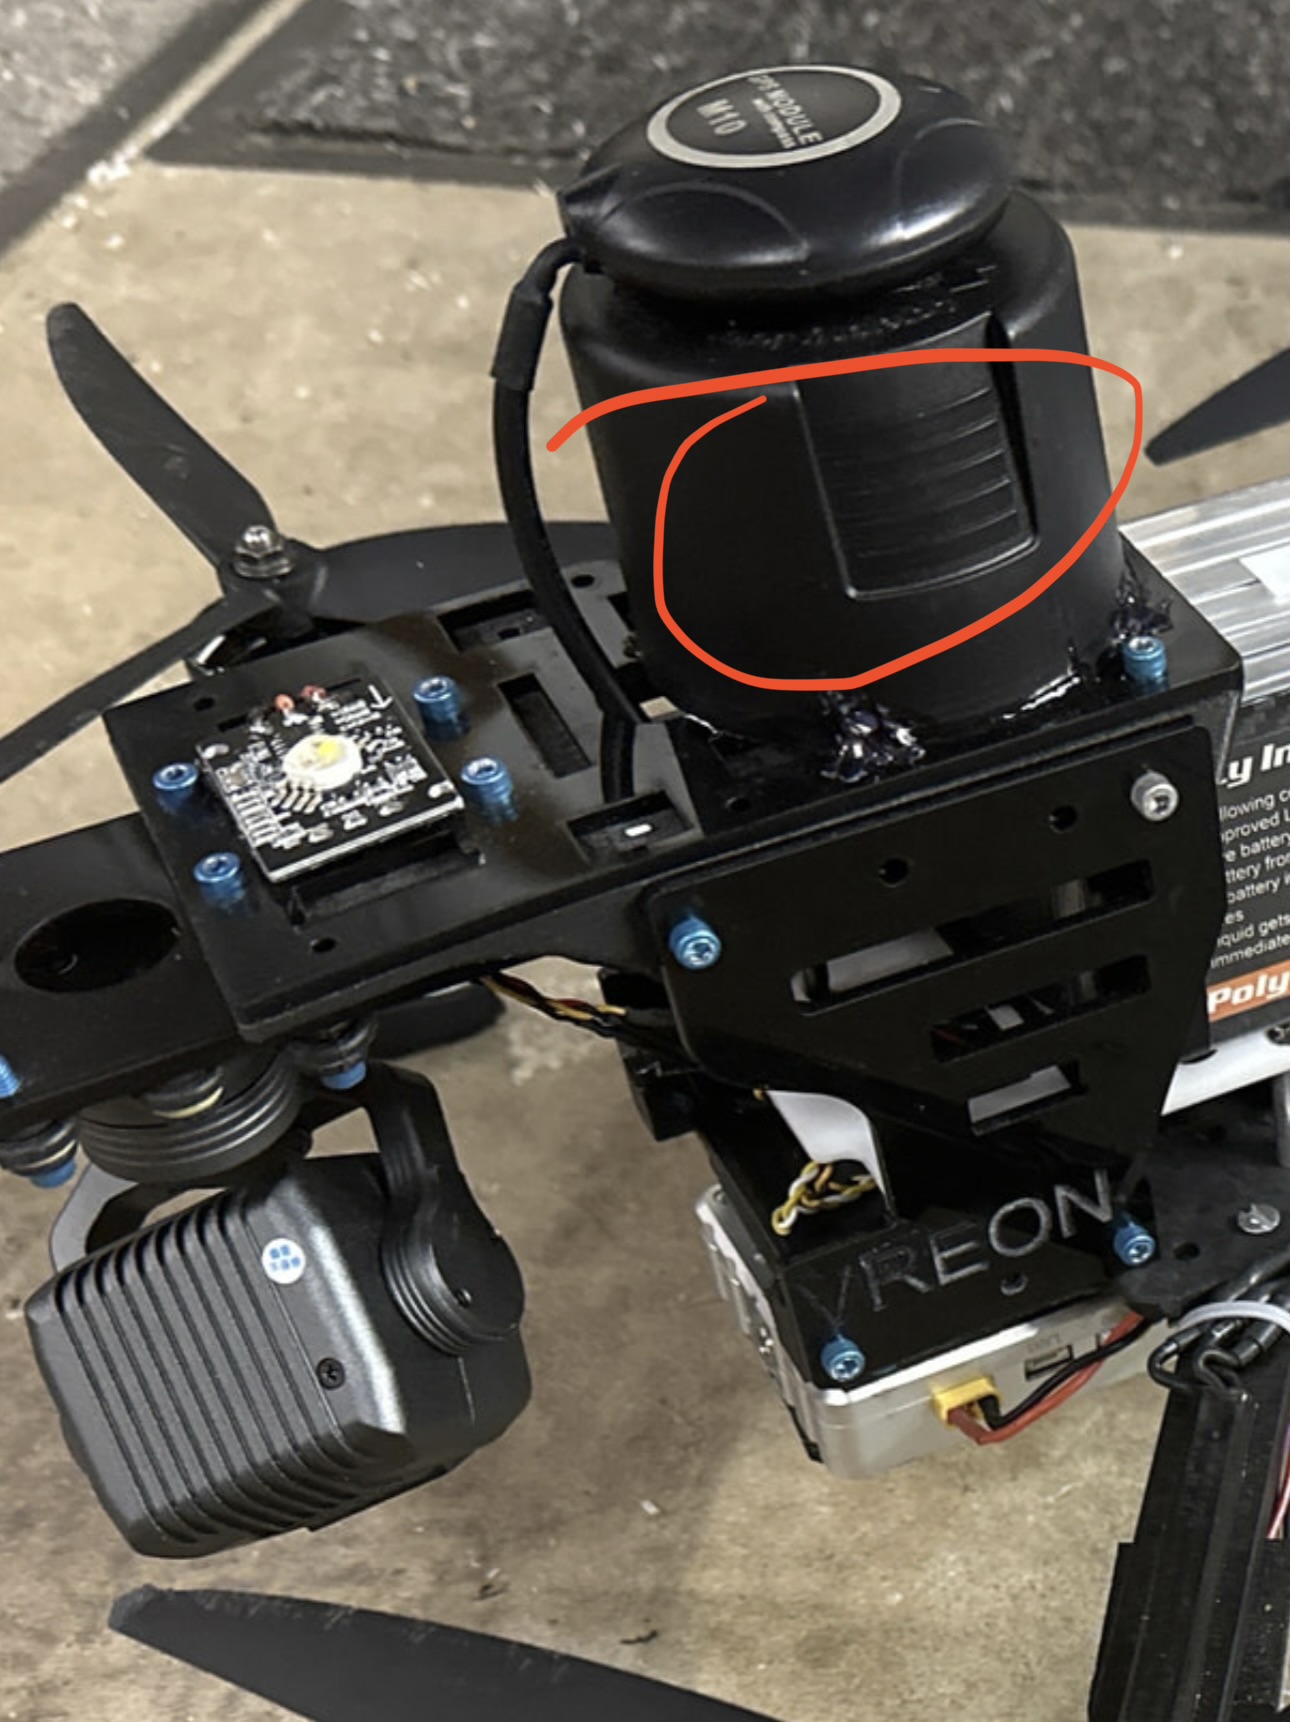
For the source of magnetic inference, based on your photos, I don’t really think that motors or other power wires have a lot of influence. However, I would consider checking your proximity sensor (am I right that the cylinder below the GPS module is a proximity sensor?) for being a potential source. I have no idea what it is, but some contain a rotating sensor head, which is then obviously driven by a motor, which may turn on when the vehicle is armed. If so, it may explain what you see.
Thanks very much for all of the detailed analysis. I only get the YAW on the rare occasion that I do get EKF variance on takeoff in which case yes there’s a YAW affect but during normal flight, I never see the YAW as you described. I’m not aware of any steel or magnetic material in the ground under the asphalt in my driveway during most testing. I’ve seen this happen at other locations at a Concrete driveway, which certainly could’ve had Rebar in it. Not sure if it was magnetized.
I will attempt to do the compass motor calibration tomorrow. One thing to know is is I use the PM 06 and a TEKKO 32F4 and there’s no elegant way to get the total combined current. You have to get the motor current and read it off of the TEKKO current output or you have to take the current off of the PM 06 which is driving camera, gimbal, rear spotlights, several PEC. Right now I’m taking current off of the PM 06 but tomorrow I’m going to switch that to the TEKKO. So I can use the current on the Compass motor calibration instead of throttle. I would love to find a setting or calibration that would solve this problem. I built this drone for search and rescue for pets and it has a 640 thermal, 48 MP daylight camera, laser rangefinder, and rear spotlights with tilt motor.
I got my disarm back working again, so I’ll be able to mitigate this experience in the future I had deleted the file. The very front device is a camera with gimbal, which yes has three motors in it. I have TF mini on the bottom, actually two of them went straight down and one Forward aimed down slightly.
I learned how to do CompassMot today, I tested without props just to see how to do it. I’ll need to rig up a system for prop method. I put friction on some motors to simulate load. After each test it shows some errors but if I run the motors from the remote control, disarm, repeat I do not get EKF. Chatgpt says because I can run the motors and stress them using TestMotor and using remote control without EKF errors on the bench that it is likely those errors are coming from something related to the Compass Mot calibration
However testing on my asphault driveway I get the same EKF variance on take off, slight yaw left, then it stabilizes but its eratic for the first 5-8 feet. Landing was fine. AltHold tests.
I tested on grass with a 24"x24" paver as a base, got the same EKF. Landed fine. GPS is always bad near ground being surrounded by trees.
What about getting a card table for takeoff to avoid eratic takeoffs, landings are not usually a problem. The previous posts showing lots of vibrations is usually landings on asphault where touch down produces oscillation and bouncing. Rubber pads wear off easy. I need a better method to cushion landings that don’t wear off.
Where I’m getting the ground anomaly I’ve taken off probably a few hundred times before and now I’m experimenting by moving at 10 feet in either direction. I did takeoff on some grass about 10 feet away from the asphalt yesterday and did not get an error which makes this very sporadic and intermittent.