LiteGCS_v8.2.8 - Lightweight GCS for flying fied, very handy and runs on PC & Raspberry Pi 3B+ & above.
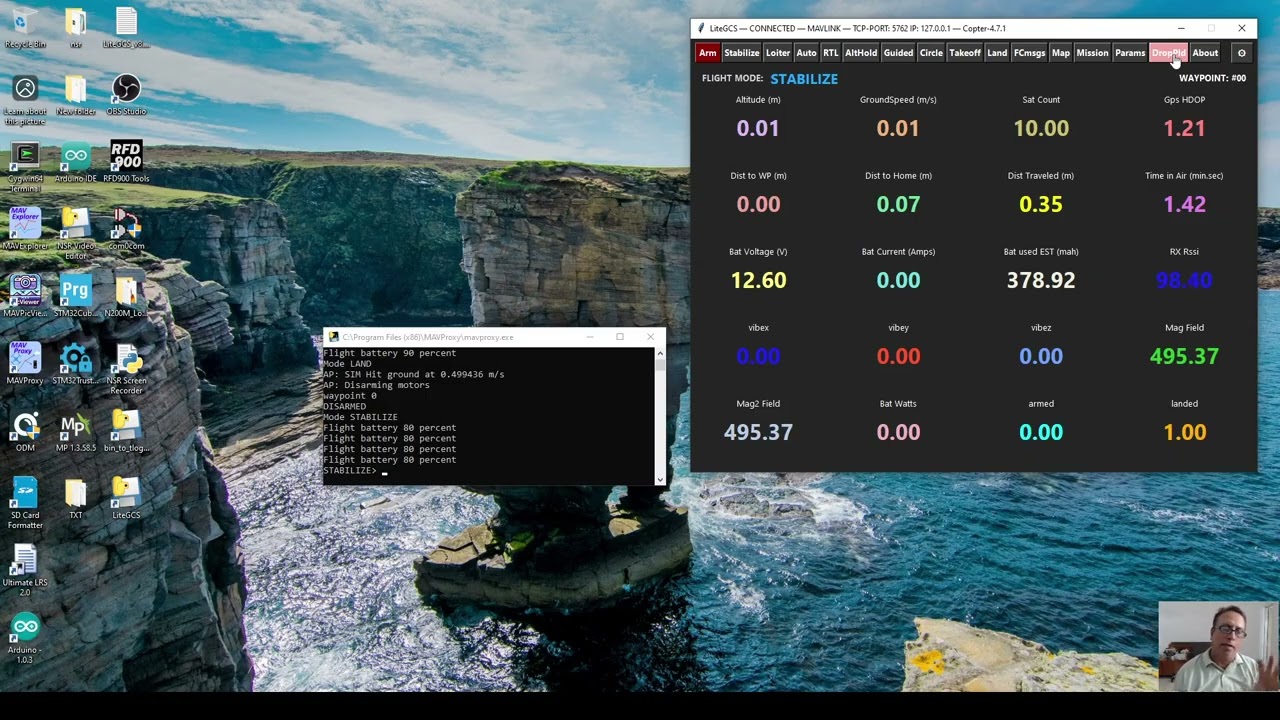
While in the flying field, I always dreamed of a lightweight GCS which have all the important buttons and important telemetry data on one panel infront of me, so I created one !
It has most of the good features I dreamed about. It can even run on Pi Zero 2W, Raspberry Pi 3B+ and above. In this case, I requires HDMI monitor, Keyboard, Mouse, Telemetry Radio, 5V, 3Amp source.
Let me make it clear, it’s not the competetor of Mission Panner or QGC nor it can compete, it’s just simple handy, lightweight GCS for flying Field.
This is LiteGCS ver 8.2.8, an upgraded version with some more added features and functionality.
Connectivity:
You have options to connect LiteGCS to the drone over Serial Port or UDP Port or TCP Port.
Streaming MAVLink Telemetry:
It can stream MAVLink Telemetry on UDP port, TCP Port.
Notice Write checkbox that means if checked, the machine connecting on that port will have read and write access to control the drone else viewing only.
Parameters / Mission Download Option at Startup:
You have option to choose if you want to download parameters, mission on startup, there are more than 1300 parameters, and if you have several hundered mission waypoints then some times you may wish either of the two not to opt.
PC Keyboard Arro Keys to Re-Position the Coter as an Option:
Some time specially at time when your ground station is on the roof of the house, you need to reposition the drone when landing (if it’s not precision landing) with your rc transmitter.
I have given option to reposition the drone using your keboard’s arrow keys.
up-down arrow keys are pitch while left-right arrow keys are roll. you can reverse either of the two or both if required.
I was required to reverse pitch.
Settings:
If you do any change in the configuration and save it then you need to restart LiteGCS.
PayLoad Configuration:
If Payload alredy configured then LiteGCS will display button either “DropPld” in light red color or “HoldPld” button in light green color.
If you wish to change the Payload configuration port then click and hold for more than 3 seconds on this button, configuration window will open
You can select either of the 6 Auxilary outputs from 1-6. Aux1 is ch9 out or Servo9.
You have even option to choose PWM value for your servo for Holding the Payload and Dropping the Payload.
You can choose even pwm value as per your requirement.
Copter’s Behaviour in GPS Fail Condition:
I have also modified Ardupilot’s Copter-4.7.1-Beta1 as per my requirement.
I have observed in SITL in stock firmware Copter-4.7.1-Beta1 that if Copter is way back to home on RTL and GPS fail then efter the DR period is
over, it will land there even if GPS is restored. I modified the firmware. Now in RTL the Copter will resume its journey back home after GPS is restored in RTL mode.
Testing SOP with SITL on Windows10-64Bit:
Pre-requisite:
It is assumed that cygwin is installed, and in your Home directory of cygwin, you have cloned github repo related to Ardupilot Copter-4.7.1-Beta1.
It is assumed that you are able to compile sitl with following commands;
Open cygwin console
cd ardupilot
./waf configure --board sitl
./waf copter
It is assumed you are able to run sitl with following commands inside ardupilot of cygwin console;
Open cygwin console
cd ardupilot
Tools/autotest/sim_vehicle.py -v ArduCopter -L Khelan --add-param-file=Tools/autotest/default_params/copter.parm
or
Tools/autotest/sim_vehicle.py -v ArduCopter -L 0.3734094508579, 76.909746453166, 286.0, 115.0 --add-param-file=Tools/autotest/default_params/copter.parm
It is assumed that mavproxy is starting ok and you are able to connect the mission planner on udp port 14550, tcp: 127.0.0.1:5762, tcp: 127.0.0.1:5763 ports.
It is assumed that Python 3.12.10 (Exact file name: python-3.12.10-amd64.exe) is installed outside cygwin.
SOP:
-
Run sitl at your desired map location inside cygwin
-
After mavproxy starts fully then launch LiteGCS_v8.2.6.exe
LiteGCS will launch in few seconds.
Press Settings button ( Extreme right on LiteGCS )
Select TCP port 127.0.0.1:5762 for connectivity with SITL.
Under PC Keyboard Flight control, check the box “Use PC arrow keys as RC sticks”
You may or may not required to check boxes “Reverse Pitch”, “Reverse Roll”
Press save button, you will be required to close the LiteGCS and re-launch it.After re-launch, LiteGCS will quickly connect with SITL on TCP-5762.
-
Wait for some time as even in SITL, it takes some time to 3D Lock GPS.
Press Guided Button, press Arm butto then quickly press Takeoff button and quickly type any altitude value like 5 ot 9 or 33 and press enter from your keyboard.
Copter will takeoff to your the desired altitude you entered.
Now, raise throttle to 50% with following command in mavproxy black window that displays the current flight mode like “GUIDED>”
Type exact content in quotes “rc 3 1500” and press enter. -
PC keyboard control test:
Press Loiter button, flight mode will change to LOITERCheck if you are required to reverse pitch or roll or both;
Press up arro key repetedly, copter should fly forward (towards it’s head or nose), if it’s flying backward (towards it,s tail),
then you need to check the box “Reverse Pitch” in Settings window.Noe press left arrow key repetedly and the copter should fly side ways towards it’s left, if it is flying towards it’s right side,
then you need to check the box “Reverse Roll” in Settings window.It is assumed that if you were required to reverse any or both of Pitch, Roll, you have done the change in Settings and saved it and re-launched LiteGCS
-
Configure required Parameters;
RC8 (Disable GPS):
Press button “Params”, it will open Parameters window, You may required to press button “Fetch from FC”
In search box (top right side) type “RC8_”, you will have all parameter relared to RC8 in front of you, set as follows and save by pressing “Upload Selected”;
RC8_MAX: 2000
RC8_MIN: 1000
RC8_OPTION: 65
RC8_TRIM: 1000RC7 (Activate Supper Simple Flying Mode Globaly):
Now in search box type “RC7_”, you will have all parameter relared to RC7 in front of you, set as follows and save by pressing “Upload Selected”;
RC7_MAX: 2000
RC7_MIN: 1000
RC7_OPTION: 13
RC7_TRIM: 1000RC9 (AUXILARY OUTPUT 1 OR SERVO9) for payload hold or drop:
Now in search box type “RC9_”, you will have all parameter relared to RC9 in front of you, set as follows and save by pressing “Upload Selected”;
RC9_MAX: 2000
RC9_MIN: 1000
RC9_OPTION: 19
RC9_TRIM: 1000Wind Direction and Speed setting:
Now in search box type “SIM_WIND_”, you will have all parameter relared to SIM_WIND in front of you, set as follows and save by pressing “Upload Selected”;
SIM_WIND_DIR: 270 (West to East flowing wind)
SIM_WIND_SPD: 2 (2 meters per second, is light wind) -
Testing Drop Payload:
See, if you can see button with exact text inside “Payload”, if yes then click on it but if it is displaying light red button “DropPld” or light green button
“HoldPld” then continuously press this button for more than 3 secons till the Payload configuration window opens in front of you.
Here in this window, you can select any of the six Aux1-6, you can select desired pwm value dor Hold Payload and Drop Payload.
Do change if required, press Save button, close LiteGCS and re-launch.Drop Payload Testing:
Focus on mavproxy black window which displays flight mode like STABILIZE>
Type exact command in the quotes “status SERVO_OUTPUT_RAW” and press enter
It will display all servos status, look for “servo9_raw”, most likely you will see its value 1100Now press light red button “DropPld”
Now again focus on mavproxy black window and type same command as earlier “status SERVO_OUTPUT_RAW”, and press enter.
It will display all servos status again, look for “servo9_raw”, you will see its value 1900, this denotes payload has been dropped,
and now the button color will change to light green and button name will be “HoldPld”
It’s not going