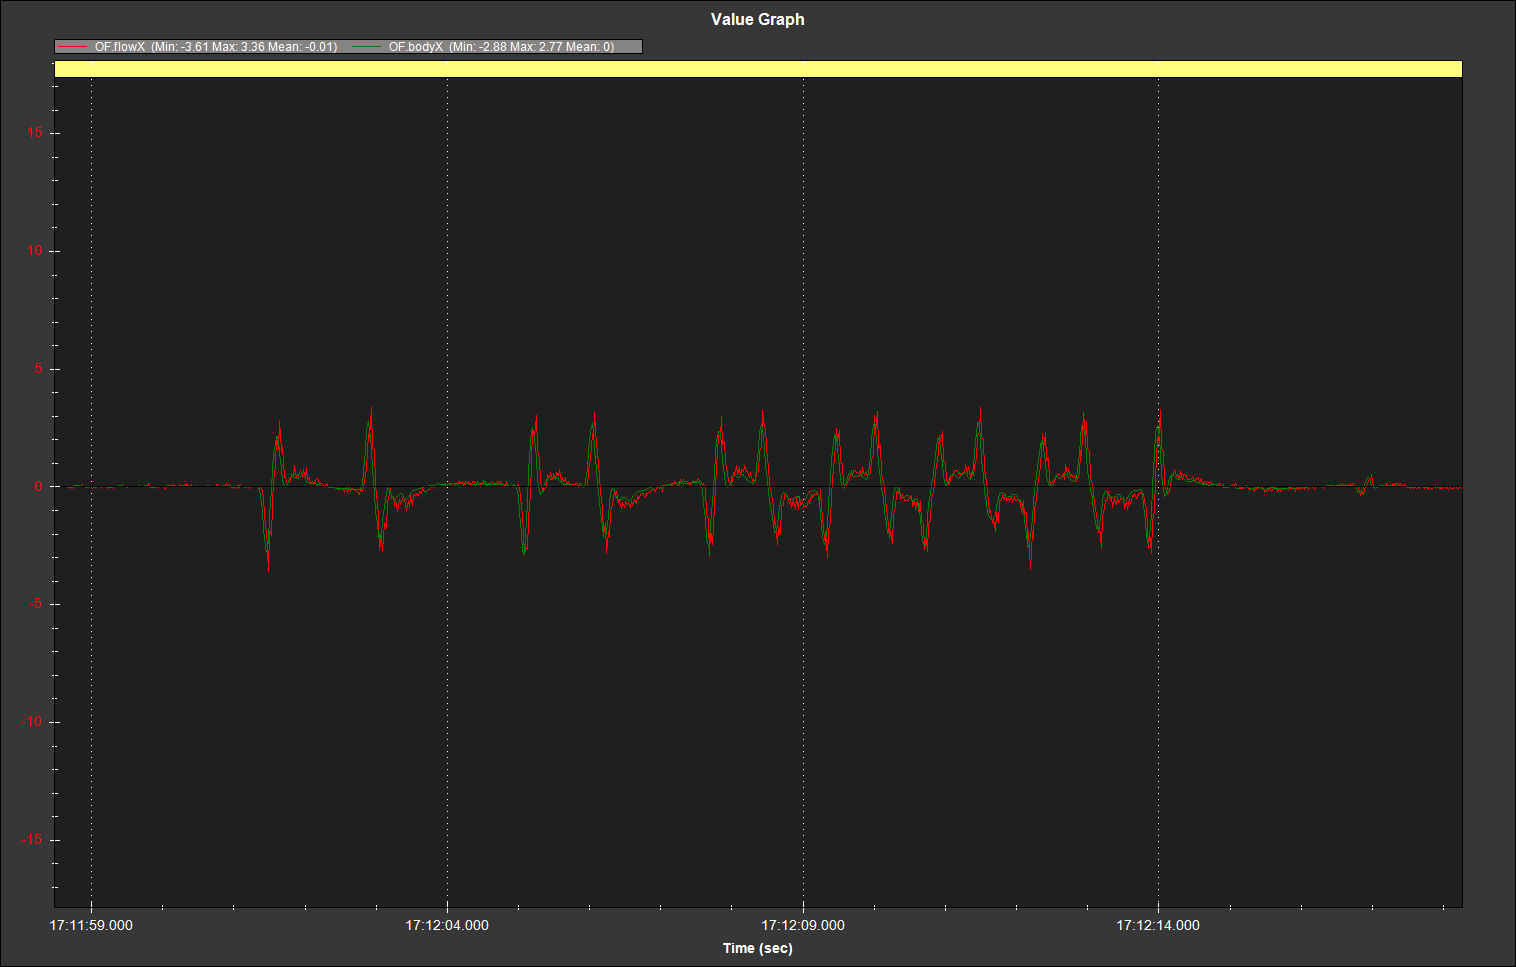
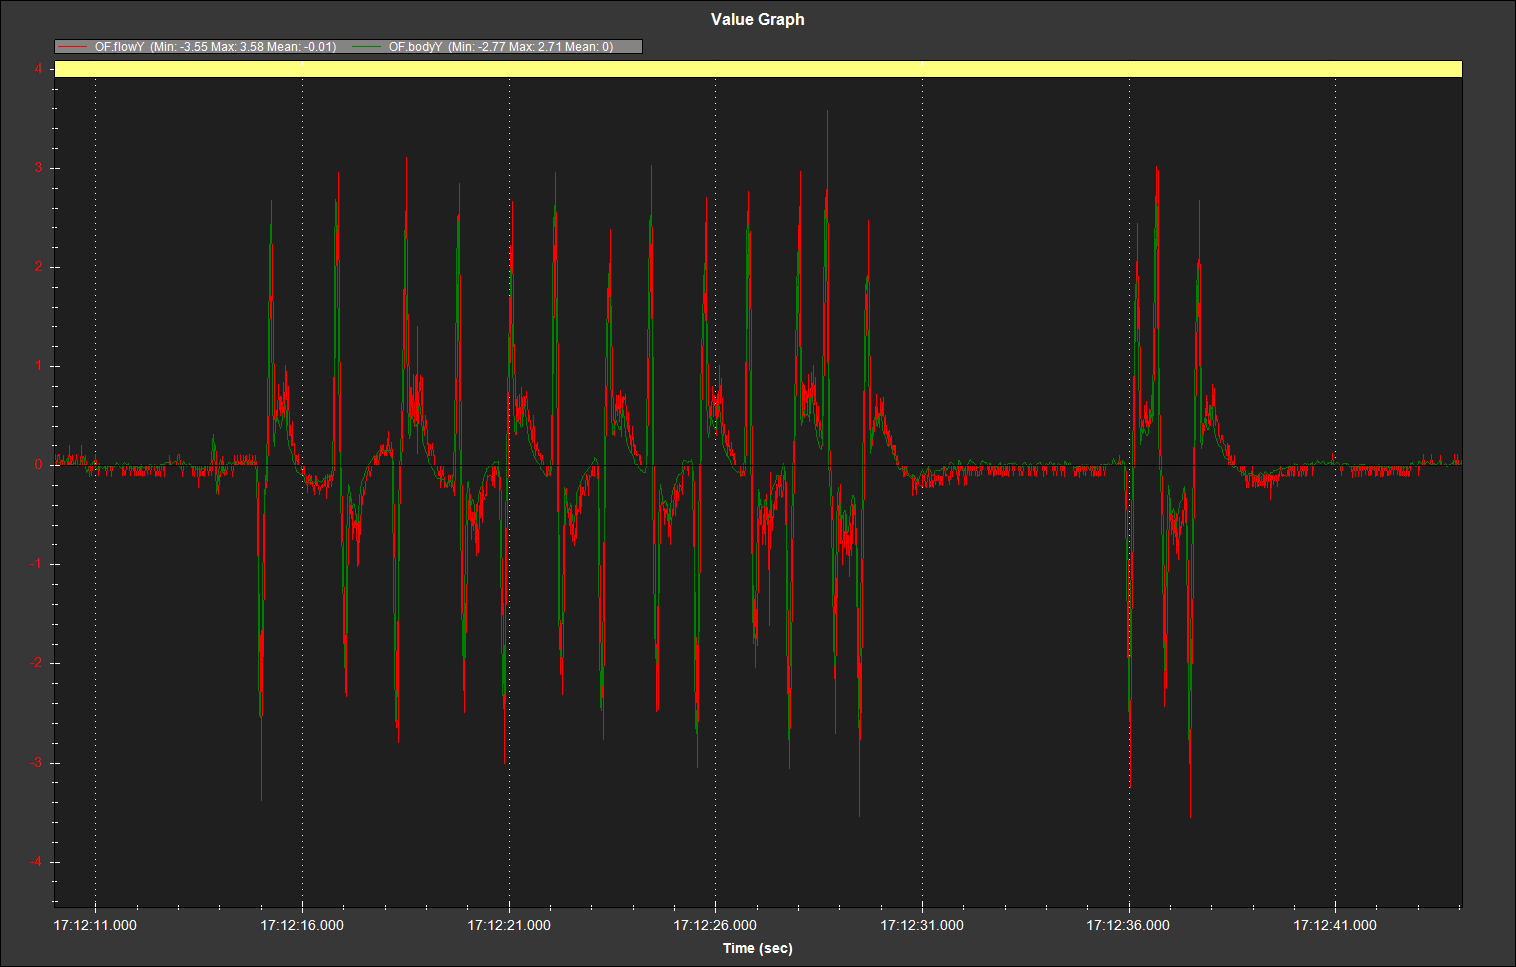
Unable to get a Scalar for Micoair MTF-02P during optical flow in-flight calibration. Attempted twice, and the result is the same. Why? Is it normal? In my experience with other optical flow sensors and with older Arducopter, scalars are always needed.
Offset forward by 7 cm.
Arducopter 4.6.3
FCU: MicoAir MicoAir743v2-AIO-45A
hi, i am using SpeedyBee F405 Mini BLS 35A 20x20 Stack fc, MicoAir Tech MTF-02P Optical and Range Sensor and a custom firmware to enable the flow options. I tried to calibrate the optical flow but the flowcal values are not appearing in the msg tab.
24/09/2026 11:39:19 am : Field Elevation Set: 0m
24/09/2026 11:39:18 am : Field Elevation Set: 0m
24/09/2026 11:39:17 am : Field Elevation Set: 0m
24/09/2026 11:39:16 am : Field Elevation Set: 0m
24/09/2026 11:39:15 am : Field Elevation Set: 0m
24/09/2026 11:39:14 am : Field Elevation Set: 0m
24/09/2026 11:39:13 am : Field Elevation Set: 0m
24/09/2026 11:39:12 am : Field Elevation Set: 0m
24/09/2026 11:39:11 am : Field Elevation Set: 0m
24/09/2026 11:38:55 am : FlowCal: Stopped
24/09/2026 11:38:41 am : FlowCal: timeout
24/09/2026 11:36:41 am : FlowCal: Started
24/09/2026 11:36:39 am : FlowCal: Stopped
24/09/2026 11:36:31 am : Warning: Arming Checks Disabled
24/09/2026 11:36:31 am : Field Elevation Set: 0m
24/09/2026 11:36:30 am : Field Elevation Set: 0m
24/09/2026 11:36:29 am : Field Elevation Set: 0m
24/09/2026 11:36:28 am : Field Elevation Set: 0m
24/09/2026 11:36:27 am : Field Elevation Set: 0m
24/09/2026 11:36:27 am : FlowCal: Started
24/09/2026 11:36:26 am : Field Elevation Set: 0m
24/09/2026 11:36:25 am : Field Elevation Set: 0m
24/09/2026 11:36:24 am : Field Elevation Set: 0m
24/09/2026 11:36:23 am : Field Elevation Set: 0m
24/09/2026 11:36:22 am : Field Elevation Set: 0m
24/09/2026 11:36:21 am : Field Elevation Set: 0m
24/09/2026 11:36:20 am : Field Elevation Set: 0m
24/09/2026 11:36:19 am : Field Elevation Set: 0m
24/09/2026 11:36:18 am : Field Elevation Set: 0m
24/09/2026 11:36:17 am : Field Elevation Set: 0m
24/09/2026 11:36:16 am : Field Elevation Set: 0m
24/09/2026 11:36:15 am : Field Elevation Set: 0m
24/09/2026 11:36:14 am : Field Elevation Set: 0m
24/09/2026 11:36:13 am : Field Elevation Set: 0m
24/09/2026 11:36:12 am : Field Elevation Set: 0m
24/09/2026 11:36:11 am : Field Elevation Set: 0m
24/09/2026 11:36:10 am : Field Elevation Set: 0m
24/09/2026 11:36:09 am : Field Elevation Set: 0m
24/09/2026 11:36:08 am : Field Elevation Set: 0m
24/09/2026 11:36:07 am : Field Elevation Set: 0m
24/09/2026 11:36:06 am : Field Elevation Set: 0m
24/09/2026 11:36:05 am : Field Elevation Set: 0m
24/09/2026 11:36:04 am : Field Elevation Set: 0m
24/09/2026 11:36:03 am : Field Elevation Set: 0m
24/09/2026 11:36:02 am : Field Elevation Set: 0m
24/09/2026 11:36:01 am : Field Elevation Set: 0m
24/09/2026 11:36:00 am : Field Elevation Set: 0m
24/09/2026 11:35:59 am : Field Elevation Set: 0m
24/09/2026 11:35:58 am : Field Elevation Set: 0m
24/09/2026 11:35:57 am : Field Elevation Set: 0m
24/09/2026 11:35:56 am : Field Elevation Set: 0m
24/09/2026 11:35:55 am : Field Elevation Set: 0m
24/09/2026 11:35:54 am : Field Elevation Set: 0m
24/09/2026 11:35:53 am : Field Elevation Set: 0m
24/09/2026 11:35:52 am : Field Elevation Set: 0m
24/09/2026 11:35:38 am : FlowCal: Stopped
24/09/2026 11:34:55 am : FlowCal: timeout
24/09/2026 11:32:54 am : FlowCal: Started
24/09/2026 11:32:45 am : EKF3 IMU0 MAG0 initial yaw alignment complete
24/09/2026 11:32:45 am : Using EKF Source Set 2
24/09/2026 11:32:16 am : Warning: Arming Checks Disabled
24/09/2026 11:32:16 am : Field Elevation Set: 0m
24/09/2026 11:32:14 am : Field Elevation Set: 0m
24/09/2026 11:32:13 am : Field Elevation Set: 0m
24/09/2026 11:32:12 am : Field Elevation Set: 0m
24/09/2026 11:32:11 am : Field Elevation Set: 0m
24/09/2026 11:32:10 am : Field Elevation Set: 0m
24/09/2026 11:32:10 am : EKF3 IMU0 origin set
24/09/2026 11:31:38 am : ELRS: Link rate 250Hz, Telemetry rate 10Hz
24/09/2026 11:31:35 am : GPS 1: detected u-blox
24/09/2026 11:31:35 am : GPS 1: probing for u-blox at 230400 baud
24/09/2026 11:31:33 am : ELRS: Link rate 250Hz, Telemetry rate 55Hz
24/09/2026 11:31:31 am : EKF3 IMU0 tilt alignment complete
24/09/2026 11:31:30 am : AHRS: EKF3 active
24/09/2026 11:31:30 am : EKF3 IMU0 initialised
24/09/2026 11:31:28 am : Using EKF Source Set 3
24/09/2026 11:31:28 am : RCOut: PWM:1-5
24/09/2026 11:31:28 am : AHRS: DCM active
24/09/2026 11:31:28 am : ArduPilot Ready
24/09/2026 11:31:28 am : ELRS: RSSI now displays normally
24/09/2026 11:31:28 am : ELRS: Link rate 250Hz, Telemetry rate 249Hz
24/09/2026 11:31:28 am : Initialising ArduPilot
24/09/2026 11:31:27 am : Barometer 1 calibration complete
24/09/2026 11:31:27 am : ELRS: bootstrap complete, fw 1.00
24/09/2026 11:31:27 am : RCInput: decoding CRSF(3)
24/09/2026 11:31:27 am : Frame: QUAD/X
24/09/2026 11:31:27 am : RCOut: Initialising
24/09/2026 11:31:27 am : SpeedyBeeF405Mini 003F0042 32345112 39333531
24/09/2026 11:31:27 am : ChibiOS: 88b84600
24/09/2026 11:31:27 am : ArduCopter V4.6.3 (92b0cd78)
24/09/2026 11:31:26 am : Frame: QUAD/X
24/09/2026 11:31:26 am : RCOut: Initialising
24/09/2026 11:31:26 am : SpeedyBeeF405Mini 003F0042 32345112 39333531
24/09/2026 11:31:26 am : ChibiOS: 88b84600
24/09/2026 11:31:26 am : ArduCopter V4.6.3 (92b0cd78)
24/09/2026 11:31:26 am : Frame: QUAD/X
24/09/2026 11:31:26 am : RCOut: Initialising
24/09/2026 11:31:26 am : SpeedyBeeF405Mini 003F0042 32345112 39333531
24/09/2026 11:31:26 am : ChibiOS: 88b84600
24/09/2026 11:31:26 am : ArduCopter V4.6.3 (92b0cd78)
24/09/2026 11:31:26 am : Calibrating barometer
24/09/2026 11:31:26 am : Frame: QUAD/X
24/09/2026 11:31:26 am : RCOut: Initialising
24/09/2026 11:31:26 am : SpeedyBeeF405Mini 003F0042 32345112 39333531
24/09/2026 11:31:26 am : ChibiOS: 88b84600
24/09/2026 11:31:26 am : ArduCopter V4.6.3 (92b0cd78)
this is my msg logs. Help me in resolving this issue, if you require i can provide the custom firmware as well as param file
Can we assume you have set the jumper and mounted the orientation correctly? It is very weird that the information wasn’t mentioned, but it is mentioned on the store page. And does your custom ArduCopter firmware include optical flow support?
Do you think it could be due to STM32F405 has been overloaded?
Are you holding the position using the optical flow sensor while trying to calibrate the optical flow sensor? Could you share your EK3_SRC2_xx parametres?
You cannot use optical flow to hold position and trying to calibrate at the same time. please use EK3_SRC1_xx (gps) to hold position and calibrate optical flow sensor.
In my area there is no strong gps signal the hdop is always around 10. I am not using optical flow to hold position and then calibrate it, my dorne does not switch into loiter mode whenever i tried to switch it into the loiter mode, it shows and error msg “Mode change to LOITER failed: requires position and PreArm: Need Position Estimate”, the home and ekf origin is set by me on the mission planner, still the same issue