Hi everyone,
I would like some advice on Harmonic Notch Filter tuning for my EFT420 quadcopter.
The aircraft is a relatively large/heavy-lift quad with 2-blade propellers. I am using ESC telemetry for dynamic Harmonic Notch tracking.
My current setup is:
ArduPilot: Copter 4.7
MOT_THST_HOVER: 0.166

INS_GYRO_FILTER = 30 Hz

INS_HNTCH_ENABLE = 1
INS_HNTCH_MODE   = 3 (ESC telemetry)
INS_HNTCH_FREQ   = 62 Hz
INS_HNTCH_BW     = 30 Hz
INS_HNTCH_ATT    = 40 dB
INS_HNTCH_REF    = 1
INS_HNTCH_HMNCS  = 11
The propellers are 2-blade, and the hover RPM is approximately 1900 RPM.
Therefore:
1900 RPM / 60 = 31.7 Hz (1/rev)

31.7 × 2 = 63.3 Hz (2/rev / blade-pass frequency)
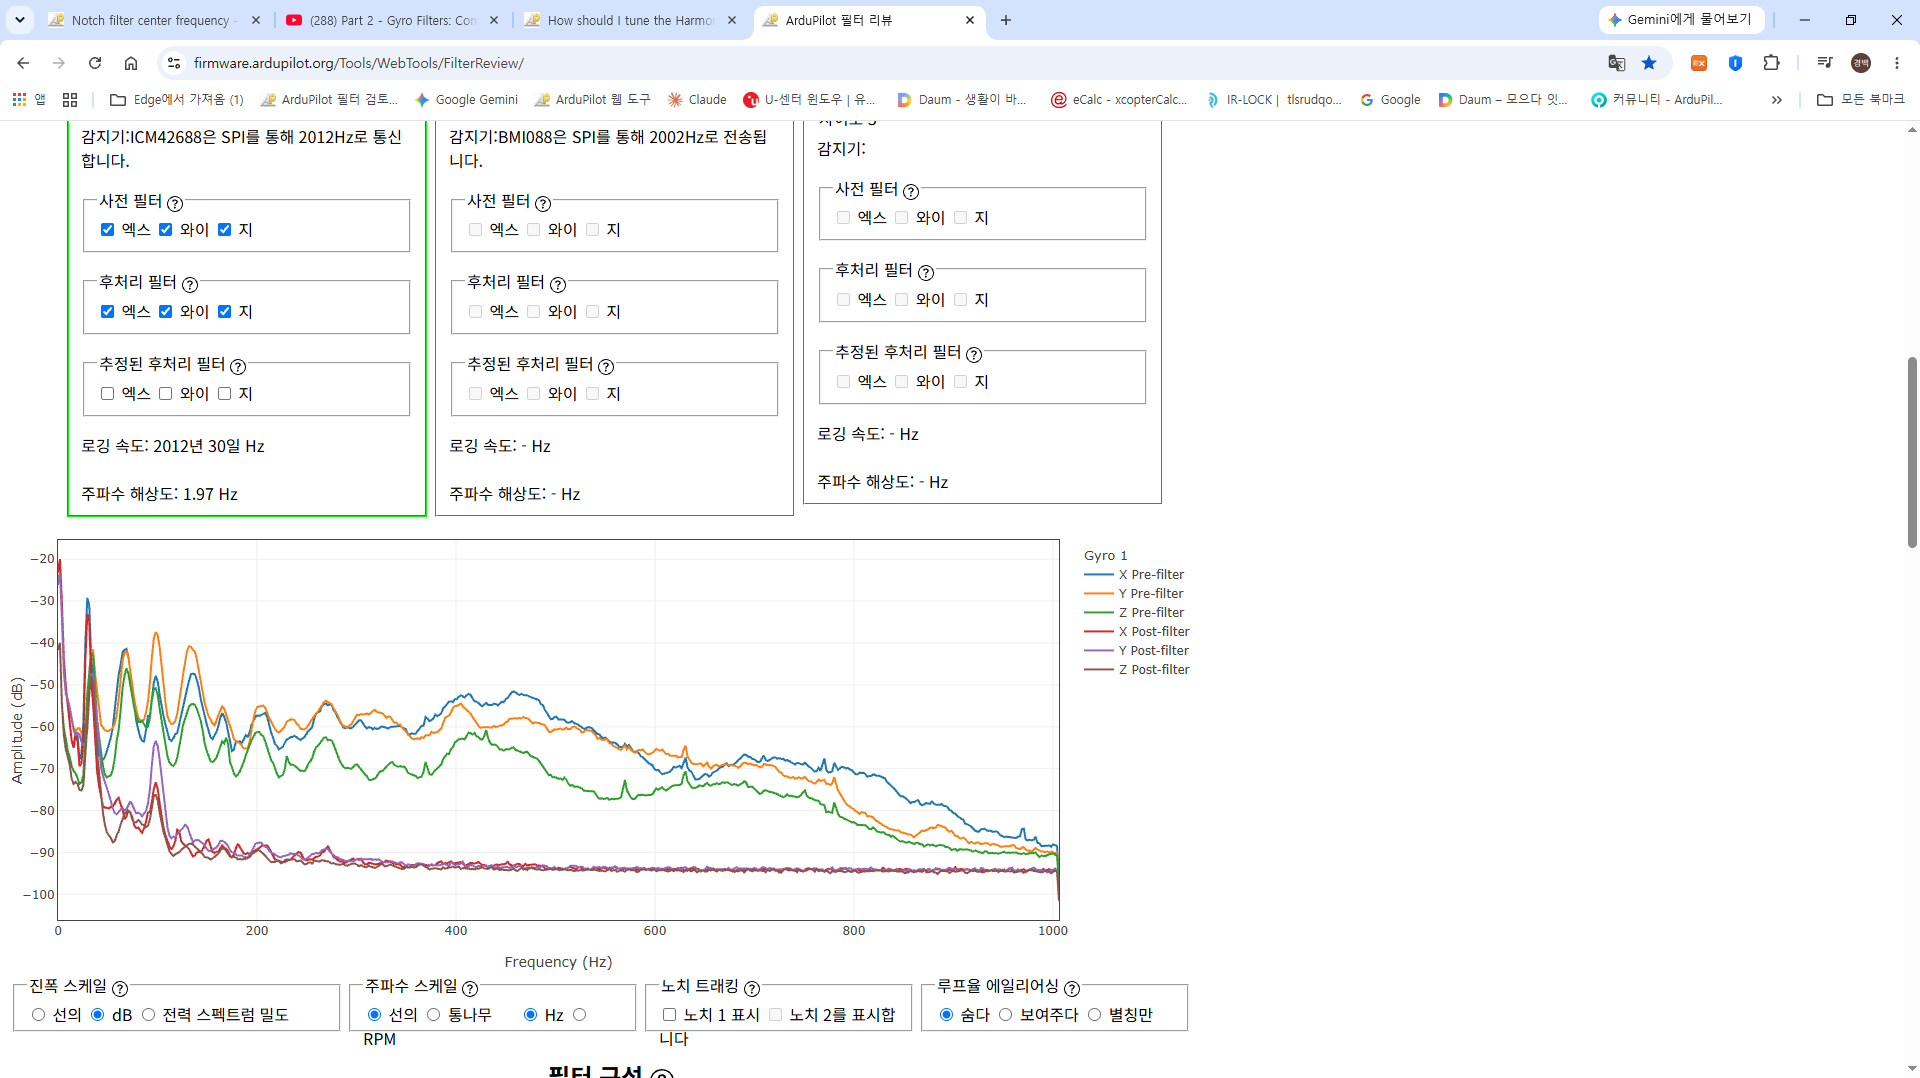
The FFT shows a strong peak around 30–32 Hz, followed by strong peaks around approximately 63–70 Hz, 95–100 Hz, 130–135 Hz, etc.
The ESC telemetry data also shows approximately:
Fundamental:  ~29.4 Hz
2nd harmonic: ~58.8 Hz
4th harmonic: ~117.7 Hz
So the approximately 30 Hz peak appears to correspond to the motor 1/rev frequency, while the approximately 60–63 Hz component corresponds to the 2/rev component and the 2-blade propeller BPF.
My questions are:
- Should I actively filter the strong ~30 Hz 1/rev component, or is it preferable to leave it relatively unfiltered if it is not causing control problems?
- Since the hover RPM is about 1900 RPM, the 2-blade BPF is approximately 63 Hz. Does
INS_HNTCH_FREQ = 62 Hzmake sense in this situation? - With
INS_HNTCH_HMNCS = 11, the notch tracks the 1H, 2H and 4H components. Is this the appropriate configuration when the strongest vibration components appear at approximately 30, 60 and 120 Hz? - Is
INS_GYRO_FILTER = 30 Hzunnecessarily low because it is close to the 1/rev frequency (~32 Hz), or is it reasonable to keep it at 30 Hz when the 1/rev vibration is strong? - Would you recommend changing the gyro LPF, the Harmonic Notch frequency/BW/attenuation, or leaving the current configuration unchanged?
The post-filter FFT looks significantly cleaner than the pre-filter FFT, so I am mainly trying to understand whether I am over-filtering the 30 Hz 1/rev component or whether it is appropriate to suppress it.
I can provide the BIN log and screenshots of the FFT / Filter Review if needed.
Thanks for any advice.