Hi all,
I’ve built a small Windows companion app called HaptiStick that connects an FFB (force-feedback) joystick — DirectInput-based, e.g. Logitech WingMan/Force 3D Pro class hardware — to live ArduPilot telemetry over MAVLink (SITL or a real autopilot), and drives real force feedback effects from it.
What it does:
- Wind/turbulence resistance on Plane (pitch/roll/yaw)
- Stall-warning stick shaker
- Terrain roughness on Rover, from IMU vibration data, translated into steering feedback
- Vortex Ring State haptic warning on Copter
- 4 vehicle profiles: Plane / Rover / Multirotor / Heli
Short demo video (SITL + Mission Planner):
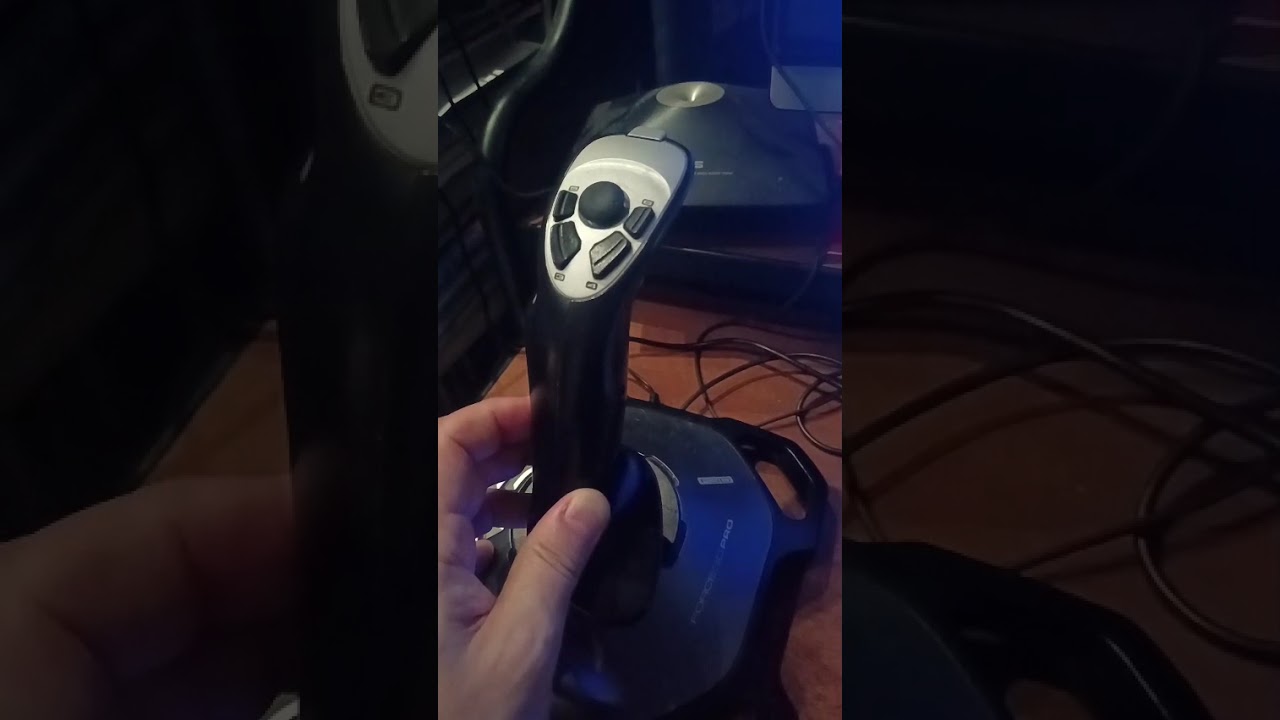
It’s an independent third-party tool, not affiliated with the ArduPilot project, built purely on the open MAVLink protocol. Available on the Microsoft Store:
There’s also a companion editor, HaptiStick Studio, for designing custom force feedback effects (all 11 DirectInput effects on the real spec, multi-track timeline, JSON presets):
Happy to answer questions about the implementation (DirectInput force feedback + MAVLink telemetry mapping), or hear feedback if anyone tries it against their own setup.