The gimbal is a Pixy LR S-port with the AirPixel Entire built in.
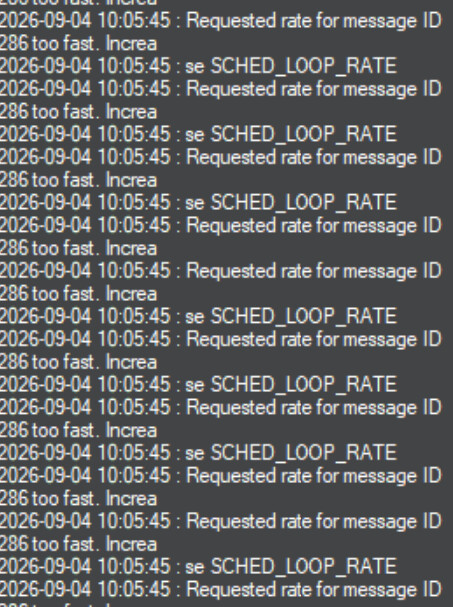
I’ve gone through the gremsy and the ardupilot wiki but I don’t seem to get it working. When I set the baudrate of Serial1 to the correct baud rate I get this message. If I change the baudrate to any other than the gimbals baudrate the message’s gone. So it must be the gimbal causing this somehow.
I also set Serial_Options to “Don’t forward mavlink to/from” according to the ardupilot wiki, although I think this step is not included in the Gremsy wiki.
I checked my loop rate, it was at 50Hz. I tried changing it to 300Hz which seems to have solved my issue. I now get tilt and pan through Mavlink. The gimbal still dosen’t show Mavlink as status under “RC” in the G-tune app. I’ve seen videos where it does. But at least it works.
The baudrates I tested was 115200 and 921600. Both rates generated my loop time issue and both was also resolved by increasing the loop rate to 300Hz. The baud gremsy recommends is 921600 which seems high? It might have something to do with the Air pixel entire built in to it. They will both run on the same serial port together.
I also cheched the data stream settings in G-tune, none were over 10Hz. I did some disarmed logging with the issue pressent and loop rate at 50Hz. Even if I solved it, it’s strange how it’s not mentioned in either the ardupilot or gremsy wiki? I fear I’ve only covered the actuall issue and it’ll give me a bunch of headache further down the road.
Etid: A quick google search told me a baud rate of 921600 (which I’m running now) would require a loop rate of at least 360Hz. If that’s correct I should still se issues?