Hello everyone,
I am troubleshooting an issue on a 10-inch FPV quad running ArduCopter 4.6.3 and would appreciate some guidance on the EKF behavior.
Hardware
-
Matek H743-Slim V4
-
Matek M9N-G4-3100 GNSS
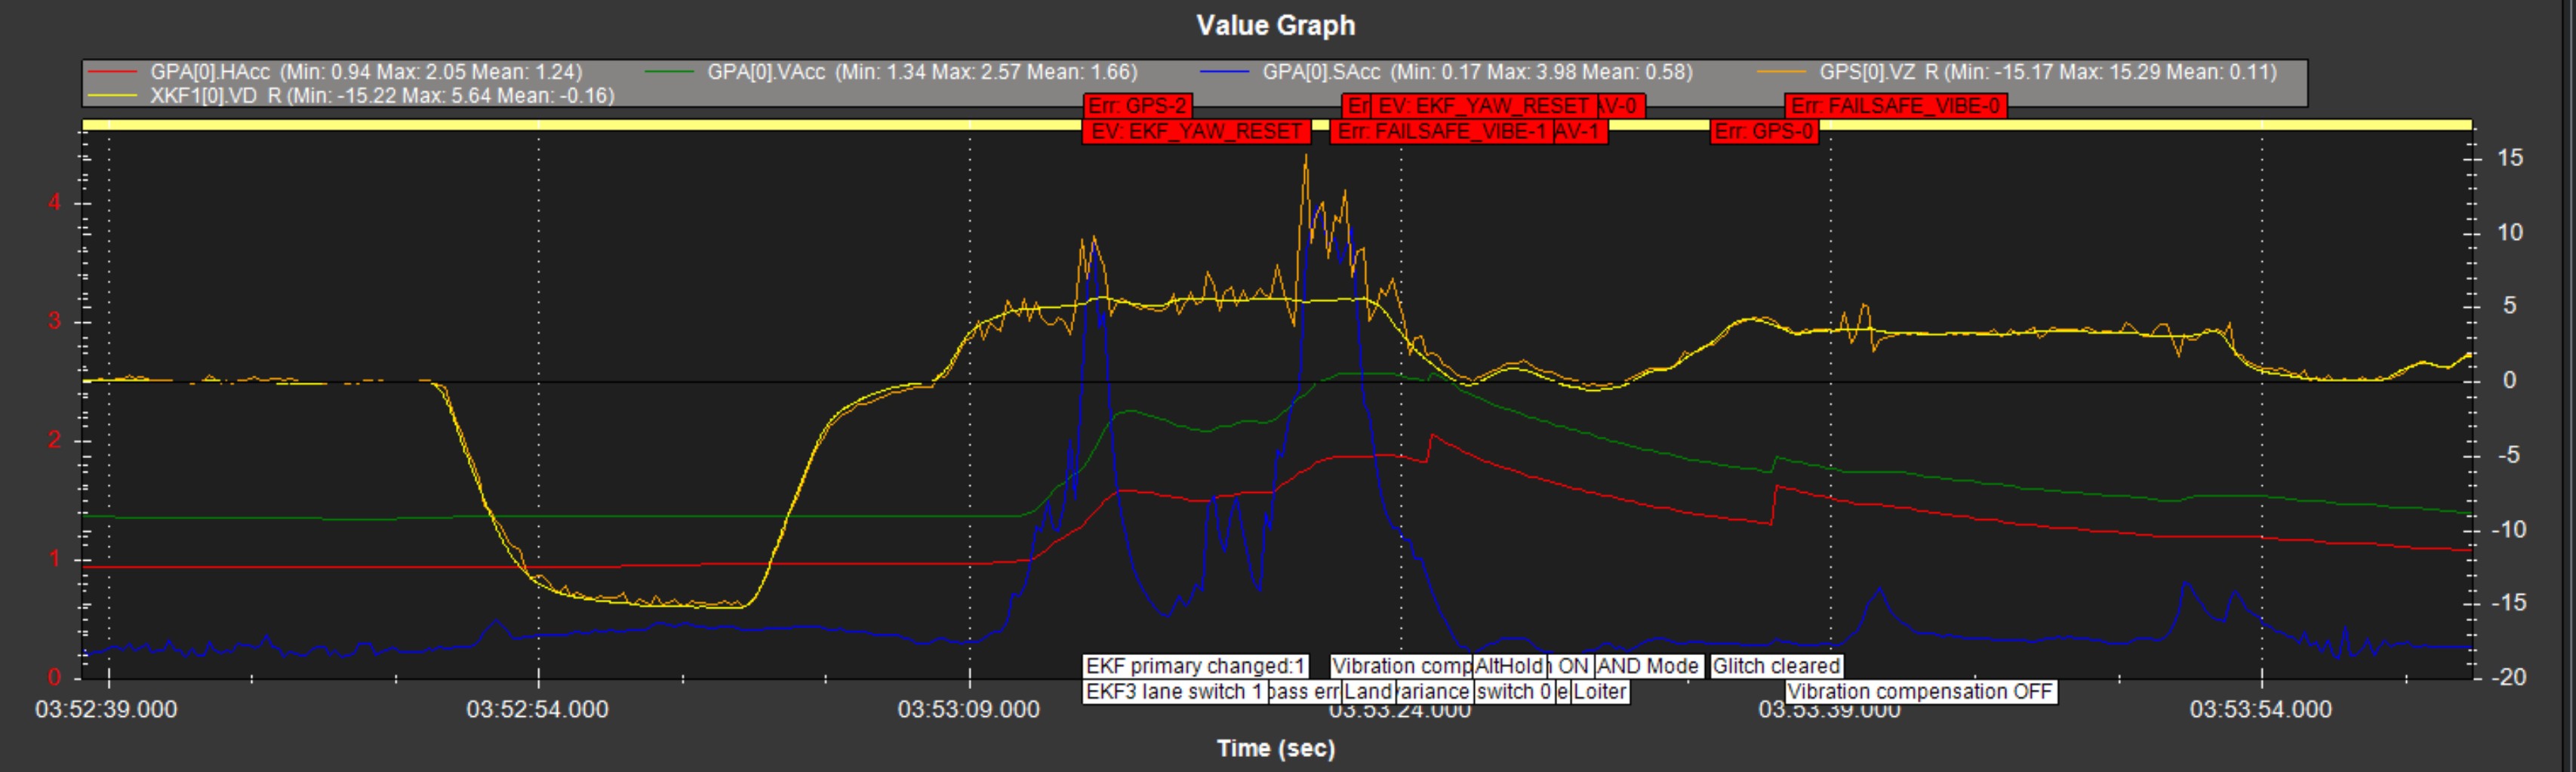
The aircraft flies well during hover, but when I apply impulse inputs or perform ascents and descents, I start getting GPS Glitch or Compass Error, EKF disturbances/lane switching, followed by Vibration Compensation ON.
From the logs, the GPS reception appears to be very good during these events, with NSats > 24 and HDOP < 0.6.
To rule out the barometer and compass as potential sources, I am using GSF yaw and have EK3_SRC1_POSZ set to GPS.
The measured vibration levels also remain relatively low, but the GPS/compass and vibration-compensation events continue to occur.
I have two identical systems. One system flies normally without these issues, while the second system consistently shows this behavior.
To rule out a GPS hardware problem, I swapped the GPS modules between the two systems, but the problem remained with the same aircraft.
I have attached the Flight Log.
I would appreciate any suggestions on what could be triggering the EKF disturbance and subsequent vibration compensation, and what parameters or log messages I should focus on to isolate the initial cause.
Thank you.