Hi all,
I am asking the community for help, especially from people who actually fly and tune planes.
I built a small live stand for seeing ArduPilot loops - which blocks the current mode closes, and which knobs sit on them. It started as a copter tool. I recently drew a Plane map, with L1 and TECS as the outer path. I am not a plane person. I would like to ask you to look at the map and the two outer schemes and tell me where they are wrong, incomplete, or the convenient lie.
It is not Mission Planner, not Autotune, and not a tuning protocol.
-
Installers (1.1.0): Release ArduLoops 1.1.0 · alex-pokydin/ArduLoops · GitHub
The map - this is the thing I need eyes on
One picture of the live path. Top is command (stick + mission targets). Then a Navigate band: L1 and TECS sit outside attitude, side by side. Then roll and pitch as two cards, yaw damper, ground steer, then surfaces.
Empty map = this mode’s path (dimmed cards are not closed now). Click a card = only that block’s in and out. Left edge: solid = tune these, hollow double = later, dashed = no knobs.

What I am trying to say with that layout:
-
There is no
PSC_*stack on a wing. Horizontal path is L1 (cross-track → demanded bank). Height/speed is TECS (energy → pitch + throttle). They are not one “outer PID”. -
L1 writes
nav_rollinto the roll loop. TECS writesnav_pitchand throttle. In FBWA the stick is the angle and the left stick is still throttle — L1/TECS should go dim. In AUTO / LOITER / RTL they should light up (TECS also in FBWB / CRUISE). -
I may have the live-in-mode list wrong (TAKEOFF, GUIDED, TRAINING, CRUISE vs FBWB). That dimming is the part I trust least.
If the map’s shape is wrong - wrong neighbours, wrong “outside”, a missing first-flight block — that is the most useful reply I can get.
L1 - what the Loop tab draws when you click that card
Wiki I used: L1 navigation.
The scheme is: look a distance L1 ahead of the track → lateral acceleration → bank φ = atan(a/g) → nav_roll for the roll loop.
-
L1 = (1/π) · DAMPING · PERIOD · groundspeed (so the same PERIOD feels the same at different speeds)
-
K = 4 · DAMPING²
-
a = K · V² / L1 · sin(Nu) — Nu and a_y are not on this MAVLink sample; we show
nav_roll -
NAVL1_PERIODis the main knob (wiki start ~17, damping 0.75). Smaller = tighter turn. Weaving after a turn: add 1–2 s. Turn too slow: subtract about 5. -
Tune roll first. Raising PERIOD will not hold a wing that cannot hold bank.
ROLL_LIMIT_DEGis the stall-safe bank, not an L1 gain.WP_RADIUSis fly-through vs turn-early.

Does that match how you explain L1 to a new pilot? Is PERIOD really the knob to touch, or am I hiding NAVL1_DAMPING / WP_RADIUS in the wrong place?
TECS - same idea, the other Navigate card
Wiki I used: TECS speed/height.
I tried not to draw a black box. The scheme is one energy, two plants:
-
SPE = g · h (potential, per unit mass)
-
SKE = ½ V² (kinetic)
-
STE = SPE + SKE → throttle (total energy)
-
SEB = (2−W)·SPE − W·SKE → pitch (energy balance: nose down trades height for speed)
-
W =
TECS_SPDWEIGHT: 0 pitch holds height, 2 pitch holds speed (glider), 1 mix. It is not a P. A circle sits where the four arrows cross.

Also on the picture: height error and airspeed feed SPE/SKE; throttle and pitch limits (THR_MAX, TRIM_THROTTLE, PTCH_LIM_*, climb/sink) sit at the edges. Click a block for extra knobs under the scheme; the sidebar keeps the main ones.
Stories I need checked:
-
Throttle cannot set the balance - that is pitch. Pitch cannot set the total - that is throttle.
-
Without an airspeed estimate, W is forced to 0.
-
Measure
TECS_CLMB_MAX/SINK_MIN/SINK_MAXin FBWA; if they are optimistic, height oscillates. -
Porpoise → pitch rate first, then
TECS_TIME_CONST. Do not hunt a height P. -
In FBWA the left stick is still throttle. TECS should not look “live” there.
If SPE/SKE/STE/SEB/W is not how you think about TECS, or the arrows are swapped, please say so in those letters.
Inner loops (rate FF in FBWA, yaw damper, ground steer) are on the same map below L1/TECS. Happy to hear if those cards are wrong too — but the ask is the Navigate band.
How to try it
Windows or Linux x86_64 from release 1.1.0. SITL in the header → plane thumb → Start. It downloads official SITL and Links tcpout:127.0.0.1:5770.
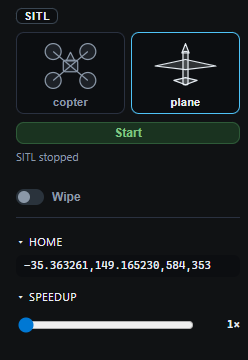
Then:
-
Leave it in FBWA. Empty map: L1/TECS dim, roll/pitch live. Does that match the aircraft?
-
Switch AUTO (or FBWB / CRUISE). Do L1 and TECS light the way you expect?
-
Click L1, open Loop. Then TECS. Walk the blocks. If a box or an arrow is the lie, name it.
A real board is the same Link (close Mission Planner - one TCP client per SITL port). From source: npm install && npm run dev → http://127.0.0.1:5173.
Thanks in advance for any ideas or suggestions!