I am setting up a Nimbus 1800 VTOL with ArduPilot v4.0.1 and I am having an issue with ESC calibration.
My receiver works normally when the flight controller is powered from the flight battery, but it does not bind/connect when the flight controller is powered only through USB it just blinks red.
Because of this, I cannot complete the recommended ESC calibration procedure using:
Q_ESC_CAL = 1
The procedure requires me to enter QSTABILIZE and arm, but when powered through USB I have no RC input because the receiver is not bind. Therefore, I cannot arm the vehicle and start the ESC calibration.
Is there an alternative method to calibrate the ESCs in ArduPilot without relying on USB power + RC input + QSTABILIZE arming?
Q_ESC_CAL = 2also doesnot seems to be working for me as after doing this and calibrating then using motor test, I have to set the throttle to 10% then only the motor spins
Any advice on the proper procedure for the Nimbus 1800 VTOL would be appreciated.
Basically, you can temporarily disable the arming check. Then you can arm the drone without GPS reception, RC, etc. But be careful—don’t forget to turn it back on before your first flight, and remove the propellers.
Why are you using such an old version as 4.0.1 from November 2019? Could it be that it’s already installed and no one has updated to a newer version yet?
In 4.0.1, the parameter to disable the arming check is ARMING_CHECK 0. Please reset it to ARMING_CHECK 1 (default) afterward.
The current stable version is 4.7.1. In the meantime, the corresponding setting is ARMING_SKIPCHK 1 to skip the check. Again, be sure to reset it back to ARMING_SKIPCHK 0 afterward.
If you want to upgrade, it probably won’t be practical to do so in a single step anymore. I’m not sure exactly in what stages you should update a 6-year-old firmware version. Maybe someone else knows more about this.
Ok I will update the firmware to the latest. I was using the old firmware as my initial guess was that my servo output where wrong as with the old firmware there was a param file which I simply loaded
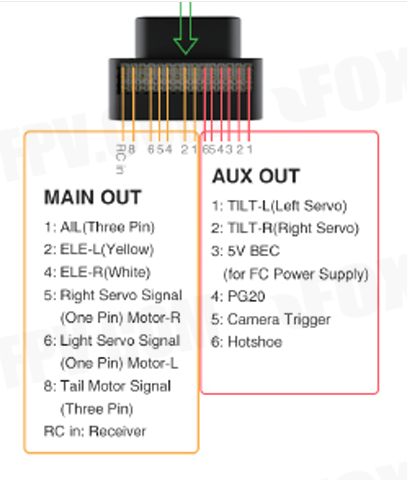
Second, I have my servo outputs as per this diagram of pixhawk. Currently I have 1100 as my pwm minimum and 1900 as the maximum for motor 1,2,4.
Do I need to assign Throttle to channel 3 of servo output as I have many tilt rotors have that assigned?
My doubt about esc not being properly calibrated arised when during quad test in qloiter mode, the vtol was yawing in clockwise direction when leaving ground.