I went to test 4.7.1 today to see if the super simple mode was fixed. It did work correctly now with this update. Everything flew perfectly and I landed and upon landing I pulled the throttle all the way down, and it disarms in the motor shut off and then shut down the remote control which is a skydroid G30. I have been storing my remote control in the backseat face down in a padded pelican case to avoid having something accidentally scratch the screen. So with the remote control completely shut off, I placed it in the backseat face down and very shortly thereafter, the drone took off on its own and went up about. I’m guessing 75 feet and started moving towards a tree. I was grabbing the remote control to try to turn it on, and I had no control whatsoever of any motion. I was a bit frantic, trying to control the drone from the remote control not considering that it was not turned on and it was headed towards a tree. I was pushing RTL over and over again, hoping that it could somehow connect with the power off, then finally realized I needed to power up by the time I got the power to boot up. It started doing an RTL on its own before the system even booted up completely, and started a very slow descent in between my two cars approximately 8 feet from both of my cars. It did an almost perfect landing while I was having a heart attack.
When placing the remote control face down into the pelican case which is padded, I think it’s obvious that one of the levers may have gotten moved, but let’s say that coincidentally the throttle lever was pushed to the position of approximately 5 o’clock, which is the arming position and it armed itself a question is how did it take off on its own without pushing to throttle up? Furthermore, how would pushing a throttle knob doing anything anyway, with the power turned off?
Well, it’s taking a long time for an 18m file to download but in the meantime what I’ve observed is the most recent log which is called 430.bin is 18 meg and the previous file 429.BIN is 14 meg and I know that my TestFlight was probably in the range of 10 minutes or so maybe less but the flight that took off by itself and landed itself lasted only one or two minutes. Which means it’s not possible that the flight that took off by itself and landed by itself could be 18 megs compared to my flight that I flew for five or 10 minutes prior could be 14 megs, which is making me think that possibly when I landed it after the first TestFlight, I may have thought that I completely disarmed, but I may not have completely disarmed, which is a very strange thing to consider. But based on these file sizes, that is the only explanation. Which means that one possibility is that I landed the drone after the TestFlight and then thought that I disarmed it, but I didn’t and then I turned off the remote control by pressing a sequence of power off, and then pressing a graphic on the screen that said power off and perhaps the remote was still slightly active when I placed it into the pelican case face down, and when I placed it face down, perhaps the throttle got pushed up and it took off and in the process of taking off the remote control, finally shut down and the drone did a RTL on loss of signal. I will upload the BIN later right now it’s taking a very long time to download for some reason.
In my opinion, I did shut the propellers off on a disarm, but I cannot think of a better explanation
I forgot that you have to download from the data panel. Here is the file. I’m hoping that somebody can help me understand what happened today.
To summarize what happened.
I flew a TestFlight for somewhere between five and 10 minutes. Then landed.
Upon landing, I do what I typically do is pull the throttle back to disarm the drone in which case the propeller stop spinning.
I turn off the remote control by holding the power button, and then a graphic pops up for me to press a shut down button on the G 30, which is an android based system.
A place the remote control face down into a pelican case, and most likely moved some sticks most likely moved the throttle stick some, and the other stick on the right.
The drone took off and went straight up with a little bit of a lateral move of 20 or 30 feet towards a tree, then did not hit the tree
The drone was up approximately 75 feet which was lower than my return to Home height, which is much higher than that, but when the drone is within a certain range of home, it only goes up to a certain height where there’s this funnel shape that determines what the maximum height needs to be
The drone descended automatically and landed at the takeoff point. 10 feet from my car and luckily there was no injury to the car.
The drone shut itself down upon landing at which time I was just now getting the remote control powered back on fully so I could run the app
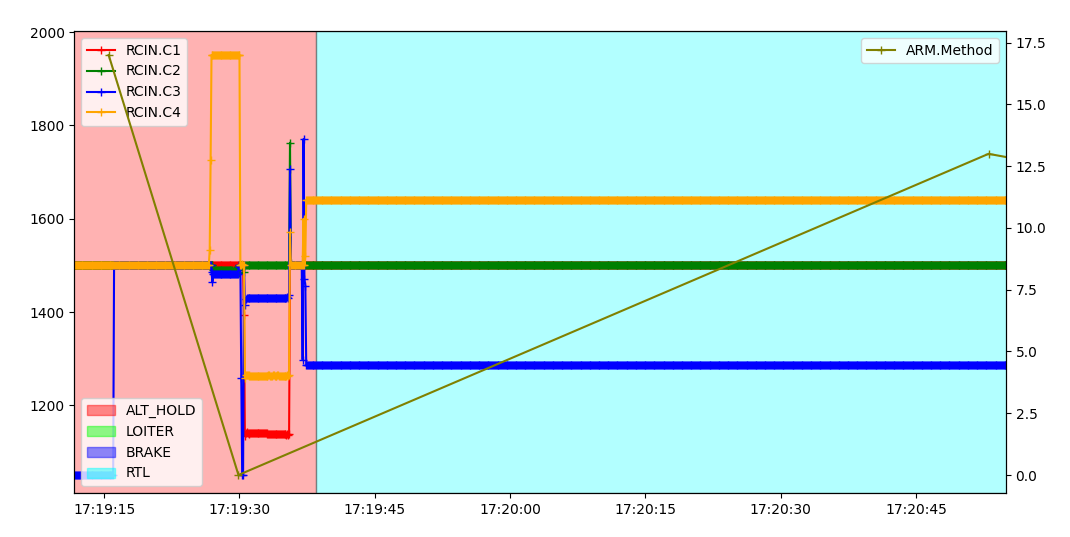
The part I’m confused about is even though the rudder went to full travel, the throttle seems to have only just come out of the deadzone. Is this controller a center-sprung throttle?
Edit:
I’m just looking around, and I see that MOT_SPIN_MIN and _ARM look like they are still default (among a bunch of other parameters related to the tuning). The hover thrust values and motor PWM outputs suggest this drone has a good amount of power. It’s possible that those MOT_SPIN values are too high, allowing the drone to fly too soon. It wouldn’t have stopped the arming, but it might have prevented the take-off.
Hello, thanks for taking a look pic. Yes it is a center returned joystick. The drone does not have enough power to fly at center. I think the thing I need to look for is, I assumed that this file included both my first TestFlight and the second automatic takeoff and automatic land in which case a question would be how many arm and disarms are found
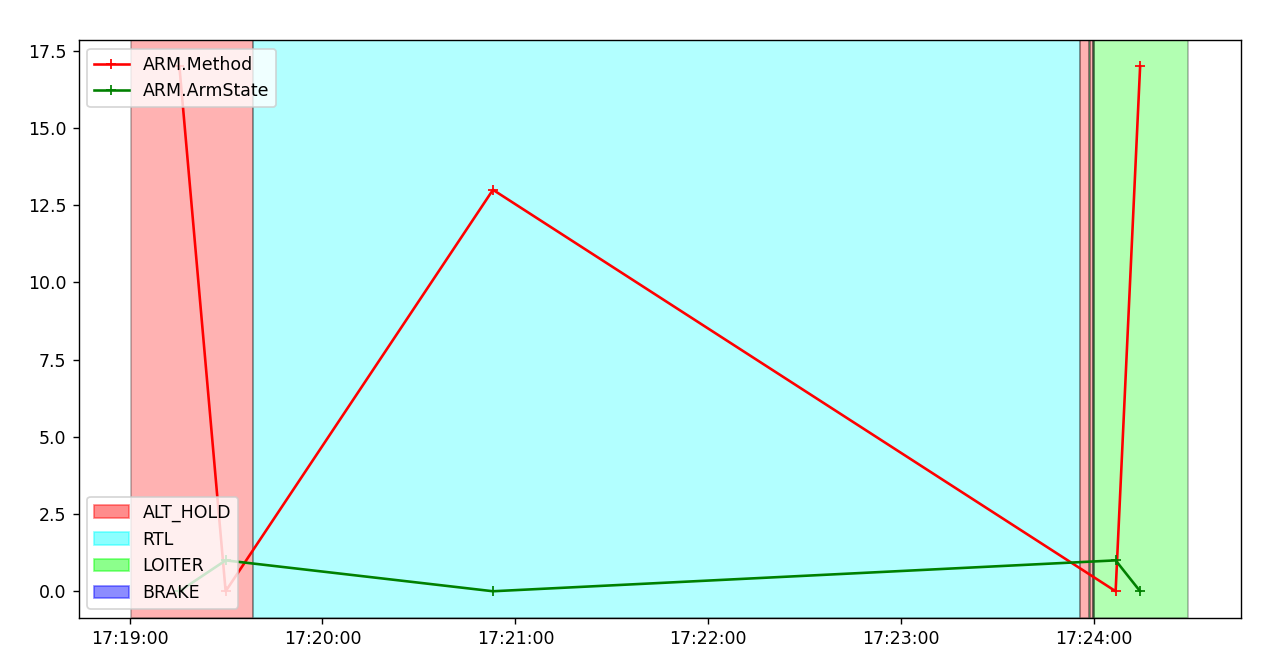
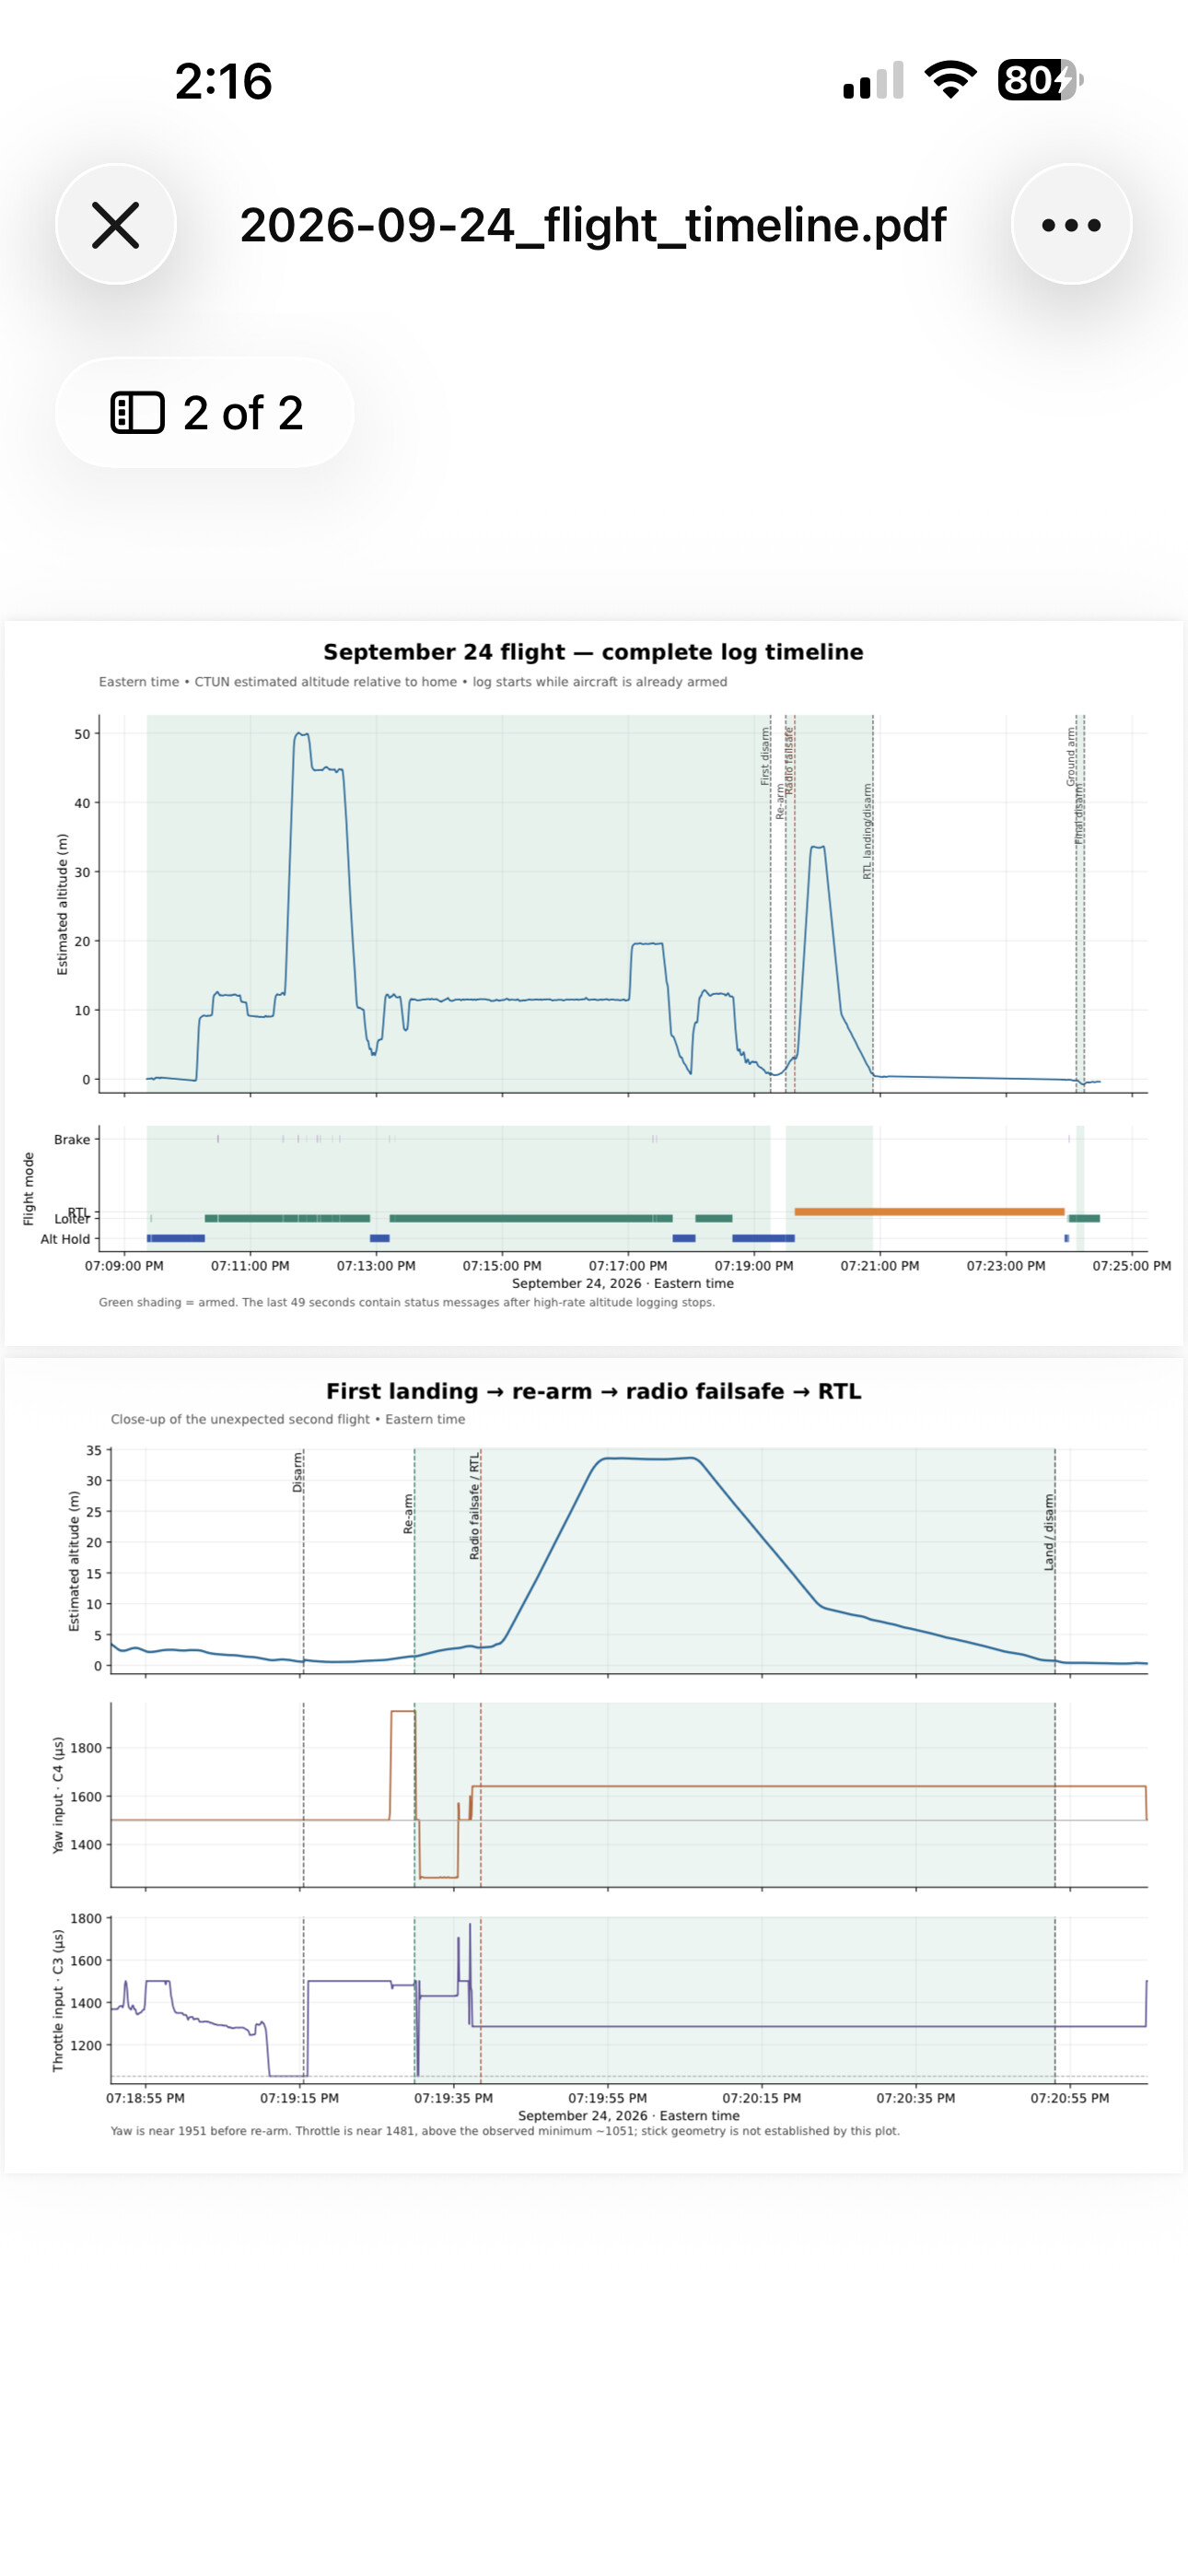
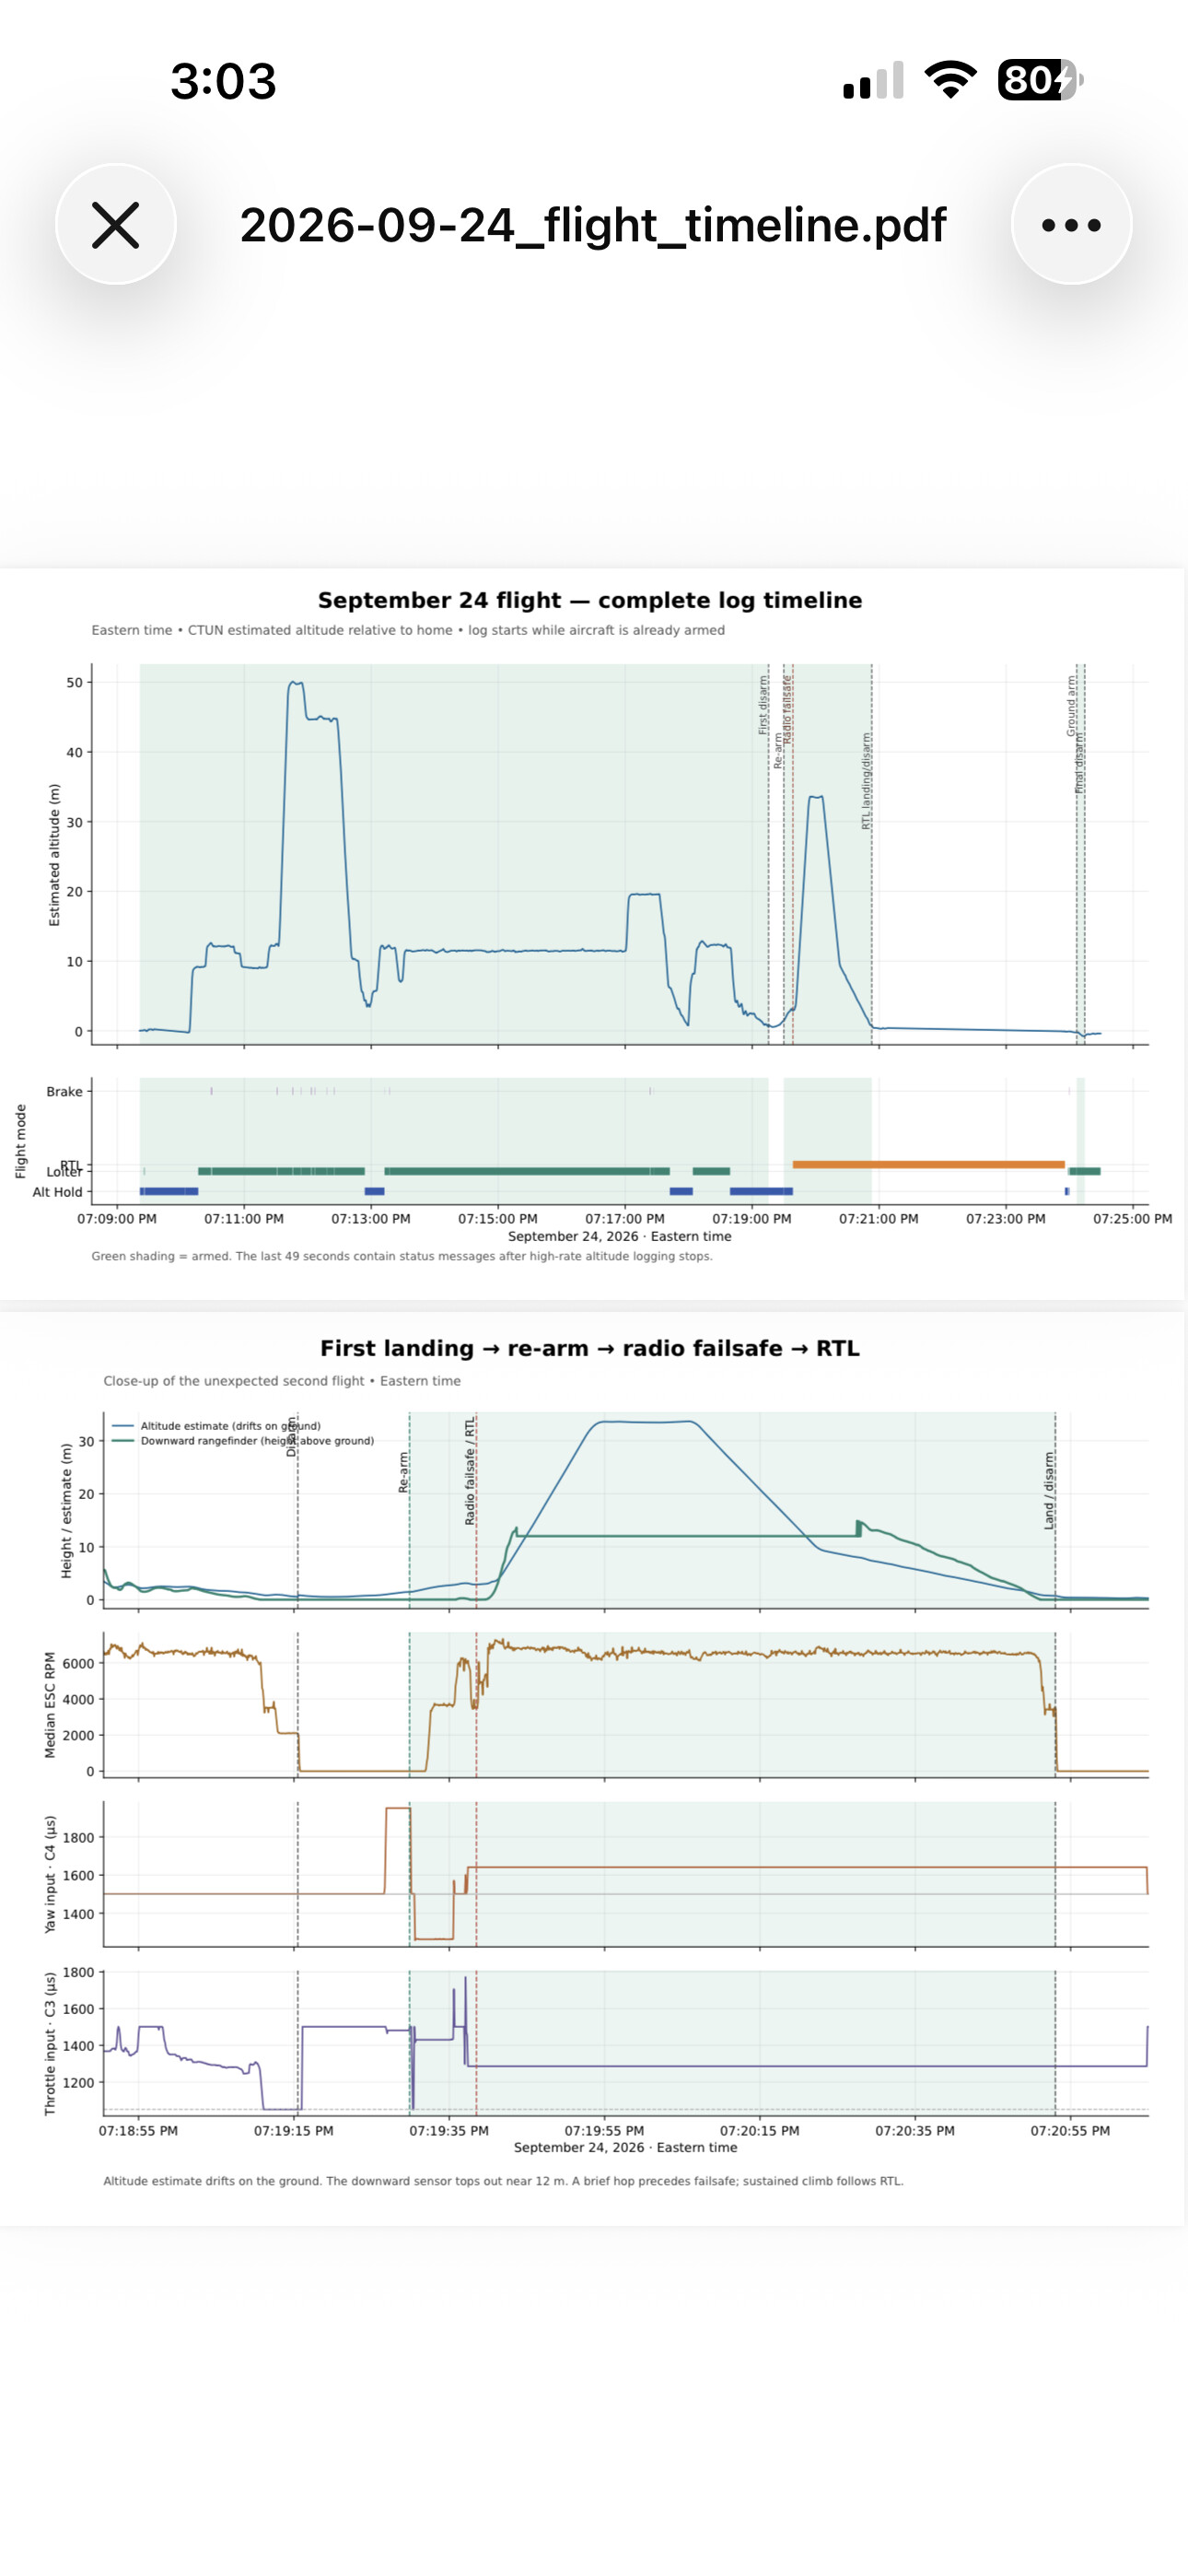
It appears that I did do a successful disarm after the first short TestFlight, and it looks like after powering off the remote control when I placed it into the pelican case faced down, it must not have been fully off because the throttle joystick was moved to a position to apparently rearm, but the question still remains if the throttle were in a state at approximately 5 o’clock, which would be my arming position and it remained that position that would not have been sufficient throttle for it to takeoff so the question is it looks like it armed, but the radio fell safe actually is what caused it to take off and go to the height, overwriting the joystick position. I’ve attached ChatGPT graph. After the automatic land after the radio fail safe takeoff in landing. I did another arm and immediate disarm.
My conclusion is that when I place the remote control down to power was still on sufficiently for the joystick to work, even though the screen was turned off, and by pressing the joystick to a certain position for the throttle and YAW, it caused a re-arm. The mystery is that the throttle never exceeded 1400 and for a center detent remote control you must push it above 1550 and higher on the throttle to get it to take off the ground. As you can see the throttle never exceeded 1400 so the only way that it left a ground was with RTL in control. But why would RTL have an effect when it never left the ground? It seems like a very dangerous possibility in the software.
Because it was not “Landed” it was at Land Complete Maybe then the FS occurred.
The aircraft was physically on the ground, but the radio failsafe occurred during the short interval where ArduPilot had only reached “LAND_COMPLETE_MAYBE,” not full “LAND_COMPLETE.” RTL therefore won the race against the land detector.
I just think it’s very strange that there’s some condition by which the drone can takeoff by itself under an autonomous mode with one exception being a takeoff command. It’s extremely dangerous that aI just think it’s very strange that there’s some condition by which the drone can takeoff by itself under an autonomous mode with one exception being a takeoff command. It’s extremely dangerous that a loss of signal while armed can cause an RTL to send a drone up 100 feet. Maybe there is some LUA option I can create that would force disarm if there was an RTL flight mode received during one of the rangefinders being under a few meters. Or maybe there’s some other Status Status flag that indicates that the drone is currently landed and capital I capital F drone is landed and IF flight mode equals RTL then disarm
Land detection is not a simple thing. Done wrong it could disarm in mid air. Even with the algorithm in place today that can still happen although it’s rare. Your craft did what Arducopter was configured and expected to do.
I think what you are saying is the quad was powered on and then you turned the radio off. If I’m reading this correctly, this can make issues. I always if i can remeber I power down the craft not disarm then power down the radio. Could be you have experienced a failsafe.
Normally this requires the throttle to be moved to center position, I not sure if this is still a option. I can take a look.
“extremely dangerous that a loss of signal while armed can cause an RTL” Well not really this happens if your radio has a loess of power like a low bat. In one case years ago I needed to power off my radio to get a RTL after I lost the drone back in the day with a Nasa FC. The drone thought for a sec and came home.
My controller throttle stays in the center. It must go to 5 o’clock to arm. Then you just push above center to lift off. It just sits on the ground. At or below center. The drone took off after accidental arming and loss of signal since the radio was in the process of turning off when the throttle got moved unknowingly to arm position. I would just not expect that after a disarm and motor shutdown there would be any ambiguity about whether it was landed vs landed maybe. There should be no case where after disarm and motor shut down that upon re-arming and ANY fail safe that the drone should take off except for a takeoff command or throttle move up. My drone took off with RTL signal loss failsafe. That is a very scary thing When your drone takes off and your radio is off and you are trying to turn it back on while the drone is going up and away. Maybe gps drift pushed it over but it corrected after. Very lucky it landed back correctly. Motor shutdown should force landed status if the argument is that it was still in a maybe state from the previous test flight.
I understand how scary it is/was for you. In the future make sure the craft is off i.e remove the bat then power down the radio… I just looked at Auto flight mode I can’t get it to engage on the tarmac with only using the throttle like in older firmware. I think you have to be in the air…
Actually you can set a parameter that will allow arming in Auto mode and NO throttle increase to start the Mission. Auto_options. Been around since 4.1 But if it didn’t start the Auto Mission when you raise the throttle that could be due to a few different issues.