Hello,
My quadcopter (10" frame, 7" propellers, ArduCopter V4.6.3) generates vertical vibrations when it is flying, and even when it is supposed to land slowly: the expected path downwards is regularly modified by short bursts of power.
I hear a specific noise at, say, 4 Hz, and the drone clearly vibrates around the vertical axis.
Propellers are new, motors are clean, the FC (DakeFVP H743) seems gently fixed.
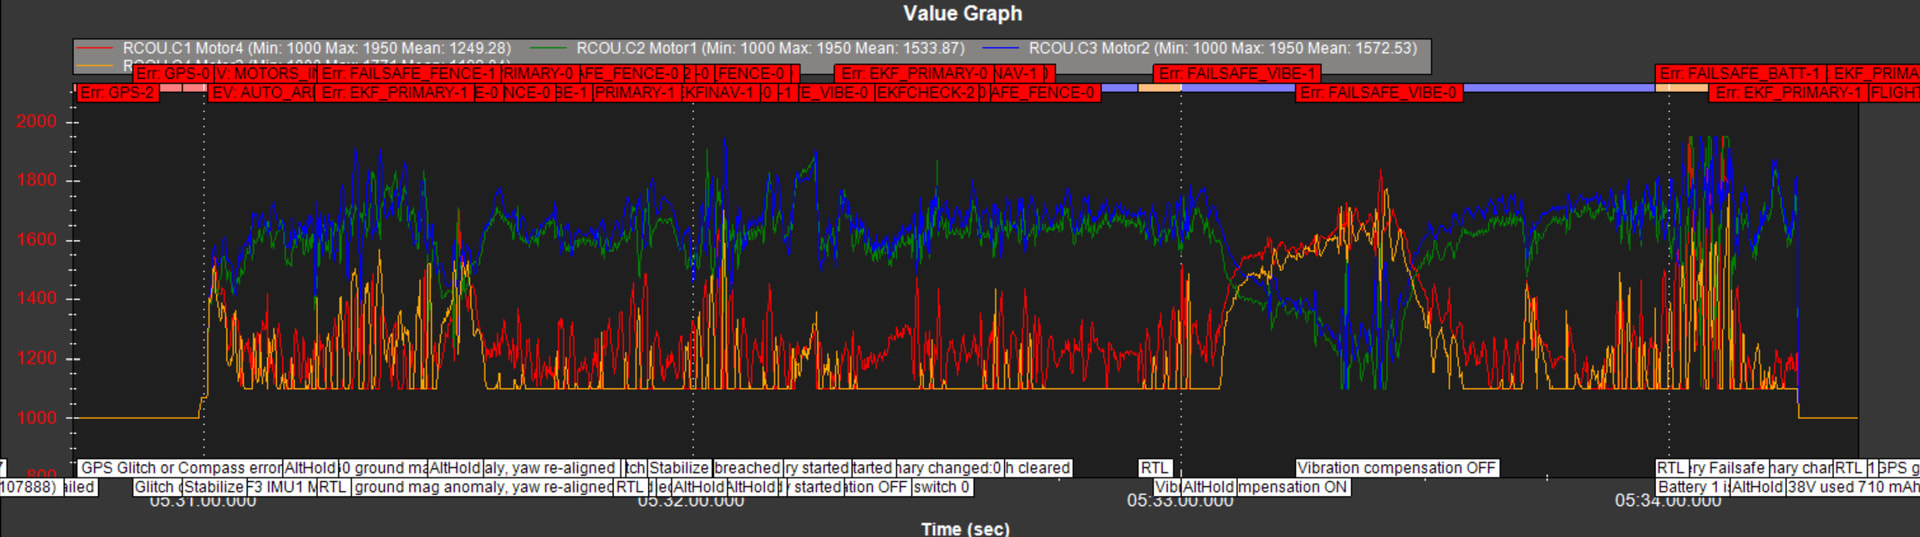
I looked at RCOU and discovered that ONE of the 4 motors regularly dropped at 15% of its speed (the minimum in flight), whilst the other motors had a decent speed.
So I recalibrated the ESC… and now, all 4 motors drop at 15% one after the other. So of course the drone vibrates…
Also, CTUN.ThH is stable at 0.126 , and CTUN.ThO moves around 0.1.
VIBE.X was around 30, VIBE.Y around 70, so I added a filter
INS_HNTCH_ENABLE = 1
INS_HNTCH_MODE = 1
INS_HNTCH_FREQ = 80
INS_HNTCH_BW = 40
INS_HNTCH_ATT = 40
I thought (well, ChatGPT suggested) that the drone may be under-weight: putting all motors above 15% power would push the drone upwards ; so it would decide to stop each motor one after the other.
So I added some weight to the drone, but it does not help:
the 4 motors drop to 15% one after the other: every second or so (the 4 Hz I mentioned may be due to 4 motors at 1 Hz each)
the motors seem to have similar behaviors by pairs : Motors 2 + 4, and Motors 1+3, have “saw” shapes: 15% up to 70%, down to 15%, one pair after the other.
CTUN.ThH is stable at 0.2 , and CTUN.ThO moves around 0.2.
Either read and follow the ArduPilot wiki documentation (and stay away from chatgpt) or use ArduPilot methodic configurator software to guide you through the correct and safe configuration sequence.
Your altitude controller is missconfigured and the notch filter also.
Looks like it needs some tuning. There are many params with default values. I see You tried AltHold, but did not do anything with the hoover learning results. First - use stabilize and decrease value in Basic Tuning and check if it oscillates. When it stops, then follow with alt hold and learning hoover.
After that PID tuning - there are many ways, easy is quick tune, autotune also is not bad. You can do it also manually using pot from transmitter.
That is a bit simplified, but general way I do it, and more or less docs describe.
Yea, you have quite the mess with the parameters. Some are are not suited to a 7" propped craft and others are not set at all. You have some serious Yaw bias going on.
Thanks a lot for these inputs.
Basically, I moved to ArduCopter 4.7, revisited parameters but I kept most of them similar, and when I went out for a tuning test, the flight was far far better than previously. So I can follow the tuning track now.
I must admit I don’t really know what I changed,..Most parameters used to be the “default suggested” ones and still are.
Anyway, thanks a lo!
And once again the robustness of the ArduPilot firmware, prevents a user from finding out how good a well tuned drone flies.
In other words: the firmware is so good that most users are happy with the performance of the default values. Unfortunately that prevents them from finding out, how well a properly (non-defaults) tuned drone operates.
Yes I agree.
For the time being, I wanted a flyable drone (despite it’s being over-powerfull) to test a Precision Landing procedure. Then I will increase the weight with various payloads (requiring PL), so the parameters will change.
For now, I know where to start from.
You do realize You need some tuning to have precision control first?
How You are going to test precision landing to work precisely, when drone is unable to control itself precisely? If it is “flyable” tune at least alt hold properly, notch filters and run quicktune/autotune. Not that hard.
Also testing with payload… too low PIDs can be as bad as too high, as PID may not be able to get enough corrections to keep drone stable and You will crash. Something to think about when increasing payload.
Also vibration/noise levels will increase with payload and if You do not have filters setup they will finally cause drone unsatble enough to crash.
And from my own experience - 5" props can do a lot of harm with skin contact, not to mention larger props, so If You do not want to at least do basic stuff, keep test in some open space
Yes, I agree (again). The term “flyable” was a bit too aggressive…
PL was working already even with my “hops”, but I lost so much time before landing…This morning it was really far far better.
The next steps are:
tune it with no payload, and optimise my PL procedure (I need to adjust yaw and the PL tools on the market don’t enable to do this…)
add fake payloads, and calculate relevant tunings (in case of crash)
when I’m confident, add the real costly payloads
And to complete the story, in fact, I have 2 drones, and I run tests on the one I mentioned here, and then I reproduce the procedure on the bigger drone (10", 400 KV, 1 m x 1 m frame), and the real value payload.
The payload is a 5 kg stick of 2.5 meters length… So it will really not be symetrical. I need to tune all of this step by step…
(And I do run tests in open space, which requires me to drive 30 minutes each way every time, to spend 1 hour of testing before my batteries get dry… Still, since Day 1, I made so many progress…)
AMC is a checklist, indeed helpful, to address all parameters and force to read the documentation (which I tried to do before).
But I have issues with AMC (some bugs; some parameters addressed twice; unexplained difficulties to upload the parameters to the FC ; and it requires a connection to the FC so the motors do Bip Bip after some time…) so I take the parameters list and I address them by hand.
Also, AMC modified some of my Serial configurations, and then the FC then refused to arm…
And some of my equipment require that I “put this parameter to 3”, and AMC proposed options-without-numbers, so I get lost.
Globally also, when reading the web-documentation, I have a kind of feeling that it goes in so many sub-topics that I loose track of the global procedure.
So globally, I use a reproducible method which is following the web-based procedure, addressing the parameters, and going onto Autotune, keeping all intermediate configuration files as references.
A simple way to remove the aggressive wobble for my Pix racer pro is to use the slider control to dial down the PIDs, this will stabilize the craft then you can fine tune it using the recommended software the guys talk about. But this will require you reset your config to default then back down the settings. I did a youtube video that show how this is done. The Pixracer pro is a high quality FC making the small adjustments are not a issue to remove shaking. https://www.youtube.com/watch?v=2YzIqk1vcG4 Notice as i move the slider to the right the craft starts shaking moving to the left removes the shaking. I think you could use a slider to do this in air real time but I land the craft to make the changes. Works well and is fully tested with the PRP in flight and tested in Realflight respectfully.
 )