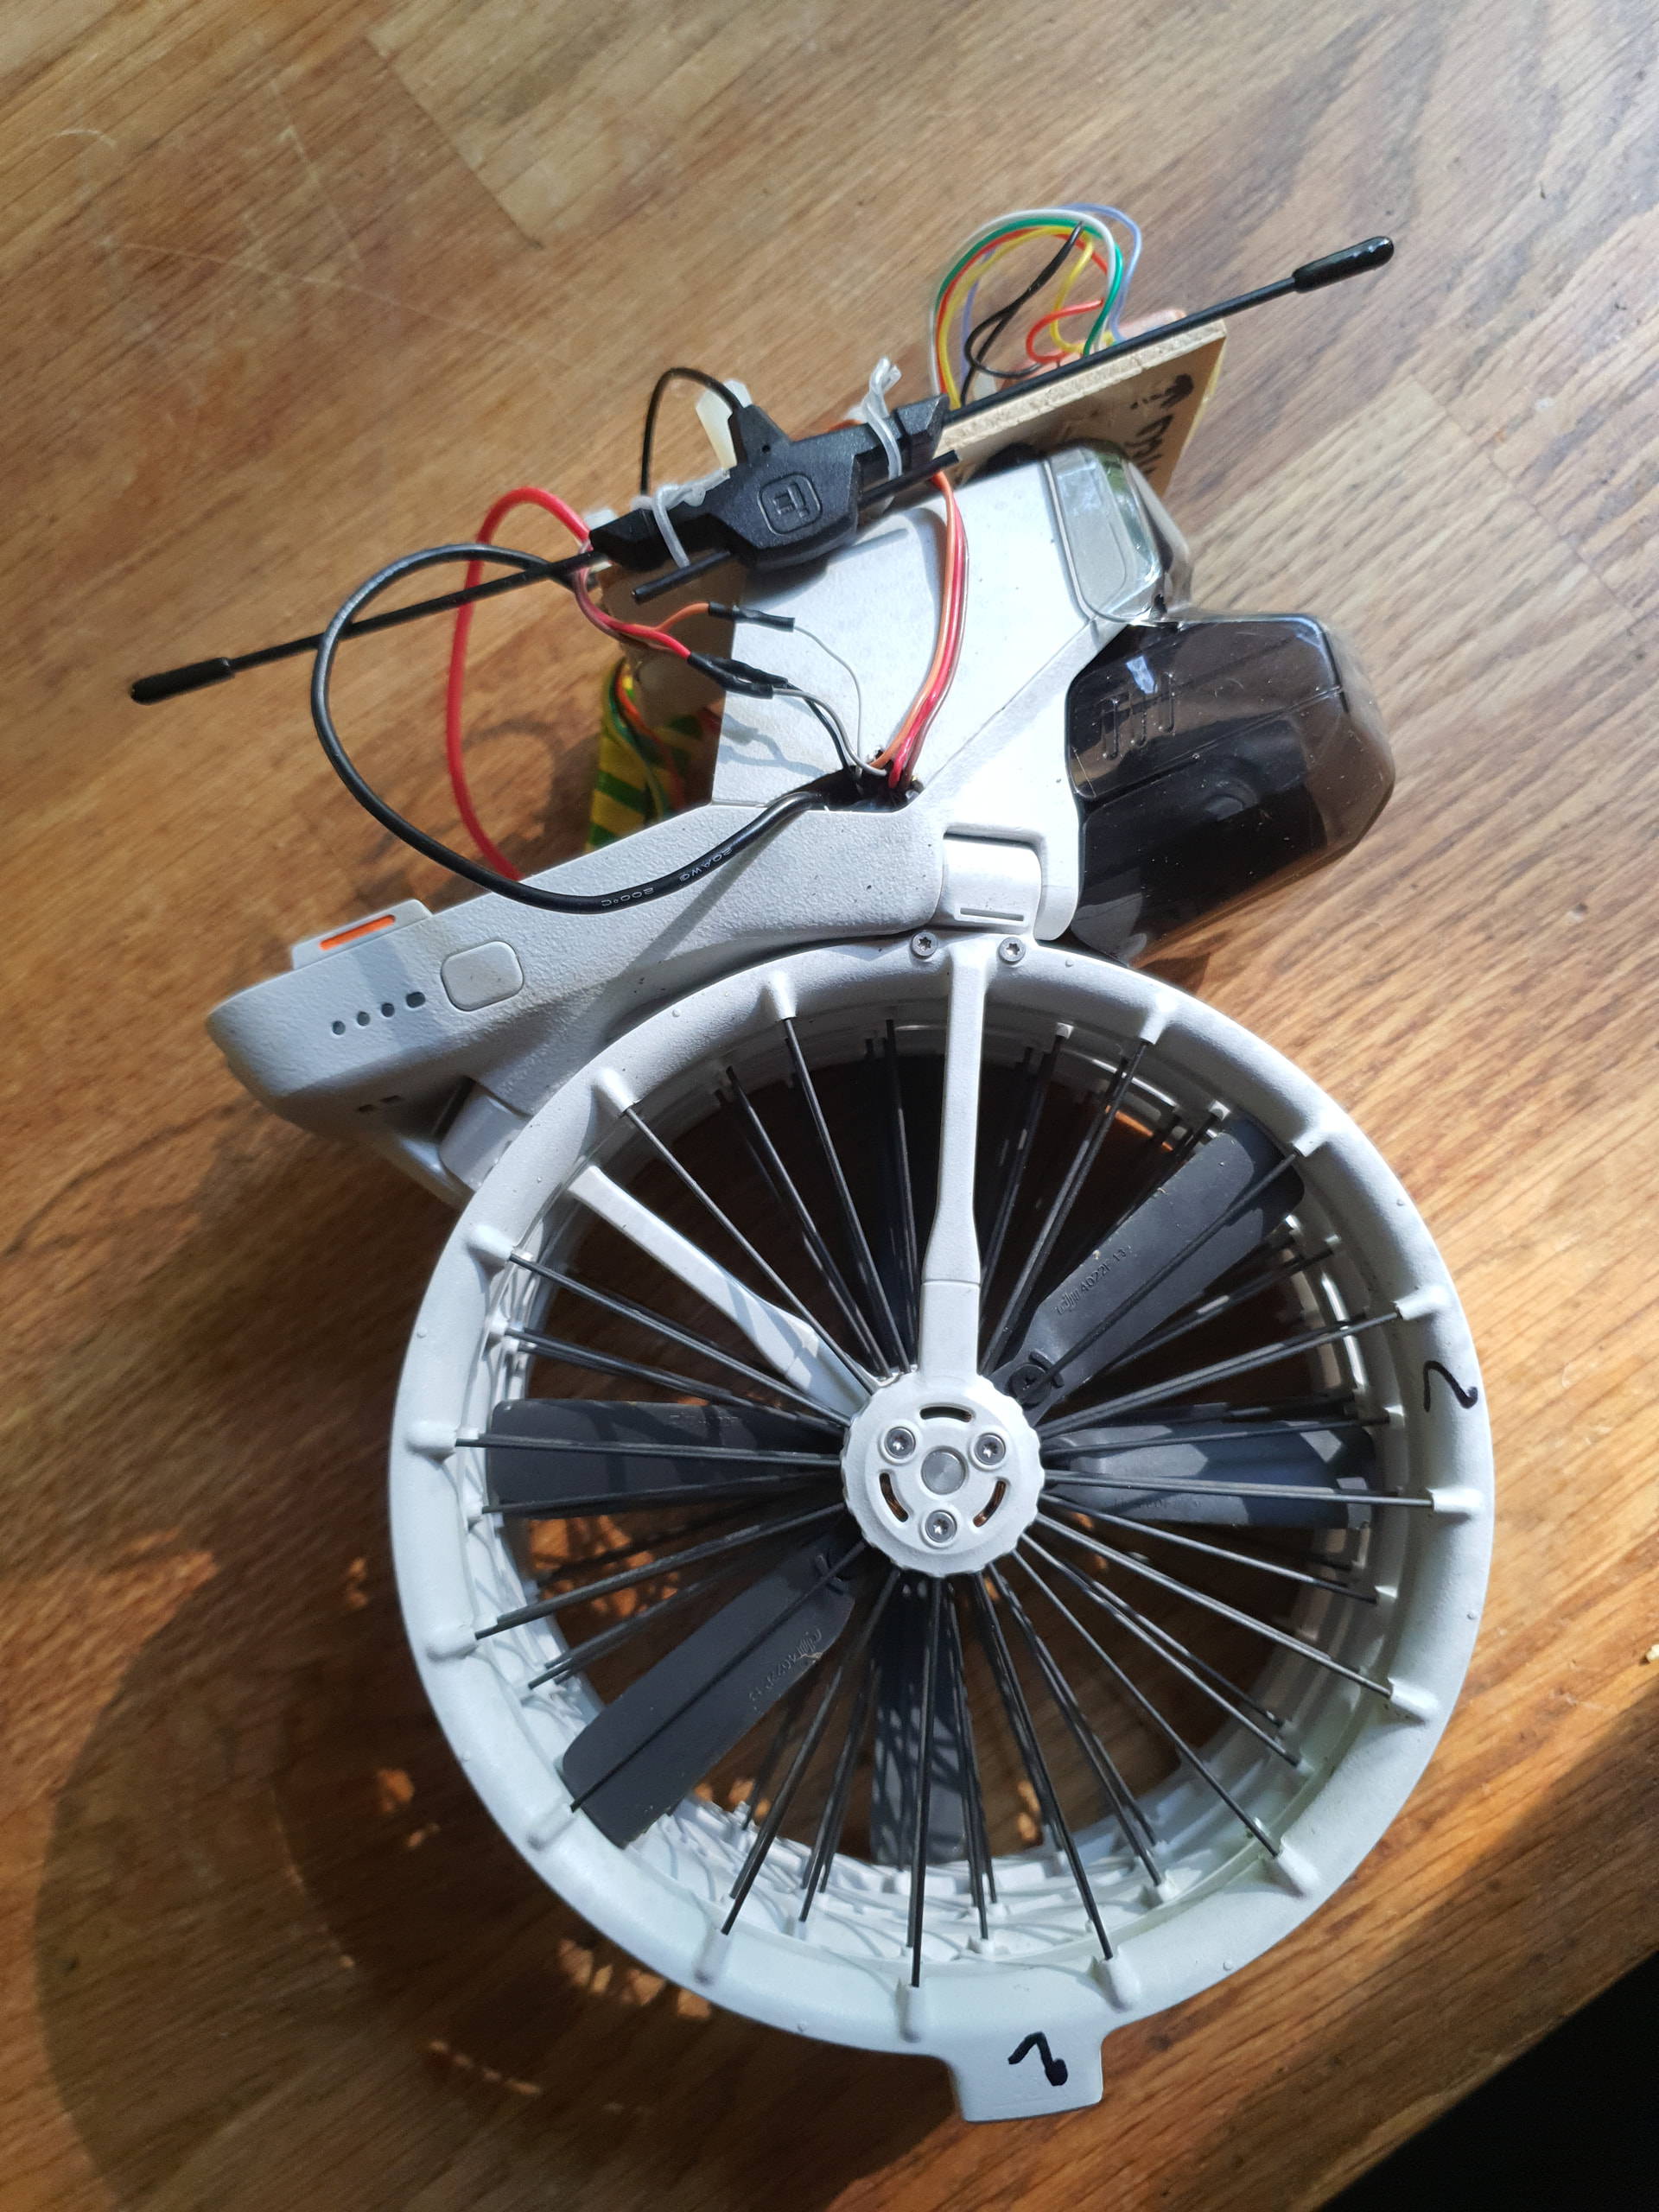
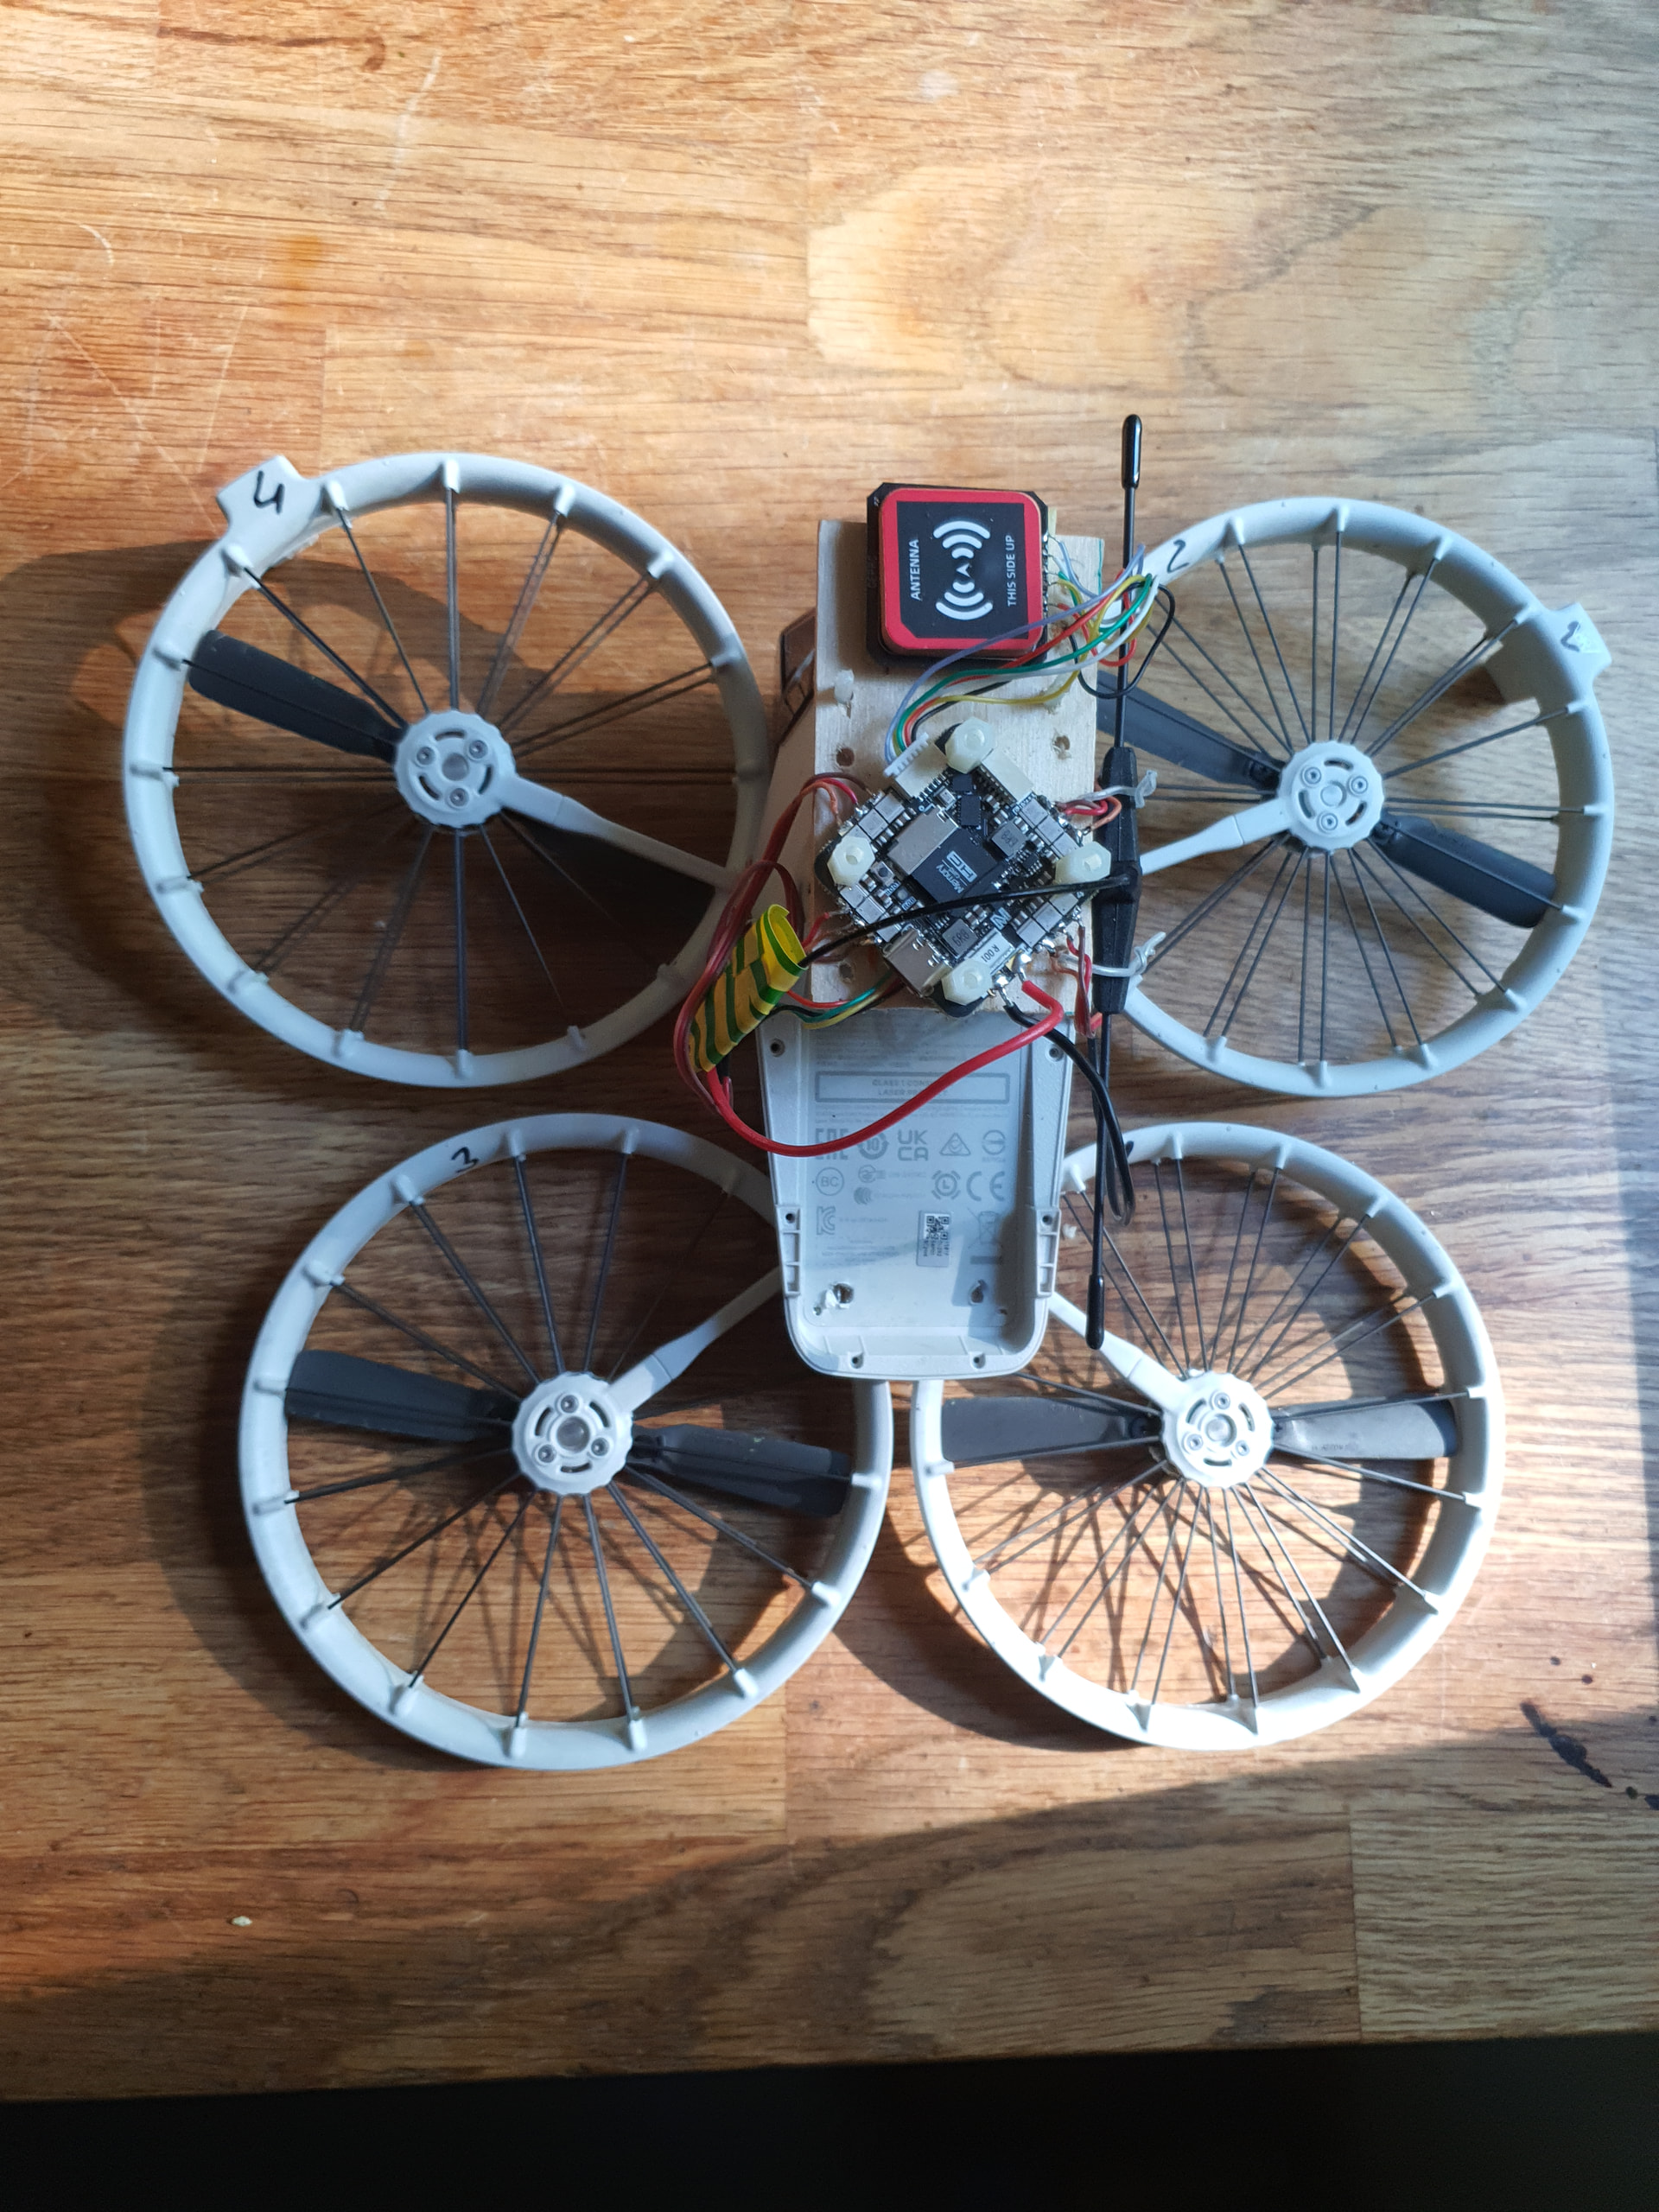
Photos explain (almost) everything. I think it’s very cost-effective, compare it to say GEPRC MOZ7 - for less money you get gimbal+decent video, and even a battery  Many DJI copters are sold crashed/damaged.
The FC is Micoair H743 AIO V2.
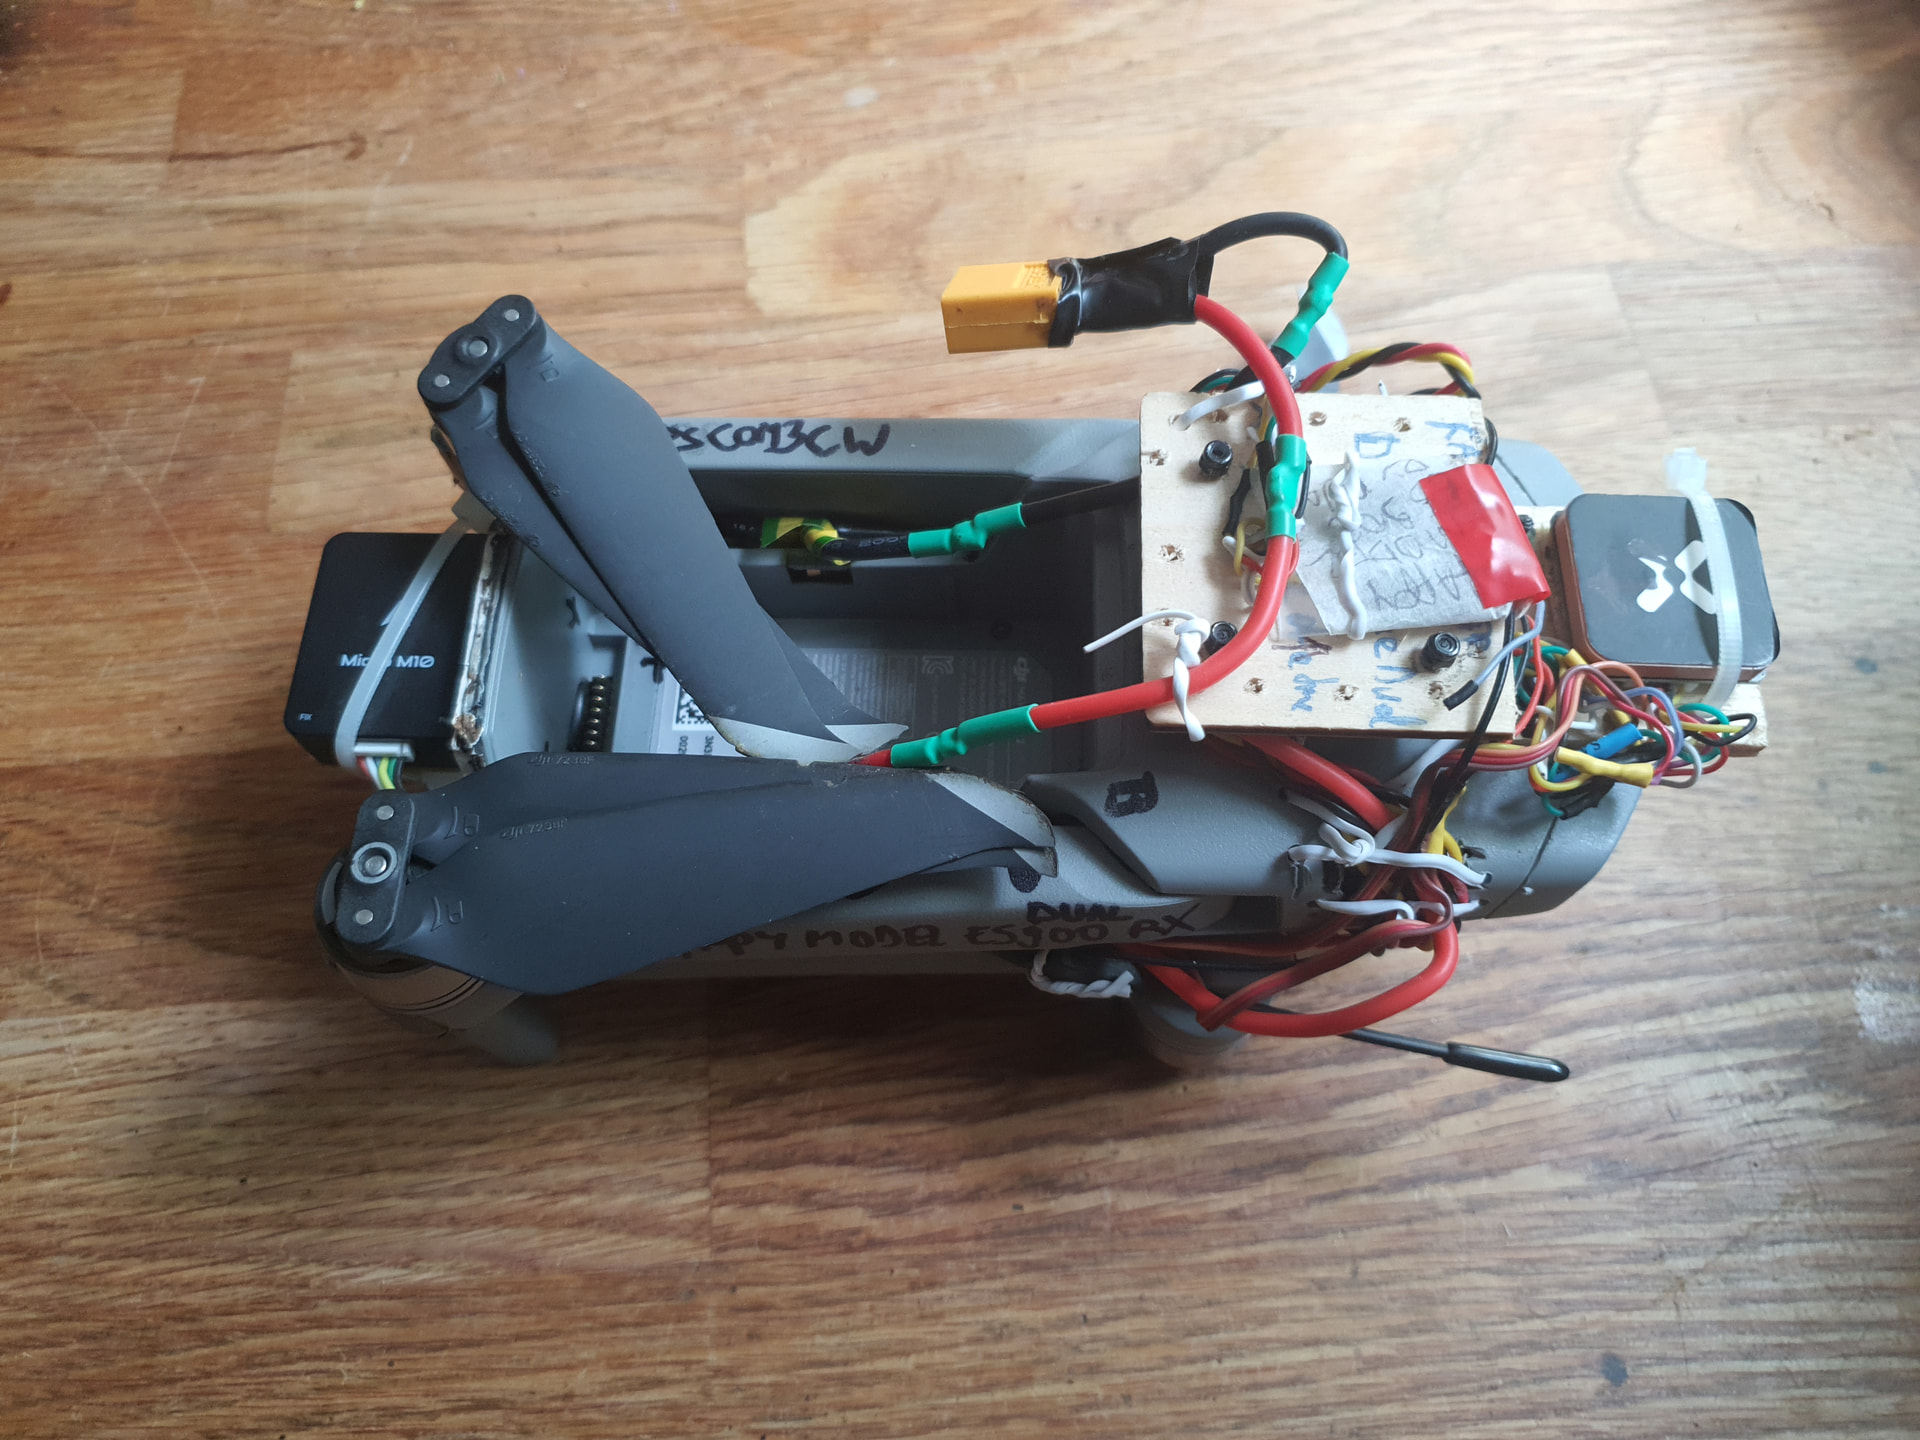

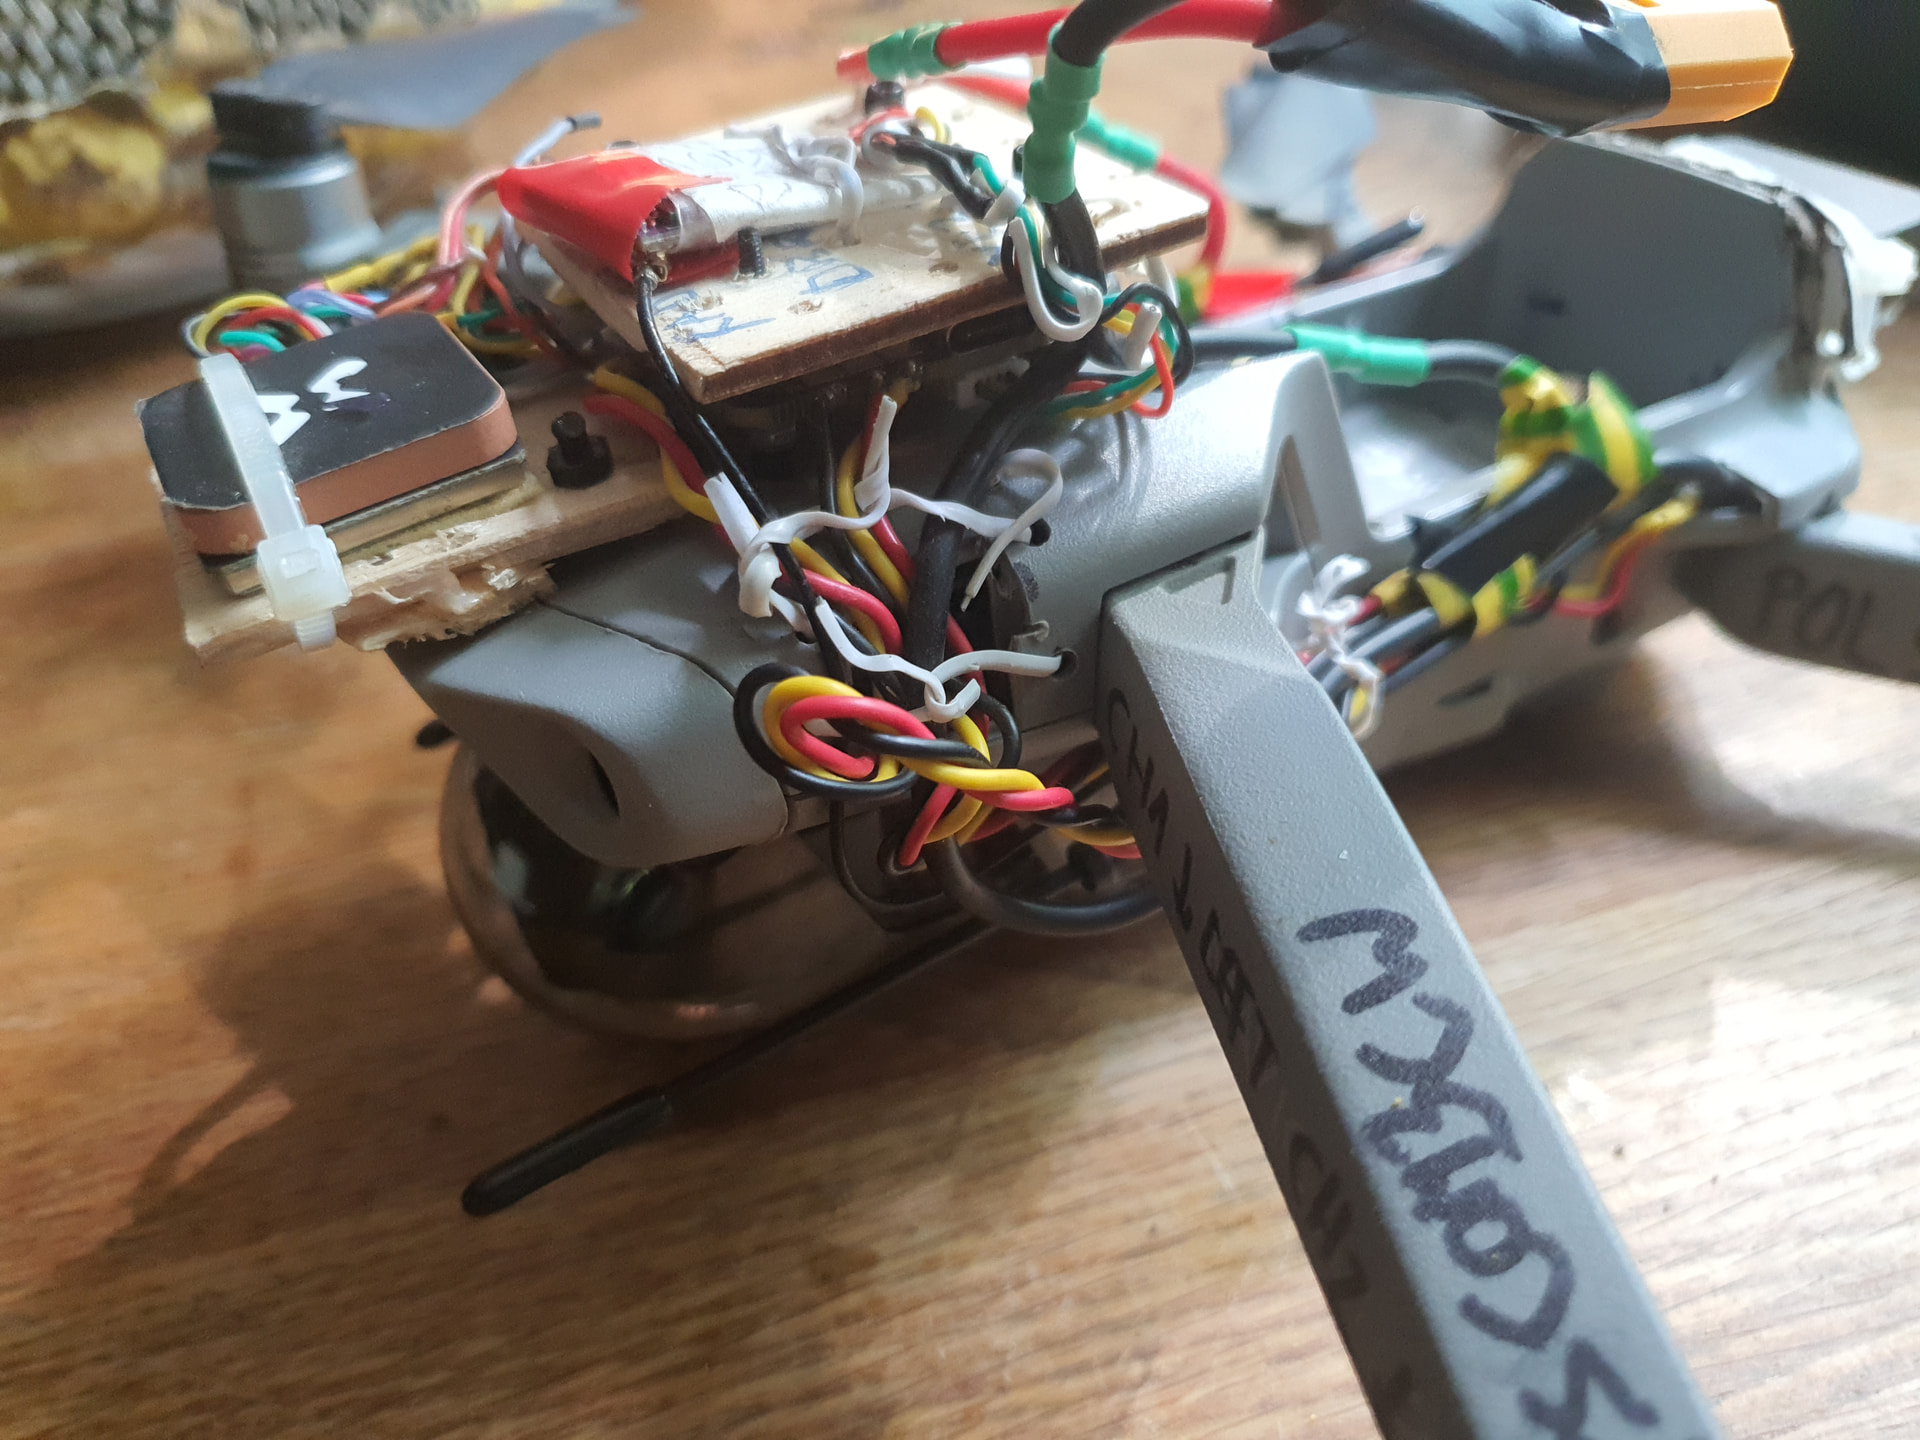
There are two GPSes, maybe it’s an overkill. In the next build I’ll stay with a single one.
Some trouble with routing wires, so that it’s still foldable. But flies fine.
ELRS is 868 MHz, because of the strong video link ELRS 2.4 GHz does not work. In theory, it is possible to set the video link to 5.8 GHz, but it’s less range and it sometimes switches back to 2.4 GHz.
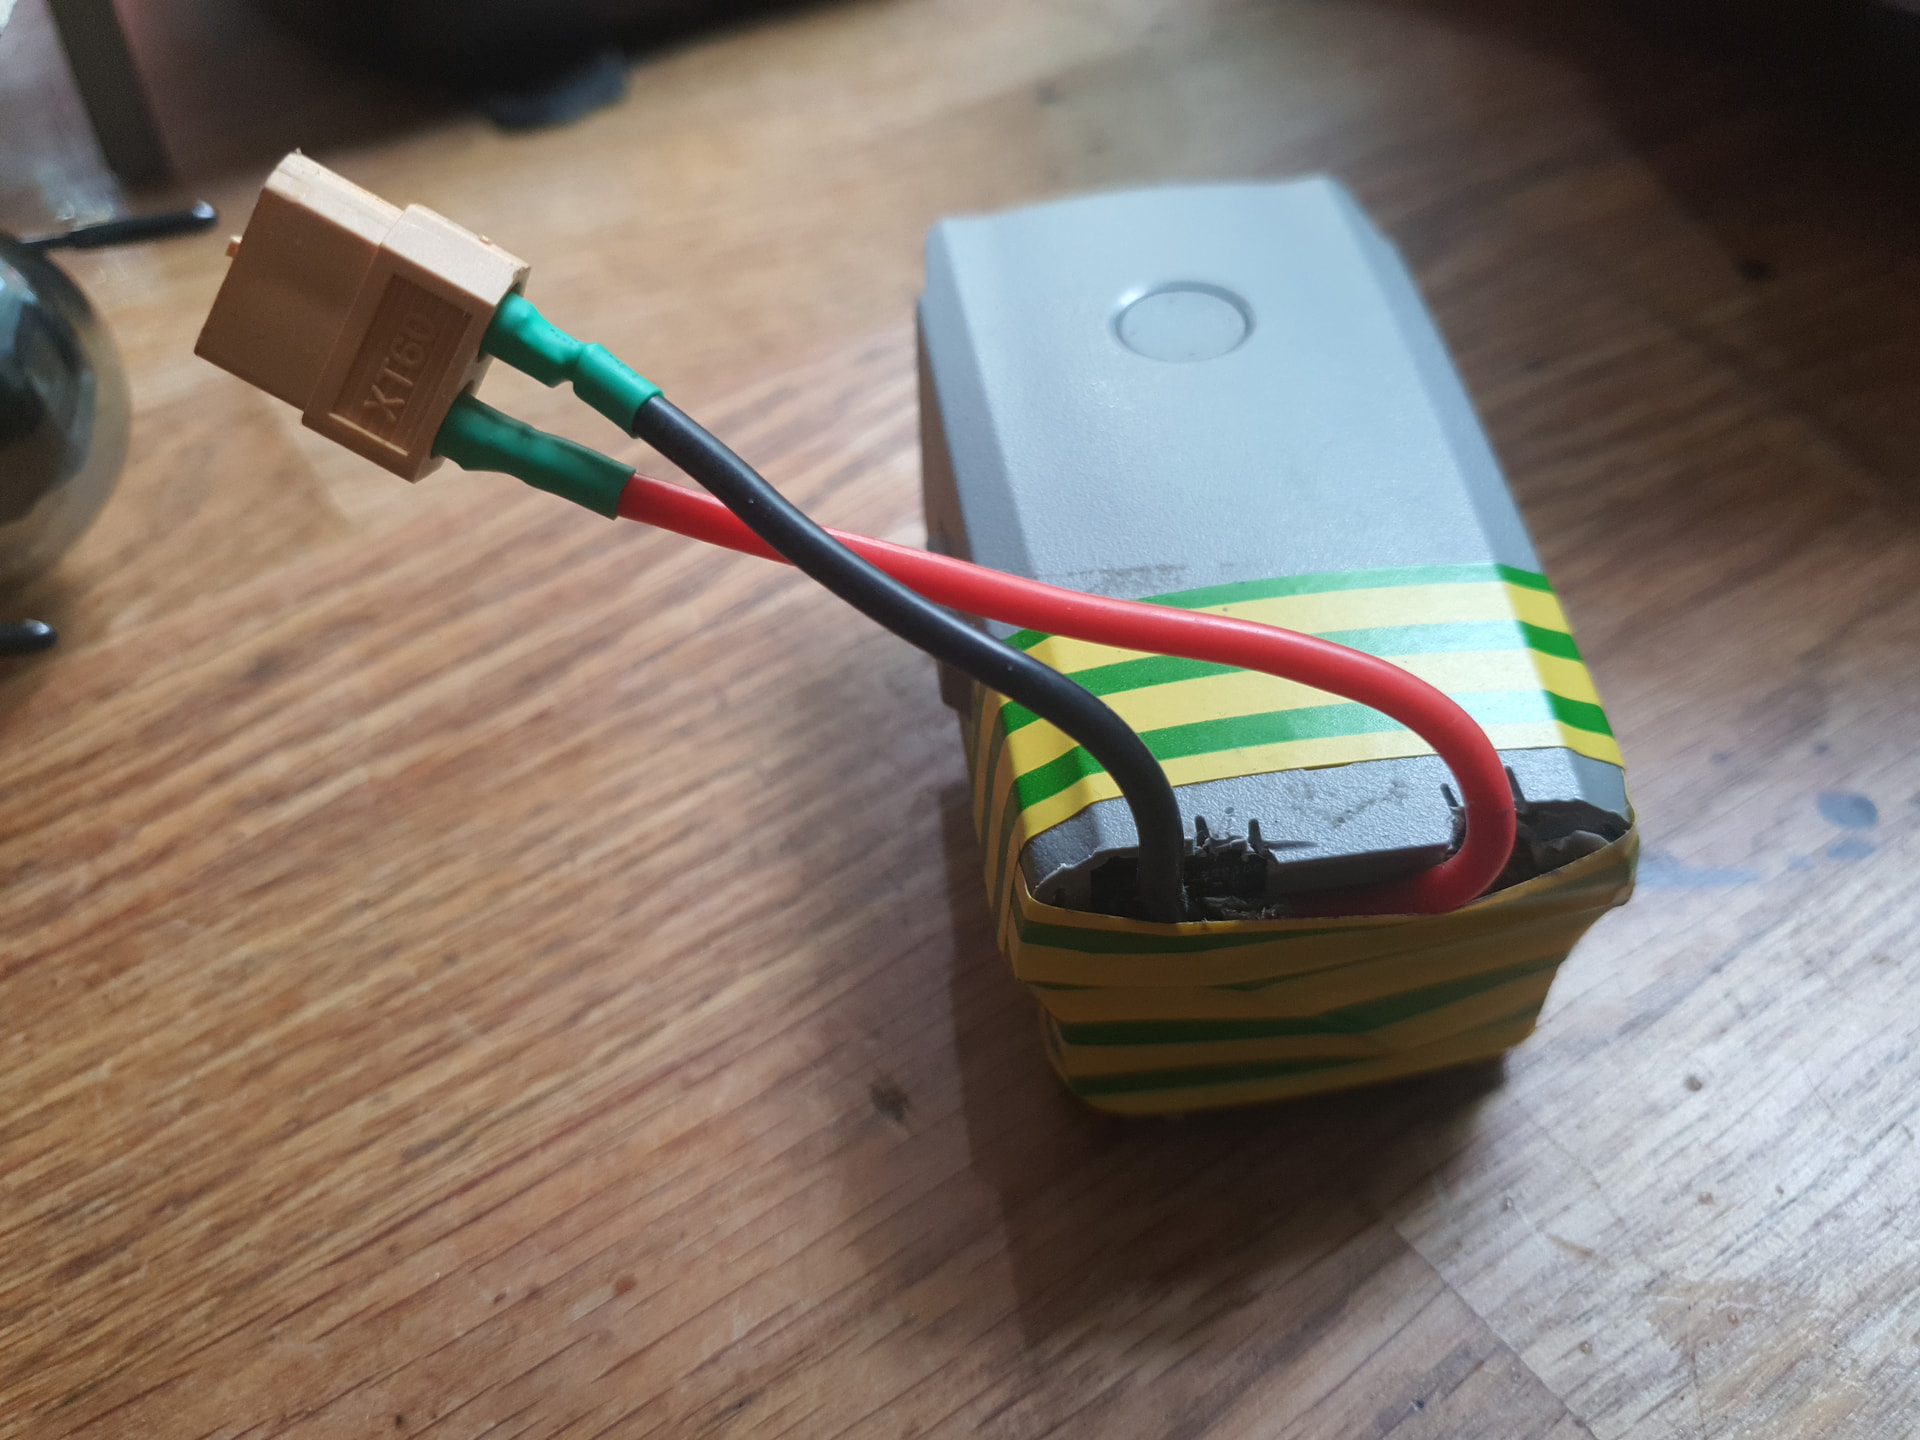
I had to solder the power connector directly to the battery’s pads, that’s the hard part because these pads are made of some kind of inox and soldering does not work easily. I’ve used a special liquid agent for soldering aluminium/inox, this must be reliable - test it by pulling the wires. On the copter’s ESC board, there are special round pads with +/-. After removing the top cover, I’ve added 4 holes and screws with spacers, holding two plywood pieces. The FC is on the lower floor, above it the ERLS rx. Bypassing the battery controller is necessary, because it switches off after a couple of seconds when under load. The motor wires are soldered directly to the FC motor pads.
Batteries can be charged in the normal way, no need to add a balancer connector.
I have not disabled the motor stuck protection in AM32, and one of the motors has some problems with starting, I need to fold the propeller in the direction of the rotation. But this is a minor issue.
Here I describe some problems with precise tuning, you can see some logs.