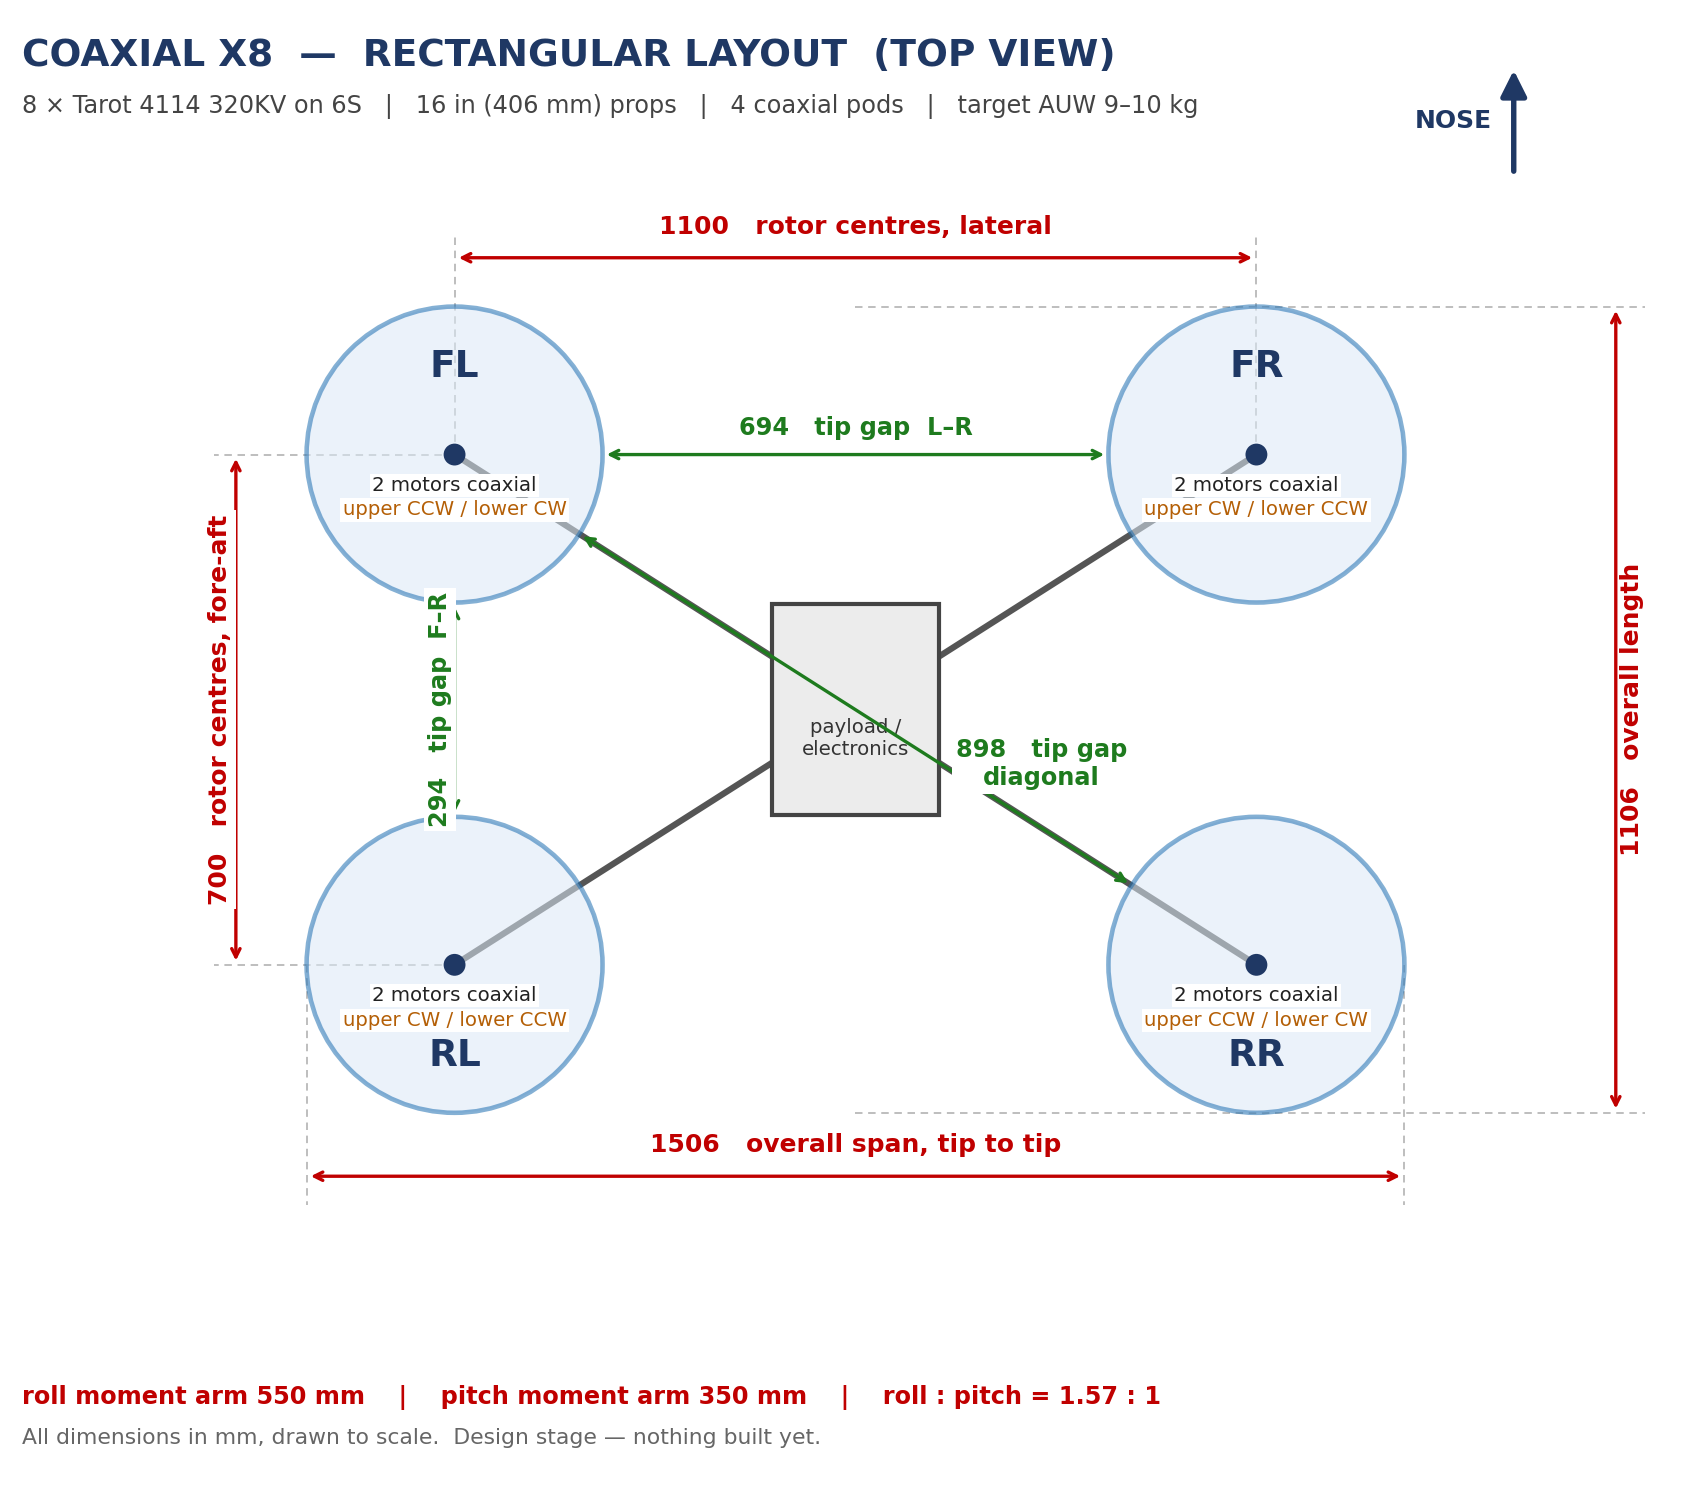
First-time large-multirotor builder, looking for a sanity check before I cut metal. I have the motors and I’d rather find out now that I’ve picked wrong. Not flying yet — still at the design stage, nothing built.
The airframe
8 × Tarot 4114 320KV on 6S, arranged as 4 coaxial pods (2 motors back-to-back per pod, counter-rotating)
Tarot 1655 16" carbon folding props
Cube Orange+ / ArduCopter
Target AUW 9–10 kg
The layout is a rectangle, not a square or an X:
rotor centres: ±350 mm fore-aft, ±550 mm lateral
→ 700 mm front-to-rear, 1100 mm left-to-right
→ roll arm 550 mm, pitch arm 350 mm (ratio 1.57:1)
prop tip gaps: front-to-rear, same side 294 mm
left-to-right 694 mm
diagonal 898 mm
The rectangular proportion is fixed by a structural and payload constraint I can’t change, so “make it square” isn’t available to me.
Estimated thrust: assuming a coaxial efficiency factor of 0.80–0.85 (from published rotor literature — I have not measured it), I get ~4.3–4.6 kgf per pod, ~17–18 kgf total, T/W around 1.7–2.0. I’m building a load cell stand to measure this properly before I buy anything else.
My questions:
Motor mix. OctaQuad X assumes symmetric arms, so its roll and pitch factors come out equal. With a 1.57:1 arm ratio that seems wrong. Do I need a custom mix (Lua scripted mixer?), or does ArduPilot scale this correctly if I just set the frame class and tune? What’s the current right way to do this on 4.6?
Roll:pitch ratio. Is 1.57:1 controllable with normal tuning, or does the short pitch arm become a real problem — sluggish pitch, Autotune struggling, or worse?
Coax spacing and loss. I’ve designed 83 mm between the prop discs — 20% of prop diameter. Is that a sensible spacing for 16" props, and what thrust loss should I actually expect? Is 0.80–0.85 realistic or optimistic?
Margin. Is T/W 1.7:1 enough for someone flying their first machine this size, or should I design in more headroom before I commit to the frame?
Anything here that’s obviously wrong and I can’t see it?
Happy to share thrust data back once I’ve measured it.
There’s lots of rectangular frames out there. The tuning process will take care of that.
1.7:1 sounds under-powered. Run the numbers through ecalc.ch and see what it comes back with, but I think you’re not going to be happy with that ratio. It will fly, but you’re not going to have a lot of head-room for control or performance. I say you need to be at least over 2.
Thanks Allister, that’s genuinely useful — and the layout answer is a relief. I’d half convinced myself the 1.57:1 ratio was going to be a problem, so it’s good to hear tuning handles it.
On the thrust margin, you’ve pushed me to recheck and it’s actually worse than what I posted. I’d left the arm clamps out of the mass budget. Adding them (~0.6 kg for the set) takes AUW to about 9.8 kg, so I’m at roughly 1.8:1 on my assumed numbers — and that assumes a coaxial efficiency of 0.85, which I’ve never measured. If the real figure is 0.75 I’m down around 1.55:1. So the whole plausible range sits under the 2.0 you’re suggesting.
I’ll buy an xcopterCalc subscription tonight and run it properly rather than keep arguing with my own spreadsheet. Nothing is bought beyond the motors, so changing props or trimming weight is still cheap for me right now — which is exactly why I posted before ordering.
Two things from my original post nobody’s picked up yet, if you or anyone else has a view:
1. Motor mix. OctaQuad X derives equal roll and pitch factors, but my arms are 550 mm roll and 350 mm pitch. Does ArduPilot scale that correctly from the frame class, or do I need a custom mix — and on 4.6 is Lua scripting the current way to do that?
2. Coaxial loss. I’ve designed 83 mm between the prop discs (20% of prop diameter) on 16" props. Is that a reasonable spacing, and what loss would you expect in practice? Everything I have is from published rotor literature rather than anyone’s measured data.
I’m building a load cell stand to measure a full pod properly, and I’ll post the numbers back here when I have them — there doesn’t seem to be much real coaxial data around for this size, so it may be useful to someone else too.