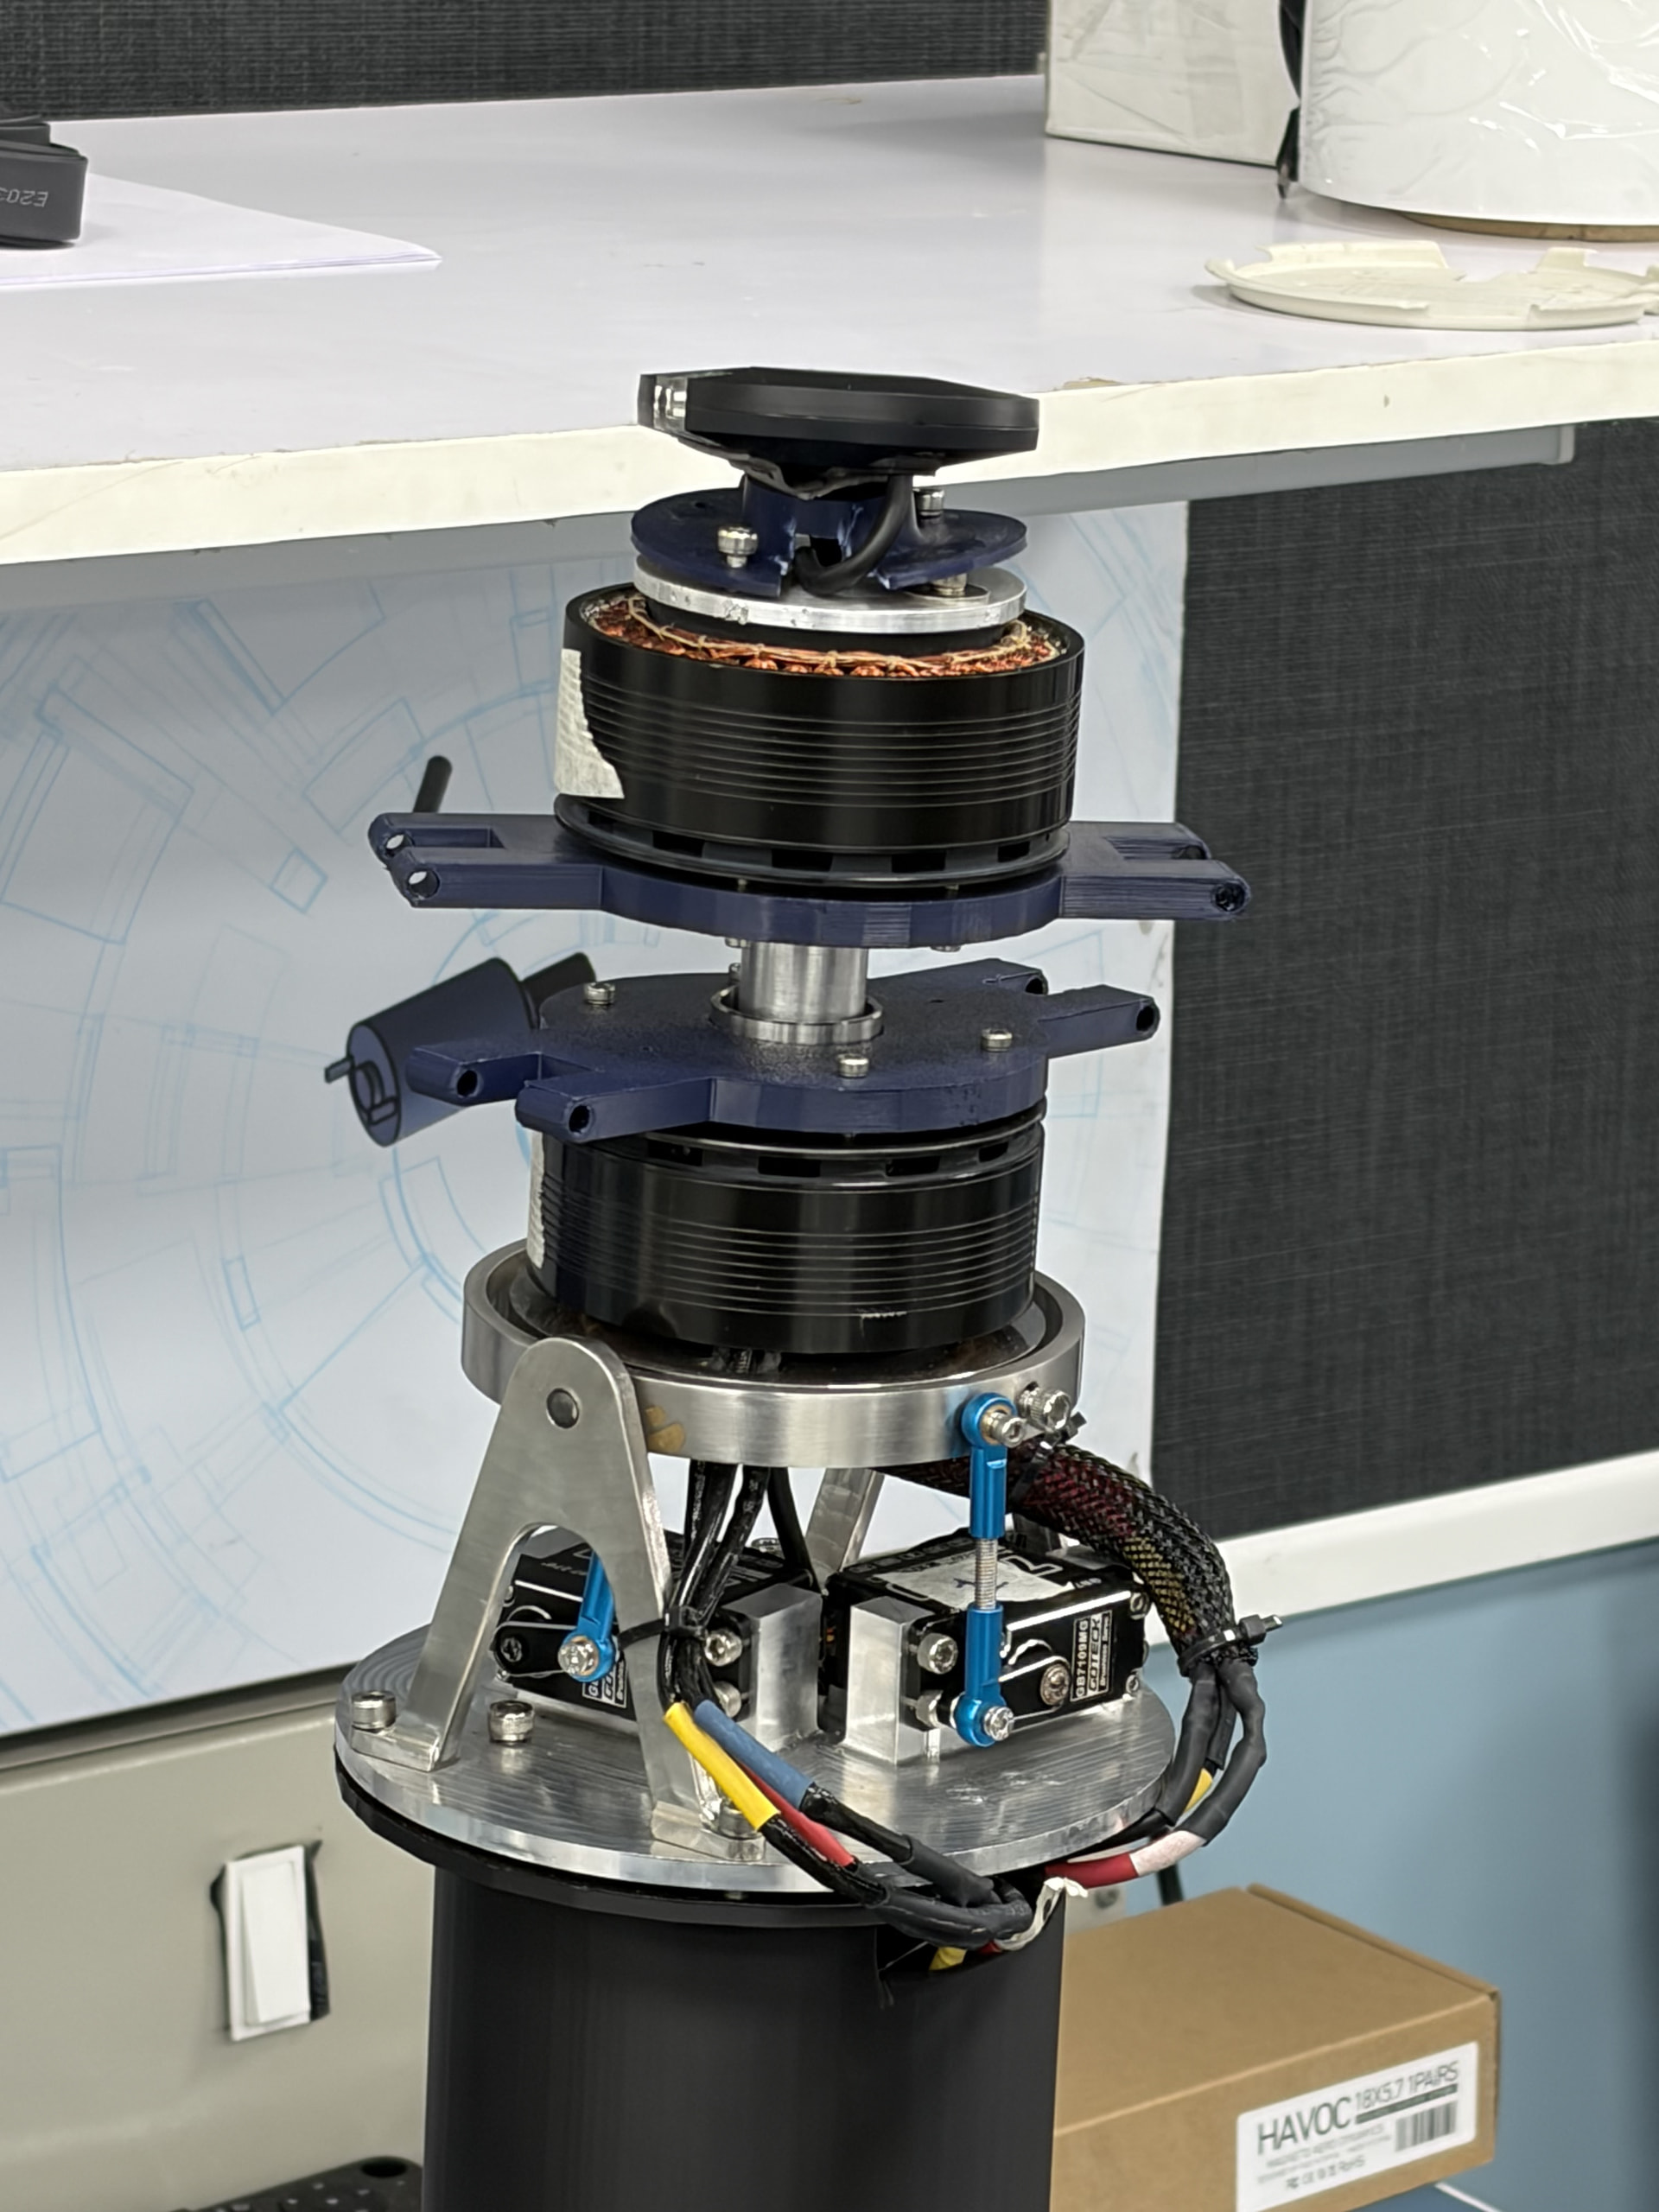
I am building a CoAx-Copter with gimbal controls for roll and pitch. as far as I explored the ardupilot documentation of Copter setting a frame class = 9 is only for the coax copter with flaps.
I would like to get some help on configuring my coax copter which build for an AUW of 20 kgs where the roll and pitch is controlled using a gimbal setup with servos for each axis. And yaw I am planning for the differential RPM & torque no servo setup for it.
Currently it’s in Frame class = 1 and frame type = 1. Basically the quad configuration.
Could anyone help me with sorting out and configuring my copter well ?
The frame code behind this option implements what is known as small angle approximation (where, for an angle x in radians, sin x is considered to be equal to x, and cos x is considered to always be 1). If your gimbal system is linear enough and outputs up to 15 degrees or so, this will do just fine.
There is a caveat with the current frame code which is applicable to machines with large thrust-to-weight ratio though. In coax copters, servo outputs should be scaled inversely to the throttle. The current code does this, but only if the (linearized) throttle is above 0.5. This was, I guess, written this way to avoid divisions by zero and too fast actuator outputs for the low throttle regimes (and also when on the ground barely spinning) - and is in line with similar throttle scaling in planes, which is by default in [0.5; 2] there - but it leads to certain issues when the machine is powerful.
I have developed a slightly better version of the coax frame code with regards to the first issue (and other small quirks), and am (way too slowly) working towards an even better version which will explicitly consider limited roll/pitch actuator performance. I will, of course, eventually contribute this to ArduPilot when it’s sufficiently ready. If you wish, I can build this one for you (and possibly customize, if your actuator is trickier than I think) and consult, for free of course, in direct messages on what to do with it.
Thanks for the response. But the main issue is when i change the frame class = 9. the FC is not initializing and I am unable to find out the issue with that. when I change back to quad its working good and its initializing. And the system is armable and connecting with GCS via herelink airunit.
This surely was not clear from the initial post, and surely needs more information. What are the flight controller version, the ArduPilot version, and the exact messages at startup which indicate the problem? (For the latter, screenshots of your ground control software should hopefully be sufficient)
Flight controller used is the Cube orange plus mini, Ardupilot version is the latest stable version of it. And about the messages I will check and revert back.