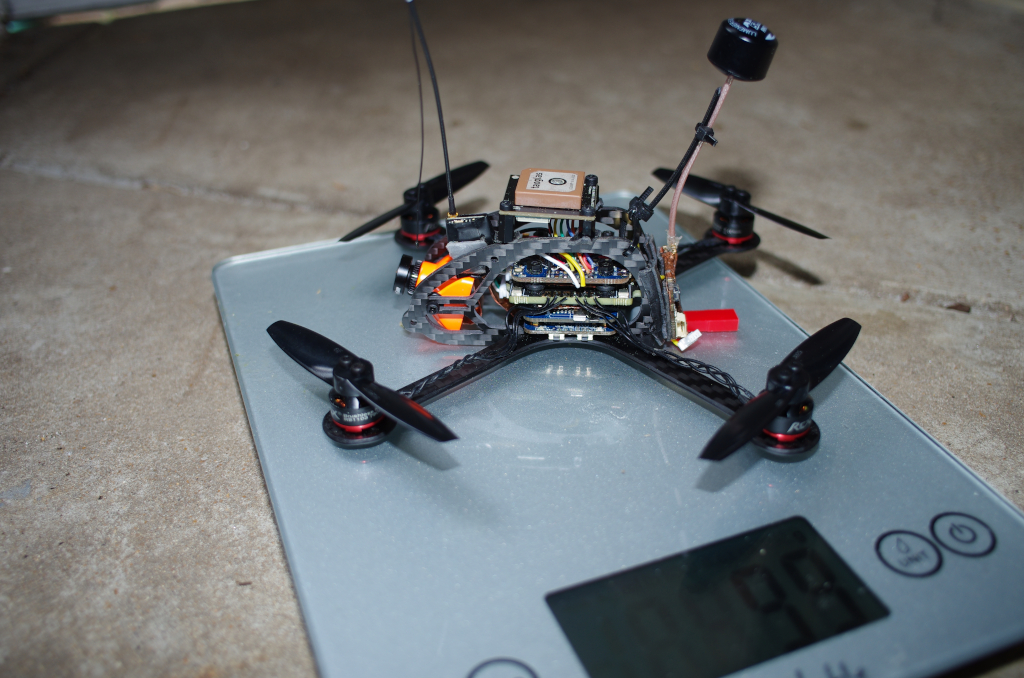
Per AP here, FlywooF745. I flew my 3 inch long range Quad yesterday successfully. AltHld and Loiter worked perfectly. Need some work on decreasing vibrations and then on to tuning, and mounting O4 Unit lite. I used Volador 3 inch frame, TBS CRSF Nano RX, 4S1P Li ion 3000 mah, and GepRC 1804 SpeedX2 2450, HGLRC GPS (very reliable), ESP01s (and not ESP01) for telemetry with instructions from here. I would be happy to share the parameters with the community, given the restrictions for over 250 grams quads.
I have used Kakute H7 mini, V 1.3 very successfully. @dkemxr thanks for confirming for 1.5. Kakute H7 mini is my go to for a serious, long lasting build. I welcome other opinions of course .
What flight time do you get with that drone? That battery sounds too big for under 250g, but I don’t know. (Mine are a bit over 250g, but close.. I think I could get one under it now, with smaller FC’s and ESC’s available now)
I’ve also got long range 3” quads. 2.4ghz video. TBS CRSF. 2s lipo or li-ion. Can fly for about 10 minutes, and have gotten 2 km away, near Death Valley national park (in the middle of the desert with no interference around). The video was quite bad, and I turned around as soon as it hit 2km.
My pleasure, and thank you for your patience as I clarify a few things—sometimes it helps to keep my thoughts more coherent before replying! I haven’t yet built a long-range sub-250g quad; in fact, the Volador isn’t quite sub-250 grams with a Li-ion battery. My most recent build is a sub-150g, 2-inch quad running on a 3S LiHv 550mAh battery, Kakute H7 mini 1.3, TBS CRSF RX, ESP01S telemetry, and 2.4 GHz video. While I just finished tuning it, I haven’t had a chance to time the flights yet, as life and work have been keeping me busy—hopefully, I’ll have more time for this once I retire in a few years.
My most solid Kakute mini H7 build is a 3.5-inch long-range quad that weighs about 350 grams or so. I haven’t officially timed its flights either, but it feels like it keeps going for ages on a 4s1P Li-ion. It’s still running AP 4.5.5, since I’m a bit cautious about updating and potentially risking this reliable setup.
Next up, I’ll be cleaning up a 3-inch Cinewhoop based on Kakute, still on AP 4.5.7, as a tester for AP 4.6. I’m always happy to share the parameters from any of my quads, and since I’m still learning, I appreciate all the opinions and advice from the experts and enthusiasts in this community.
Looking forward to hearing your thoughts and suggestions!
I’m working on a 3” with the flywoo Goku AIO with a 3S 3000mah liIon pack. I’m right at 250grams. I’m on track for 20+ minutes. I had 17 minutes on 2S (and still a lot of gas in the tank) but I ran into a low voltage issue with the ESC so I couldn’t get what I was looking for out of.
My first suggestion is to get a subscription to ecalc.ch and spend some time with that trying to figure out motor and props. At this point I’m guessing it’s saved me a ton of cash. I’ve found if you take the time with it and get all the variables where they should be it can be accurate enough to help you make truly enformed buying decsisions rather than just relying on some random youtube or forum post about what motor and prop to buy.
My other comment is that it’s not always worth sharing parameters between builds. There’s too many variables in terms of setup that any time you think it’s going to save you ends up more than lost in trouble shooting why it’s not flying well (if at all). Better to just follow a procedure such as AMC and build your own.
I’ve built two sub 250 gram Arducopters, a 3.5” ImpulseRC Micro Alien (4” arms, 3.5” props) and a 4” LR Explorer. Both frames are/were available with 3” arms. If your aim is to be sub 250 grams then frame selection is critical. There don’t seem to be many light frames that accommodate a 20mm stack & GPS.
My LR Explorer has a Kakute H7 Mini v1.3, Mamba F30-BLS Mini, Walksnail WS-M181 GPS (with compass) & Xing 1404 motors. Flight time with a 650mah LiPo is around 8 minutes.
My Micro Alien has a Speedybee F405 Mini stack, a Walksnail WS-M181 GPS & T-Motor 1604 4S motors. Flight time with a 650mah LiPo is around 6 minutes.
The F405 is very tight for log space, but I was able to get a good tune. The H7 Mini is also tight..
Both copters perform well. The Micro Alien is very fast, but the GPS performance is worse because it’s closer to the rest of the electronics. I also think I might have overdone it with the motors - 6S motors might have been a better match for the light weight of the build.
If I was starting a sub 250g 3.5” build now I’d consider the SupaFly Flip Mini & Quadmula Siren F35 Split. ImpulseRC Apex Mini, Grinderino & Volador 3/3.5” frames are too heavy.
I have build and flown four small 3” and 5” quads using MicoAir f405 boards. They also carry H7 boards. A distributor in Canada have some stock. For a small quad it is extremely important to have good compass.
By 4s and 6s motors, is that the voltage they’re rated for? Do you actually use batteries that big? (aren’t they heavy?)
I had a different philosophy for my tiny builds.. I wanted to keep everything as light as possible. My copters w/out battery come in at just under 100 grams. And my batteries weigh about 50 grams. (and this is with products available in 2018.. I can probably get lighter w/ newer components)
I use much smaller motors than ecalc would recommend.. Ecalc says I’ll burn them up. But I’ve got many hours of flights on these w/out problems. I’m not flying at full throttle often. So, tiny 1103 motors at about 10,000kv. 2s battery. I get 7 minute flights w/ my smallest battery. 20 minutes if I use two li-ion’s. It can fly almost 150kph. -edit to mention 2 blade, low pitch props are part of this equation.
I’ll post a couple links to photos from my old thread..
Started with this: (Not sure why it’s not showing the photo in-line)
Then here’s a heavier long range one w/ 2.4ghz video. I have grounded foil tape on a lot of components, and wrapped around the video cable. All wires tightly twisted. Low ESR caps on the battery terminals and the 5v rail of the FC to help lower electrical interference. It’s a tight build!
The P1604 motors are available with two different windings. 2850KV is aimed at 6S batteries, 3800KV is aimed at 4S batteries. I’m using Dogcom UCell 4S 650mAh packs with that copter. They’re a little heavy at 88g, but they’re rated at 150/300C and they don’t sag much at full throttle. The logs show a maximum ground speed of 86mph, and IIRC it’ll climb vertically at around 70mph. As an inexperienced fpv pilot, I would be very happy with 3/4 of that performance, hence the comment. I built it as a low cost beater - it’s not a long range endurance machine!
I’m using Tattu 650mAh 4S (non R-Line) lipos with the LR Explorer. They are a lot lighter, enabling the addition of a companion computer whilst staying under 250g.
 .