Hello,
I am investigating a crash of a 15-inch quadcopter running ArduCopter V4.6.0 and would appreciate help identifying the root cause.
Aircraft / Power Setup
- Frame: 15-inch quadcopter
- Flight Controller: ArduPilot
- Firmware: ArduCopter V4.6.0
- ESC: T-Motor Cine 80A 4-in-1
- ESC firmware: AM32
- Battery: 8S
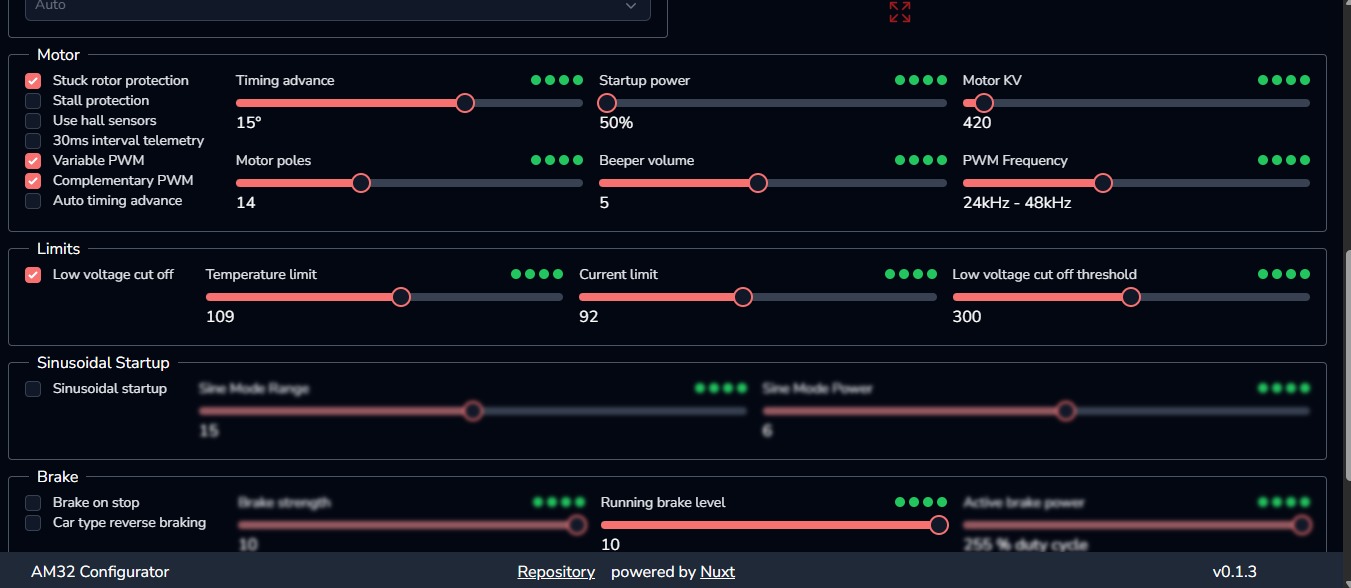
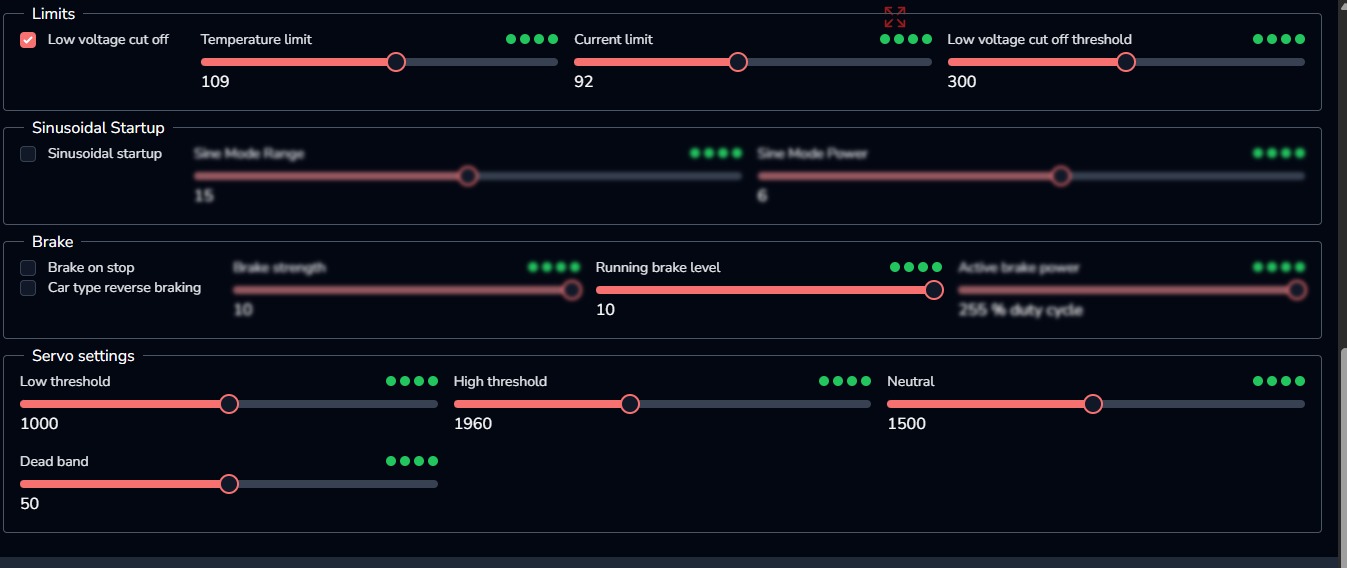
- AM32 Low Voltage Cutoff: 3.00 V/cell
- AM32 Current Limit: 92 A
- Temperature Limit: 109°C
What happened
The aircraft was hovering normally at approximately 5–6 m altitude. There was no significant roll or pitch disturbance before the incident.
The aircraft suddenly lost propulsion and crashed.
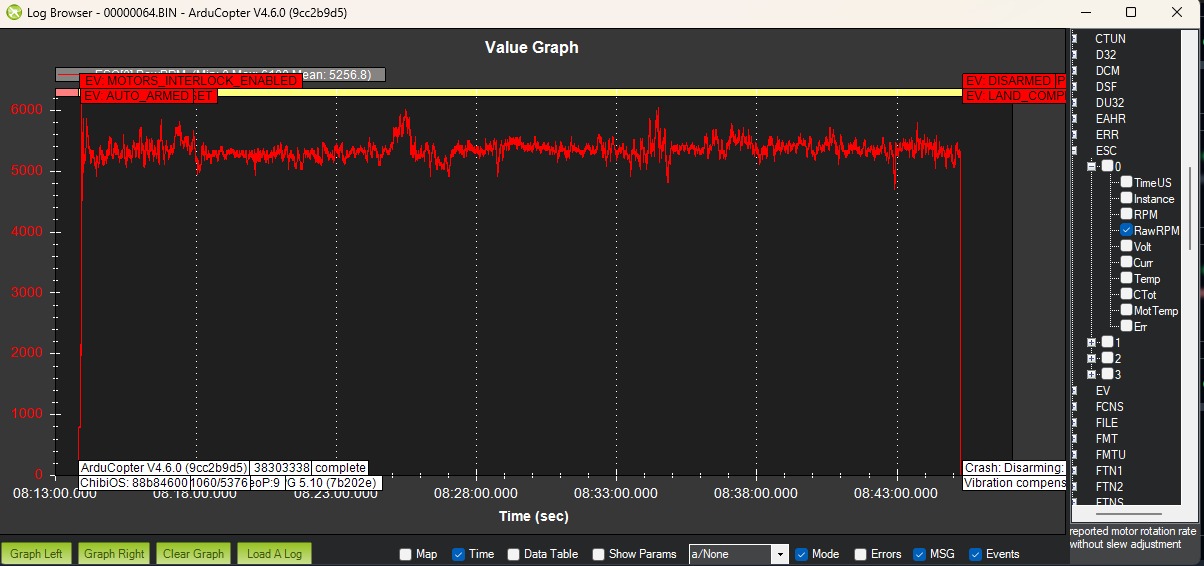
The important point is that the motor RPM suddenly dropped to zero while the flight controller was still operating and continuing to record data.
ESC telemetry
Before the incident:
- ESC RPM: approximately 5,100–5,600 RPM
- ESC current: approximately 63–65 A
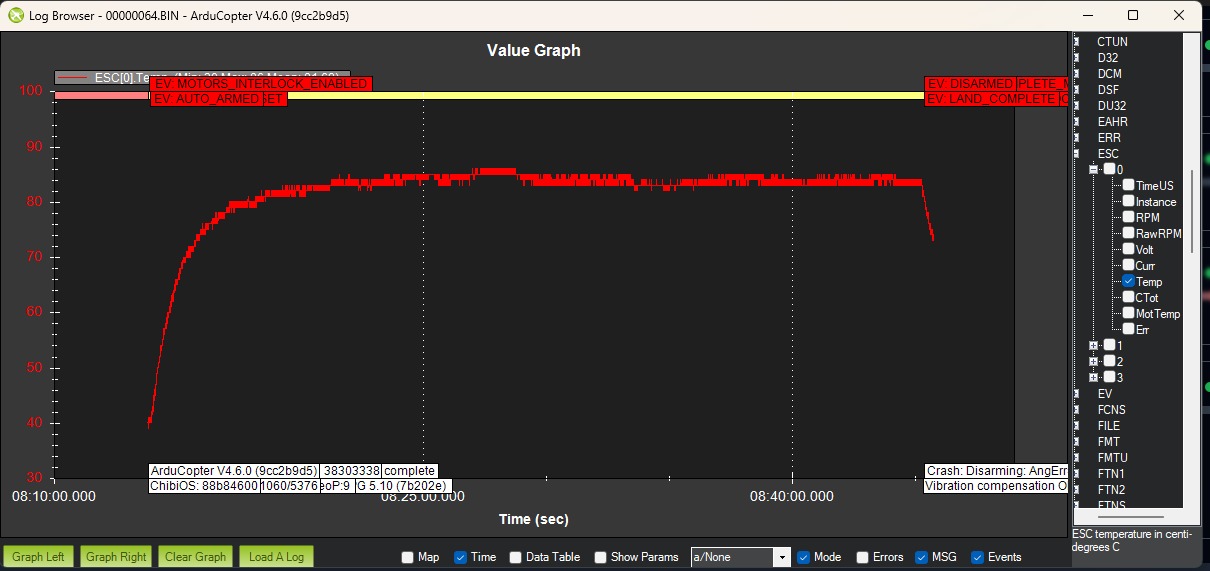
- ESC temperature: approximately 83–85°C
For example, ESC3 RPM remained around 5,200 RPM and then suddenly dropped to 0 RPM.
There was no gradual RPM reduction.
ESC Error telemetry
I checked:
ESC0.ErrESC1.ErrESC2.ErrESC3.Err
All four show:
Min = 0, Max = 0, Mean = 0
So there is no ESC error flag recorded in the ArduPilot ESC telemetry.
Battery
The battery voltage did not show a sudden voltage collapse before the incident.
The minimum recorded voltage was approximately:
25.85 V on 8S ≈ 3.23 V/cell
The AM32 low-voltage cutoff was configured for:
3.00 V/cell
Therefore, the logged voltage does not appear consistent with a low-voltage cutoff event.
RCOU behavior
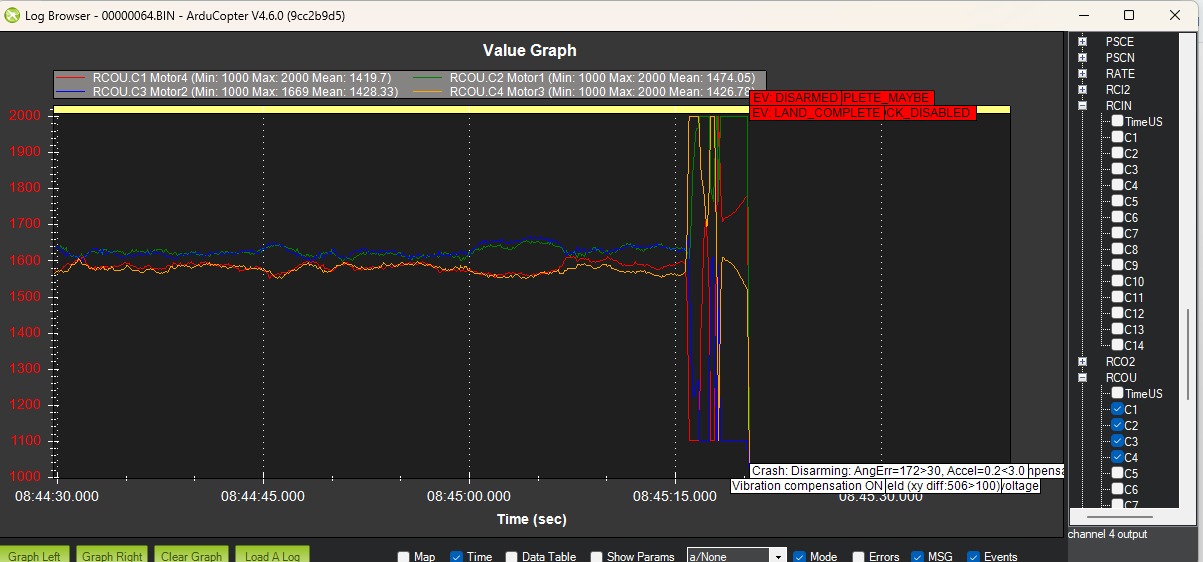
Before the failure, the RCOU outputs were relatively stable at approximately 1550–1650, consistent with hover.
Around the failure, the RCOU outputs began changing significantly, with some channels going toward approximately 1100 and others toward 1800–2000.
The outputs were not immediately all at 1000.
Later, after the crash detection/disarm sequence, the outputs went to approximately 1000.
Crash events
The log contains:
FAILSAFE_VIBE
CRASH_CHECK
and:
Crash: Disarming: AngErr=172>30, Accel=0.2<3.0
My understanding is that the AngErr crash-disarm message may be a consequence of the aircraft losing thrust and attitude, rather than necessarily being the original cause of the failure.
Main Question
I am trying to identify why the ESC RPM suddenly dropped to zero during flight.
The ESC telemetry shows a sudden RPM drop from approximately 5,100–5,600 RPM to 0 RPM, but we have not identified any solid reason for an ESC cutoff.
The available telemetry does not indicate:
- Low-voltage cutoff — battery remained above the configured 3.00 V/cell threshold.
- Over-current protection — current was approximately 63–65 A, below the 92 A current limit.
- Over-temperature protection — ESC temperature was approximately 83–85°C, below the 109°C limit.
- ESC error —
ESCx.Errremained 0.
Therefore, I would like to understand what could have caused the ESC RPM to suddenly become zero and whether the flight log can help identify the actual cause of this RPM loss.
Any guidance on determining the reason for this sudden ESC RPM drop would be greatly appreciated.
Thank you for your help.