Hello
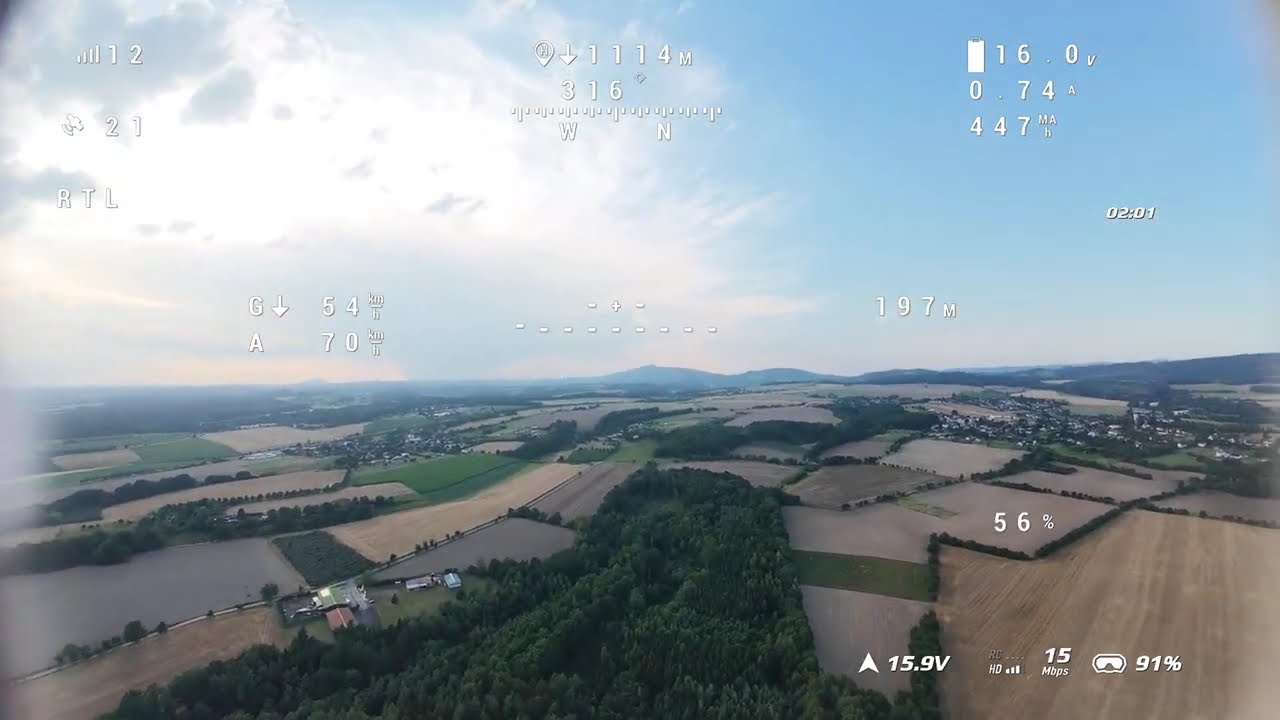
I discovered problem how Arduplane TECS controls airspeed of my plane in AUTO/RTL modes. It makes absolutely no effort to prevent stall. I performed test which is visible in the video where I disabled motors during RTL mode and the aircraft tried to maintain altitude disregarding the airspeed. The airspeed dropped below AIRSPEED_MIN=14 m/s and AIRSPEED_STALL=12.5 m/s and resulted in stall. Although my aircraft does not have physical airspeed sensor, the displayed estimated airspeed is not very wrong. What can I do to make aircraft to pitch down in this situation?
Check the TECS_SPDWEIGHT. Default is 1, but for this you might consider pushing it up towards 2. Go up in steps about .1 or .2 at a time and make sure it doesn’t cause any other issues.
Stall prevention, for example, increases speed or the turn radius if you try to fly too tight a turn at too low a speed. See the detailed description in the WIKI:
TECS isn’t intended for engine failure. You can use a “dirty” workaround to force TECS to make the plane descend with negative pitch during an engine failure by changing TECS_PITCH_MAX and TECS_PITCH_MIN via a LUA script—for example, to match best pitch for optimal glide performance.
So I tried to enable synthetic airspeed and it solved the problem. Not only it does not stall in RTL/AUTO mode but it also resolved other problem I had that aircraft most of the time flied much faster than necessary in AUTO mode.
 .